
Working With the Hitachi RC Z3 Controller
The Hitachi RC Z3 is a CNC controller board that was popular in mid-range routing machines from the late 1990s through the mid-2000s. It sits between the computer and your drive motors, translating G-code into actual motion. If you are running an older Hitachi or compatible router, you are probably dealing with this board or a clone of it. They still show up in shops everywhere because they work, even though the documentation is scattered and sometimes contradictory. Official documentation from Hitachi for this unit is essentially impossible to find on any corporate site. The original manuals were distributed on CD-ROM or as printed booklets with the machine. What exists now lives in a few places: CNC-related forums where users have scanned copies, secondhand equipment marketplaces where sellers include paperwork, and archived industrial sites. I have found functional PDFs on a few niche CNC boards, but the links rot fast. Your best bet is searching the exact model number along with "PDF" or "manual" on those forums, or reaching out to people who sell refurbished Hitachi routers. They usually have a folder of scanned docs. The manual you need covers three main areas: wiring and connections, parameter settings, and the operator panel interface. If you only get one document, make sure it has the parameter list. That is the part people lose and then struggle with.
Setting Up the Controller From Scratch
I had a RC Z3 board delivered without any paperwork two years ago. It was sitting on a bench after being pulled from a decommissioned router. The first thing you need to do is verify the power supply. This board runs on 24V DC. Connect a properly rated power supply to the terminal block, observing polarity. Get that wrong and you will smell smoke within seconds. I learned that from experience. The board has reverse polarity protection on some revisions, but not all, so double-check before powering up. Once power is confirmed, you need to wire the axis drivers. The RC Z3 has terminal blocks for X, Y, and Z axes, each providing pulse and direction signals. Connect your stepper or servo drivers to the appropriate terminals. The manual will show which pins correspond to which axis, and on some board revisions the layout differs slightly, so do not assume pin-out consistency across all units. I found that one of my boards had the Y-axis and Z-axis labels swapped on the silkscreen compared to the documentation. I caught it by tracing the traces with a multimeter rather than trusting the print. After the axes are wired, connect the computer interface. The RC Z3 uses either a parallel port or a USB-to-parallel adapter for communication with control software like Mach3 or similar CNC controllers. Parallel port is the native and most reliable method. USB adapters work but introduce latency that can cause missed steps at higher feed rates. If you are running a modern computer without a parallel port, invest in a proper PCI-e parallel card rather than relying on a cheap USB dongle. I ran a job once on a USB adapter and the machine skipped a contour pass because the adapter buffered the pulse stream inconsistently. Switching to a PCI-e card eliminated the issue entirely.
Parameter Configuration
This is where most people get stuck. The RC Z3 relies on internal parameters to define step pulse width, axis direction, maximum speed, acceleration, and home switch behavior. These parameters are set through a combination of the onboard buttons and a small LCD panel, or sometimes through the control software depending on your setup. You enter parameter mode by holding specific keys during power-up, but the key combination varies by firmware revision. There is no universal combination, which is frustrating. Some of the critical parameters you need to get right include: Parameter 0-3: Axis selection and step pulse configuration. These determine which physical terminal outputs control which axis. If your axes are moving in the wrong direction or the wrong axis is responding, check these first.
Get the Full Details
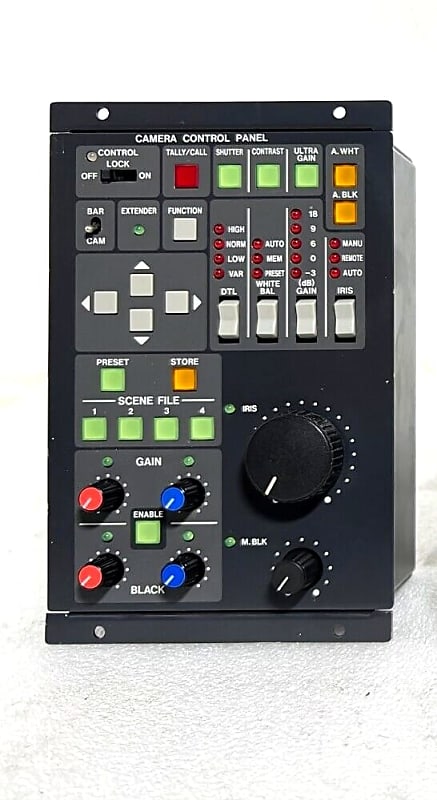
Parameter for max velocity and acceleration: Set these based on your mechanical limits, not what the board can theoretically handle. I saw someone set the acceleration to the maximum value on a router with worn ball screws and belt drives. The machine vibrated itself apart within three minutes. Start conservative and work up. Home switch parameters: These control how the homing cycle behaves, including search speed and latch speed. Getting these wrong means your machine will either overshoot the home position repeatedly or not register the home switch at all. The manual explains the difference between single-direction and dual-direction homing, and you should match that to your physical setup.
Common Problems and What Actually Works
The RC Z3 boards are generally reliable hardware, but they age poorly in certain conditions. The electrolytic capacitors on the board degrade over time, especially in shops with heat or dust. A failing capacitor will cause intermittent communication errors or random axis drops. I replaced the main filtering capacitors on two of these boards and it resolved issues that had been traced back to "software problems" for months. Visual inspection of the capacitors for bulging or leakage is worth doing before you blame your CNC software. Another issue is the parallel port connector on the board. These are DB25 sockets and they develop loose connections over time as cables are plugged and unplugged. The result is stuttering motion or complete loss of one axis during a job. I solved this by adding a small amount of solder to the pin contacts inside the socket to tighten the grip on the cable connector. It is not a pretty fix, but it has held for over a year of daily use. The operator panel keypad is also a wear item. The membrane switches inside become unresponsive, usually starting with the arrow keys or the enter key. When that happens, you can still operate the board through your CNC control software for most functions, but you lose the ability to adjust parameters on the board itself unless you have an alternative input method. Some users have successfully replaced the membrane with custom-made equivalents, but the sourcing is difficult. Keeping a spare keypad is reasonable if this is your primary machine.
Software Compatibility Realities
The RC Z3 was designed for older Windows environments. It works with Mach3 without major issues on Windows 7 and earlier. Running it on Windows 10 or 11 introduces driver compatibility layers that may cause timing irregularities. If you are planning to run this board on a modern OS, expect to spend time tuning step pulse parameters to compensate for OS-level scheduling delays. I typically recommend keeping a dedicated older machine for the RC Z3 if possible, or at minimum a clean install of Windows 7 in a virtual machine with proper hardware passthrough, though VM-based CNC control is inherently risky for production work. Post-processors and G-code generators need to output the right format for this controller. The RC Z3 understands standard G-code but has some limitations on macro commands and certain canned cycles. Complex tool paths that rely heavily on peck drilling cycles or adaptive clearing may need to be simplified. I had a user try to run a heavy adaptive clearing program through this board and the controller buffered overflowed, causing the machine to pause mid-cut. Reducing the lookahead buffer size in the software settings and breaking the job into smaller sections resolved the issue, but it cost several hours ofprogramming.

Limitations You Should Know About
This board is not a solution for high-speed or high-precision work. The pulse generation architecture limits how fast and smoothly axes can move compared to modern controllers. If you need sub-thousandth repeatability or feed rates above 100 inches per minute, the RC Z3 will struggle regardless of how well you tune it. It is fine for sign making, light woodworking, and low-volume production where the work envelope and speed requirements are moderate. It is not fine for aerospace composites machining or anything that demands consistent high-speed contouring. The documentation gap is also a real limitation. There is no official support channel, no firmware updates from Hitachi, and no community-wide parameter reference that covers all revisions. You are largely on your own for troubleshooting beyond the basic wiring and parameter setup. If you are not comfortable experimenting and reading technical schematics, this controller will be frustrating. A newer controller like a Mach4-based system or a dedicated motion controller would provide better documentation and support, though at a higher cost and with the trade-off of requiring a different machine integration. If you can track down a complete manual with the full parameter table for your specific firmware version, do so and save it locally. Those documents are getting harder to find with each passing year, and losing access to them when you need them is a genuine operational risk.


