Figuring Out Acceleration When It Actually Matters
Most people learn acceleration as dv/dt or F/m and then immediately forget how fragile that becomes when you try to use it on a real system. I've spent years debugging measurement setups where the textbook answer was wrong not because the math was wrong but because the sensor environment destroyed the signal before it ever reached the ADC. The question ofHow Do You Determine Acceleration
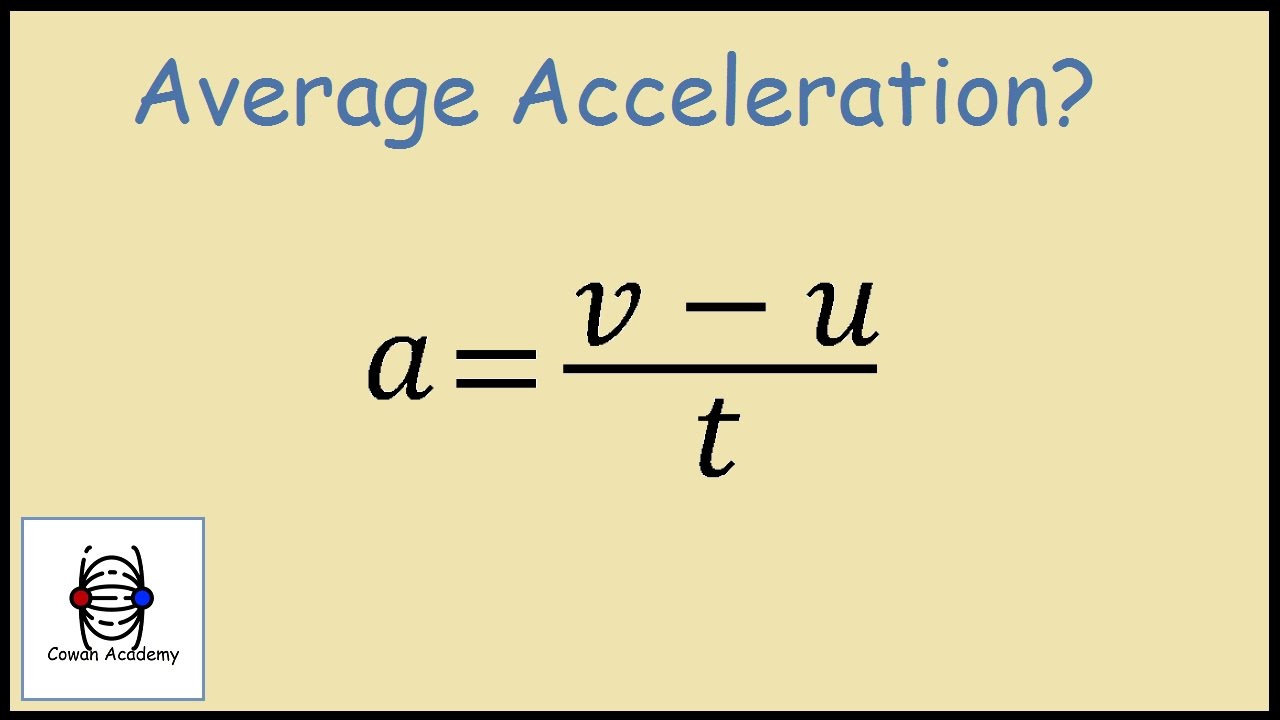
has a different answer depending on whether you're reading a spec sheet or you're trying to make something move predictably in the real world.The baseline approach is straightforward: apply a known force to a known mass and divide. Or measure velocity change across a time window and divide. Both give you the same number on paper. On paper. Real systems inject friction, compliance, sensor noise, temperature drift, and mounting resonance into that calculation until the clean number looks suspiciously optimistic. I work mostly with vehicle dynamics and robotic actuation, so my default method is to use an IMU mounted rigidly to the structure and fuse it with wheel encoders or GPS depending on the speed regime. IMU gives you direct specific force output along three axes. You subtract gravity by aligning the sensor frame with the body frame, then integrate or differentiate as needed. The trick is that the mounting point matters more than anyone admits. A bolt that flexes at 40 Hz will produce readings that look like acceleration when it's actually structural resonance. I learned that the hard way on a test rig where the numbers suggested we had twice the thrust we actually produced. The fix was swapping the aluminum bracket for a steel plate and re-torquing everything to spec. Measurement jumped into alignment with the force gauge within an hour. When direct sensing isn't available, you fall back to kinematic methods. You record position at discrete intervals and compute acceleration through finite differences. Two-point differentiation amplifies noise dramatically, so people usually smooth first with a moving average or a low-pass filter, then differentiate. That works until the signal has sharp transients. A step input gets smeared by any aggressive smoothing and you end up measuring filtered acceleration instead of actual acceleration. I ran into this on a robotic arm project where the joints experienced rapid direction changes. The smoothed data looked clean but systematically lagged the real acceleration by roughly 80 milliseconds. That lag translated into positioning errors at the endpoint that exceeded tolerance. The workaround was switching to a Savitzky-Golay filter, which fits a polynomial locally and preserves peak amplitude better than a standard exponential moving average. It didn't eliminate the error but reduced it to something usable.
Another angle people overlook is force-torque sensor based determination. If you have a calibrated six-axis sensor at the base of a manipulator or under a wheel contact patch, you can back-calculate acceleration from the measured force field. This sidesteps the noise problem of accelerometers entirely for translational components. The downside is that force sensors are expensive, they drift with temperature, and they measure everything including gravity and inertia coupling. You still need the mass matrix to separate what's acceleration from what's just weight distribution. I once worked on a system where the operator assumed the force sensor read pure dynamic force. It didn't. Gravity loading shifted as the arm articulated, and the uncorrected readings suggested acceleration spikes that never actually happened. The correction was a simple static calibration at multiple poses and subtracting the gravitational component before converting force to acceleration.
Practical constraints nobody mentions
MEMS accelerometers have a noise floor that limits low-acceleration resolution. Anything below roughly 0.01 g gets buried in random walk noise unless you average heavily, and heavy averaging kills bandwidth. If your application involves slow, precise movements like a precision positioning stage or a medical device, you're better off using laser interferometry or encoder-based displacement measurement and differentiating position rather than relying on the onboard accelerometer. Encoder-based differentiation gives you cleaner low-frequency response even though high-frequency content suffers from quantization steps. Temperature is another silent killer. A typical MEMS sensor drifts by about 0.001 g per degree Celsius. In a field deployment where ambient temperature swings from 10 to 40 Celsius, that's up to 0.03 g of offset drift. You can compensate with a two-point calibration at known temperatures, but the compensation only holds if the sensor package itself reaches thermal equilibrium. Thermal gradients across the silicon die cause non-uniform expansion and introduce cross-axis sensitivity that looks like acceleration in a direction where nothing is accelerating. I spent two days chasing a phantom lateral acceleration signal on a drone test before realizing the IMU housing was heated unevenly by the ESC running nearby. Shifting the sensor location and adding a thin thermal layer eliminated the artifact. Sampling rate selection is often done wrong too. People pick a rate that's high enough to capture bandwidth but forget about aliasing. If your anti-aliasing filter rolls off slowly, signals above half the sampling rate fold back into the band and contaminate the acceleration estimate. A 1 kHz sampling rate with a gentle 100 Hz roll-off will let significant energy from 400 to 500 Hz alias down into the useful range. Use a proper anti-alias filter with at least 4th order rolloff and sample at least 5 to 10 times the bandwidth of interest. For most mechanical systems, that means 2 to 5 kHz sampling with adequate filtering, not the 500 Hz that a lot of off-the-shelf IMUs default to.
Get the Full Details
When all else fails and you need an independent check, use a reference method. A pendulum gives you a gravity-referenced acceleration check. A calibrated shaker table lets you verify frequency response. A simple drop test against a high-speed camera gives you a sanity check for free-fall acceleration. I keep a laser disto and a high-frame-rate phone camera for quick verification on site. It takes about ten minutes and catches mounting or calibration issues that would otherwise hide for days in the data.