Getting Vibration Data Off a Running Motor
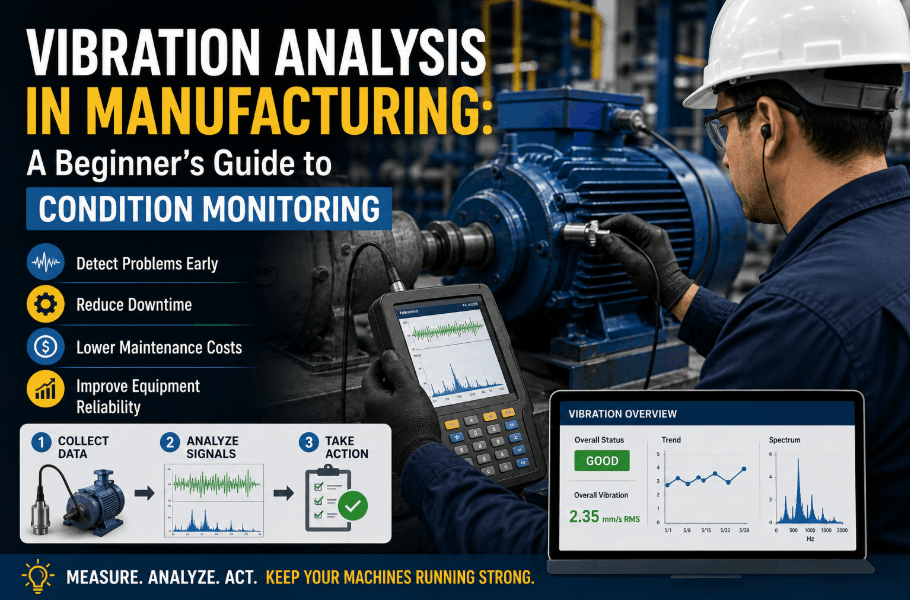
You slap a sensor on a machine housing, the analyzer starts collecting, and then you spend the next twenty minutes staring at a spectrum and trying to figure out what's wrong. That's basically what vibration analysis is. It's the practice of measuring oscillatory motion on mechanical equipment, breaking that motion down into its component frequencies, and using those frequencies to identify faults before they turn into downtime. The acceleration transducer is the workhorse. You screw it to the bearing housing or mount it with a magnetic base, route the cable to the collector, and you're picking up g's of acceleration. The sensor outputs a voltage proportional to the acceleration it senses. The analyzer digitizes that signal, runs it through an FFT, and gives you a frequency-domain display. Each peak in that spectrum corresponds to a physical event repeating at a specific rate. The trick is knowing which rate maps to which failure mode. I've seen people skip theFFT and just look at overall velocity or RMS acceleration. That works fine for trend monitoring — you can track a motor over six months and watch the number creep up. But once you need to diagnose, overall values tell you nothing about what's actually happening inside the machine. A bearing defect, an imbalance, misalignment, and a gear mesh problem can all produce the same overall velocity reading. The spectrum doesn't lie. The summary numbers often do.
Reading the Spectrum Without Losing Your Mind
Start with what you know about the machine. Every rotating component has a characteristic frequency. Shaft speed is 1x RPM divided by 60, giving you Hz. Bearing defect frequencies are calculated from the geometry — BPFO for the outer race, BPFI for the inner race, BSF for the rollers, FTF for the cage. Gear mesh frequency is the number of teeth multiplied by shaft RPM divided by 60. These are the landmarks on your spectrum. Everything else is noise or a secondary effect. Here's something most beginner guides don't emphasize enough: amplitude modulation is often more diagnostic than the peak itself. When you see a bearing defect frequency, the real confirmation comes from looking for its sidebands. If the defect frequency is modulated at the shaft rotational frequency, that's your smoking gun for an inner race fault. Outer race faults show up with no modulation at all because the defect passes through the load zone once per revolution. I spent an entire shift chasing what I thought was a bearing issue on a 1800 RPM pump motor. The spectrum showed a clean 2x line amplitude and a bunch of random peaks. Turned out the real problem was a loose foundation bolt on the right-hand foot. The loose bolt created an impact every time the shaft rotated twice — the 2x was the bolt hitting, not a misalignment. You learn to stop trusting the first pattern that looks familiar.
Where the Method Actually Fails
Vibration analysis is not a universal solution. It struggles in three specific situations that will cost you if you don't know about them upfront. First, low-speed machinery. Below about 500 RPM, the frequency resolution gets coarse and the bearing defect frequencies drop into a range where environmental noise dominates. You're measuring micrometers per second of signal against millimeters per second of background vibration from the floor, nearby equipment, and hydraulic flow. At those speeds, oil analysis and thermography usually give you more useful data than acceleration measurements. I learned this the hard way on a 360 RPM ball mill gearbox. The vibration signatures were buried so deep in the noise floor that every peak looked like a potential fault and nothing looked confirmable. Switched to infrared thermography on the bearing housings and caught a failing pinion bearing three weeks before it actually seized. The vibration data could have told us something if we'd taken long enough trend samples, but we were on a tight schedule. Second, heavily damped systems. If the sensor mounting is soft or the structure itself absorbs energy — rubber-mounted equipment, flexible couplings, composite housings — the high-frequency content gets eaten before it reaches the transducer. Bearing defects generate broadband energy in the ultrasonic range. A rubber mount will kill that energy completely. You need to bond the sensor directly to the metal, not press it against a painted or coated surface. I've seen technicians run surveys on machines with thick paint layers and wonder why their high-frequency metrics came back clean while the bearing was literally falling apart inside the housing. Scrape the paint. Or use an stud mount.
Get the Full Details
Third, electrical faults masquerading as mechanical problems. A failed stator bar or rotor eccentricity in a motor produces vibration at line frequency and its multiples. That 60 Hz (or 50 Hz) peak shows up in exactly the same place as a structural resonance or a loose part. The differentiation requires looking at the load response — if the amplitude changes significantly when you vary the motor load, it's electrical. If it stays constant, it's mechanical. Most field technicians don't change the load during a survey because it feels complicated. It takes about thirty seconds to request a load change from the operations team and it prevents half the misdiagnoses I see in the field.
Practical Setup Details That Matter More Than Theory
The measurement channel configuration determines whether your data is useful or garbage. Here's the minimum setup I use on any rotating equipment survey: Each bearing location gets at least two measurement axes — horizontal and vertical. Axial is mandatory on anything with thrust loading or axial play, because many faults like misalignment and certain bearing defects show up strongest in the axial direction. The sampling frequency should be at least ten times the highest frequency of interest. If you're looking for bearing defects on a 3600 RPM motor, that means a sampling rate of at least 10,000 Hz. Most modern collectors default to 25,600 Hz or higher, which covers everything you need without thinking about it. The averaging count matters too. Single-channel readings give you a snapshot. Ten-event averaging smooths out the random component and makes repeating patterns clearer. I use fifteen to twenty averages on most surveys. It adds maybe forty-five seconds to each point but cuts the false alarm rate roughly in half. The trade-off is real — you'll miss something transient that only shows up on a single hit. But the cost of chasing phantom faults is higher than the cost of missing a soft early-stage defect by a few days.
Phase analysis is the one tool that separates trend watchers from actual diagnosticians. Two-point phase measurements across a coupling or between bearing housings tell you whether two shafts are in plane or out of angular misalignment, whether a foot is loose, and whether a resonance is being excited. A phase difference of roughly 180 degrees across a coupling flange in the horizontal plane is soft foot. Same plane in the vertical, opposite in the horizontal — that's angular misalignment. Parallel offset shows as 0 degrees across the coupling in the radial direction. I've fixed more bad alignment jobs by running phase than by eyeballing shim marks on a coupling. The visual inspection is a starting point. Phase tells you whether the fix actually worked.
When to Call It Done
The standard is ISO 10816 for general machinery vibration severity. It gives you threshold values for velocity in the 10 to 1000 Hz band, broken down by machine size and mounting type. There's also ISO 7919 for shaft vibration on rotordynamic equipment, which uses displacement measurements rather than velocity. Both standards are guidelines, not laws. A factory running continuous process equipment at the "acceptable" threshold is in a different position than a seasonal manufacturer running the same equipment for three months a year. The numbers are the same. The business risk isn't. My rule of thumb is straightforward: if the overall velocity is under 0.15 in/s on a rigidly mounted motor, it's normal. Between 0.15 and 0.30 in/s, start trending and look for the pattern. Above 0.30 in/s, something needs attention. Above 0.50 in/s, it needs attention now. These values assume a standard 1800 and 3600 RPM machine on a steel base. Cast iron foot-mounted pumps on rubber isolators will read higher and still be fine. Always compare to the baseline you established when the machine was new, not to a textbook number. The baseline is the only number that matters.