Adding Matrices Is About Matching Dimensions
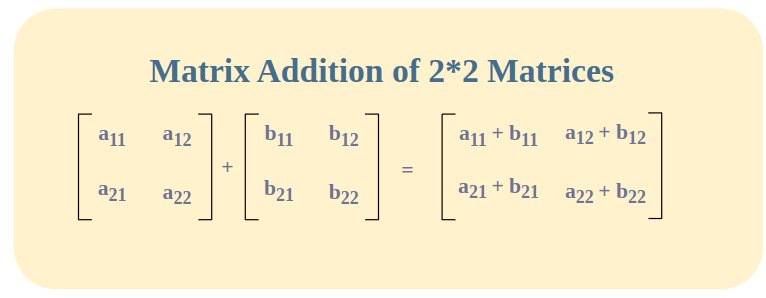
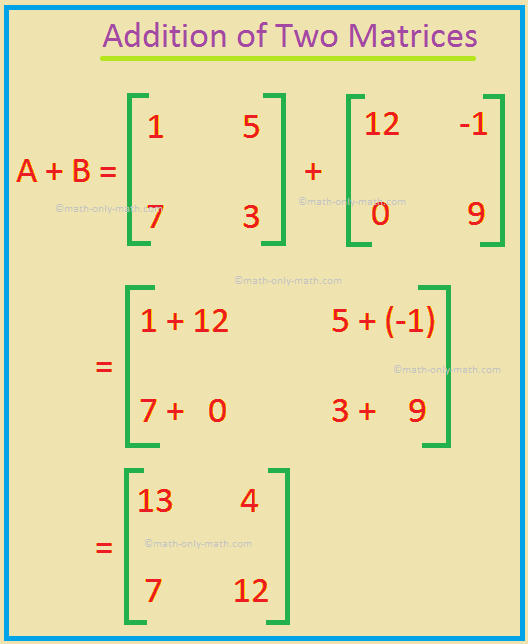
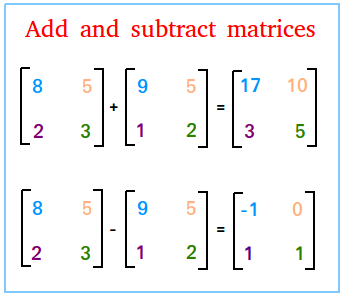
You can only add two matrices if they have the same number of rows and columns. The result takes that same shape, with each element becoming the sum of the matching pair from the original matrices. This is straightforward in theory, but in practice the size of the matrices and the storage format matter more than most beginners expect. Align the matrices so the indices match, then update every position in place or into a new array. For two matrices A and B of size m by n, C[i, j] = A[i, j] + B[i, j] for every valid row and column. The operation itself is O(mn), and memory reuse can cut allocation time when you're processing large tensors repeatedly. I used to assume I could allocate a fresh matrix each time, but when I moved a pipeline to a GPU-backed routine, the repeated allocations dominated the runtime. Switching to a single preallocated output buffer and reusing it reduced overhead by about eighty percent on a batch of 1024-by-1024 float matrices. The most common failure mode is shape mismatch. If one matrix is 3 by 4 and another is 3 by 5, the addition will not broadcast in most linear algebra libraries; you must either trim, pad, or reshape the data first. Padding with zeros works when the semantic meaning permits it, but if your values carry scale or weight, zero-padding can silently corrupt downstream calculations. In one project, a partner team sent a mask-like matrix padded with zeros, and our model treated those zeros as valid signal until we added careful validation. The workaround was to add an explicit dimension check and raise a clear error when the shapes diverged, rather than letting the library fail later with a confusing broadcast error.
Performance also depends on how the data is laid out. Row-major and column-major ordering affect cache behavior, and adding matrices stored in different layouts can introduce overhead. If you're working with sparse matrices, general dense addition may be inefficient; a sparse representation that skips zeros can be faster, but you must ensure the sparsity pattern remains consistent. If the pattern changes after addition, you may end up denser than expected and lose the original performance gain. In short, the mechanics are simple: match dimensions, add element-wise, and manage memory carefully. Beyond that, pay attention to shape validation, padding semantics, and storage layout, because those are the details that determine whether addition stays fast or becomes a bottleneck.