The Real Way to Handle Friction Calculations
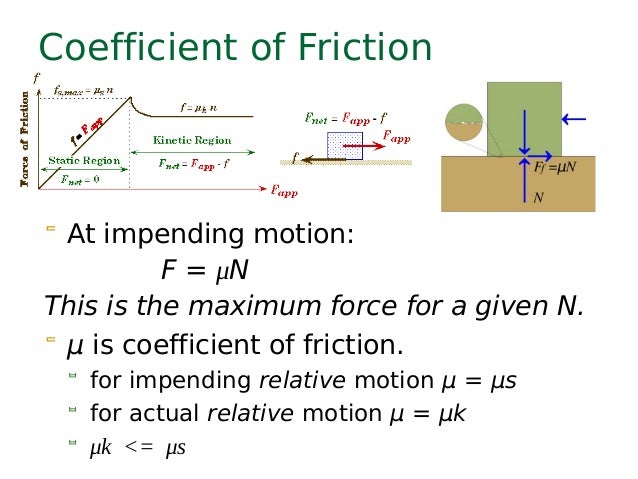
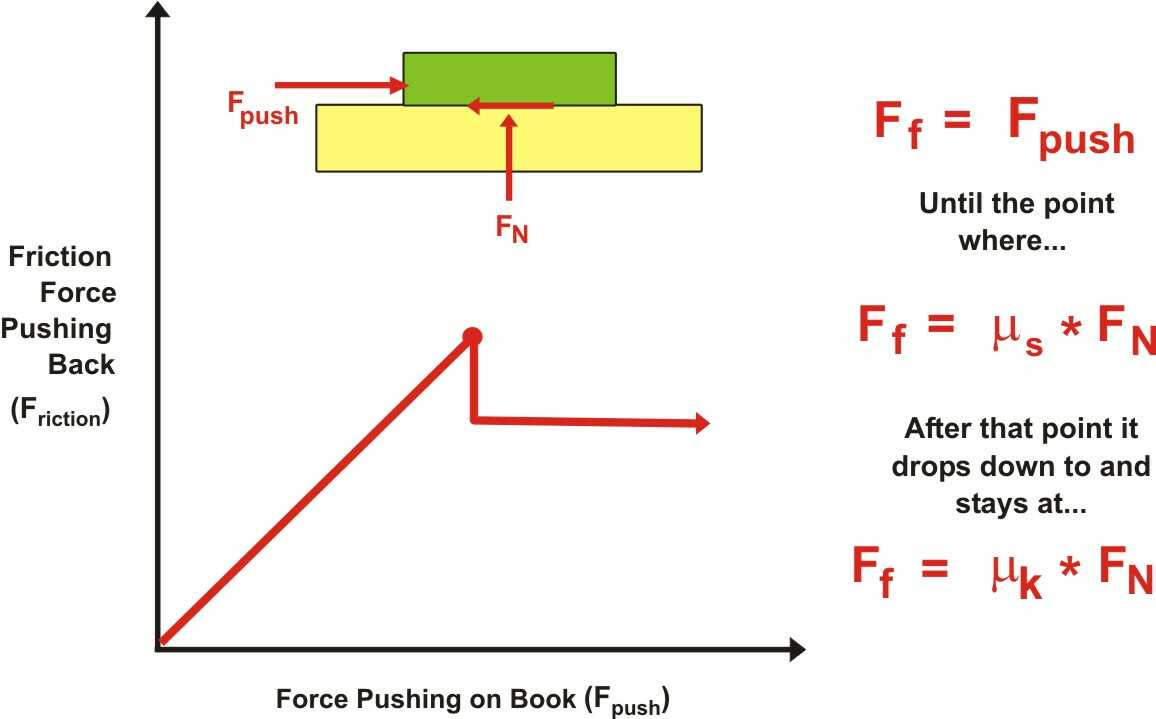
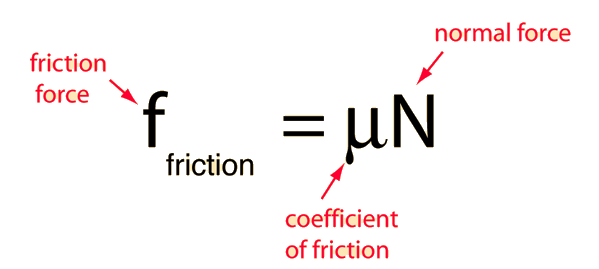
I used to think friction was just times N and move on with my day. That works for textbook problems where surfaces are smooth and normals are obvious. In the field, it rarely is. The first thing I learned the hard way is that the coefficient of friction isn't a fixed property you look up and trust. It changes with temperature, surface finish, speed, and whether there's lubrication or contamination between the materials. I spent three weeks debugging a conveyor system because the spec sheet listed a static coefficient of 0.4 and a kinetic of 0.3 for steel on steel, but under actual operating conditions with light oil splash and a few degrees of heat buildup, the effective coefficient settled closer to 0.18. Nobody had told me that. Start with the basic equation, which is deceptively simple: F_friction equals the coefficient of friction multiplied by the normal force. That gives you the magnitude. You need to figure out the normal force independently. It is not always equal to weight. On an inclined plane, the normal force is the component of the gravitational force perpendicular to the surface, which means m times g times the cosine of the angle. If there are additional vertical forces pushing or pulling on the object, those change the normal force too. A downward push increases it. An upward lift decreases it. Once you have the normal force, you pick the right coefficient. Static friction applies when the surfaces are not sliding relative to each other. The maximum static friction force is the static coefficient times the normal force. The actual static friction force can be anything from zero up to that maximum, depending on what is needed to prevent motion. Kinetic friction applies once sliding has started, and it stays roughly constant at the kinetic coefficient times the normal force. Static coefficients are generally higher than kinetic ones, which is why it takes more force to start something moving than to keep it moving.
Here is a practical example. A 50-kilogram crate sits on a concrete floor angled at 15 degrees. The static coefficient between the crate and concrete is 0.6 and the kinetic coefficient is 0.4. The normal force works out to 50 times 9.81 times the cosine of 15 degrees, which is approximately 474 newtons. The maximum static friction is 0.6 times 474, giving about 284 newtons. If you apply a horizontal pushing force of 200 newtons along the plane, the crate does not move because 200 is less than 284. The actual static friction force is exactly 200 newtons opposing your push. If you push with 300 newtons, the crate breaks free. Kinetic friction then takes over at 0.4 times 474, which is about 190 newtons opposing the motion. A detail that trips people up constantly: the friction force always acts parallel to the contact surface and opposite to the direction of impending or actual motion. Direction matters as much as magnitude. In multi-force systems, resolve everything into components parallel and perpendicular to the surface before applying the formula. If you skip that step, you will get the wrong answer every single time. I ran into a case a while back involving a belt drive system where the wrap angle created a large difference in tension between the tight and slack sides. The standard friction equation for flat surfaces does not apply directly. Instead, I had to use the capstan equation, which introduces an exponential relationship between the tension ratio and the coefficient of friction times the wrap angle in radians. A belt wrapped 180 degrees around a pulley with a coefficient of 0.3 creates a tension ratio of roughly e to the power of 0.3 times , which is about 2.5. That means the tight side can carry 2.5 times the tension of the slack side before slipping. Without that formula, I would have undersized the motor and the whole system would have slipped under load. Most introductory courses never cover this, and that gap costs engineers real money.
Another common pitfall is assuming friction is always resistive. It is not. Friction can be the driving force. When you walk, the friction between your shoe and the ground pushes you forward. When a car accelerates, static friction between the tires and the road propels the vehicle. In those cases, the friction force points in the direction of motion, not opposite to it. The rule is still the same: friction opposes relative motion between the surfaces. If your foot pushes backward against the ground, friction pushes forward on your foot. Getting this straight prevents conceptual errors in dynamics problems. Rolling resistance is a separate category entirely. A tire on pavement does not obey the same simple friction model. Rolling resistance depends on deformation of the tire and the surface, and it is typically modeled with a coefficient multiplied by the normal force, but the coefficient is much smaller than sliding friction coefficients. A car tire on dry asphalt might have a rolling resistance coefficient around 0.01 to 0.015, compared to a sliding friction coefficient of 0.7 or higher. Do not confuse the two. Using a sliding friction coefficient for rolling resistance will massively overestimate your braking distance or fuel consumption calculations. Limitations of the basic model: the standard friction equation assumes dry, unlubricated contact between relatively rigid surfaces. It breaks down when surfaces are heavily lubricated, when materials deform significantly, or when sliding speeds are high enough to generate substantial heat. In those regimes, you need more sophisticated models like Stribeck curves for lubricated contacts or finite element analysis for complex contact geometries. The simple formula is a starting point, not a universal law.
Get the Full Details
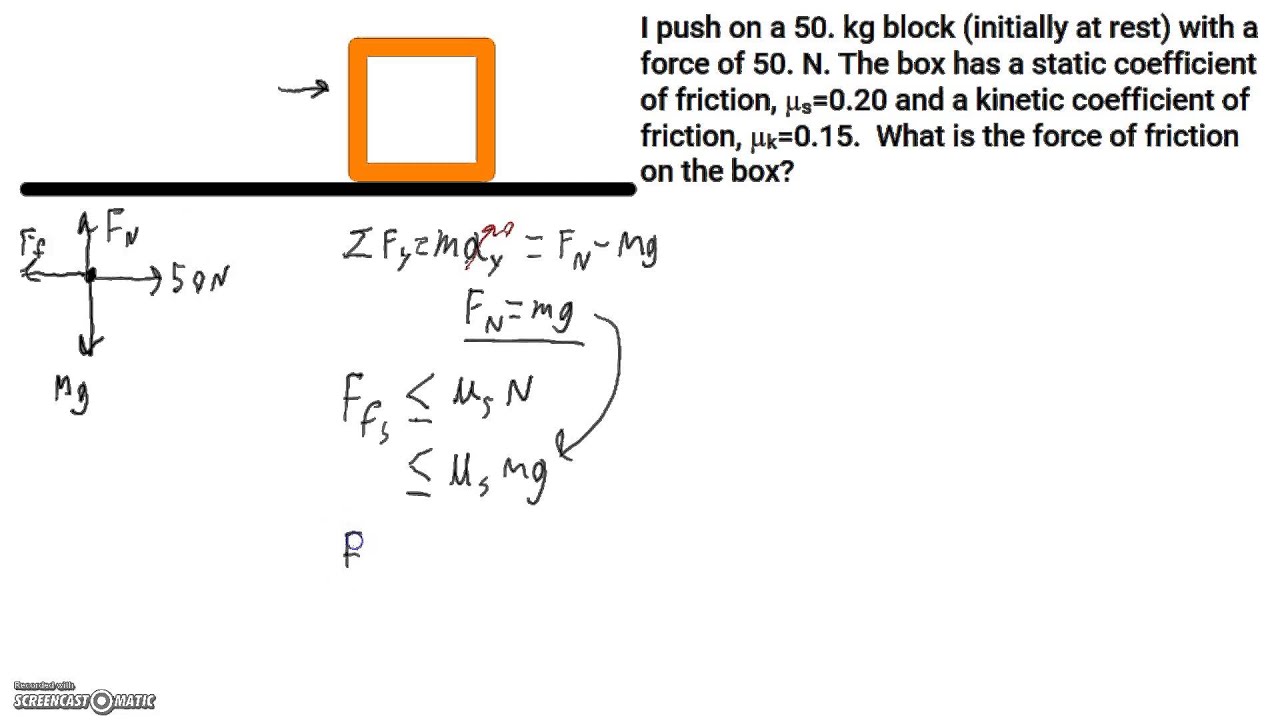
If you need a reference for coefficient values, the Engineering Toolbox and MatWeb are decent starting points, but they list typical ranges, not precise values. Always verify against your specific material pairing and surface condition if you can. A polished steel surface has a dramatically different coefficient than a rough cast iron surface, even though both are steel. The workflow I actually use is straightforward. Draw a free body diagram. Identify all forces. Resolve the normal force correctly. Select the appropriate coefficient for your conditions. Apply the friction formula. Check whether the assumed state static or kinetic is consistent with your results. If the required friction to maintain equilibrium exceeds the maximum static friction, motion occurs and you switch to kinetic. That consistency check is where most mistakes happen, so I do not skip it.