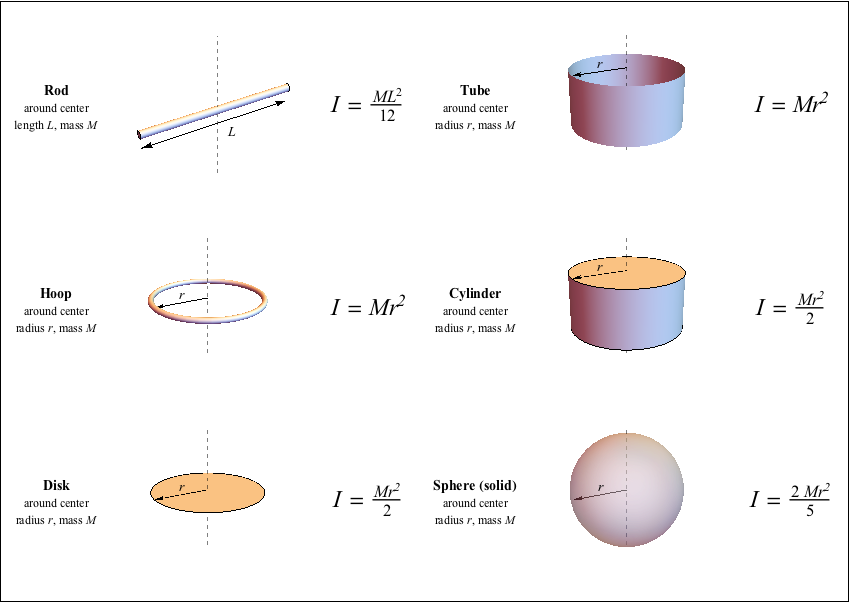
The Practical Guide to Getting It Right
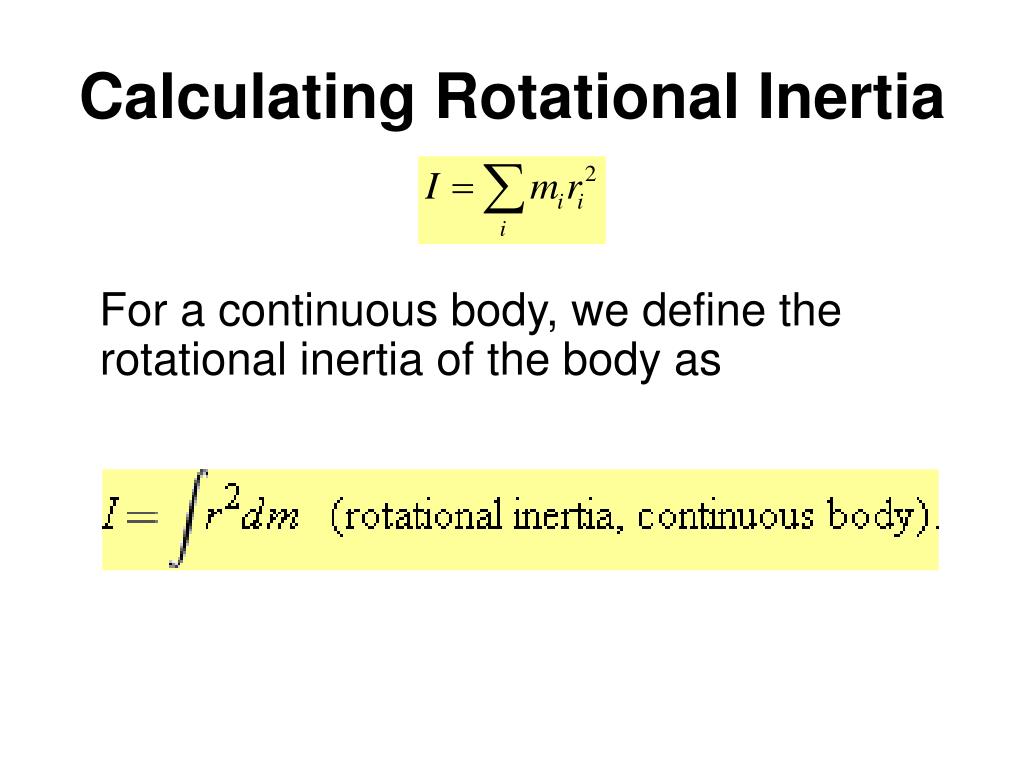
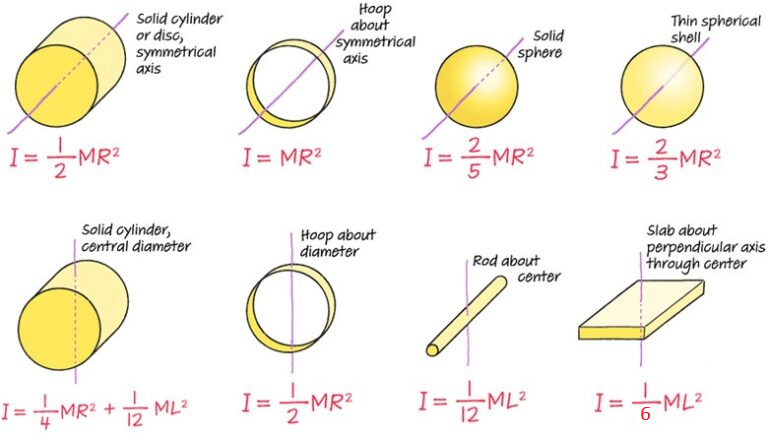
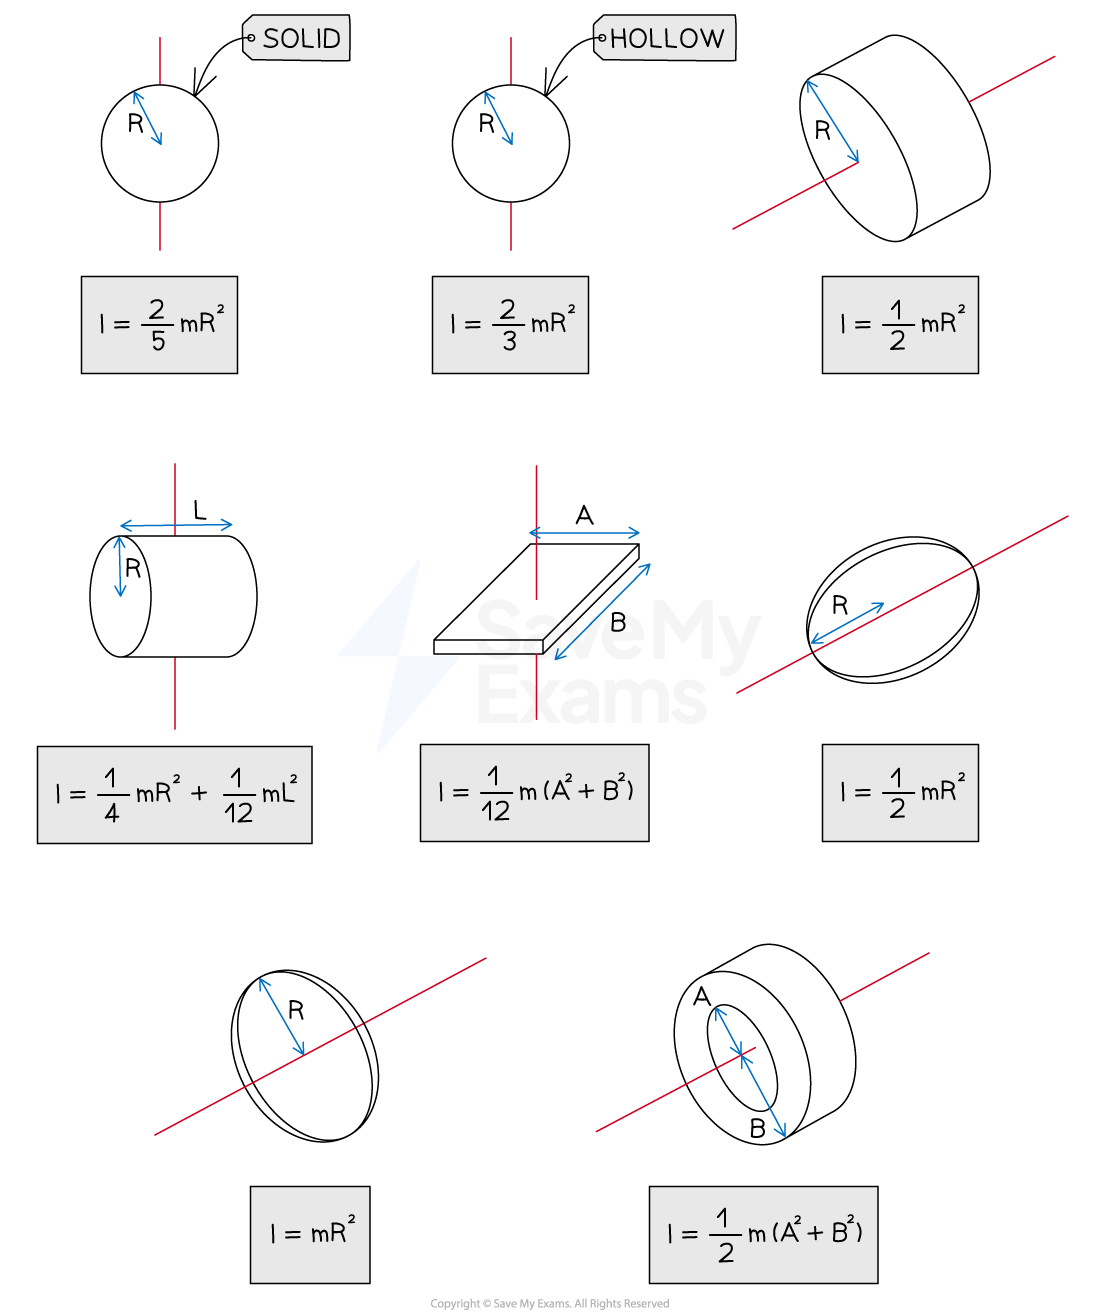
Most people approach rotational inertia wrong from the start. They memorize the table of shapes and hope their object matches one perfectly. That rarely works out. Real parts don't come in textbook geometries, and assuming they do will cost you time and bad data. The actual skill is knowing when to use each method and when to stop trying to calculate it by hand. Let's talk about the direct calculation method first since that's where everyone starts. You need three things: the mass of your object, the distance from your axis of rotation to every piece of that mass, and the right integral or formula for the shape. For a solid cylinder rotating about its central axis the formula is 1/2 MR squared. For a thin rod about its center it's 1/12 ML squared. These are useful but they're also the trap most people fall into. The hard part is identifying what your axis actually is. A flywheel doesn't always rotate about its geometric center in practice. Mounting brackets, offset shafts, and real-world constraints shift the axis. Once you've got the axis sorted, you're usually plugging numbers into software or a spreadsheet. I've seen engineers spend three hours deriving an integral for a weird bracket assembly only to realize they could have measured the thing in ten minutes with a physical pendulum setup.How To Calculate Rotational Inertia Without Guessing
Here is the workflow that actually works in a shop or lab setting. Step one is mapping the geometry. If your part is simple enough, you can decompose it into primitive shapes. A motor armature might be a cylinder plus a rectangular keyway cut out of it. You calculate each piece separately and then combine them. Step two is the parallel axis theorem. This is the thing most people skip or mess up. If you know the rotational inertia about the center of mass, I = I_cm + Md squared, where M is the total mass and d is the distance from the center of mass to your actual rotation axis. Get d wrong by even a millimeter on a heavy part and your answer drifts noticeably. I spent an afternoon last year trying to calculate the rotational inertia of a custom clutch disc. It looked like a simple plate with holes, right? Wrong. The bolts creating the holes weren't evenly distributed and the material wasn't uniform thickness across the face. The analytical approach gave me two different answers depending on whether I treated the holes as mass removed from a solid disk or as separate negative masses. Neither matched what the dynamometer was reading. I ended up using a trifilar suspension setup to measure it physically. The measured value was about 8 percent different from the analytical prediction. That 8 percent would have been the difference between a smooth engagement and a jerky one that wore out the bearings early.
When Calculation Fails
Not every object plays nice with math. Cast iron flywheels have density variations from the cooling process. Welded assemblies have heat-affected zones that change material properties locally. Add in manufacturing tolerances and you're building a theory on top of a lot of uncertainty. At some point you just measure it. The oscillation method is straightforward. Suspend your object from a wire and let it twist. Measure the period of oscillation and work backward. The formula connects the period to the rotational inertia directly. It takes about twenty minutes to set up and gives you a number with maybe 2 to 3 percent uncertainty if you're careful with timing. Another approach is the drop method. Hang a known mass from a string wrapped around a pulley attached to your object. Let it fall. The acceleration of the falling mass tells you the rotational inertia of whatever is resisting that rotation. This one works well for larger, heavier objects where the oscillation method would be impractical.
Pitfalls That Waste Time
Units are the quiet killer. Mixing kilograms and grams with meters and millimeters will silently corrupt your result. I've seen it in design reviews more times than I care to admit. Someone posts a rotational inertia value and nobody catches that the mass was entered in grams while the radius was in meters. The result is off by a factor of a thousand and the simulation looks plausible enough that it slides through. Another issue is treating rotational inertia as a fixed number. It isn't. If your object changes shape during operation, like a figure skater pulling in their arms or a deployable space structure, the rotational inertia changes with it. Even something as mundane as a telescoping robotic arm has a rotational inertia that varies along its stroke. Calculating it at one configuration and applying it everywhere is a common error in control system tuning. The moment of inertia tensor is the full picture. Most introductory courses stop at scalar rotational inertia for symmetric objects rotating about a principal axis. That works until your object is asymmetric or your axis isn't aligned with a symmetry direction. Then you need the tensor. A rectangular plate rotating about a diagonal axis doesn't behave the way you'd guess from the principal values alone. Cross terms matter. If you're doing anything beyond a basic physics problem, getting the tensor right is non-negotiable.
Get the Full Details

Practical Tools
CAD software handles this well now. SolidWorks, Fusion 360, and similar packages will compute the rotational inertia for any solid body you model. You assign a material density, define the axis, and it spits out the number. This is usually accurate to within the tolerance of your model. The catch is that the CAD model has to represent the real part faithfully. Missing fillets, wrong tolerances, or simplified bolt patterns will skew the result. I don't trust a CAD-only rotational inertia value for anything critical without cross-checking it against a physical measurement or at least a hand calculation on a simplified version of the part. For quick estimates in the field, there are mobile apps and online calculators. They're fine for ballpark figures and homework problems. They're not suitable for production design work where a 5 percent error in rotational inertia could mean an undersized motor or a vibration problem you'll chase for months.
What I'd Tell My Younger Self
Start by drawing the axis clearly on your diagram. I can't stress this enough. Ambiguity about the rotation axis is the root cause of most errors. Then pick your method based on what you actually know about the object. If you have a detailed CAD model, use that. If you have access to the physical part, measure it. If you have neither, decompose into primitives and apply the parallel axis theorem carefully. Don't default to calculation just because it feels more rigorous. A ten-minute physical measurement is more reliable than a three-hour analytical derivation on a poorly characterized object. Keep a log of your assumptions. Write down the axis location, the material density you used, how you handled cutouts and features, and the expected uncertainty. Six months later when someone asks why your simulation didn't match the test data, that log is the only thing that will help you figure out where things went wrong.