The Practical Side of Computing Velocity
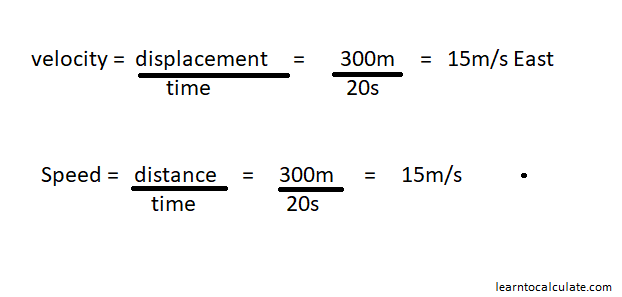
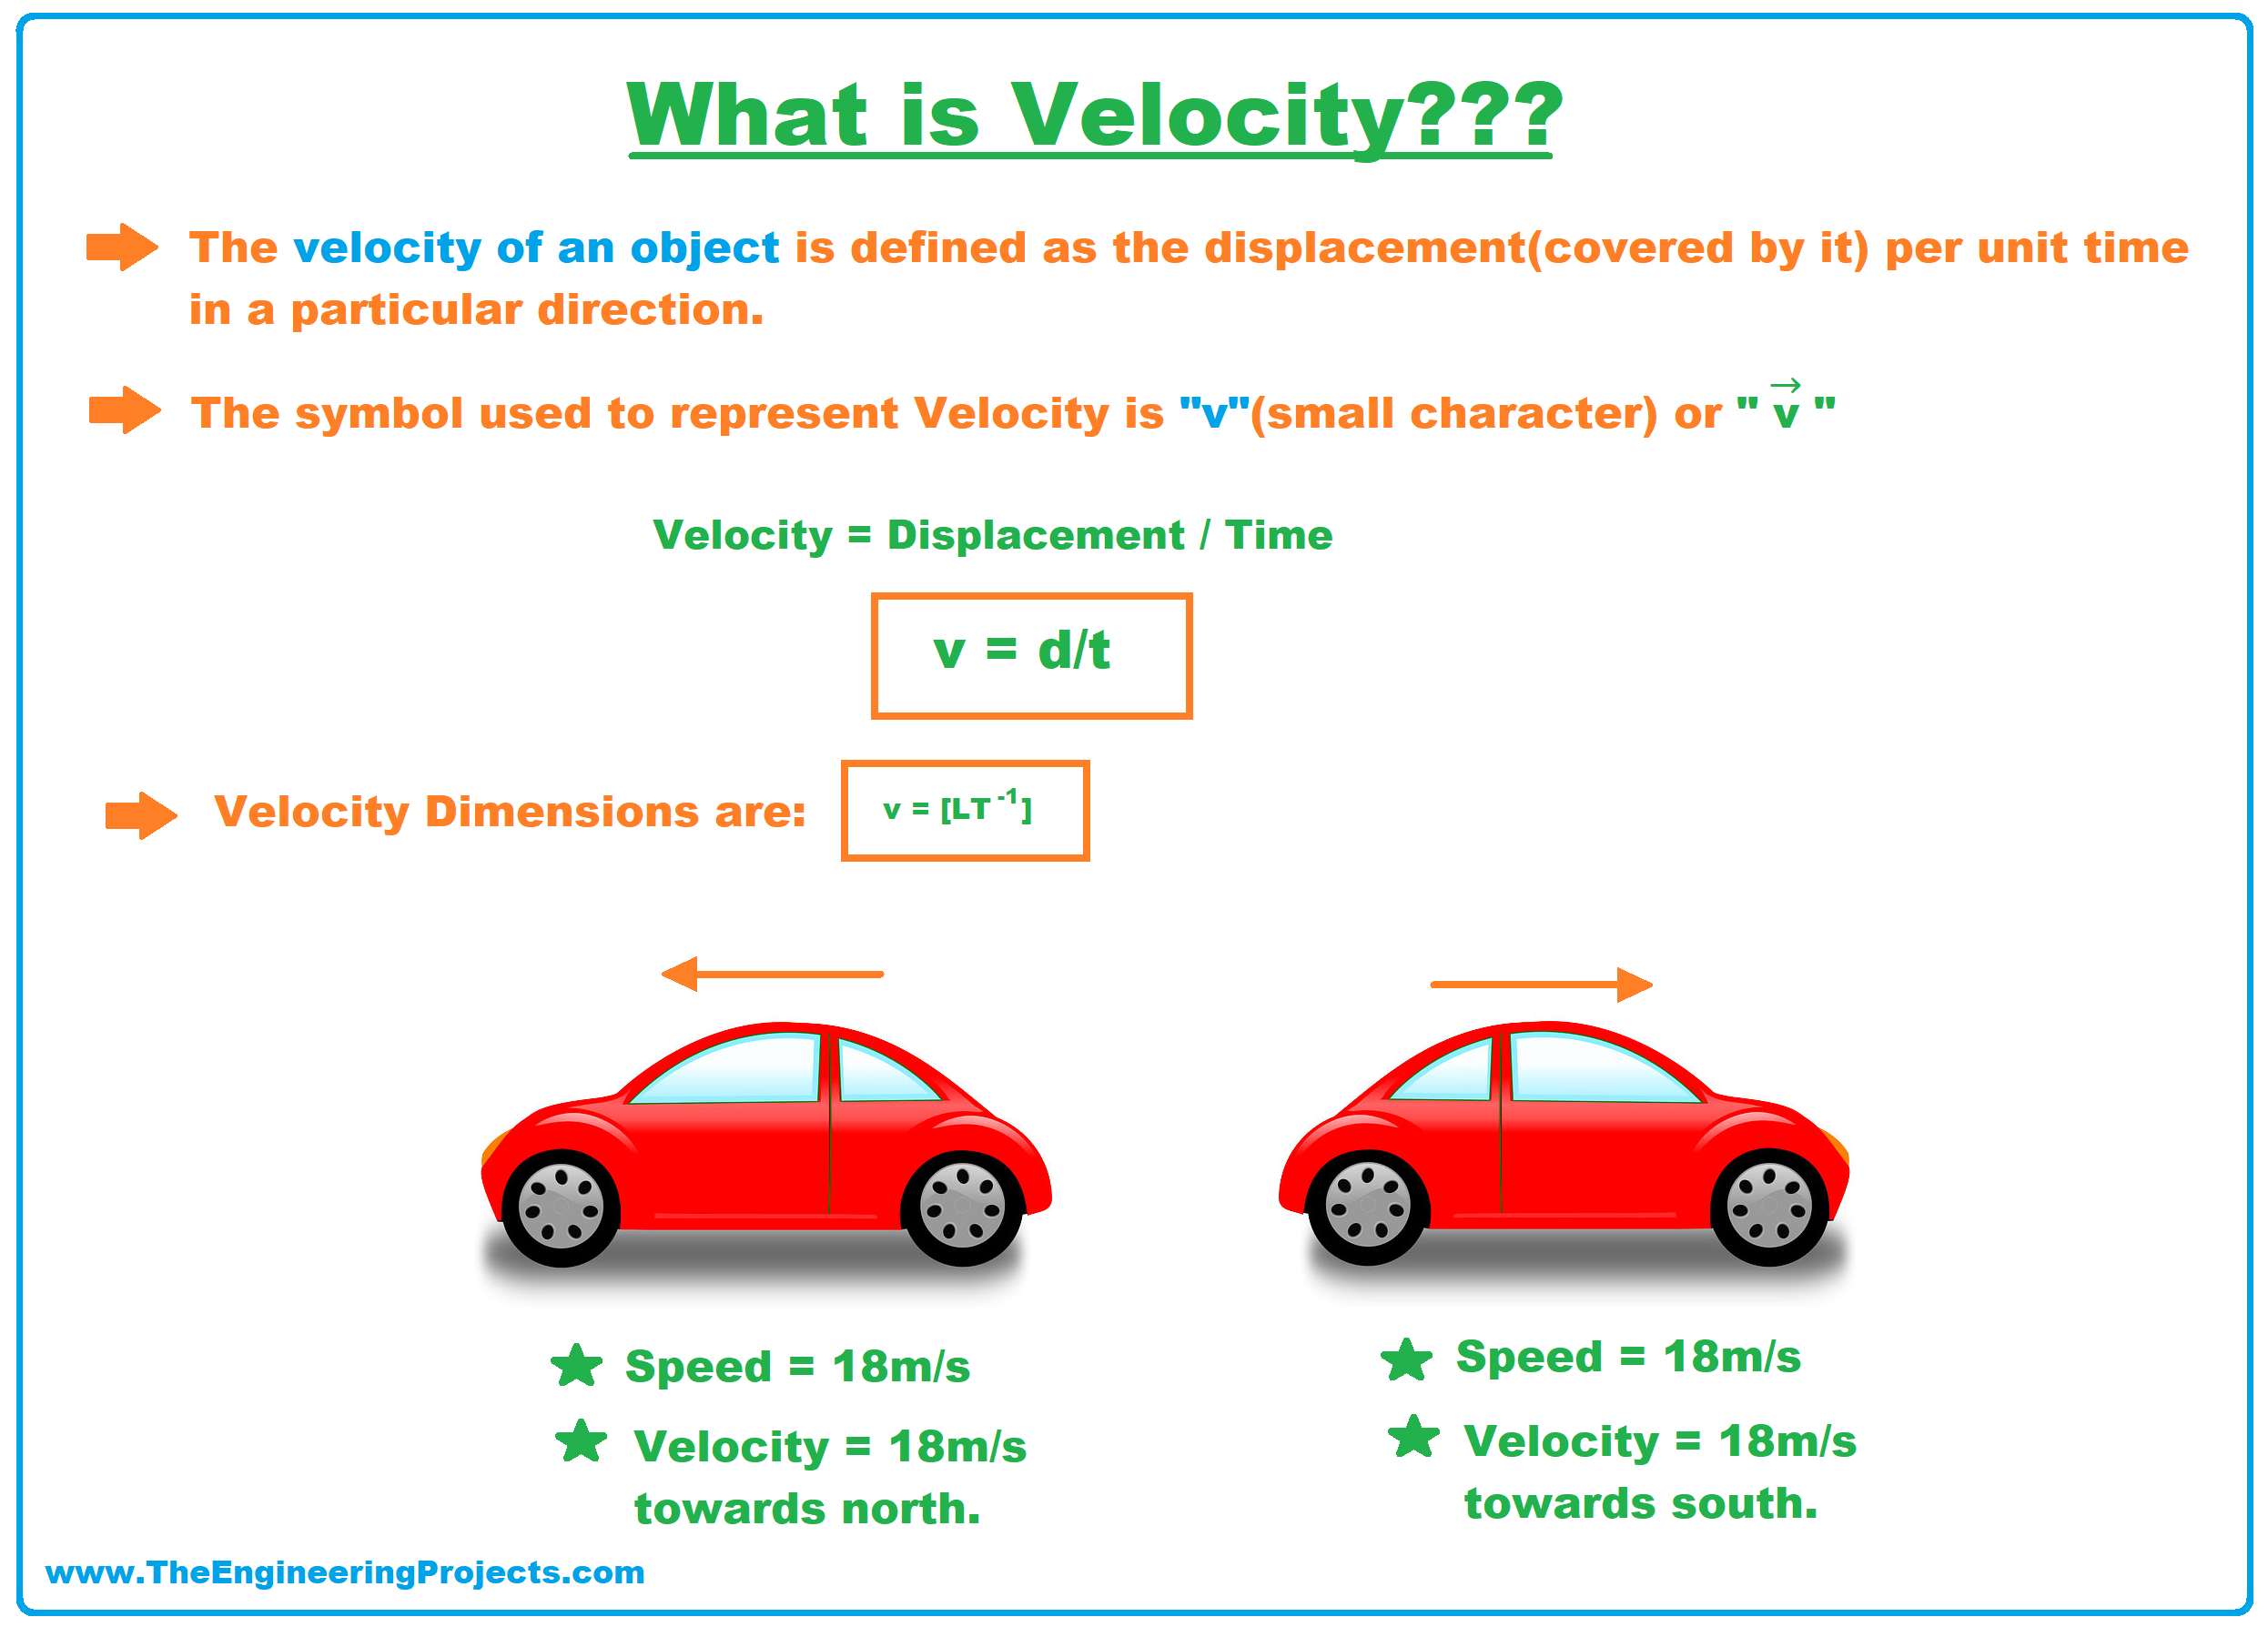
You need velocity for something specific — maybe debugging a physics simulation, optimizing a game engine, or calculating how fast a projectile hits a target in a CAD program. The textbook answer is straightforward, but the real world introduces edge cases that trip people up regularly. Velocity is displacement divided by time. Write that as v = x / t where x is the change in position and t is the change in time. That is the average velocity over an interval. If you need instantaneous velocity, you take the derivative: v(t) = dx/dt. Both are valid depending on whether your data comes as discrete samples or a continuous function. I worked on a trajectory prediction tool once where the sampling rate was 60 Hz and the object moved erratically between frames. Naively computing velocity as (x[n] - x[n-1]) / (t[n] - t[n-1]) produced violent spikes whenever the sensor had a bad reading. The fix was a simple exponential moving average with a window of about 5 samples, but the tuning required checking the noise spectrum first rather than guessing a window size.
Discrete vs Continuous Methods
When you have discrete position data, finite differences are your default. The forward difference v[n] = (x[n+1] - x[n]) / t is first-order accurate and introduces bias toward later times. The central difference v[n] = (x[n+1] - x[n-1]) / (2t) is second-order accurate and generally preferred when boundary conditions allow it. The tradeoff is that central differences lose accuracy at the endpoints of your dataset. If your position data is a fitted curve or analytic function, differentiating the fit is cleaner than differentiating the raw samples. A polynomial fit through noisy data can actually reduce noise while preserving the underlying velocity signal, but overfitting produces oscillatory derivatives that are worse than the original noise. I once spent two days debugging a system where a high-degree polynomial fit was generating velocity spikes that didn't exist in reality. Dropping to a cubic spline fixed it without any parameter tuning.
Vector Velocity in Multiple Dimensions
Velocity is a vector quantity. In two dimensions you compute vx = x/t and vy = y/t separately, then combine them if needed. The magnitude is |v| = sqrt(vx² + vy²). In three dimensions add vz the same way. Programs that treat velocity as scalar when it should be vector produce incorrect results for anything involving direction changes, which is most real-world problems. Angular velocity follows a similar logic but uses angle instead of distance. = /t with units of radians per second. Converting between linear and angular velocity requires the radius: v = r. This relationship breaks down if the radius changes during motion, which happens in orbital mechanics and certain robotics applications.
Get the Full Details

Common Pitfalls That Waste Time
Unit consistency is the most frequent source of errors. Mixing meters with kilometers, seconds with milliseconds, or degrees with radians produces velocity values that look plausible until you check the magnitude. Always normalize to SI units before computing, or track units explicitly through the calculation. Timestamp alignment matters more than people expect. If your position samples and time samples are not perfectly synchronized, the denominator t becomes unreliable. In practice this shows up as velocity drift even when position is correct. High-frequency data acquisition systems usually handle this internally, but when you are working with exported CSV files from different instruments, verifying timestamp alignment should be the first step. Neglecting reference frames is another silent error source. Velocity measured in a moving frame differs from velocity in a stationary frame. Relative velocity between two objects is v_rel = v - v when both are expressed in the same frame. If one is already in a different frame, you need to transform before subtracting. I spent a week tracking down a bug in a drone collision avoidance system that turned out to be an untransformed velocity vector from the ground frame being compared directly with an airframe-relative measurement.
When Velocity Computation Fails
At very low sampling rates relative to the signal frequency, numerical differentiation amplifies noise beyond usefulness. If your Nyquist frequency is close to your signal bandwidth, expect significant error. Increasing sampling rate helps, but sometimes the hardware limit is hard. In those cases smoothing before differentiation is necessary, and you lose some temporal resolution in the process. Non-differentiable motion, like impacts or step changes in position, produces undefined instantaneous velocity. The mathematical limit does not exist at those points. Numerical methods will return whatever the surrounding data allows, which is often meaningless. Detecting these discontinuities and handling them separately is usually the only practical approach. Relativistic velocities require the Lorentz factor = 1/sqrt(1 - v²/c²) and the classical formula becomes inaccurate above about 10 percent of light speed. For particle physics or satellite navigation corrections, this matters. For anything on Earth, ignore relativity.
Implementation Notes
For production code, consider using a library function rather than writing your own differentiator. NumPy's gradient function handles boundary conditions better than manual central differences. MATLAB's diff and gradient functions have similar advantages. Writing custom code is fine for learning, but library implementations usually account for edge cases you might miss. Memory layout affects performance when processing large datasets. Column-major versus row-major storage changes which elements are contiguous in memory, and that impacts cache performance significantly. For real-time velocity computation on embedded systems, this can be the difference between meeting a timing constraint and missing it entirely. Precision loss occurs when subtracting nearly equal numbers in finite-precision arithmetic. If position changes are small relative to absolute position values, catastrophic cancellation can dominate the error. Kahan summation or higher precision intermediates help, but the simplest solution is often to recenter your coordinate system around a recent reference point before computing differences.