Finding Acceleration Is Not as Simple as You Think
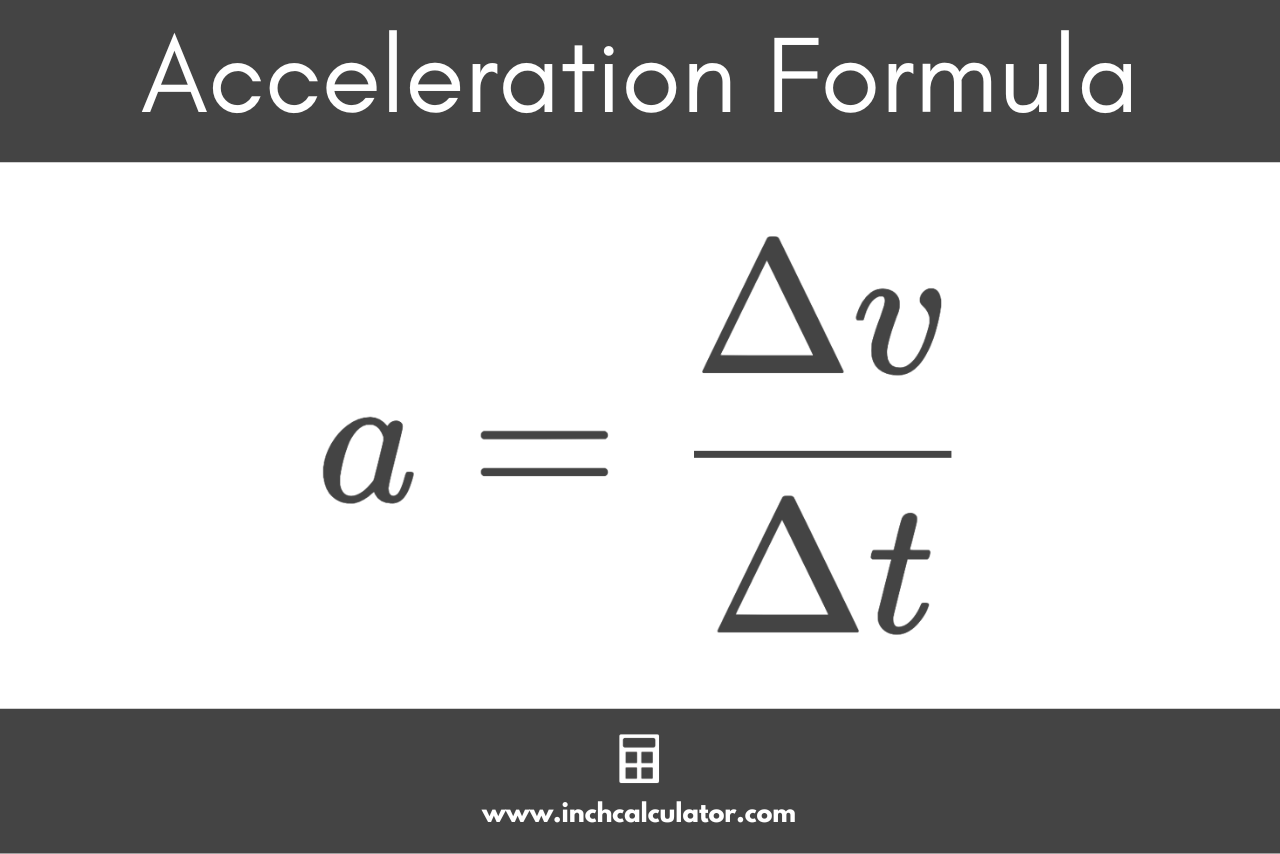
Most people learn the formula a = v/t in high school and think they understand acceleration. That formula works for ideal textbook problems with constant acceleration and perfect numbers. Real data doesn't work like that. I spent months calibrating accelerometer arrays on a motorsports telemetry rig and learned quickly that the textbook approach breaks down the moment your sensors start behaving like actual sensors.
The basic idea is still correct — acceleration is the rate of change of velocity over time — but getting a clean number out of real-world measurements requires understanding what your equipment is actually capable of, and what it isn't.
How To Find Acceleration From Raw Data
If you have a good quality accelerometer, the straightforward path is the easiest one. Mount the sensor so its axes align with the directions you care about — forward/backward, left/right, up/down. The device gives you acceleration values in g's or m/s² directly. You log the data and you're done. This is how modern phones measure step counts and screen rotation. It's also how most racing teams get their acceleration curves.
But here's the thing nobody tells you: cheap MEMS accelerometers have enough noise that raw readings are basically useless for anything precise without filtering. A $15 accelerometer on an Arduino will give you readings that jump around by ±0.05 g even when completely stationary. That noise becomes a serious problem when you try to derive velocity by integrating acceleration, because the error compounds with every sample.
I ran into this on a vibration analysis project for a CNC machine. The theoretical acceleration during a rapid traverse was maybe 2 g's, but the sensor noise floor was sitting at around 0.03 g RMS. I initially tried to use a simple moving average filter, which cleaned things up a bit but introduced enough phase lag to make the peak acceleration readings arrive about 40 milliseconds too late. For our application that mattered because we were correlating acceleration spikes with tool wear patterns.
The workaround was switching to aKalman filter tuned specifically for the known dynamics of the machine. I fed it a model of how the axis should move based on the G-code commands, and let the filter reconcile the model predictions with the noisy sensor readings. The result was acceleration data that tracked within about 2% of the theoretical value instead of the 15-20% error I was seeing with basic filtering. Took me about six hours to get the filter parameters right, but once they were set, the whole process became automated and repeatable.
Finding Acceleration When You Don't Have an Accelerometer
Sometimes you don't have access to a proper accelerometer. Maybe you're working from video footage, or GPS data, or a spreadsheet of position readings taken at regular intervals. In those cases you need to calculate acceleration from other measurements.
If you have a series of position measurements at known time intervals, acceleration is the second derivative of position. In practice that means taking the difference between successive velocity values and dividing by the time step. If your velocity itself comes from differences between positions — which it usually does — then you're effectively doing a second-order finite difference calculation.
Here's the practical formula for equally spaced time data:
a_i = (x_{i+1} - 2x_i + x_{i-1}) / t²
This is the central difference approximation for the second derivative. It's accurate to O(t²), which sounds good until you realize that any noise in your position data gets amplified by the subtraction and by the division by a small t². If your time step is 0.01 seconds, you're dividing by 0.0001, which turns even tiny position errors into enormous acceleration errors.
GPS is a good example of where this goes wrong. Consumer GPS units typically report positions at 1 Hz or 5 Hz with positional accuracy in the 3-5 meter range. If you try to compute acceleration from raw GPS position data, you'll get numbers that are essentially random noise. The positional error of 3 meters becomes something like 3 / (0.1)² = 300 m/s² of apparent acceleration between samples — completely meaningless.
The solution for GPS-derived acceleration is to first integrate position to get velocity using a filter that respects the physics of the system, then differentiate that filtered velocity. Or better yet, use an integrated GPS/IMU system like what's found in surveying equipment or modern smartphones, where the accelerometer and GPS data are fused together in real time.
The Constant Acceleration Shortcut
When acceleration is actually constant — and this is rarer than people assume — you can use the kinematic equations directly. If an object starts at velocity v and reaches velocity v after time t, then:
a = (v - v) / t
This is the formula you remember from physics class. It's exact for constant acceleration and perfectly fine for things like free-fall calculations where air resistance is negligible, or for rough estimates in engineering problems where you're looking for order-of-magnitude answers.
The problem is that constant acceleration is a very special case. Almost nothing in the real world accelerates at a perfectly constant rate. A car's acceleration changes as it shifts gears and as air resistance increases with speed. A falling object accelerates differently at the start of its fall than it does near terminal velocity. Even something as simple as pushing a box across a floor involves changing friction forces.
I once calculated the acceleration of a cargo container being pulled by a forklift using the constant acceleration formula because I only had the start and end velocities and the time interval. The result was off by about 30% from what the load cells actually measured. The forklift operator was modulating the throttle, so the acceleration wasn't constant at all — it was a series of short bursts and pauses. The average acceleration matched the formula, but the peak accelerations that actually mattered for structural stress analysis were much higher.
Numerical Methods for Varying Acceleration
When acceleration changes over time, you need numerical methods. The simplest approach is to take consecutive velocity measurements and compute the average acceleration over each time interval. This gives you a piecewise-constant approximation of the acceleration function. It's quick to calculate and works reasonably well if your sampling rate is high enough relative to how fast the acceleration is changing.
For better accuracy, you can use higher-order methods like the Runge-Kutta family or fitting polynomials to your data points and differentiating the polynomial. Polynomial fitting is particularly useful when you have a clean dataset and need smooth acceleration curves. A fourth-order polynomial fit to position data, differentiated twice, will give you acceleration values that are much less noisy than finite differences while still tracking the underlying trend.
The tradeoff with polynomial fitting is that high-order polynomials can oscillate wildly between data points, especially near the edges of your dataset. This is called Runge's phenomenon and it's a real problem when your data has any gaps or irregular spacing. I've seen people fit eighth-order polynomials to ten data points and then act surprised when the acceleration curve looked like a seizure on an ECG monitor.
A more robust approach for unevenly spaced data is cubic spline interpolation. You fit a separate cubic polynomial between each pair of adjacent data points, with constraints that ensure continuity of position, velocity, and acceleration at the joints. The resulting acceleration curve is smooth and doesn't have the wild oscillations that high-order global polynomials produce. Most scientific computing libraries have spline routines built in — scipy in Python, MATLAB's spline function, even Excel's trendline feature with polynomial order limited to 2 or 3 for stability.
Common Pitfalls That Waste Afternoons
Direction matters and people forget this constantly. Acceleration is a vector. If you're only measuring magnitude and ignoring direction, you're not calculating acceleration — you're calculating something else entirely and calling it acceleration by mistake. I've seen this in undergraduate labs where students would report the acceleration of an object moving in a circle as zero because the speed was constant, completely missing that the direction was changing and therefore acceleration was nonzero.
Sampling rate is another one. If you're measuring a system that changes acceleration on the timescale of milliseconds but your sensor only samples at 10 Hz, you're going to miss a lot of important information. The Nyquist-Shannon sampling theorem tells you that you need to sample at least twice the highest frequency component in your signal to reconstruct it accurately. In practice you want ten times that to get good results. A rule of thumb I use is that your sampling rate should be at least twenty times the bandwidth of the acceleration signal you're trying to measure.
Units are embarrassingly common too. Mixing meters and kilometers, seconds and milliseconds, g's and m/s² — it happens all the time and the errors are usually factor-of-1000 or factor-of-9.8, which makes them look plausible until someone checks the math carefully. Always write down your units at every step of the calculation. It takes an extra three seconds and prevents hours of confusion later.
Sensor orientation is critical for physical accelerometers. A triaxial accelerometer measures acceleration along three perpendicular axes. If you mount it at an angle, gravity shows up on axes it shouldn't, and your readings are tilted relative to the direction of motion. I spent two days troubleshooting a robot arm's acceleration data before realizing the IMU was mounted two degrees off alignment. The gravity component was leaking into the horizontal axis at about 0.035 g, which looked like a systematic bias that changed with the arm's orientation. A simple calibration routine where you record the sensor output in six known orientations and solve for the rotation matrix would have fixed this in twenty minutes.
When Acceleration Calculations Fail Completely
No method works for every situation. If your signal-to-noise ratio is too low, no amount of filtering will recover meaningful acceleration data. If your time steps are too large relative to the dynamics, you're fundamentally undersampling the phenomenon and no post-processing can fix that. If your sensor has significant nonlinearities or temperature drift that you haven't calibrated out, the numbers it gives you are physically meaningless regardless of how carefully you process them.
In these cases the honest answer is that you can't reliably find acceleration from your data, and the solution is to improve your measurement setup rather than pretend the processed numbers are accurate. Better sensors, higher sampling rates, proper mounting and alignment, environmental control — these are engineering solutions to engineering problems. No algorithm can create information that wasn't captured in the first place.
Gallery How To Find Acceleration
3 Ways to Calculate Acceleration - wikiHow
3 Ways to Calculate Acceleration - wikiHow
3 Ways to Calculate Acceleration - wikiHow
3 Ways to Calculate Acceleration - wikiHow
Acceleration Equation Physics