How to Actually Handle Integrals with Inverse Trig Functions
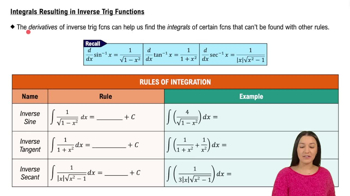
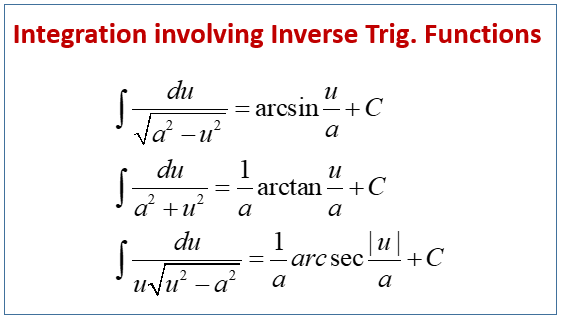
When you see an integral involving inverse trigonometric functions like arcsin, arccos, or arctan, most people just memorize a sheet of formulas and hope for the best. That approach fails quickly when the problem doesn't look exactly like the textbook version. I still encounter this regularly in engineering work. The core integrals you need are straightforward enough: the integral of 1/(1 + x²) is arctan(x) + C, the integral of 1/(1 x²) is arcsin(x) + C, and the integral of 1/(1 x²) is arccos(x) + C. But those only apply when the expression matches perfectly. Once you introduce coefficients, shifts, or composite arguments, you have to adapt.
Working Through Integral Calculus Inverse Trigonometric Functions in Practice
Integration by parts is your primary tool when the integrand contains a product of an inverse trig function and another expression. I usually set u equal to the inverse trig function because differentiating it simplifies immediately into an algebraic form, and dv as the remaining part of the integrand. This flips the problem into something more manageable. For example, if I'm integrating x · arcsin(x), I let u = arcsin(x) and dv = x dx. The derivative of arcsin(x) is 1/(1 x²), which converts the integral into a rational expression under a square root. Then I use substitution or another integration technique on what's left. The key insight most people miss is that choosing u based on whether differentiation simplifies the term matters more than alphabetical order. I've seen students pick the polynomial as u out of habit, which makes the problem harder instead of easier. Substitution is equally important. When you have something like dx/(4 + 9x²), the standard arctan formula doesn't apply directly. Factor out the 4 to get (1/4)dx/(1 + (9/4)x²), then substitute u = (3/2)x. The result becomes (2/3)arctan(3x/2) + C after adjusting for the differential. I've spent years watching people skip the factoring step and end up with wrong coefficients. It's a small detail but it ruins everything downstream.
Edge Cases and Where This Method Breaks Down
Not every inverse trig integral is friendly. Consider arcsin(x)/x dx. This has no closed-form solution in terms of elementary functions. You either express it as an infinite series or accept that it must be evaluated numerically. I hit this exact problem once while working on a signal processing project where someone needed the definite integral from 0.1 to 0.9 for a normalization constant. A series expansion worked fine for that narrow range, converging after about twelve terms. For wider ranges, numerical quadrature is your only realistic option. Another common trap involves domain restrictions. The formula dx/(a² x²) = arcsin(x/a) + C only holds when |x|
|a|. If your variable exceeds that bound within the integration interval, the integrand becomes complex or undefined. I've seen this blow up finite element simulations because nobody checked the bounds before running the routine. Always verify the domain before applying the formula. Inverse hyperbolic functions sometimes appear disguised as inverse trig forms, especially when the discriminant under a square root goes negative. Converting between them can save you from hitting a wall. For instance, dx/(x² 1) gives you a result involving ln((x1)/(x+1)), which is essentially related to arctanh for |x|
1. Recognizing these equivalences cuts down unnecessary computation.
Get the Full Details
Quick Reference for Common Forms
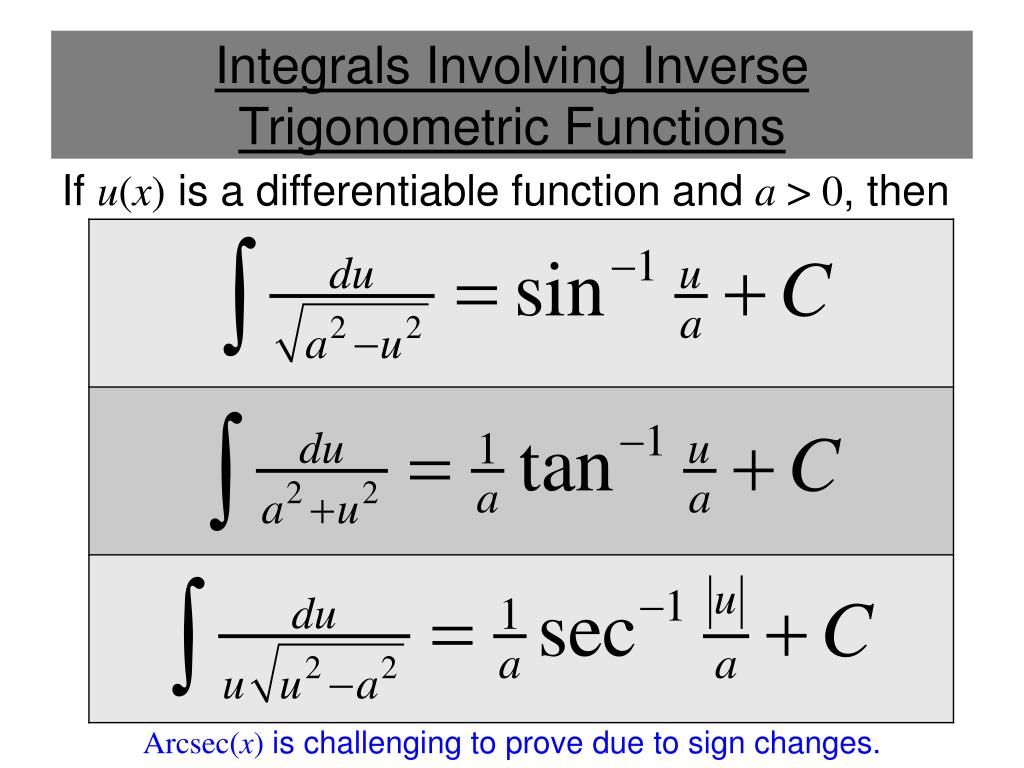
Here are the forms I actually use in practice, not the full exhaustive list from a textbook: Memorizing all five is overkill. The first three are standard forms you should recognize instantly. The last two come from integration by parts and show up often enough to be worth knowing by heart. When the integral resists all standard techniques, a trigonometric substitution often helps. If you have (a² x²), try x = a·sin(). If you have (x² + a²), try x = a·tan(). If you have (x² a²), try x = a·sec(). These are not suggestions. They work every time the form matches, and they convert the square root into a single trig function that simplifies cleanly. I used this exact approach last month on an integral involving (9x² 16) over a limits interval of [4/3, 4], and the secant substitution reduced it to a basic cosine integral in about four steps.
The main limitation of relying on these techniques is that they require the integrand to have a specific structure. Random polynomials multiplied by inverse trig functions won't cooperate. In those cases, numerical integration software is the practical answer, even if it feels less satisfying than finding an analytic solution.