Why This Keeps Coming Up
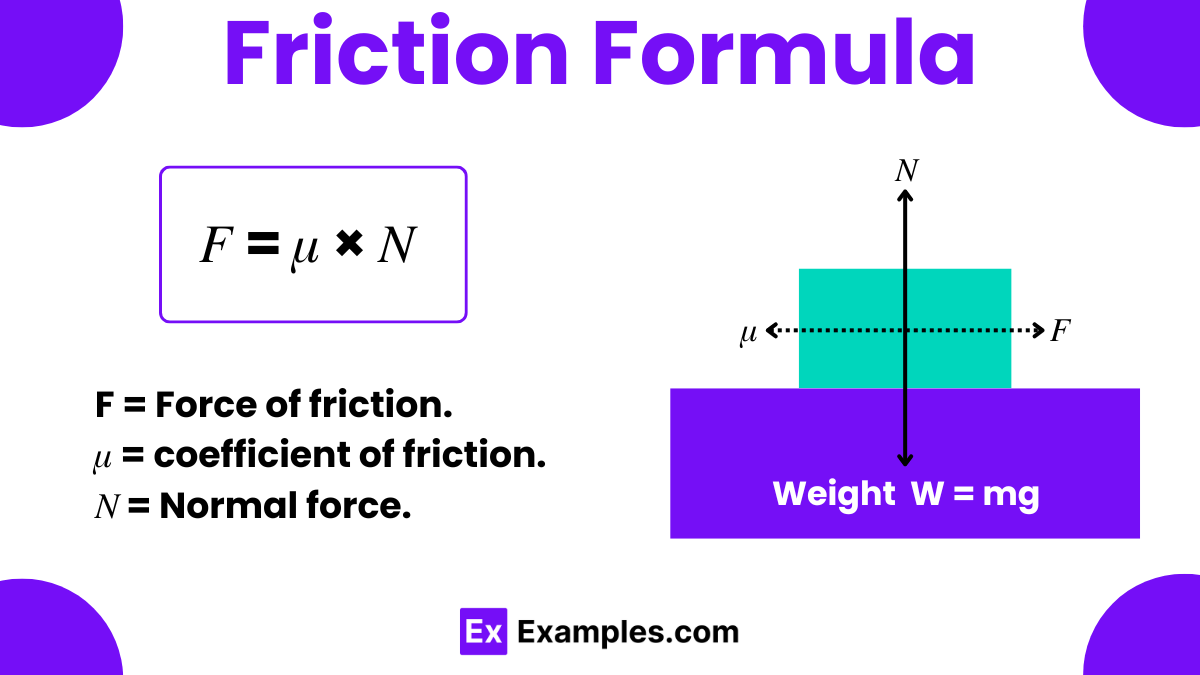
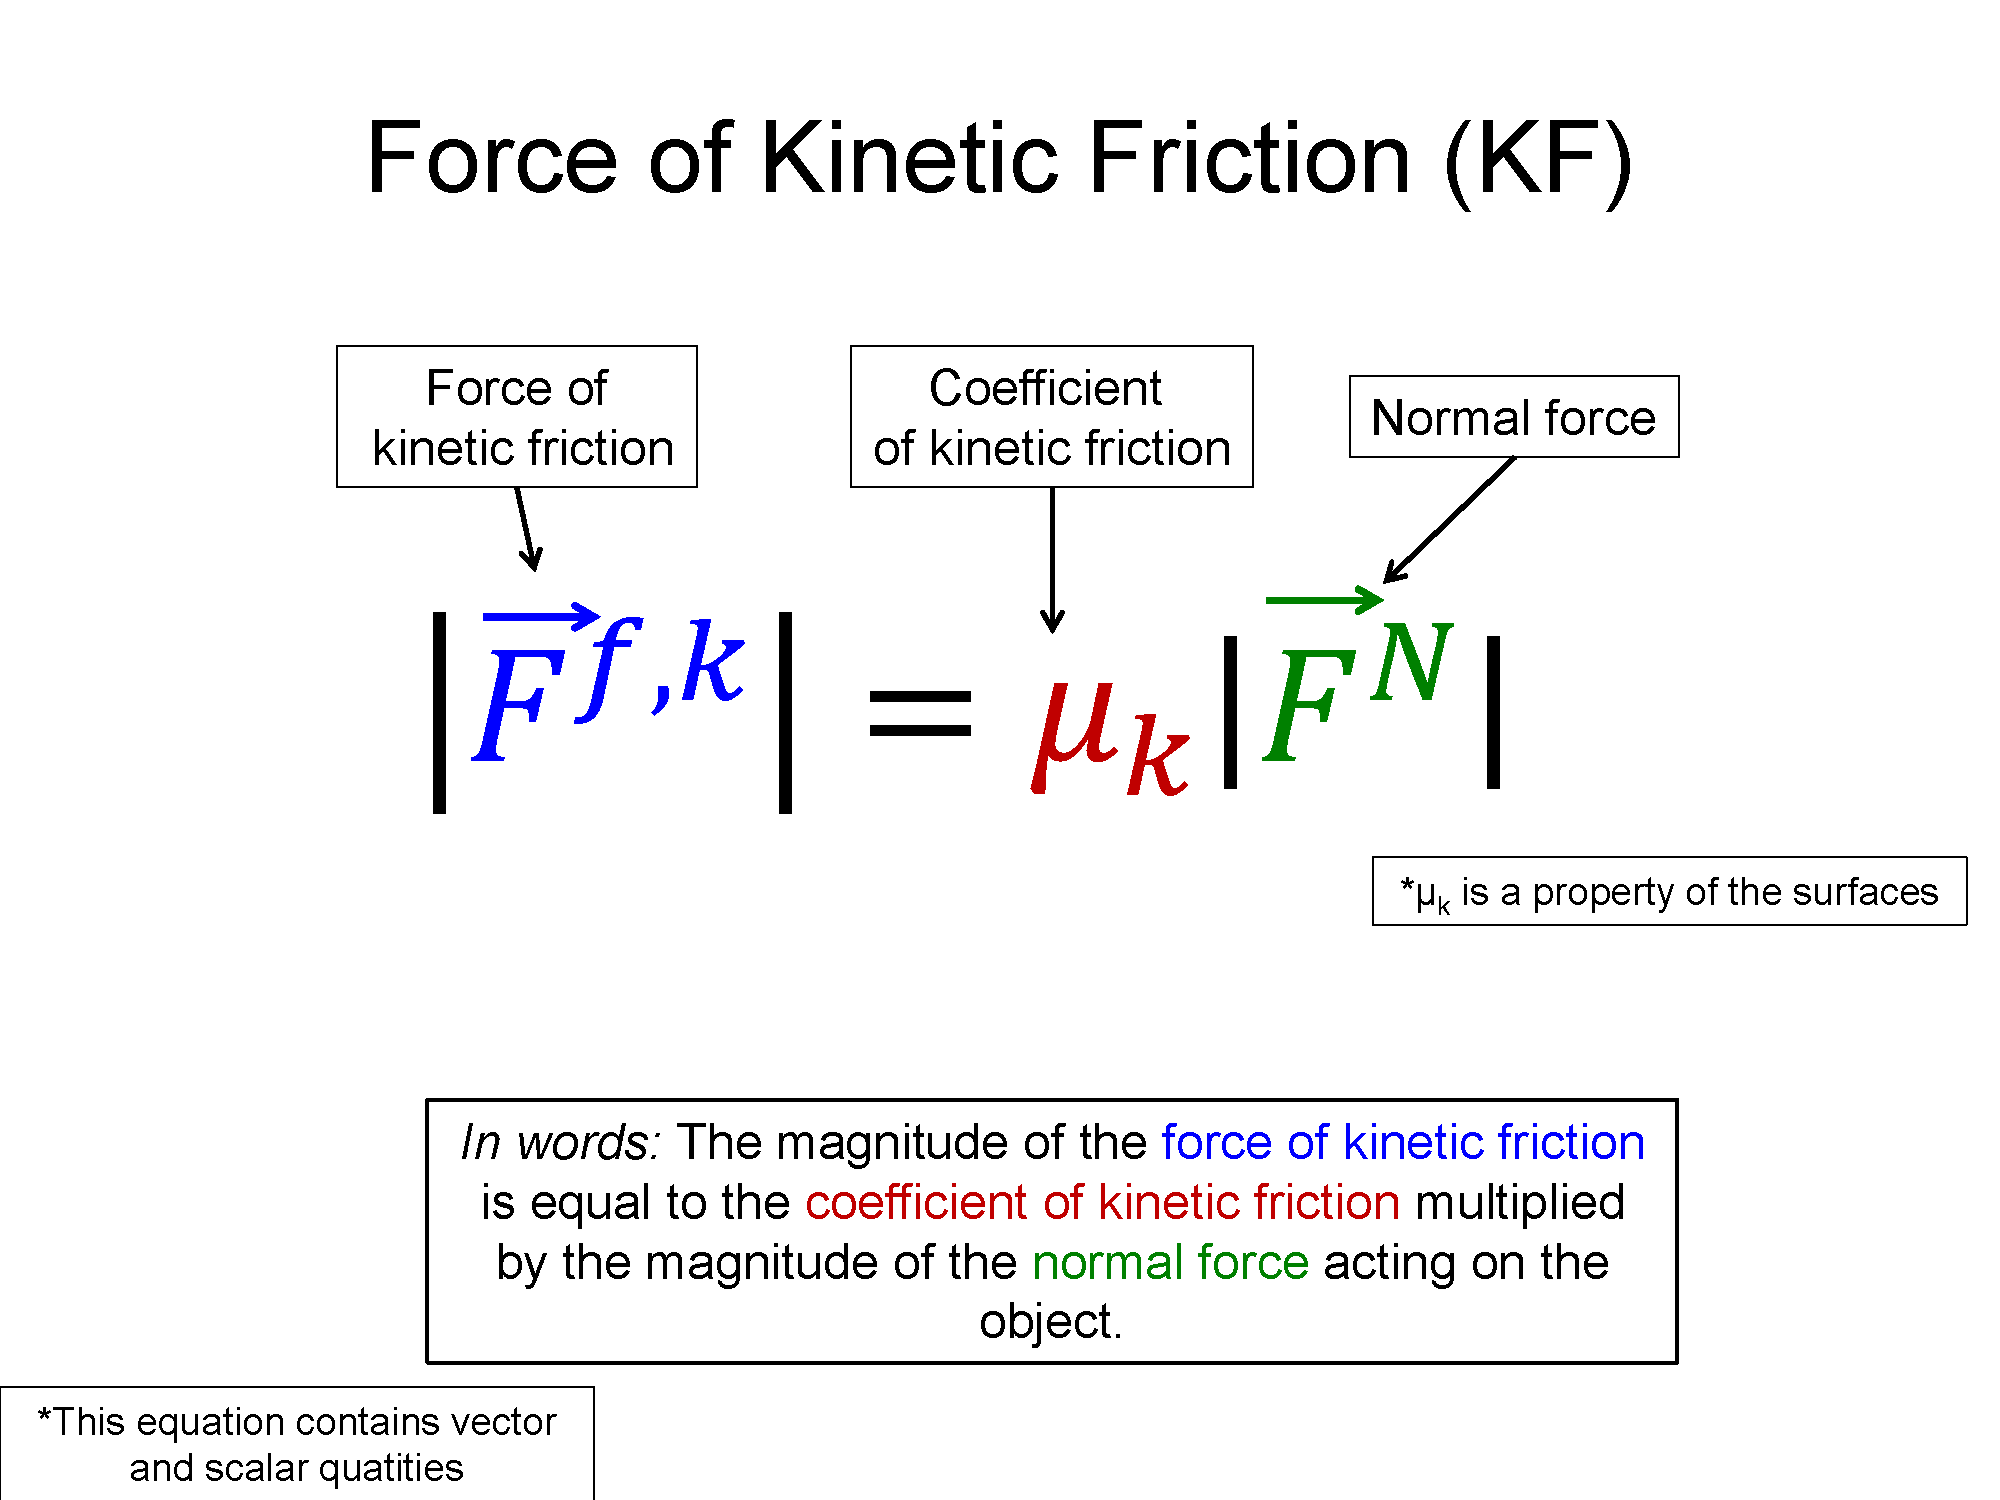
I keep seeing people mess this up in simulation projects and physics lab reports. Not because the math is hard—because the assumptions are buried under the surface. The kinetic friction force equation itself is just one line, but getting it right in practice takes some actual thought about what the variables mean when your real system is moving. It goes like this: f_k = _k × N. The kinetic friction force equals the coefficient of kinetic friction multiplied by the normal force. That's it. But "normal force" is where most people trip up. The equation assumes you're working on a flat horizontal surface where the normal force simply equals mg. Under those conditions, you plug in the mass, multiply by 9.81, multiply by the coefficient, and you're done. Easy enough. But here's what nobody tells you upfront—the coefficient _k is not a material property. It's a system property. It changes with speed, surface temperature, contamination, and how long the surfaces have been in contact. The table value you find in a textbook was measured under specific lab conditions that probably don't match your setup.
I ran into this on a conveyor belt project last year. We were calculating the power needed to keep a steel pallet moving at constant velocity across an aluminum guide rail. The handbook listed _k for steel on aluminum as 0.41. I calculated the motor torque based on that, built the system, and the pallet would occasionally stall at certain positions along the rail. That should have been a red flag right there—if friction were truly constant, it would move uniformly. It didn't. The workaround was brutal but straightforward. I ran a drag test by pulling the pallet across the rail with a spring scale at different speeds and at different points along the rail's length. The coefficient varied from about 0.35 to 0.58 depending on position. The rail had slight machining marks from the extrusion process that created directional variation in surface roughness. We ended up using 0.58 as our design margin and oversizing the motor by about 20 percent over the nominal calculation. The project went fine after that, but it cost us three weeks of testing we didn't budget for.
Working Through a Real Example
Let's say you have a 12-kilogram block sliding across a wooden workbench. The coefficient of kinetic friction between the block's bottom surface and the wood is approximately 0.35. The normal force is simply 12 times 9.81, which gives you 117.72 newtons. Multiply that by 0.35 and you get a kinetic friction force of about 41.2 newtons opposing the motion. If you need to keep the block moving at a constant velocity, your applied force must equal 41.2 newtons. Any more and it accelerates. Any less and it slows down. This is Newton's first law doing the heavy lifting, not the friction equation itself. The friction equation just tells you one side of the force balance. Now complicate it. Put that same block on a ramp inclined at 20 degrees. The normal force is no longer mg. It's mg times the cosine of the angle. So 12 times 9.81 times cos(20°) equals roughly 110.56 newtons. The friction force becomes 0.35 times 110.56, which is about 38.7 newtons. But now there's also a component of gravity pulling the block down the slope equal to mg times sin(20°), or about 40.1 newtons. The net force down the ramp is 40.1 minus 38.7, which is 1.4 newtons. The block accelerates slowly downhill. That's the part most introductory treatments gloss over—they give you the friction number and stop there instead of putting it back into the full free-body diagram.
Get the Full Details

Where the Equation Breaks Down
At very low velocities, kinetic friction becomes unpredictable. Some materials actually exhibit stick-slip behavior where the transition from static to kinetic friction isn't smooth. If you're designing something that needs consistent motion at low speed—like a precision positioning stage—relying on the simple _k × N model will give you chatter and jerking. The Coulomb friction model underneath this equation was never meant for that regime. People use Stribeck curves or more complex velocity-dependent friction models when they need accuracy there. The basic equation just doesn't apply. Another failure mode is when the normal force changes dynamically. In a rotating system like a clutch or a brake, the normal force is generated by a spring or hydraulic actuator and can fluctuate. If you're estimating friction torque in a clutch and you assume a static normal force when the actuator pressure is actually cycling, your friction prediction will be wrong. I've seen this in HVAC actuator designs where the friction drag was miscalculated because someone used the static spring preload instead of accounting for pressure transients during valve closure. The valve would slam shut instead of closing smoothly, and the root cause was a friction calculation that didn't match the real operating conditions. If you're working with lubricated contacts, the equation gives you a number but that number is essentially meaningless without context. A hydrodynamic lubrication regime changes the physics entirely—you're no longer dealing with dry friction at all. The _k value you'd look up in a handbook assumes boundary or mixed lubrication. If your bearing is running in full film, the effective friction coefficient could be two orders of magnitude lower than the table value. I've seen engineers waste days troubleshooting bearing overheating only to realize the friction model they used was completely wrong for the operating regime. The fix was running an S-N curve analysis to confirm the lubrication regime before selecting materials and clearances.
Practical Steps for Using It Right
First, draw a proper free-body diagram before you plug anything into the equation. Most mistakes happen because people confuse the normal force with the weight force. They're only the same when the surface is flat and horizontal and there are no other vertical forces acting. If there's an applied force at an angle, a downward push, an upward lift, or an incline, the normal force changes and you need to calculate it from the force balance, not assume it equals mg. Second, verify your coefficient value comes from a source that matches your actual materials and surface finish. Surface roughness, coatings, and even the direction of grinding marks can shift _k by 20 to 40 percent. If precision matters, measure it yourself with a drag test rather than trusting a handbook value. The time investment is small compared to catching the error later. Third, remember that _k is almost always lower than _s. If your problem involves starting motion from rest, you need the static coefficient, not the kinetic one. Applying the kinetic equation to a start-up scenario will underpredict the required force. The difference is usually between 10 and 30 percent depending on the material pair, but that gap matters when you're sizing a motor or a spring.
When I'm working through these problems in a rush, I usually set up a quick spreadsheet where I can toggle the normal force calculation and see how friction changes with angle, applied loads, and coefficient variations. It takes maybe ten minutes to build and saves you from reworking a design later. Most of the errors I see in practice come from people treating this as a one-step calculation instead of a force-balance problem.