Working Through Laplace Transforms Without Losing Your Mind
I spent way too many nights grading engineering homework where students would blindly apply the transform tables without checking whether their function actually met the conditions for convergence. It happens all the time. The basic idea is straightforward enough — you take a time-domain function and map it into the s-domain, where differential equations stop being differential and just become algebra. But getting good at it requires doing actual problems, not reading about them. The definition itself is just an integral: F(s) equals the integral from zero to infinity of f(t) times e to the negative st dt. Most textbooks present it that way, then immediately hand you a table of pre-computed results and tell you to memorize them. The table covers roughly twenty common transforms. Once your problem lands outside that set, you are on your own and need to go back to first principles.
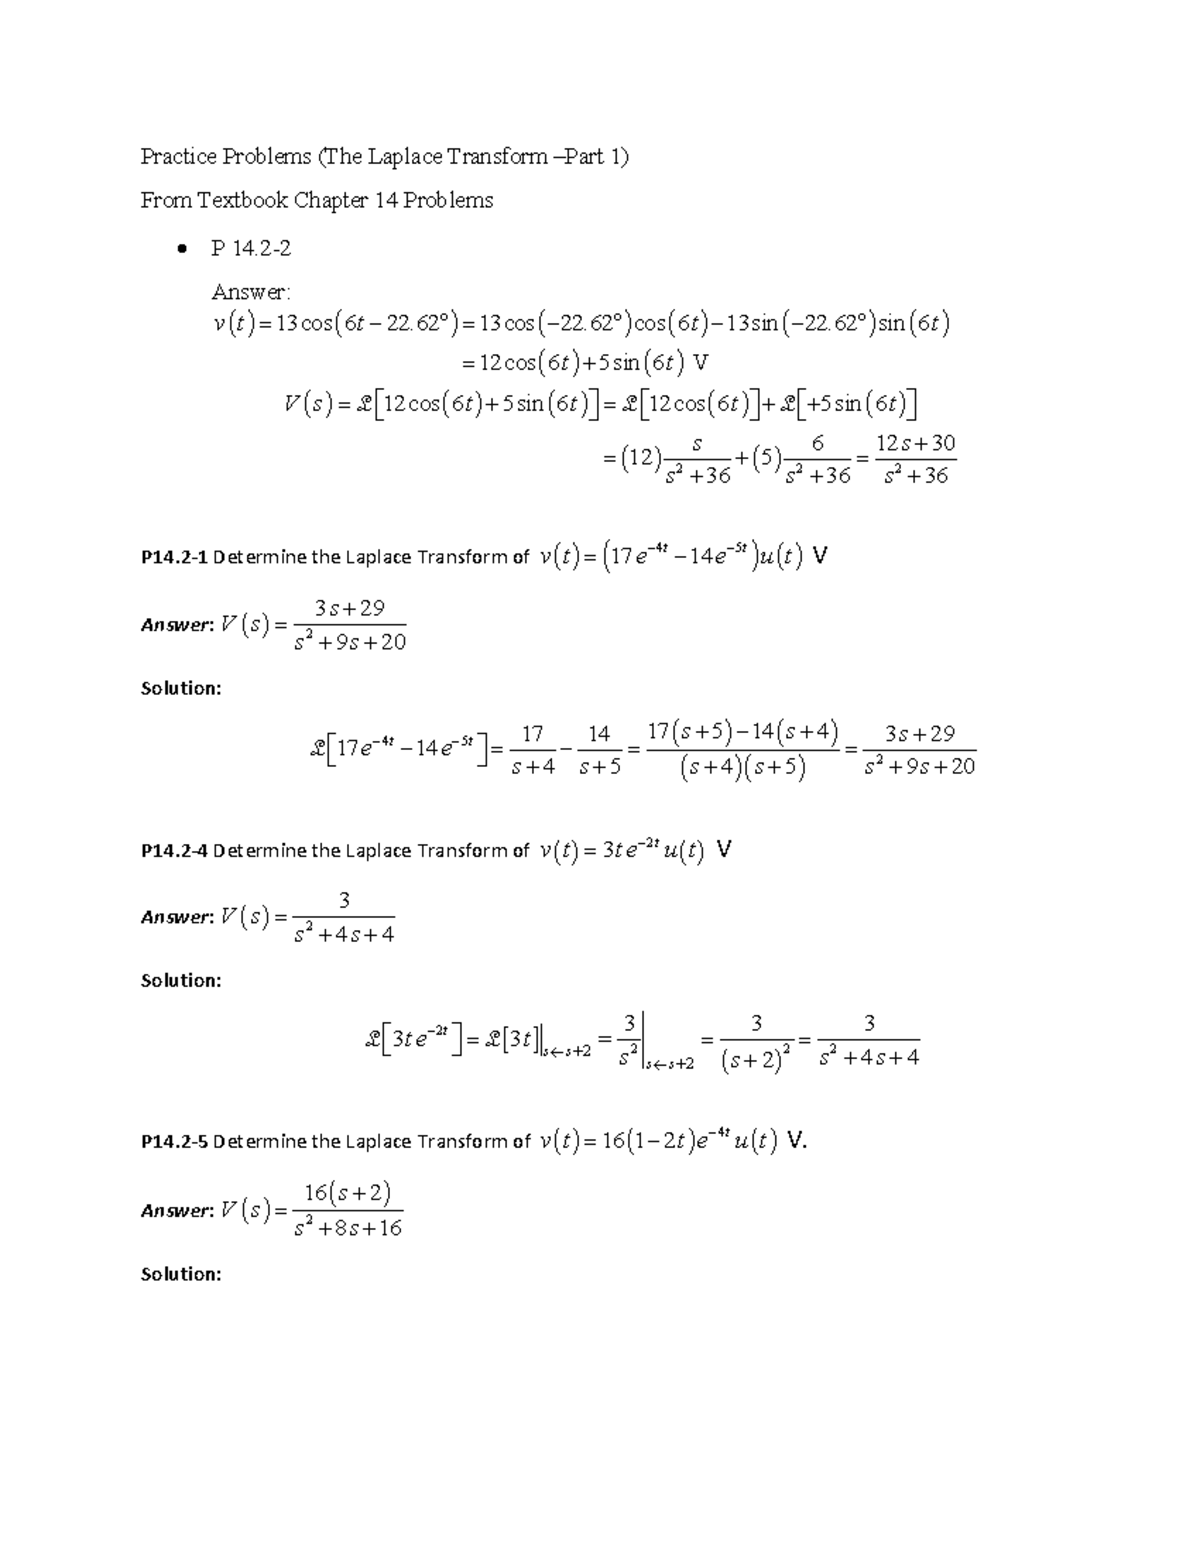
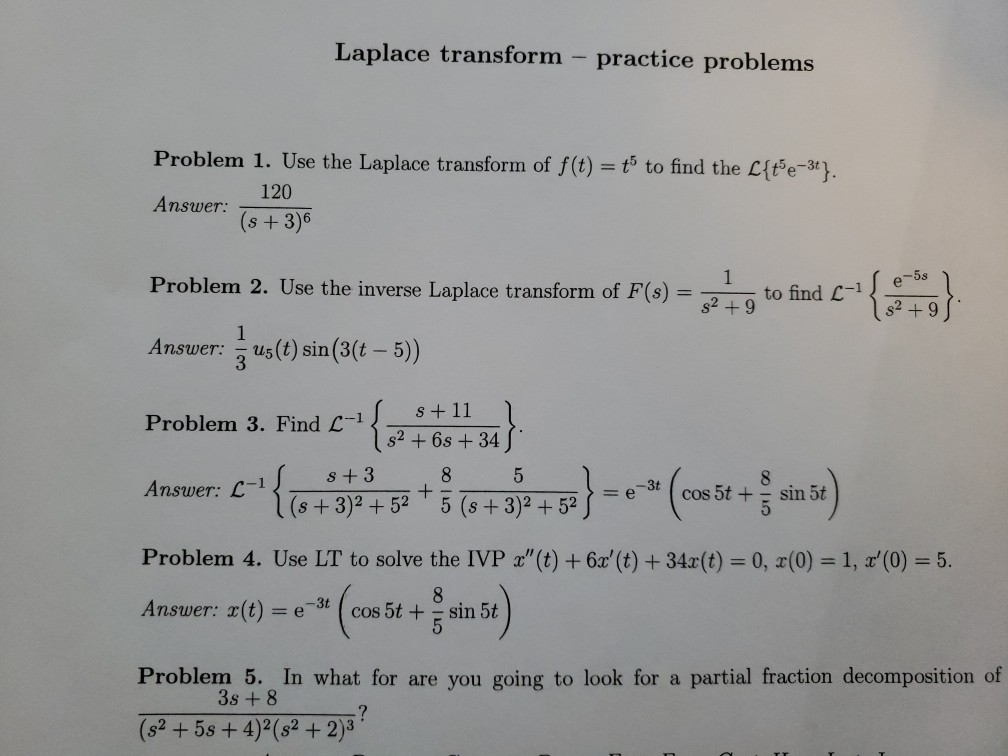
Laplace Transform Practice Problems
Here is the most practical approach I have found over years of working with this material. Start with first-order systems because they teach you the mechanics without drowning you in complexity. Take a simple RC circuit where you are solving for the voltage across the capacitor with a step input. You write the differential equation, apply the transform to every term, solve for V of s using algebra, then perform the inverse transform to get back to the time domain. That process usually takes me about ten minutes when I am doing it fresh and familiar. The trick that most people miss is that the initial conditions matter enormously and most students ignore them until they are stuck. When you transform a derivative, you get s times F of s minus the initial value. If you forget that minus the initial value part, your entire answer shifts and nothing else will save it. I have seen this error recur in virtually every cohort I have worked with, and it is almost always a careless omission rather than a conceptual gap. For second-order systems, partial fraction decomposition becomes the real bottleneck. You will be factoring a quadratic denominator and matching coefficients, and the algebra can spiral quickly if you are not careful. I usually recommend the cover-up method for simple distinct poles because it is faster and less error-prone than solving a system of equations. It only works when all poles are real and non-repeated, so you need to know when to fall back on the standard method.
One specific problem I ran into recently involved a function with a piecewise definition that included a ramp starting at t equals two seconds. The straightforward approach is to express everything using unit step functions, which means rewriting the ramp in terms of u of t minus two and then applying the time-shifting property. I initially made a mistake by forgetting that the ramp function itself needs to be shifted as well as the step, which gave me an answer that was offset by exactly two units in the s-domain. Once I corrected that, the transform worked cleanly. This kind of issue is exactly why doing practice problems beats passive studying every time. Convolution is another area where beginners get tripped up. The convolution theorem states that multiplication in the s-domain corresponds to convolution in the time domain, but most students try to compute the convolution integral directly when a simpler path exists. If you have two transfer functions multiplied together, just take the inverse transform of each one separately and read off the time-domain responses. The product in the s-domain already encodes the convolution result. This shortcut saves significant time on exam problems where the direct integral would be painful. The delta function deserves a mention because it causes unnecessary confusion. The Laplace transform of the Dirac delta at the origin is simply one. The transform of a delta shifted to t equals a is e to the negative sa. These are clean results that often get buried under lengthy derivations in textbooks. In practice, I use these facts constantly when dealing with impulse responses and system inputs.
Get the Full Details

There are real limitations to this method that nobody talks about enough. The Laplace transform requires functions to be of exponential order, meaning they cannot grow faster than e to the power of c t for some constant c. Functions like e to the t squared do not have a Laplace transform in the classical sense. Similarly, transforms of periodic functions require infinite integration ranges and the resulting expressions can become unwieldy. When these conditions fail, you need to switch to other tools like the Fourier transform or numerical methods. Another practical limitation is that the unilateral Laplace transform, which is what almost all engineering courses teach, only handles t greater than or equal to zero. If your problem involves signals or system behavior before t equals zero, you are out of luck with this framework. The bilateral transform exists but it is rarely used in standard control theory or circuit analysis courses, and the added complexity is almost never worth it for typical homework problems. For people looking to build fluency, I recommend working through at least forty to fifty problems across these categories: basic transforms from the table, derivatives with initial conditions, partial fraction decomposition, convolution theorem applications, piecewise functions with unit steps, and at least a handful of second-order system responses. Doing problems in this sequence builds the skill incrementally rather than leaving you to stumble through increasingly complex cases without foundation.
Some of the best free resources available online include MIT OpenCourseWare problem sets from their differential equations and signals and systems courses, as well as Paul's Online Math Notes, which has a dedicated Laplace transform section with worked examples at varying difficulty levels. Khan Academy also has a solid tutorial series, though it covers less advanced material than the other two. For textbook practice, Ogata's Control Systems Engineering and Kreyszig's Advanced Engineering Mathematics both contain extensive problem sets with answers in the back. If you want a single comprehensive resource, I would look for a compiled problem set or workbook focused specifically on differential equations with Laplace transform applications. Many universities publish their own problem collections freely online, and these tend to reflect the actual difficulty level and style of problems you will encounter on exams. Professor Bruce I. Collins from Cal Poly has a well-regarded problem collection, and the Georgia Tech open course materials on circuits and signals also include detailed solutions that show the intermediate steps rather than just the final answer, which is far more useful for learning. The bottom line is that competence with Laplace transforms comes from repetition and from making and correcting mistakes, not from memorizing formulas. The method itself is reliable for linear time-invariant systems, which covers the vast majority of problems you will face in introductory engineering courses. Beyond that, you need to know when it stops working and what to reach for instead.