Working With Parametric Curves And Why Everyone Messes Up The Arc Length
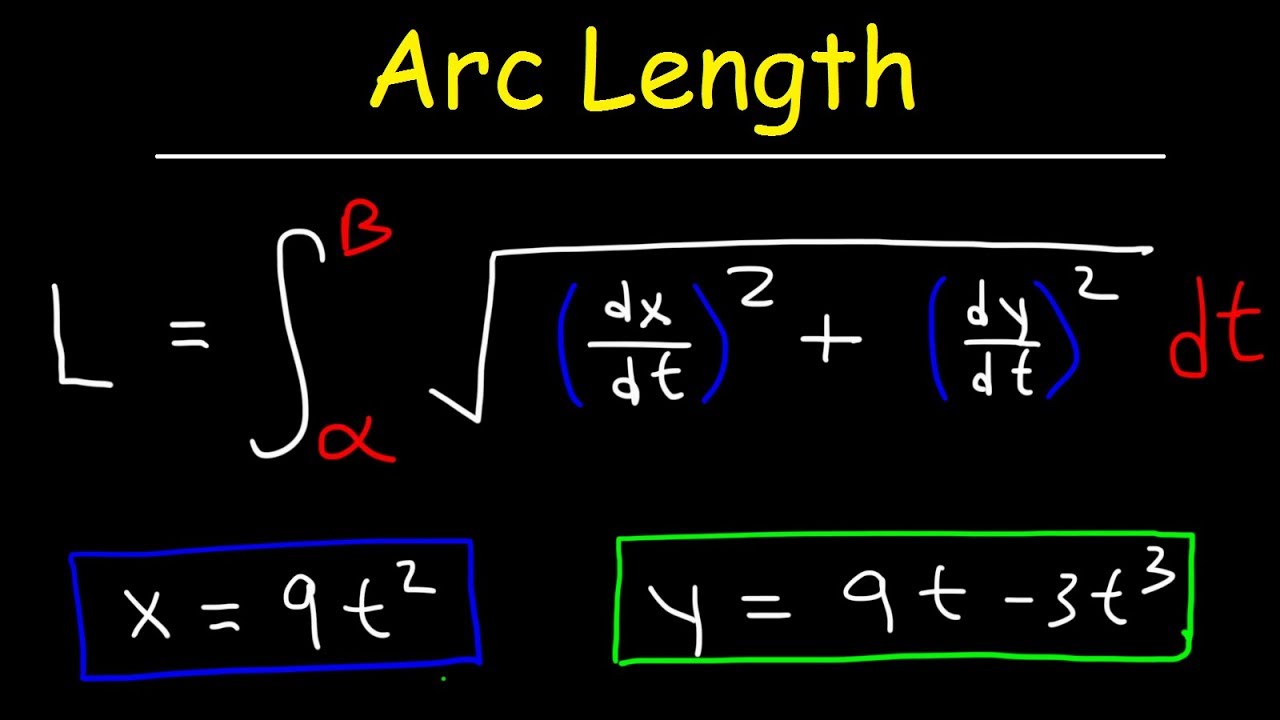
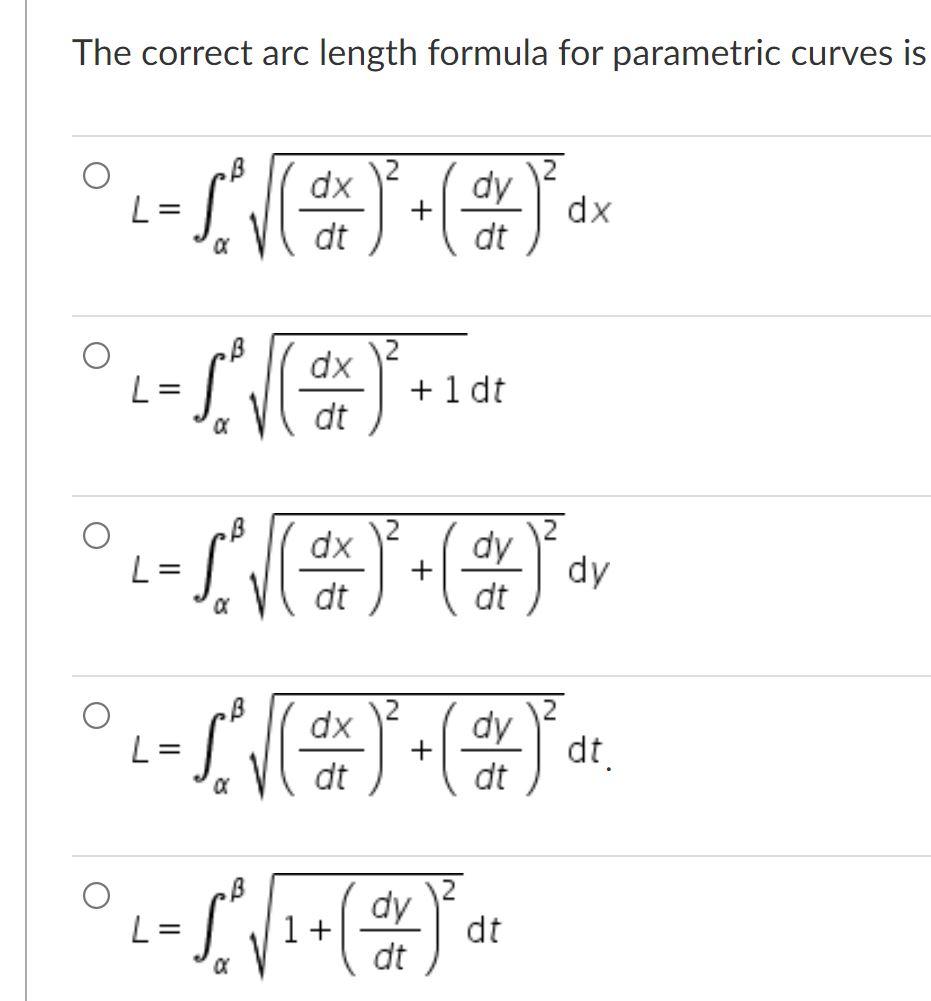
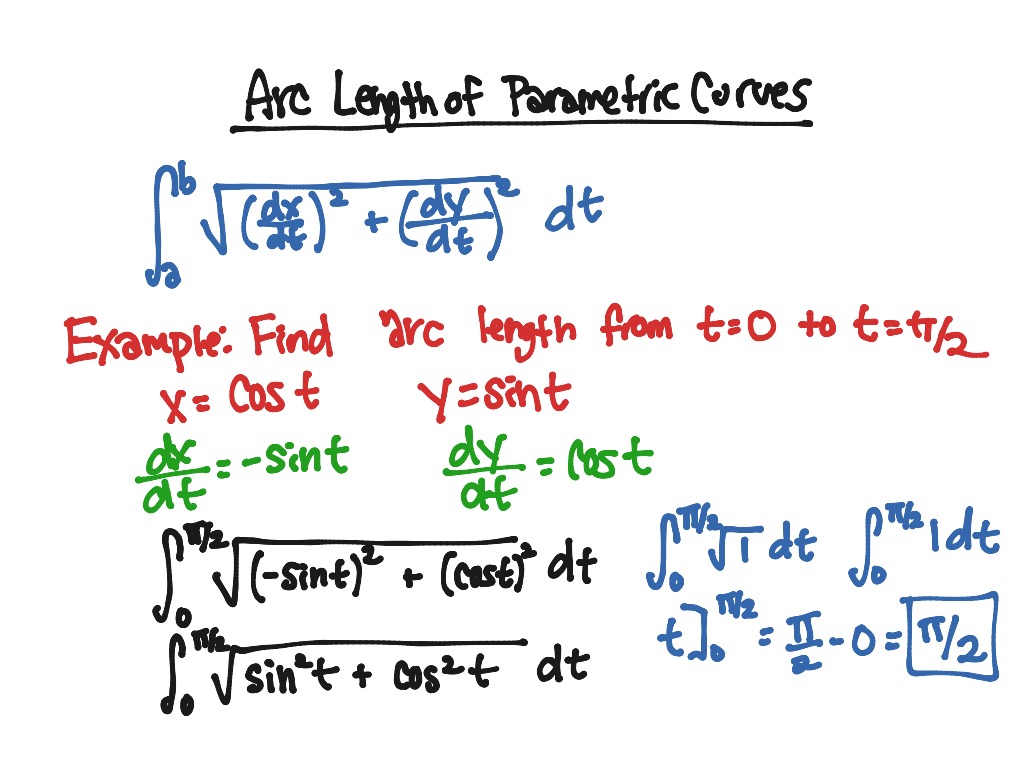
I spent about three weeks debugging a CNC toolpath program last year because someone used a parametric circle defined with cosine and sine, and the length calculation kept returning half the expected value. Turns out they had the parameter running from 0 to instead of 0 to 2. The math was right. The setup was wrong. This happens more than you would think. A parametric curve is just a set of coordinates that depend on some independent variable, usually called t. So x = f(t) and y = g(t), and as t moves through an interval, the point traces out a path. The Length Of Parametric Curve is the total distance along that path, which is computed using an integral. Specifically, it is: L = integral from a to b of sqrt((dx/dt)² + (dy/dt)²) dt
This formula comes from approximating the curve as a series of tiny straight line segments and summing them up in the limit. Each small segment has horizontal component dx and vertical component dy, and the Pythagorean theorem gives the length of that little piece. The derivative form just makes it computable.
The Practical Method
You start by taking the derivatives of your parametric equations with respect to t. Then you square each one, add them together, take the square root, and integrate over the interval that covers the portion of the curve you care about. That is the method. There is not a lot of variation in the procedure. The hard part is almost never the integration itself. It is setting up the derivatives correctly and making sure the parameter range actually corresponds to the arc you want to measure. I have seen people use the standard arc length formula for y = f(x) on curves that are clearly parametric, which defeats the whole point of having the parametric form in the first place. For example, consider the cycloid defined by x = r(t - sin t) and y = r(1 - cos t). The derivatives are dx/dt = r(1 - cos t) and dy/dt = r sin t. Squaring and adding gives r²(2 - 2 cos t), which simplifies using a half-angle identity to 4r² sin²(t/2). The square root is 2r |sin(t/2)|, and integrating that over one arch from 0 to 2 gives 8r. A classic result, but getting there requires actually working through the trig simplification. Most people skip that step and punch numbers into a calculator, which works until the parameter range changes.
Get the Full Details

When The Integral Does Not Cooperate
Not every parametric curve produces an integral you can solve by hand. Some of them do not have elementary antiderivatives at all. The ellipse is a standard example. If you parameterize it as x = a cos t and y = b sin t, the arc length integral involves sqrt(a² sin² t + b² cos² t), which leads to an elliptic integral. These are well-studied but they do not have closed-form solutions in terms of basic functions. When that happens you have a few options. You can evaluate the integral numerically using something like Simpson's rule or adaptive quadrature. Most scientific computing libraries handle this without much trouble. A quick Python snippet with scipy.integrate.quad will typically give you five or six decimal places of accuracy in under a second for moderate parameter ranges. I usually default to that approach unless I am teaching a class and need the analytical derivation on the board. Another option is to approximate the curve with piecewise polynomial segments, like Bézier or B-spline curves, and sum the lengths of those segments. This is what CAD software does internally, and it is accurate enough for most engineering purposes when the segments are short. The trade-off is that you introduce approximation error, so you need to check convergence by refining the discretization until the result stabilizes.
Length Of Parametric Curve In Practice
Here is a situation I ran into recently that highlights a subtle issue. I was working with a parametric spiral where r = e^(0.1t) and the angle goes from 0 to 10. The speed function sqrt((dr/dt)² + (r d/dt)²) grows exponentially with t, which means the integrand changes rapidly near the upper end of the interval. Standard numerical integrators can miss the sharp growth and return a value that is noticeably too low if the default tolerance is left at 1e-6. The workaround was to increase the absolute and relative tolerance settings and split the integral into two parts: one from 0 to 5 and another from 5 to 10. That gave consistent results across different quadrature methods. I verified the answer by comparing it against a high-resolution polygonal approximation with a million segments, and the difference was under 0.01 percent. That level of confidence is usually what you need for production work.
Common Mistakes That Waste Time
The most frequent error I see is ignoring the absolute value when simplifying the square root. When you take sqrt(sin²(t/2)), the result is |sin(t/2)|, not sin(t/2). If your parameter interval crosses a point where the sine changes sign, dropping the absolute value will subtract rather than add that portion of the length. This is an easy mistake to make and almost impossible to catch from a visual inspection of the curve, since the path looks perfectly normal. Another pitfall is using a parameter that does not cover the full curve exactly once. If the parameter winds around twice, you double the length. If it stops short, you get less than you expect. Always verify the parameter range by checking the start and end points and making sure there is no backtracking or overlapping unless that is intentional. Self-intersecting curves are also tricky. The arc length integral does not care about self-intersections. It will count every segment of the path regardless of whether the curve crosses itself. That is technically correct, but if your goal is the length of the geometric shape rather than the traced path, you need to handle that separately. I once had a client who expected the perimeter of a figure-eight lozenge and was surprised when the parametric calculation returned twice that value.
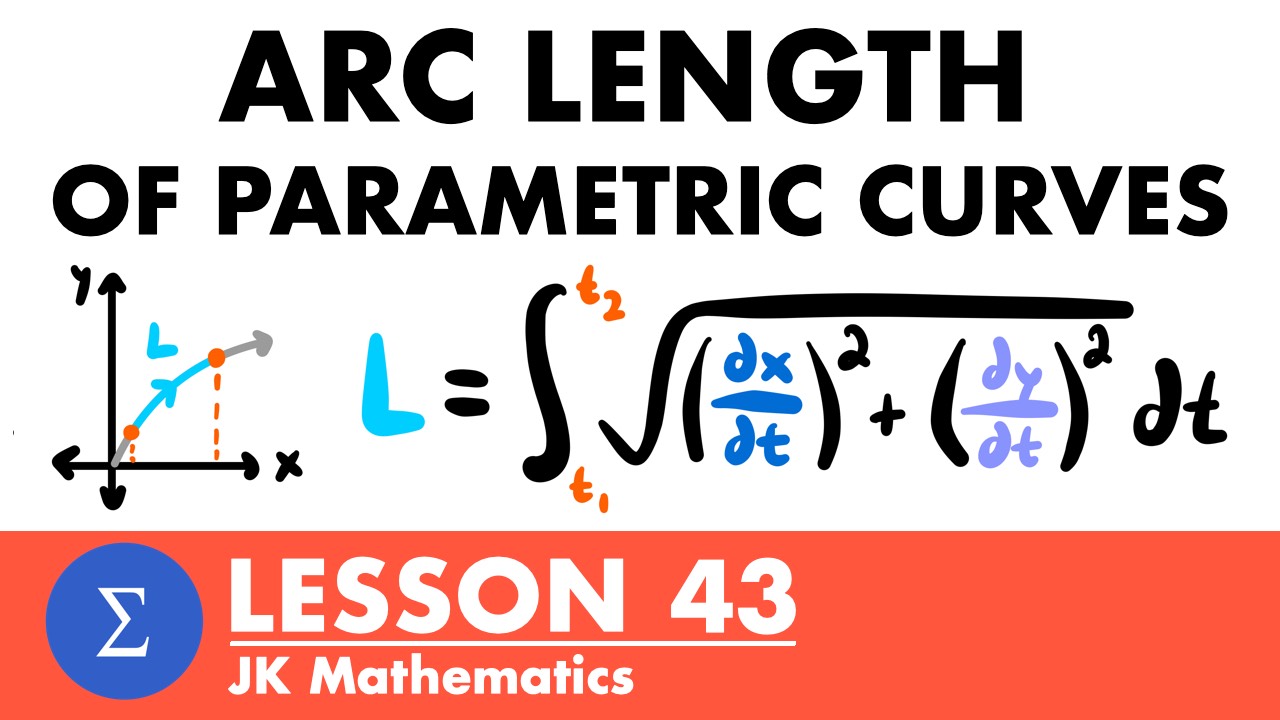
3D And Beyond
The same principle extends naturally to three dimensions. If x = f(t), y = g(t), and z = h(t), then the arc length is the integral of sqrt((dx/dt)² + (dy/dt)² + (dz/dt)²) dt over the appropriate interval. The formula is just the Pythagorean theorem in n dimensions, and nothing about the method changes except that you now have one more derivative to compute. In computer graphics and robotics, you will often encounter parametric curves in 3D space, like helices, clothoids, or spline paths. The length calculation itself is straightforward, but the derivatives can become messy if the parameterization is complex. I usually recommend simplifying the parametric equations algebraically before differentiating, because the derivative of a complicated product can be a nightmare to integrate numerically if the floating-point evaluation loses precision.
When To Use A Different Approach
There are cases where the parametric arc length formula is the wrong tool. If your curve is given as a set of discrete points rather than analytic functions, you should use numerical differentiation or piecewise linear interpolation instead. Applying the calculus formula to tabular data without proper smoothing can introduce large errors, especially if the points are unevenly spaced or noisy. Similarly, if you are dealing with a curve defined implicitly rather than parametrically, converting it to parametric form may not be feasible, and you might need to resort to implicit function techniques or level-set methods. These are more involved and usually require specialized software, so unless you have a specific reason to use them, sticking with explicit or parametric representations is easier. The arc length formula for parametric curves is reliable and well-understood, but it assumes you have a sufficiently smooth parameterization and a parameter range that matches the arc you want. When those conditions hold, the calculation is routine. When they do not, the problem becomes something else entirely, and recognizing that difference is what separates a successful computation from a wasted afternoon.