How Lidar Actually Works Under the Hood
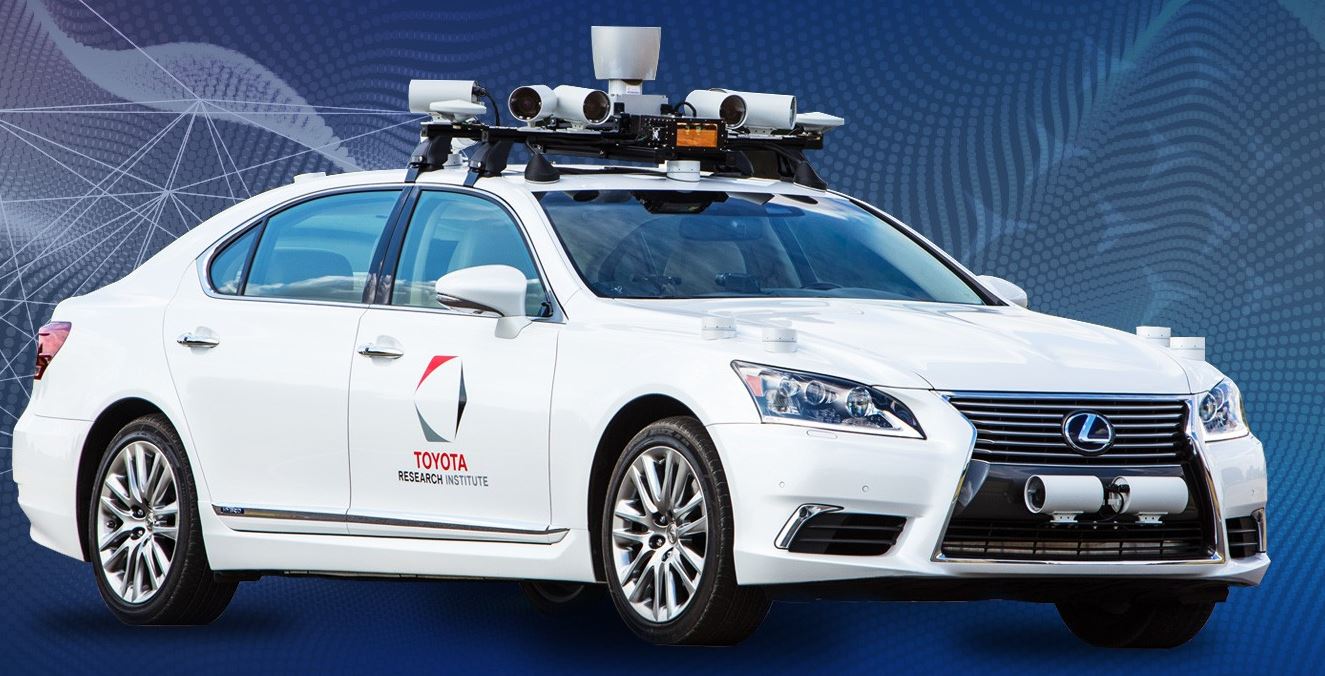
Lidar in a car is basically a spinning sensor that fires laser pulses and measures how long they take to bounce back. Most automotive systems use a 905nm or 1550nm wavelength, both of which are invisible to the human eye but get absorbed into the retina differently. The 1550nm stuff is safer at higher power levels because your eye's natural blink reflex kicks in before damage occurs. That's why you'll see more premium OEMs gravitating toward that range even though it costs significantly more. The spinning part isn't strictly necessary anymore. Solid-state lidar, or what some people call ODiD — optical phasing array — is starting to show up in production vehicles. Instead of mechanically rotating, it steers the beam electronically using phased arrays or MEMS mirrors. Mechanical spinning units still dominate the early market though, mostly because they're cheaper to manufacture and easier to debug when something goes wrong. A typical system samples somewhere between 100,000 and 1 million points per second. That number sounds impressive until you realize the sensor only covers maybe 120 degrees horizontally on most current designs. Your blind spot isn't behind the car like with radar — it's to the sides. You need multiple units to get anywhere near 360 coverage, and each one has to be calibrated independently.
Working With Lidar Technology In Cars
I spent about eighteen months debugging perception stacks that used lidar point clouds as their primary input. One specific problem kept coming up that nobody really talks about in the documentation. We were testing on a stretch of highway where the concrete barriers had those reflective safety markers spaced every few meters. The lidar was picking them up as solid objects at a fixed distance from the road edge, which meant the planning module thought there was a wall of obstacles running parallel to the lane. Every time we'd hit that section, the car would do a slow brake-and-lateral-shift routine that made passengers visibly uncomfortable. The fix wasn't software — it was a combination of adding a filter that suppressed returns below a certain reflectivity threshold and training the classification model on that specific marker pattern so it learned to ignore them as infrastructure rather than obstacles. Takes maybe two weeks of data collection and labeling if you know what you're doing. Without it, you're just fighting the physics of the sensor. Here's something most people get wrong about lidar. More points does not equal better perception. There's a diminishing return somewhere around 200,000 points per second for driving tasks, and beyond that you're just burning compute cycles on redundant data. The real bottleneck isn't point count — it's angular resolution and signal-to-noise ratio in adverse conditions. A lower-resolution sensor that stays calibrated will outperform a high-end unit that's drifted because someone mounted it poorly or the thermal cycling warped the housing slightly.
Another counter-intuitive thing: lidar alone will not make a safe autonomous system. Period. It's excellent at distance measurement and works independently of ambient light, which is genuinely useful at night. But it struggles enormously with textureless surfaces — a white wall, a clear plastic sheet, a patch of wet asphalt that matches the reflectivity of the road. These objects either disappear entirely or register at the wrong distance because the pulse scatters rather than returns cleanly. Cameras complement this by reading color and texture information that lidar simply cannot capture. Fusion isn't optional when you're building something that needs to handle edge cases. Rain and snow are the classic weakness. Water droplets in the air create a noisy point cloud — you get false returns everywhere, and the effective range drops from maybe 200 meters down to 30 or 40 meters in heavy downpours. Some newer systems use polarization filters or dual-pulse techniques to filter out some of that atmospheric noise, but it's not a complete solution. You'll see the confidence scores drop in those conditions, and any sane system should be falling back to radar and camera input as the primary signal. If you're looking to actually deploy lidar in a vehicle project, start with the mounting position and think about thermal management. These sensors generate heat, and temperature changes alter the calibration. I've seen units drift by several centimeters after a few thermal cycles because the adhesive holding the optics in place expanded and contracted differently than the sensor housing. Use a kinematic mount if you can, and recalibrate at regular intervals using a known target pattern. Doing it once during assembly and never again is a recipe for slowly accumulating error that shows up as phantom obstacles or missed detections at the worst possible moment.
Get the Full Details
Cost is still a real factor. A decent automotive-grade mechanical lidar runs anywhere from $500 to $3,000 depending on the spec, and solid-state options are getting cheaper but still sit at a premium. If you're building a proof of concept on a budget, don't buy the cheapest unit you can find — a poorly engineered sensor with bad SNR will cost you more in debugging time than the price difference would have saved you. The bottom line is that lidar is a powerful tool for spatial awareness but it has hard limitations that no amount of algorithmic tweaking will fully overcome. It works best as part of a multi-sensor system, not as a standalone solution. Treat it like any other instrument — understand its blind spots, respect its failure modes, and design your system to degrade gracefully when it can't see clearly.