Getting Your Sensors Where They Need To Go
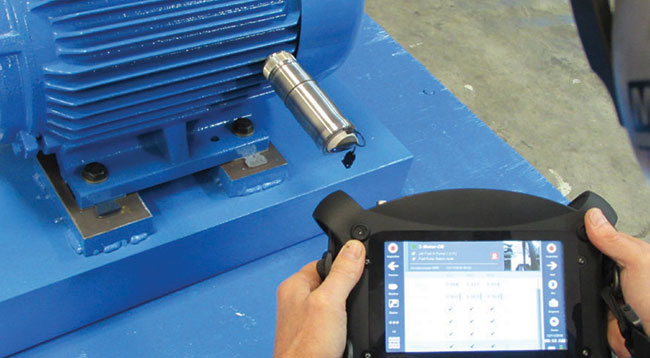
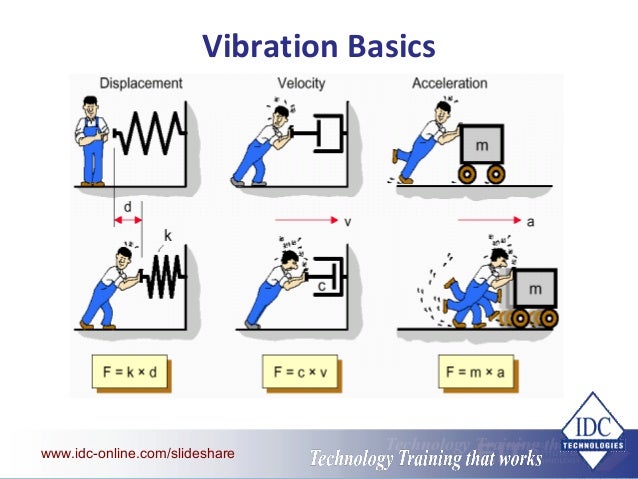
Vibration data is only as good as the point where you collect it. I spent three weeks chasing a false bearing defect on a 1500 RPM motor because the accelerometer was mounted on a painted surface with a layer of epoxy filler underneath. The frequency response rolled off at 2 kHz and masked the actual impacts. Stripped the paint, used a stud mount, and saw the defect within ten seconds of recording. That kind of thing happens more often than you would think. You measure acceleration, velocity, or displacement from transducers placed at specific points on rotating equipment. The raw time waveform gets converted into frequency domain data using an FFT. From there you compare amplitude levels, spectral patterns, and phase information against established baselines and ISO standards to determine whether the machine is healthy, developing a fault, or needs immediate attention. The hardware side is straightforward. A piezoelectric accelerometer, a data collector or online monitoring system, and some kind of mounting method. Stick-on magnets work fine on clean steel surfaces. Stud mounting is the reference standard. Adhesive mounts are acceptable for temporary surveys where drilling is not an option. Probe sticks let you reach points that would otherwise require ladders or disassembly. Pick the mount based on the frequency range you need to capture, not convenience.
Software does the heavy lifting after collection. Modern collectors have built-in analysis tools that compute RMS values, crest factor, kurtosis, and full spectrum displays. For deeper investigation you export the data to dedicated programs like SKF @ptitude, Emerson CSI Analyser, or general-purpose tools like Brüel & Kjær Pulse. The software itself matters less than understanding what each parameter tells you.
What Actually Shows Up In A Spectrum
Unbalance produces a clean single peak at 1× running speed. Misalignment typically shows 1× and 2×, sometimes 3× depending on the type. looseness creates broadband energy and multiple harmonics. Bearing defects are the tricky ones because their signatures change as the fault progresses. Early stage defects show as high-frequency resonance modulation rather than distinct peaks. By the time you see clear bearing defect frequencies like BPFO or BPFI, the damage is usually significant. Here is something people get wrong: high amplitude at a single frequency does not always mean a serious problem. I once flagged a pump with what looked like a severe unbalance condition at 1×. The amplitude was elevated but phase was stable and the overall vibration velocity was within ISO 10816 Zone A. Tracing the piping revealed a structural resonance near the operating speed that was amplifying the response. Adding a guide shoe to stiffen the foundation dropped the reading by forty percent without touching the machine. The machine was fine. The support structure was the issue. Another common mistake is relying solely on overall vibration levels. A machine can sit comfortably inside acceptable velocity limits while developing a gear tooth crack that is barely visible in the overall number. The energy is concentrated in a narrow band that gets averaged out. That is why spectral analysis exists. If you are only looking at RMS velocity you are flying blind for everything except simple unbalance and gross misalignment.
Get the Full Details

Setting Up A Practical Survey Routine
Start by defining what points matter. Horizontal, vertical, and axial measurements at each bearing housing give you the information you need for most rotational machinery. For a standard motor-pump set that means roughly eight to twelve measurement points per unit. Document the point locations with photos and labels so someone else can reproduce the survey later. Record a baseline when the machine is running well. This is your reference for all future comparisons. Without a baseline, a single measurement tells you very little. The absolute number matters less than the trend over time. A velocity reading that has been stable at 2.5 mm/s for three years is less concerning than one that jumped from 1.2 to 3.1 mm/s in two weeks, even though both fall inside typical action thresholds. Sampling rate selection is where most beginners make errors. The Nyquist theorem says you need at least twice your highest frequency of interest. In practice you want four to five times that to avoid aliasing and get usable resolution. For general machinery surveillance covering up to 1000 Hz, a sampling rate of 2560 Hz or higher is reasonable. If you are analyzing bearing defects that may extend to 5 kHz or beyond, you need 12,800 Hz or more. Using too low a sampling rate and then trying to zoom in on high-frequency content afterward just gives you interpolated garbage.
Resolution matters too. More lines in your FFT gives better frequency discrimination. Eight hundred lines is adequate for tracking shaft-related faults. Two thousand to six thousand lines is better when you need to resolve closely spaced frequencies like gear mesh sidebands or multiple bearing defect frequencies in the same spectrum.
When The Data Doesn'T Make Sense
Sometimes you will collect data that looks wrong and you will not immediately know why. Electrical issues can produce vibration at twice line frequency. On a 60 Hz system that is 120 Hz, which can be close to 1× on a 7200 RPM machine. Hydraulic phenomena like cavitation or recirculation create broadband noise that looks similar to bearing damage in the time waveform. The difference shows up in the envelope signal. Bearing faults modulate a resonant frequency and envelope detection pulls that modulation out. Cavitation stays broadband and does not produce the same envelope pattern. I had a case where a gearbox was reporting elevated vibration in the 300 to 800 Hz range across all channels. Every spectrum looked similar. I assumed bearing degradation in multiple gears. Disassembly revealed nothing abnormal. The real cause was an electrical motor driving the gearbox. Voltage imbalance between phases created a radial magnetic force at twice line frequency that excited a structural mode in the gearbox housing. The housing amplified the force in that frequency band. Rewiring the phase balance eliminated the problem. The gearbox never needed any work. These situations are why you need multiple tools in your analysis toolbox. Time waveform. FFT spectrum. Envelope spectrum. Order tracking for variable speed machines. Each one reveals different information and cross-referencing them prevents misdiagnosis.

Limitations You Should Accept
Vibration analysis is not a crystal ball. It cannot predict exact remaining life for every fault type. Bearing life estimation from vibration trends is reasonable in the later stages of defect development, but early detection and quantification of remaining useful life remains unreliable for many fault types. You can tell a bearing is deteriorating. You cannot reliably tell you have forty-eight hours or forty days before failure without additional data like oil analysis or temperature trending. Online monitoring systems have their own constraints. They sample at fixed points continuously, which is valuable for catching sudden changes. But they usually capture only a limited frequency range and a small number of channels. A comprehensive portable survey will outperform an online system for detailed fault identification because you can move sensors, test at multiple speeds, and collect longer record lengths. Online monitoring complements portable surveys. It does not replace them. Environmental factors interfere with measurements. Temperature affects sensor sensitivity and mounting stiffness. Magnetic mounts lose holding force at elevated temperatures. Electromagnetic interference from nearby variable frequency drives can couple into accelerometer cables and distort readings. Shielded cables and proper grounding reduce this. I have seen spectra where the 5th and 7th harmonics of a VFD switching frequency were clearly visible in the acceleration signal, completely unrelated to any mechanical condition.
No single threshold applies to every machine. ISO 10816 provides general guidance categories but these are starting points, not absolute rules. A large generator with a flexible foundation may have higher acceptable velocities than a small rigidly mounted motor. Machine-specific baselines and trend history are always more useful than generic standards.
Practical Steps For Someone Starting Out
Buy or borrow a decent portable vibration analyzer. Something in the $3,000 to $8,000 range will cover most industrial applications. Learn to use it thoroughly before adding more complex tools. Practice on equipment you know is healthy so you build a mental library of what normal looks like across different machine types. Take thousands of measurements. Not hundreds. Thousands. Each one teaches you something about how different machines behave, how mounting affects readings, how load and speed change spectral content. The learning curve is steep at first and then it plateaus. After a few hundred surveys you start recognizing patterns instinctively. Keep records. Every measurement, every photo, every note about operating conditions at the time. This data becomes your most valuable asset when a machine starts showing changes later. The story is always in the comparison, never in the single snapshot.