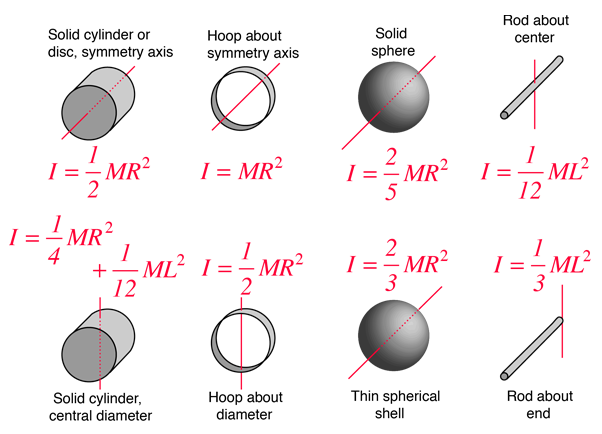Rotational dynamics in real engineering
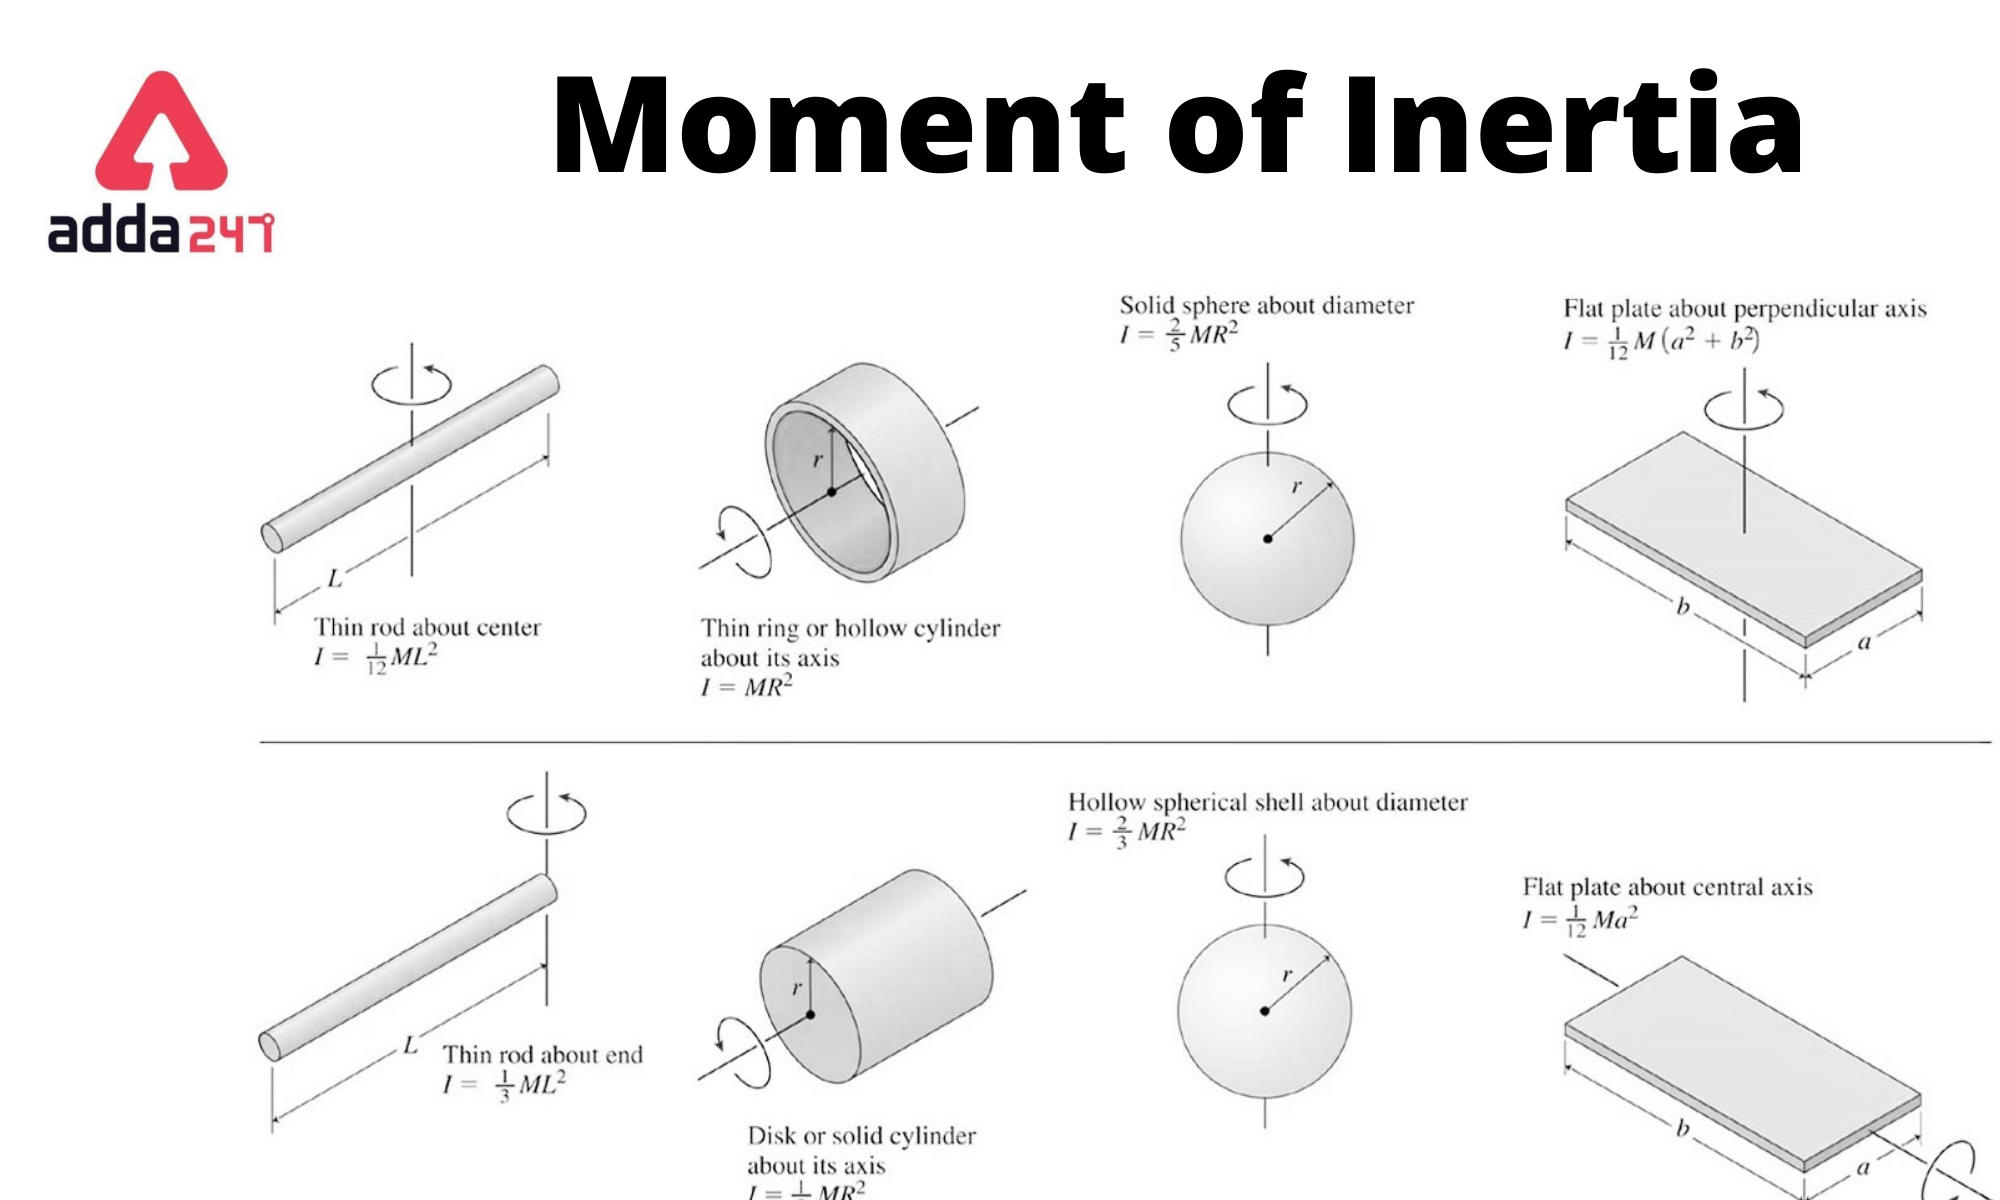
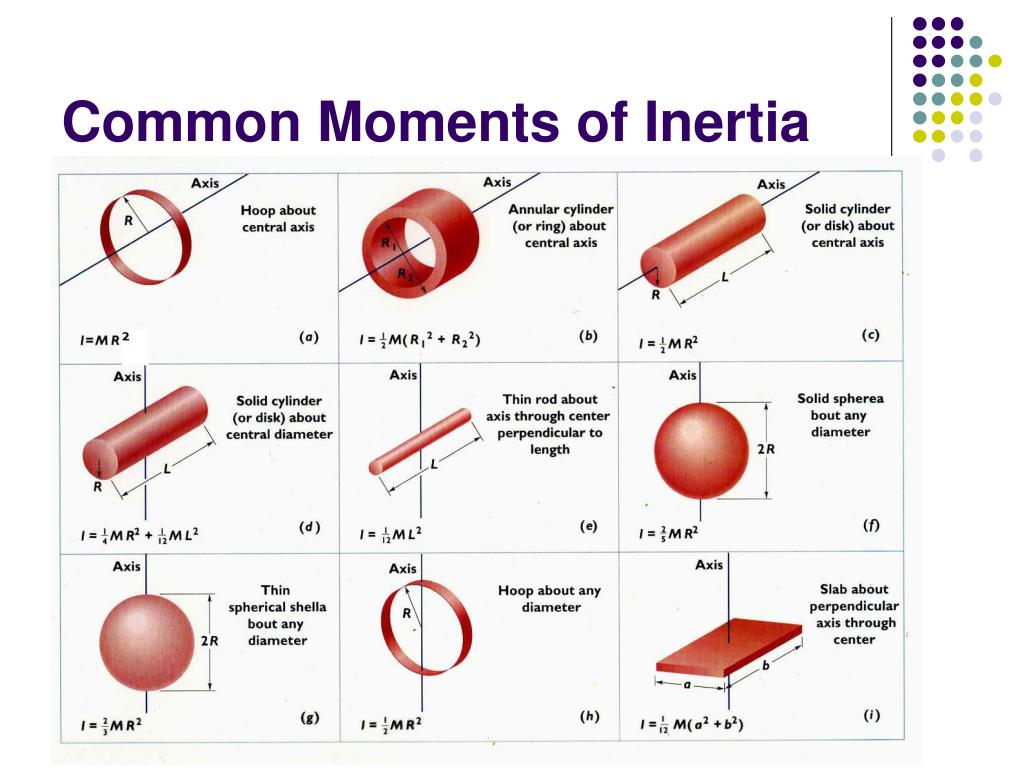
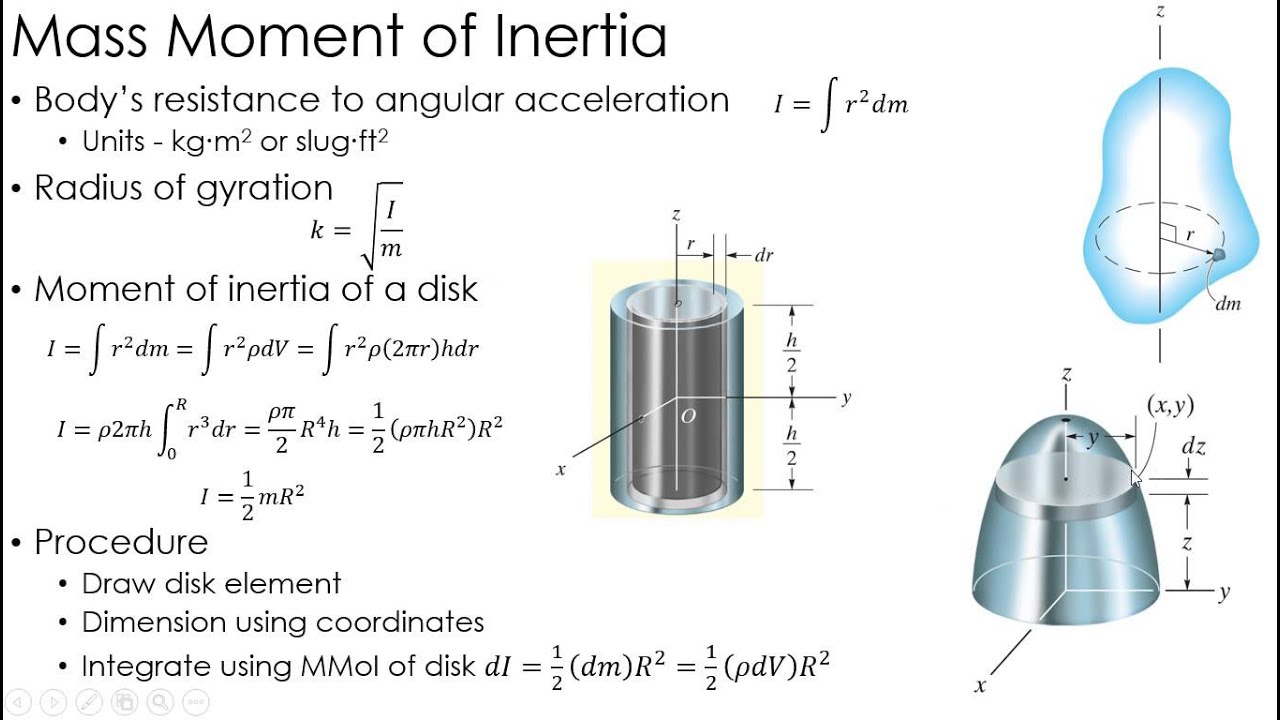
Most people learning about Mass Moment Of Inertia hit the same wall almost immediately. They memorize the thin rod formula and the solid disk formula, then try to apply them to actual assemblies and watch everything fall apart. The truth is that real parts rarely match the textbook shapes. You have pockets, fillets, cutouts, and weird flanges that don't appear in any basic table. The practical way I approach this is to start with integration for simple components, then move to composite bodies once you understand what you're adding together. A solid cylinder of mass M and radius R about its central axis is straightforward. That gives you half MR squared. But as soon as you have a hollow cylinder, you subtract the inner contribution from the outer one. This works because inertia is additive when you treat removed material as negative mass. I use this subtraction method constantly because it saves me from deriving new integrals every time.
Mass Moment Of Inertia for asymmetric assemblies
Here's where things get ugly in the field. I was working on a flywheel assembly a few years back where the hub had five bolt holes machined through it and an uneven keyway on one side. The CAD model looked fine, but when I computed the rotational inertia analytically by breaking it into primitive shapes, the result was off by about 4 percent from the simulation. That 4 percent meant our motor controller was overshooting the target speed during acceleration cycles because the inertia estimate was wrong. The fix was to model the bolt holes and keyway explicitly in the CAD solid, run a numerical inertia extraction on the full geometry, and then cross-check against the analytical result. The numerical approach caught the asymmetry that my hand calculations missed. Going forward, I always use numerical extraction from the CAD model as the primary result and analytical decomposition as a sanity check, not the other way around. If the two disagree by more than a percent, something is wrong with the model or the assumptions. Another thing beginners consistently miss is the parallel axis theorem. It sounds simple but people apply it wrong almost every time. You shift the axis by distance d from the center of mass, and the formula is I plus Md squared. The critical detail is that d is measured from the center of mass, not from any arbitrary point on the body. I see engineers measure d from the mounting surface or the geometric center instead, and the error compounds fast when you stack multiple bodies.
The tensor nature of rotational inertia is another point where practical work diverges from classroom theory. For rotation about a fixed axis, the scalar value is enough. But if your part rotates about an axis that is not a principal axis, you get product of inertia terms that cause vibration and bearing wear. I worked on a rotor that failed inspection repeatedly until we realized the mounting flange was slightly relative to the shaft. The product of inertia terms were significant enough to cause measurable lateral vibration at operating speed. Balancing the part statically didn't help because static balancing only addresses the center of mass location, not the inertia tensor orientation. When you are dealing with thin plates or shells, there is a useful shortcut you should know about. For a thin rectangular plate rotating about an axis perpendicular to the plate through its center, the inertia equals one-twelfth of the mass times the sum of the squares of the two in-plane dimensions. This comes directly from integration and it saves time compared to setting up a triple integral from scratch. One limitation you need to accept is that analytical methods break down completely when geometry gets complex. I have seen teams spend days trying to derive closed-form expressions for parts with complex blend features. The blend radii alone make the integral non-elementary. In these cases, numerical integration through CAD or finite element tools is not a luxury, it is the only practical option. Even so, the numerical results are only as good as the mesh quality and the density of elements near curved surfaces. A coarse mesh can underestimate the inertia of a thin rim by several percent, which matters when you are designing for precise dynamic response.
Get the Full Details

The material density assumption is another blind spot. Most people treat parts as homogeneous, but cast components often have density variations from shrinkage porosity. Machined parts from bar stock might have residual stresses that slightly alter the effective density in localized regions. These effects are usually small, below 1 percent for most engineering materials, but in precision instruments they can be noticeable. I once had a client measuring the inertia of a titanium impeller and finding batch-to-batch variation that traced back to density differences in the raw forging stock. If you need to compute this yourself, the workflow is roughly ten to fifteen minutes for a simple part from CAD export to a validated number, assuming your model is clean. Complicated assemblies with many sub-components can take an hour or more if you are doing manual decomposition. I use the centroid and inertia output from my CAD package as the starting point, then verify against hand calculations for the major features. When the discrepancy is larger than 2 percent, I debug the model. This habit has saved me from shipping incorrect inertia data into simulation models on at least three separate projects. The governing equation remains tau equals I alpha, and knowing I accurately is what separates a design that works on the first iteration from one that goes through multiple rounds of hardware testing and redesign. Get the inertia wrong and your actuator will be undersized or oversized, your control loop will be unstable, and you will waste time tuning parameters that should have been correct from the start.