How I Actually Use Congruence in Real Work
Most people learn congruence in high school geometry and never think about it again until they hit a proof problem they can't crack. The formal definition is simple enough — two figures are congruent if one can be transformed into the other through rigid motions: translation, rotation, and reflection. That's it. But the way it actually works in practice is less clean than the textbook makes it look. When you're checking whether two shapes are congruent, you're really asking whether all corresponding sides and angles match exactly. There's no wiggle room. Same size, same shape. Not similar, not proportional — congruent means you could physically pick up one figure and lay it right on top of the other with every point matching perfectly.Understanding the Math Definition Of Congruence
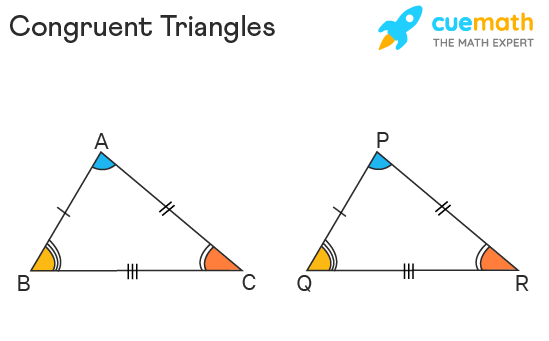
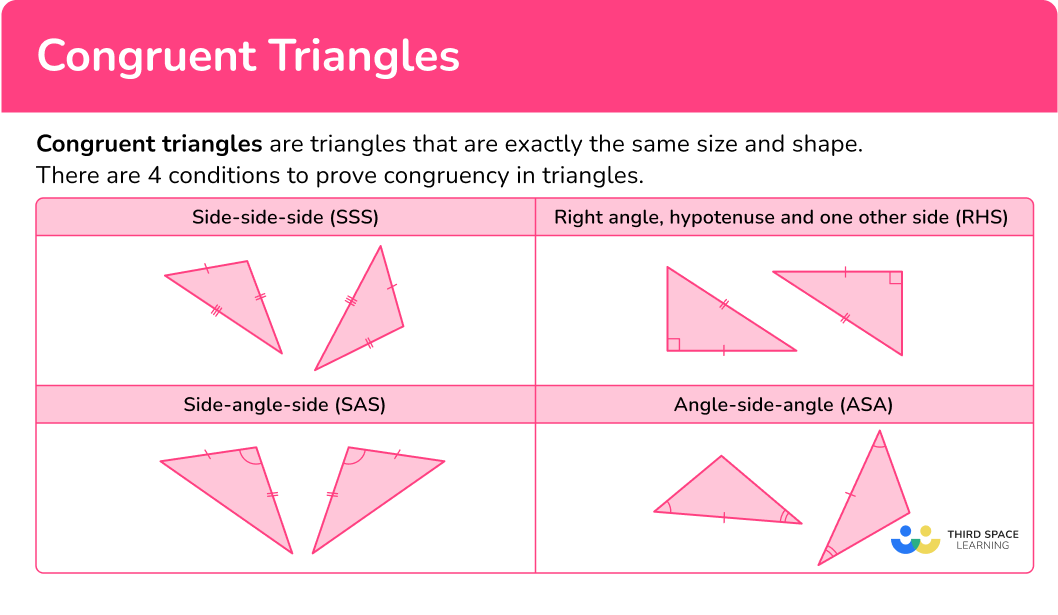
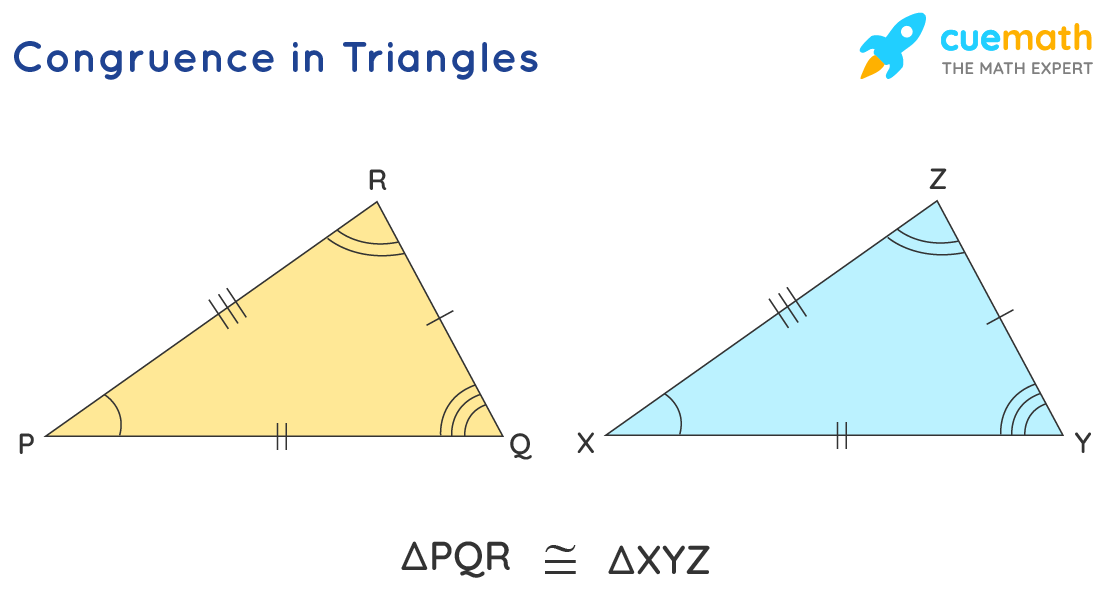
In practice, the test usually comes down to one of several short-cuts depending on what you know. For triangles, the standard criteria are SSS (three sides equal), SAS (two sides plus the included angle), ASA (two angles plus the included side), and AAS (two angles plus a non-included side). These aren't arbitrary rules — they each correspond to a different way you might have the information available when you're actually solving a problem. I spent years working with structural engineers who'd hand me two truss diagrams and ask if they were equivalent under rigid transformation. The first time I tried checking every single angle and side manually, it took forty-five minutes for a pair of moderately complex trusses. The workaround was to compute the invariant properties first — things that don't change under any rigid motion. For planar figures, that means the set of side lengths and the set of diagonal lengths between corresponding vertices. If those multisets match, you know congruence is possible without doing the full angle-by-angle comparison. There's a case where this approach falls apart that I keep running into. I once worked with two quadrilaterals that had identical side lengths in the same order but were still not congruent because one was convex and the other was concave — they had the same sequence of edge lengths but the angles arranged differently. Just knowing the sides isn't enough for polygons with four or more sides. You genuinely need the angle information or the diagonal information too. Triangles are special here because three sides lock everything in place, which is why SSS works as a standalone test. It doesn't generalize.
Another thing nobody tells you about congruence in coordinate geometry is the mess that shows up when your points are given as floating-point coordinates rather than exact values. I've seen problems where two figures looked congruent by inspection but the numerical mismatch from rounding made a direct distance comparison fail. The fix is to use a tolerance threshold — something like 1e-6 for most engineering work — and compare squared distances to avoid square root computation errors where they accumulate. The deeper you go into this, the more you realize that congruence is really an equivalence relation, and that structure matters. It's reflexive, symmetric, and transitive. That means once you establish congruence classes, you can reason about entire families of shapes without checking each pair individually. This is the foundation for a lot of computational geometry algorithms, though nobody talks about it that way in introductory courses. If you're doing this by hand, stick with the triangle criteria and draw the figures. If you're writing code to check congruence computationally, sort the edge lengths and the diagonal lengths, compare the sorted lists with a tolerance, and then verify the angles if the first filter passes. For two-dimensional point sets, there's an O(n log n) algorithm using sorted distance matrices that handles it without brute force. I usually just write a quick script and dump the data rather than doing it manually anymore.