Understanding Vectors in Mathematics
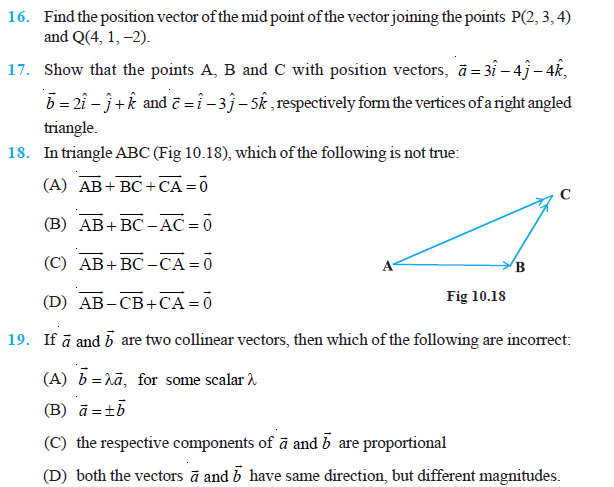
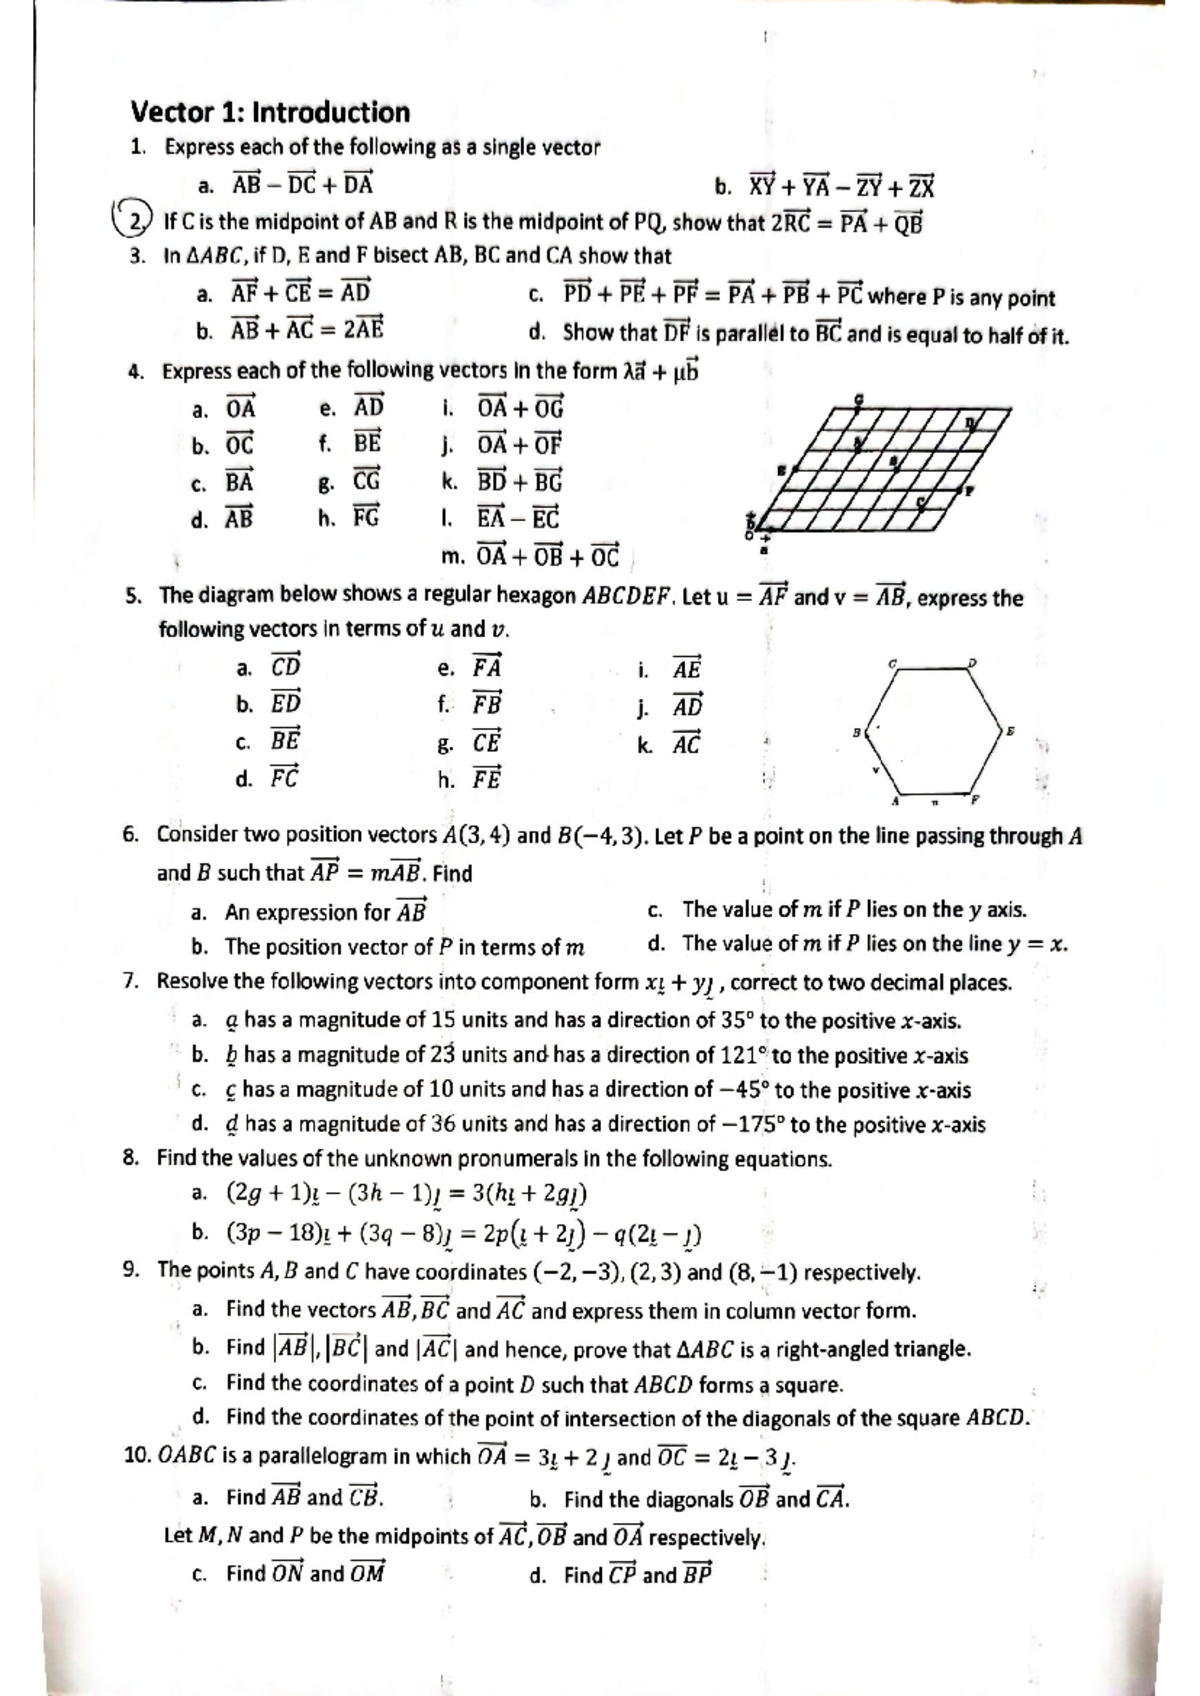
Most students first encounter vectors in high school physics or early university calculus, and they tend to think of them as arrows on a page. That's not wrong, but it's incomplete. A vector is really just an ordered list of numbers that follows certain rules when you add them or scale them. The arrow representation is a visual aid, nothing more. Once you treat them as mathematical objects with algebraic properties rather than geometric doodles, a lot of the confusion disappears. Before getting into any worked problems, here's the core idea. Vectors have magnitude and direction. In two dimensions, you write a vector as (x, y). In three dimensions, it's (x, y, z). You can add vectors component by component, multiply them by scalars, and compute their dot product or cross product. That's the entire foundation. Everything else builds on these operations. Let me walk through a few typical question types and how to solve them properly.
Common Maths Vector Questions And Solutions
Question 1: Given vectors a = (3, -2, 1) and b = (-1, 4, 2), find 2a - 3b. This is straightforward scalar multiplication followed by component-wise addition. You multiply each component of a by 2, giving (6, -4, 2). Then multiply each component of b by 3, giving (-3, 12, 6). Now subtract the second result from the first: (6 - (-3), -4 - 12, 2 - 6), which simplifies to (9, -16, -4). The most common mistake here is mixing up the order of subtraction or forgetting to distribute the negative sign across all components of b. I see this in exam scripts constantly. Students will subtract only the x-component and then move on, which gives an obviously wrong answer but earns partial credit at best.
Question 2: Find the dot product of a = (2, 5, -1) and b = (3, -2, 4). The dot product is a · b = (2)(3) + (5)(-2) + (-1)(4). That equals 6 - 10 - 4, which is -8. The dot product produces a scalar, not a vector. That's worth remembering explicitly because students sometimes write the answer as a vector by accident. A negative dot product just means the angle between the vectors is greater than 90 degrees. Nothing wrong with that result. If you need the angle between two vectors, rearrange the formula: cos = (a · b) / (|a||b|). Compute the magnitudes separately. |a| = (4 + 25 + 1) = 30. |b| = (9 + 4 + 16) = 29. So cos = -8 / (30 × 29), and 102.4 degrees.
Get the Full Details

Question 3: Find the cross product of a = (1, 2, 3) and b = (4, 0, 2). The cross product only exists in three dimensions. The result is a vector perpendicular to both input vectors. Set up the determinant: i(2×2 - 3×0) - j(1×2 - 3×4) + k(1×0 - 2×4)
That gives i(4) - j(-10) + k(-8), so the result is (4, 10, -8). Students routinely mess up the j-component because of the negative sign in front of it. Write it out step by step and you won't make that error. Also verify your answer by checking that the result is perpendicular to both originals. (4, 10, -8) · (1, 2, 3) = 4 + 20 - 24 = 0. And (4, 10, -8) · (4, 0, 2) = 16 + 0 - 16 = 0. Both dot products are zero. The calculation is correct.
Line and Plane Problems
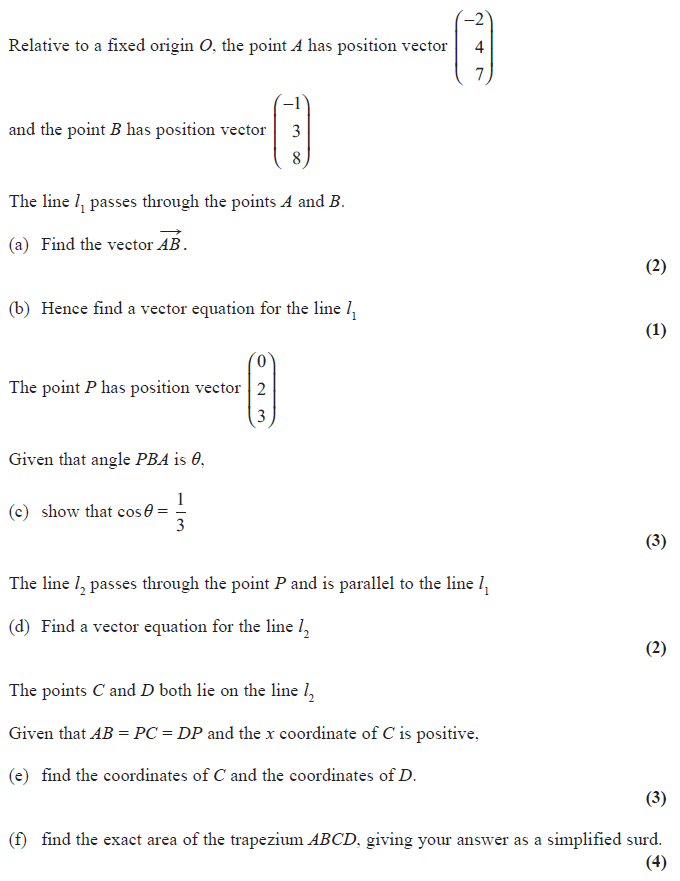
Vector questions in exams frequently involve lines and planes. These are where things get slightly more interesting and where a lot of students lose marks. Question 4: Find the equation of a line passing through point P(1, -2, 3) with direction vector d = (2, 1, -4). The parametric form is simple: r = p + td, where t is a scalar parameter. So r = (1, -2, 3) + t(2, 1, -4). Written out component-wise: x = 1 + 2t, y = -2 + t, z = 3 - 4t. That's the complete answer for most exam boards.
Question 5: Find the Cartesian equation of a plane containing point A(2, 1, -1) with normal vector n = (3, -2, 5). Use the dot product form: n · (r - a) = 0. Expanding this gives 3(x - 2) - 2(y - 1) + 5(z + 1) = 0. Simplify to 3x - 2y + 5z + 3 = 0. The plane equation can also be written as ax + by + cz = d, where d = ax + by + cz. Here, d = 3(2) + (-2)(1) + 5(-1) = 6 - 2 - 5 = -1, so 3x - 2y + 5z = -1, which is the same as above after rearranging. Both forms are correct, but examiners sometimes prefer one over the other, so check your syllabus requirements.
Question 6: Find the shortest distance from point B(4, -1, 2) to the plane 2x - y + 3z = 6. The distance formula is |ax + by + cz - d| / (a² + b² + c²). Plugging in: |2(4) - (-1) + 3(2) - 6| / (4 + 1 + 9) = |8 + 1 + 6 - 6| / 14 = 9 / 14 2.41 units.
Where Students Regularly Go Wrong
I've marked enough vector papers to spot the recurring errors. The biggest one is confusing scalar multiplication with the dot product. These are completely different operations. Scalar multiplication scales every component. The dot product combines two vectors into a single number. When a student writes 3a = (3·x, 3·y, 3·z) = (3x + 3y + 3z), that's a cardinal sin. It conflates two distinct operations and shows a fundamental misunderstanding. Another frequent issue is mishandling the parameter t in line equations. Some students think t has to be positive, or that it must equal 1 for a specific point. It can be any real number. Negative values and fractions are perfectly valid and often necessary. For cross products, the biggest trap is the right-hand rule. If you're asked for the direction of a × b, swapping the order gives b × a, which points in the exact opposite direction. The magnitude is the same but the direction flips. Examiners will specifically test this distinction, so don't treat the cross product as commutative. It isn't.
A Realistic Edge Case I've Seen
Here's a specific scenario that came up recently and consistently trips people up. You're given two lines in 3D and asked whether they intersect, are parallel, or are skew. Most textbook examples make this easy because the lines actually intersect at a nice integer point. Real problems don't always work that way. I encountered a case where Line 1 was r = (1, 0, 2) + s(2, -1, 3) and Line 2 was r = (4, 1, -1) + t(1, 1, -2). Setting the components equal gives three equations: 1 + 2s = 4 + t
-s = 1 + t
2 + 3s = -1 - 2t
Solving the first two simultaneously gives s = 1 and t = -1. But plugging those into the third equation: 2 + 3(1) = 5 and -1 - 2(-1) = 1. Five does not equal one. The lines do not intersect. They're not parallel either, since the direction vectors aren't scalar multiples of each other. Therefore they're skew lines. The workaround is systematic: always solve using two equations, then verify with the third. If the third doesn't check out, state clearly that the lines are skew. Don't just stop at "no solution" — label it properly. Examiners reward that precision.
Using Vectors in Applied Problems
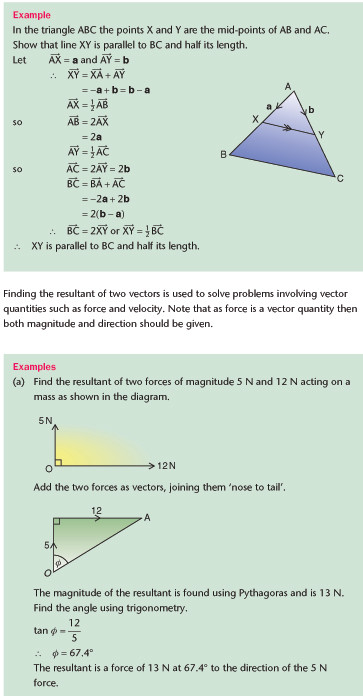
Vectors aren't just abstract exercises. They appear in mechanics for force resolution, in kinematics for velocity and displacement, and in computer graphics for lighting calculations. If you're studying physics alongside mathematics, understanding vectors as algebraic entities rather than just pictures will serve you better. Force diagrams can get messy quickly when you're dealing with three or more forces at angles. Component resolution through vectors cuts through that mess in about two minutes per problem, compared to five or ten minutes of trigonometry. For optimization problems involving vectors, like finding the minimum distance from a point to a line, you set up the squared distance function and minimize it with respect to the parameter. Differentiating and setting to zero gives the optimal parameter value. This is faster than trying to guess geometrically, especially in three dimensions where visualization fails.

When Vectors Fail You
Vector methods aren't universal. They break down or become impractical in certain situations. For instance, in non-Euclidean geometries like spherical surfaces, standard vector addition doesn't work the same way because the space itself is curved. Parallel transport on a sphere doesn't return you to the same vector orientation. If you're working in robotics or computer animation on curved manifolds, you need differential geometry tools, not basic vector algebra. Another limitation: vectors in pure form don't handle rotational dynamics well beyond simple cross products. Angular momentum involves the cross product of position and linear momentum, but when you're dealing with rotating reference frames or precession, you need tensor notation or quaternions. Vectors alone become cumbersome and sometimes misleading in those contexts. For high school and undergraduate calculus-level work, vectors are reliable and efficient. Just know where their ends so you don't waste time forcing them into problems that need a different framework.
If you want more practice, look for past paper collections from exam boards like Edexcel, AQA, or IB. They publish full marking schemes that show exactly what steps earn marks. That's more useful than random worksheets because it tells you what level of detail is expected. I usually recommend doing at least two full papers under timed conditions before any vector-heavy exam. It builds speed and exposes which question types still give you trouble.