What Inverse Actually Means When You're Not in a Textbook
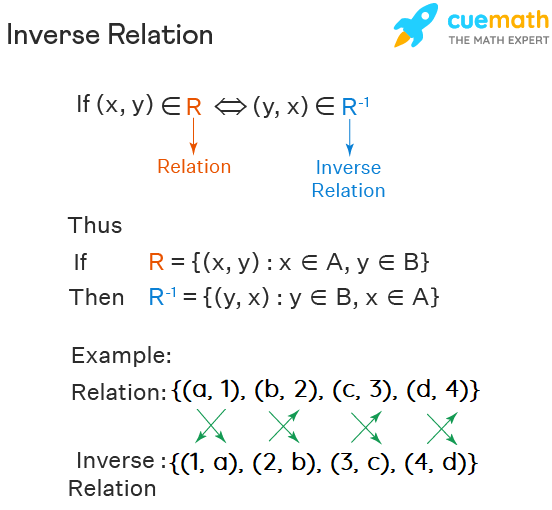
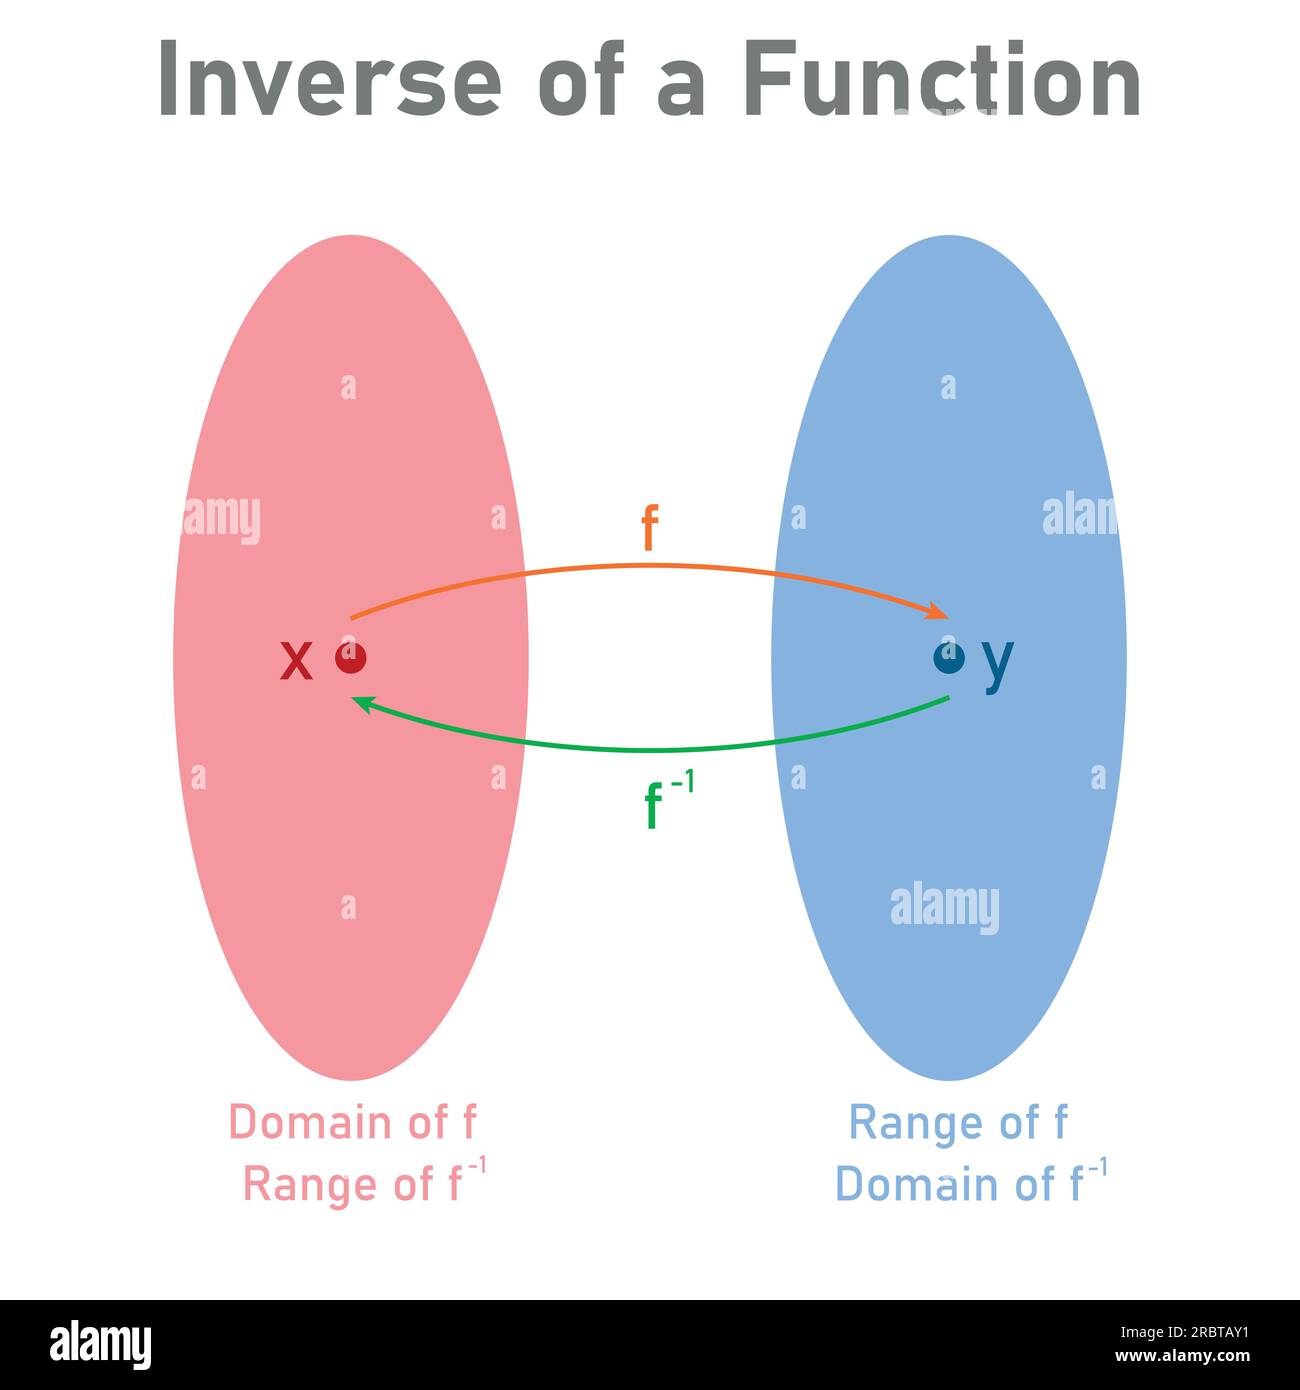
Most people hear "inverse" and think of reciprocals or flip-flopping numbers. It's simpler than that but also messier in practice. An inverse is something that undoes an operation. That's it. The concept shows up everywhere in math, but each type comes with its own quirks and ways it breaks. When you add 5 and get some result, the inverse operation is subtracting 5 to get back to where you started. When you multiply by 3, dividing by 3 reverses it. Function inverses work the same way conceptually, but that's where things get complicated fast. For a function to have an inverse, it has to be one-to-one. Every output maps back to exactly one input. If two different x values give you the same y, the inverse isn't a function. I spent a whole semester untangling students' confusion over this before I stopped bothering to explain it and just made them draw the horizontal line test on everything.
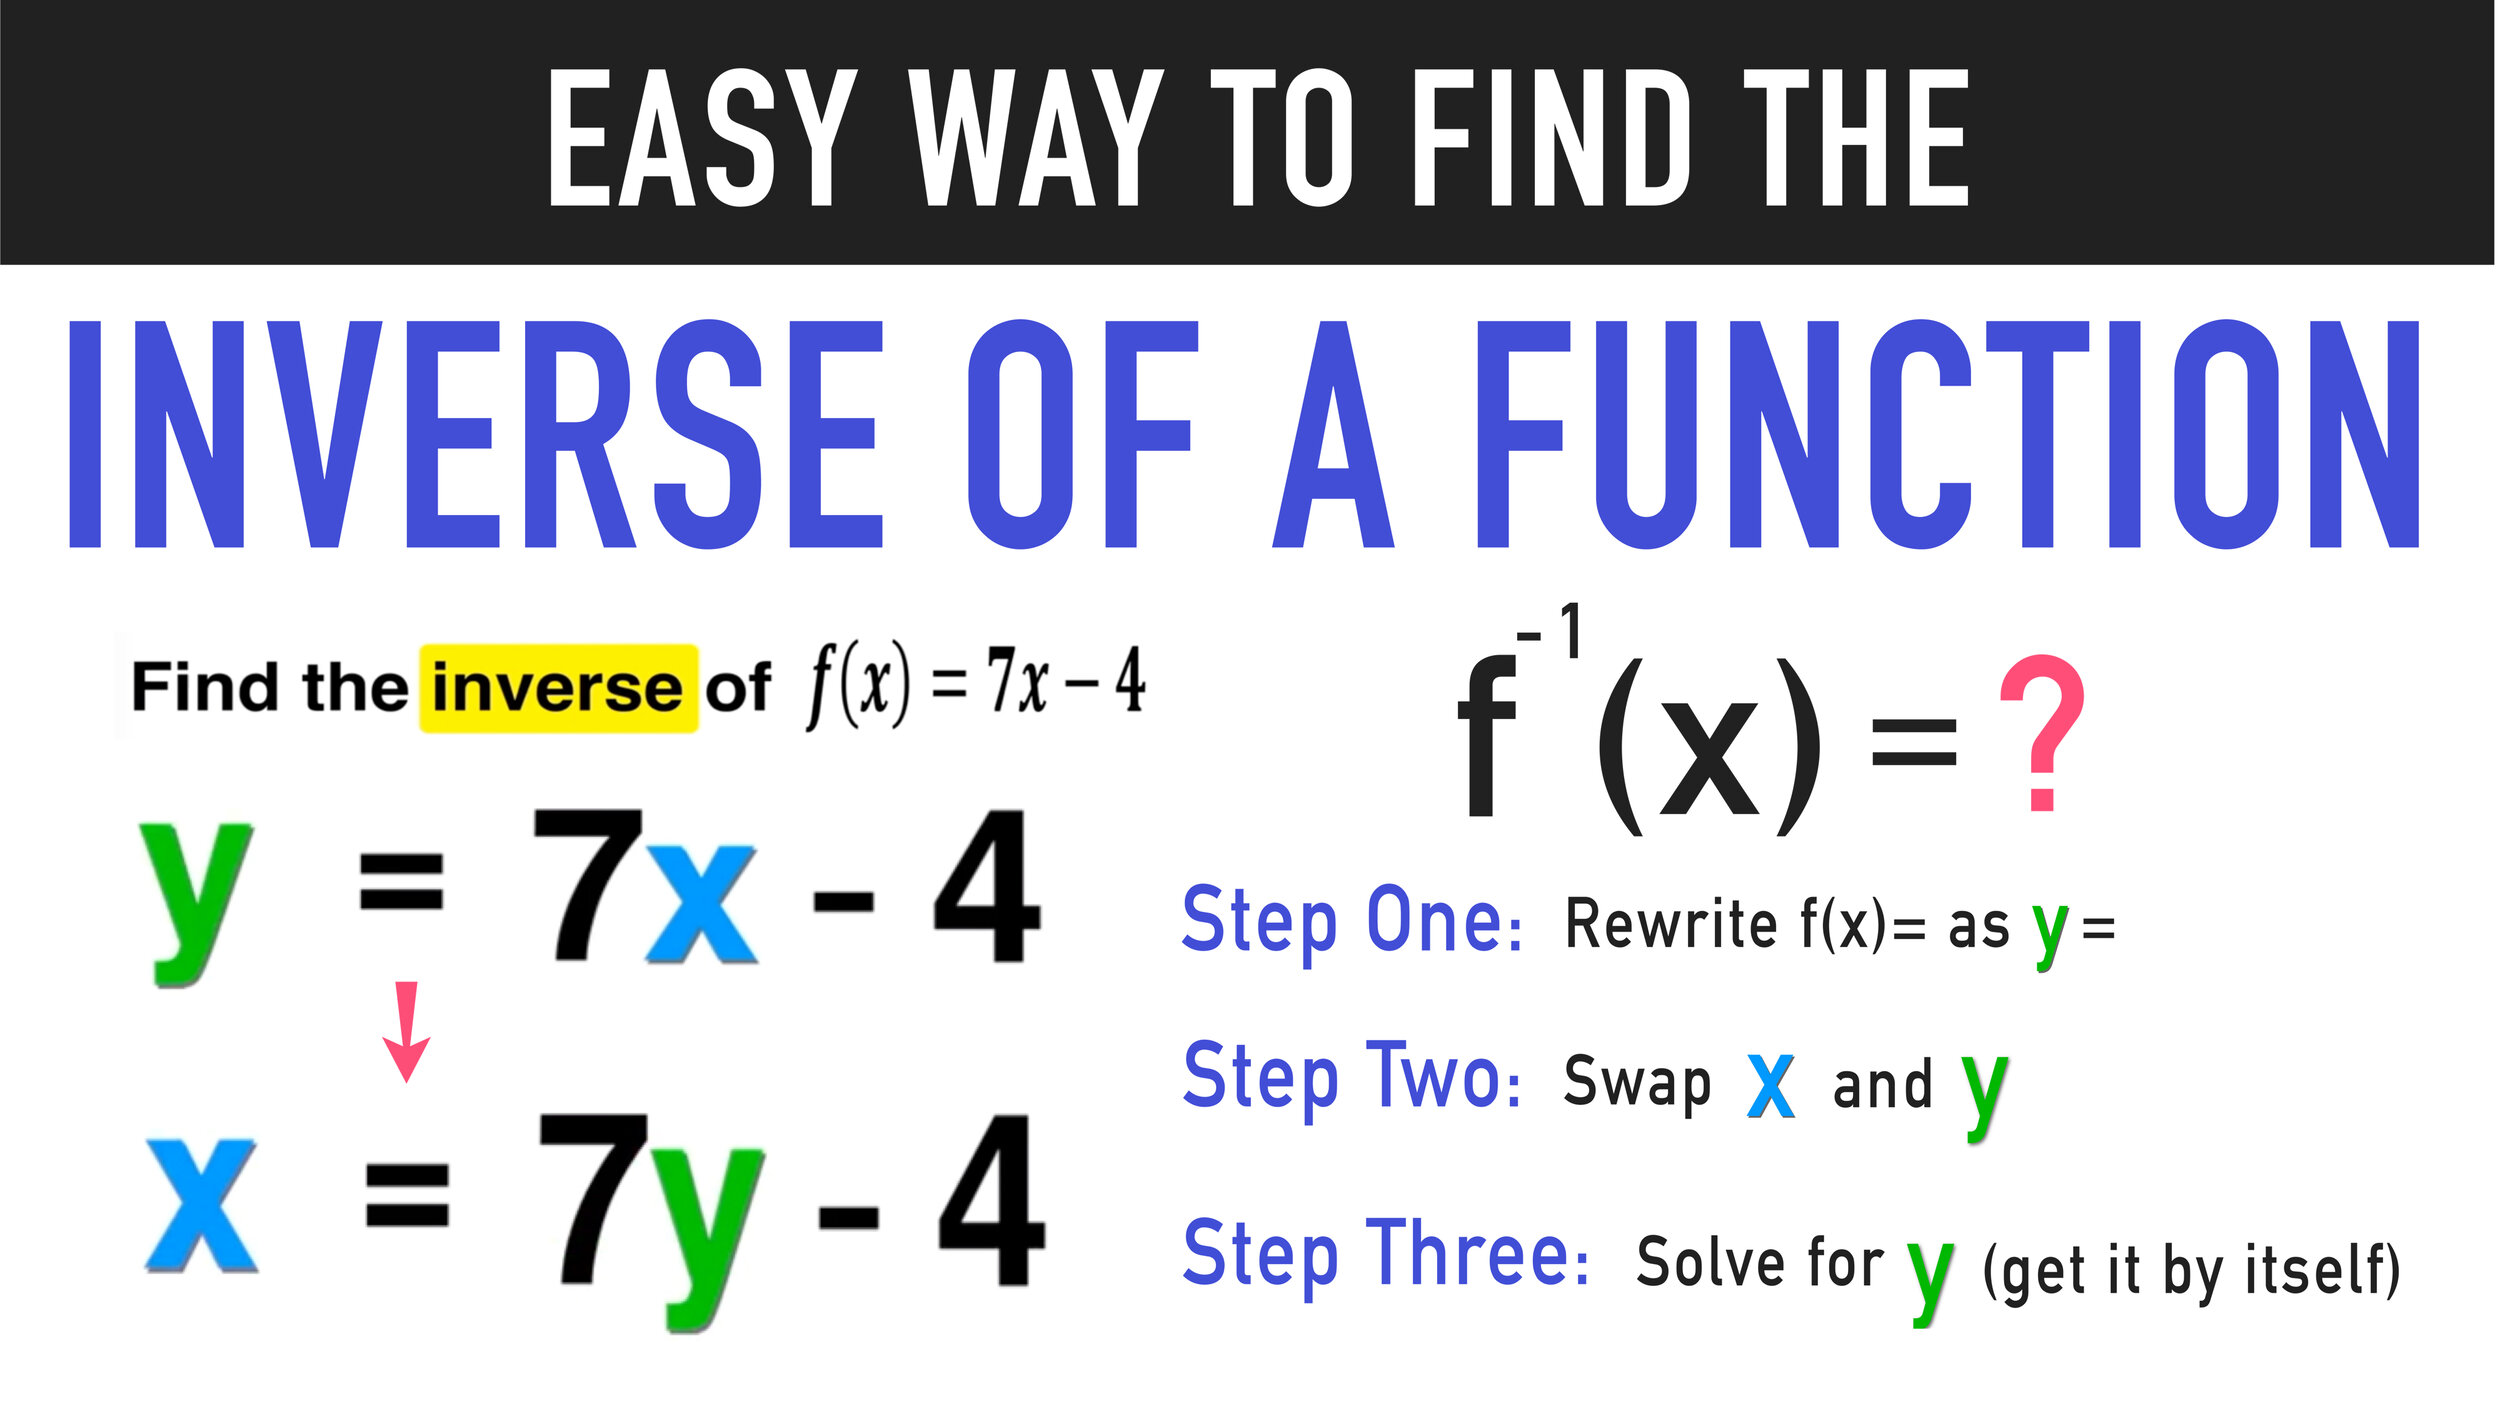
To find the inverse of a function algebraically, swap x and y, then solve for y. That's the standard algorithm. It works for linear functions, simple polynomials, exponentials and logarithms paired together. But don't expect it to work cleanly for everything, because it doesn't.
When Inverses Exist and When They Don't
Not every function has an inverse that's also a function. Take f(x) = x squared. Flip it and you get x = y squared. Solving for y gives you the positive and negative square root. That's two outputs for one input. Not a function. You can restrict the domain to make it work. For x squared, limiting to x greater than or equal to zero gives you the standard square root function as its inverse. This is taught early but people forget why the restriction matters until they run into problems later on. Matrices are another place where inverses appear, and they're even less forgiving. A matrix only has an inverse if its determinant is not zero. Zero determinant means the matrix squashes space into a lower dimension. You can't undo that. I ran into this during a numerical methods project where a nearly singular matrix was causing my solver to blow up. The determinant was on the order of 10 to the negative 15. I had to restructure the system and add a small regularization term to get it to behave. Pure inversion failed entirely.
Get the Full Details
The Practical Side of Finding Inverses
For a simple function like f(x) = 2x plus 7, the inverse is straightforward. Swap variables: x = 2y plus 7. Solve: y equals x minus 7 divided by 2. Done. Check it by composing the functions. f of f inverse of x should give you x back. f inverse of f of x should also give you x. If either composition doesn't simplify to x, you made an error somewhere. Trigonometric functions are where this gets annoying. The sine function oscillates. It's not one-to-one over its entire domain. The inverse sine function, arcsine, is defined by restricting the domain of sine to between negative pi over two and pi over two. Same thing for arccosine and arctangent with their own restrictions. If you skip the restriction discussion, you'll get wrong answers on tests and in applications. I once had someone try to use the inverse sine to solve a physics problem involving angles in a triangle. They got two valid answers from the calculator and picked the wrong one. The restriction tells you which branch the inverse function operates on, but real-world problems don't always respect those conventions. You have to check your answer against the actual geometry of the situation.
Matrix Inverses in the Real World
In linear algebra, the inverse of a matrix A is a matrix A inverse such that A times A inverse equals the identity matrix. The identity matrix has ones on the diagonal and zeros everywhere else. It's the matrix equivalent of multiplying by one. You can compute inverses using Gaussian elimination, row reducing the augmented matrix with the identity on the right side. Or you can use the adjugate method, which involves determinants and cofactors. The adjugate method is fine for small matrices. For anything larger than three by three, it becomes computationally expensive and numerically unstable. Here's what nobody tells you: most people who use matrix inverses in practice shouldn't be computing them directly. If you're solving a system of linear equations, use Gaussian elimination or LU decomposition instead. Computing the inverse explicitly is slower and less numerically stable. I learned this the hard way when a finite element analysis code I was maintaining was taking forty minutes to assemble a stiffness matrix solution. Switching from explicit inversion to a direct solver cut it down to about three minutes.
Edge Cases and Failures With Inverses
Sparse matrices are a particular pain point. When you compute the inverse of a sparse matrix, the result is often dense. You lose the memory advantage entirely. For large sparse systems, iterative methods like conjugate gradient or GMRES are the way to go. They approximate the solution without ever forming the inverse. Another failure mode is the ill-conditioned matrix. The condition number measures how sensitive the solution is to perturbations in the input. A high condition number means tiny errors in your data get magnified enormously in the result. Even if the matrix is technically invertible, the computed inverse may be garbage. I've seen condition numbers above 10 to the 12th produce completely meaningless results on double-precision floating point. In those cases, you need regularization or a different formulation of the problem. Functions with cusps or vertical tangents also cause issues. The cube root function has a vertical tangent at zero. Its inverse, x cubed, is perfectly fine. But try finding the inverse of a function that isn't differentiable at a point and you'll run into trouble with calculus-based applications. The inverse function theorem requires the derivative to be nonzero at the point of interest. Zero derivative means the inverse either doesn't exist locally or isn't differentiable.
How to Actually Use Inverses Correctly
When working with functions, always verify by composition. It takes thirty seconds and catches most mistakes. When working with matrices, check your condition number before committing to an inversion approach. Most numerical libraries will tell you if a matrix is close to singular. Listen to it. For trigonometric inverses, draw the restricted domain on the original function. Visualizing what's happening makes it obvious why certain angles are valid and others aren't. It also helps when you need to compose inverse trig functions with regular trig functions, which shows up constantly in integration techniques. The broader lesson is that inverses are useful but fragile. They don't always exist. When they do exist, they might not behave nicely. The mathematical definition is clean. The practical application is full of boundary conditions and failure modes. Understanding both sides is what separates people who can pass a math test from people who can actually use inverses in engineering or science work.
And that's really the meaning of inverse in math. It's the undo button. Everything else is just figuring out when the button exists, how to press it, and what happens when it doesn't work the way you expect.