How Curves Actually Get Made
Most people think drawing a mathematical curve is just typing an equation into a program and hitting render. It is nowhere near that simple. The mechanisms for generating mathematical curves involve a stack of decisions that compounds quickly, especially when you leave the world of basic polynomials behind. I spent years building procedural geometry tools for animation pipelines, and the difference between a curve that looks correct and one that actually works downstream always came down to parameterization choices nobody talks about in textbooks. At the base level, every curve generation method comes down to mapping a parameter to coordinates in space. The parameter usually runs from zero to one, though sometimes it runs over an infinite range or wraps around like an angle. The mapping function determines everything about the curve's shape, spacing, and smoothness properties. You have parametric equations, implicit forms, control-point-driven schemes, and a few other approaches that exist mostly as compromises. Parametric curves define x and y as separate functions of t. A circle works like this: x equals cosine of t, y equals sine of t. Simple enough until you need uniform arc length distribution, which cosine and sine do not provide by default. You end up recalculating the parameter at regular intervals along the actual path length instead of at regular intervals of t. This matters more than you would think if you are driving anything along that curve, whether that is a camera or a toolpath.
Control point methods, particularly B-splines and NURBS, dominate professional workflows because they give you local editing without reshaping the entire curve. Change one handle and only the nearby section moves. The mathematical mechanism here is a basis function multiplied by control point weights, summed across all points. The blending functions are piecewise polynomials defined over knot vectors. Knot vectors determine where the pieces connect and how smoothly they connect. A knot vector with repeated values reduces continuity at that location, which is how you get sharp corners in otherwise smooth curves. This is a feature, not a bug, but people regularly forget it and get confused when their curve develops a kink. Catmull-Rom splines sit between Bezier and B-spline in terms of complexity. They pass through every control point rather than being pulled toward them, which makes them intuitive for path design. The generating mechanism uses a tension parameter that most implementations leave at the default value of zero point five. Adjusting that tension changes how much the curve bulges between points. Lower tension creates tighter turns. Higher tension pushes the curve flatter. I have seen people try to manually edit Catmull-Rom control points to achieve specific shapes and spend two hours on something that a quadratic Bezier would have solved in ten minutes. Implicit curves define the relationship as F of x and y equals zero. The classic example is x squared plus y squared equals r squared for a circle. Implicit forms are powerful for operations like Boolean unions and intersections, which is why CAD kernels rely on them heavily. The tradeoff is that drawing them requires root finding or marching algorithms, both of which introduce numerical error at the edges. When you export an implicit curve to a mesh or polyline, you are approximating a solution to an equation, and the approximation quality depends entirely on your sampling density and tolerance settings.
What Happens When You Actually Use These
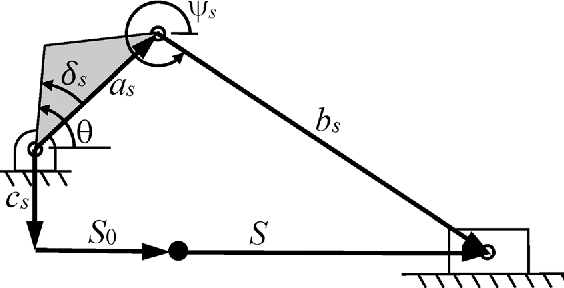
I ran into a specific problem with a cubic B-spline curve that was supposed to represent a mechanical linkage path. The curve looked perfect visually, but when I extracted points at uniform parameter intervals for a simulation, the points clustered unnaturally in some sections and spread out in others. The curve itself was mathematically correct, but the parameterization was non-uniform due to how the control points were distributed. The fix was to resample the curve using adaptive chord-length parameterization, which spreads the evaluation points based on actual geometric distance rather than parameter distance. It took maybe twenty minutes to implement once I understood what was happening, but debugging it initially consumed an afternoon. Here is a counter-intuitive point that beginners miss: higher-degree basis functions are not always better. A degree-four B-spline does not automatically produce a smoother or more accurate curve than a degree-three. In fact, higher degrees introduce more oscillation risk between control points, especially when the points are unevenly spaced. This is sometimes called Runge's phenomenon, and it shows up in curve fitting as unexpected wiggles that have nothing to do with your intended shape. I have seen engineers increase spline degree from three to five trying to fix overshoot, which only made the overshoot worse. The solution was almost always to adjust the control point layout, not the polynomial degree. Another thing that causes problems: many tools approximate transcendental functions internally. If you generate a curve using sine or exponential functions in the parametric equations, the output is only as accurate as the library's approximation of those functions. Standard double-precision math gives you about fifteen decimal digits, which is fine for most rendering applications but catastrophic if you are doing precision machining or scientific visualization where round-off accumulates across thousands of evaluation points. In those cases, arbitrary-precision arithmetic or analytically derived approximations become necessary.
Get the Full Details
NURBS extend B-splines by adding rational weights to each control point. The mechanism is the same basis function summation, but each coordinate is divided by a weighted sum of the basis functions. This single modification lets NURBS represent conic sections exactly, including circles, ellipses, and parabolas. Standard B-splines cannot represent a perfect circle; they can only approximate it with enough control points and careful placement. That is why any serious CAD or 3D modeling system uses NURBS rather than plain B-splines for production work.
Practical Approaches and Where They Break
If you are generating curves programmatically, you typically have three options: use an existing library, build your own evaluator, or sample from a symbolic definition. Each has concrete tradeoffs. Libraries like libigl, OpenCASCADE, or even the math modules in Python give you production-ready curve evaluation with edge cases already handled. The downside is that they are black boxes. When your curve behaves unexpectedly, debugging inside someone else's code is slow and frustrating. I once spent three days tracking down a continuity issue that turned out to be a knot vector edge case in a library's internal representation. I ended up writing a small custom evaluator specifically for that curve type because I needed full visibility into what was happening at each knot span. Building your own evaluator forces you to understand the mathematics deeply. You will make mistakes, and they will surface at the worst possible moments. But you will know exactly why the curve behaves the way it does. For a cubic Bezier, the evaluator is roughly forty lines of code. For a clamped uniform cubic B-spline, it is about two hundred lines including the knot vector management. These are not trivial, but they are manageable if you write tests for each component separately.
Sampling from symbolic definitions, using something like SymPy, gives you exact arithmetic for algebraic curves and good approximations for transcendental ones. The output is usually a dense point cloud that you then simplify or fit to a lower-degree representation. This approach is useful when you need analytical derivatives or when the curve is defined by an equation rather than control points. The drawback is that you are working with approximations at every step, and error compounds as you chain operations together. I use this method for initial curve generation and then convert to NURBS for downstream work because NURBS are the standard format for nearly every rendering and manufacturing pipeline. One specific limitation that deserves attention: most curve generation mechanisms assume planar or three-dimensional space. When you move to higher dimensions, the computational cost grows exponentially and many standard algorithms break down. If you are working with curves in four or more dimensions, you need different mathematical machinery entirely, and the visualization becomes abstract. This is rarely a problem for standard engineering or graphics work, but it catches people off guard when they try to generalize their tools. Another practical issue is numerical stability at curve endpoints. Repeated knots or very close control points can produce near-zero denominators in rational curve formulations, leading to division-by-zero errors or wildly incorrect coordinates. I deal with this by adding a small epsilon tolerance check before any division operation and falling back to a linear interpolation between the neighboring valid points when the denominator drops below threshold. It is a pragmatic fix, not a mathematically elegant one, but it prevents crashes in production code.

The choice of evaluation strategy also affects memory usage significantly. Storing a curve as a sequence of control points and basis function coefficients is compact, but evaluating it on demand for every frame of animation or every pixel of rendering requires computation each time. Caching precomputed evaluations saves time but consumes memory. For real-time applications, I typically precompute a lookup table of curve points at a resolution appropriate for the display, then interpolate between cached values during rendering. This trades a small amount of accuracy for predictable performance, which is usually the right call.
What to Watch Out For
Continuity is not the same as smoothness. A curve can be C-one continuous, meaning the first derivative is continuous, but still look visually jarring if the curvature changes abruptly. G-one geometric continuity is a weaker condition that only requires the tangent direction to be continuous, not the magnitude. Most curve generation tools guarantee C-zero or C-one continuity, but achieving C-two or higher, where the curvature itself is smooth, requires additional constraints on the control point configuration. If visual quality matters, you should explicitly check the curvature profile, not just the position and tangent. Self-intersection is another issue that standard generation mechanisms do not prevent. A well-placed set of control points can make a B-spline loop back on itself, creating regions where the curve crosses its own path. This is fine for some applications like decorative patterns but disastrous for toolpath generation or boolean operations. Detecting self-intersections requires pairwise comparison of curve segments, which is O of n squared in the number of segments. For long curves, this becomes expensive, so I use spatial partitioning to reduce the comparison count to roughly O of n log n. There is no universal best method for generating mathematical curves. Parametric equations are simplest but limited in shape. Control-point methods are flexible but require understanding of basis functions and knot vectors. Implicit methods excel at Boolean operations but are numerically fragile. NURBS are the industry standard for good reason but carry complexity overhead. The right choice depends entirely on what you are building, what precision you need, and what downstream systems will consume the output. Pick the mechanism that matches your constraints, test it thoroughly at the boundaries, and do not trust the visual preview to catch everything.


