Getting Started With 8085 Board Work
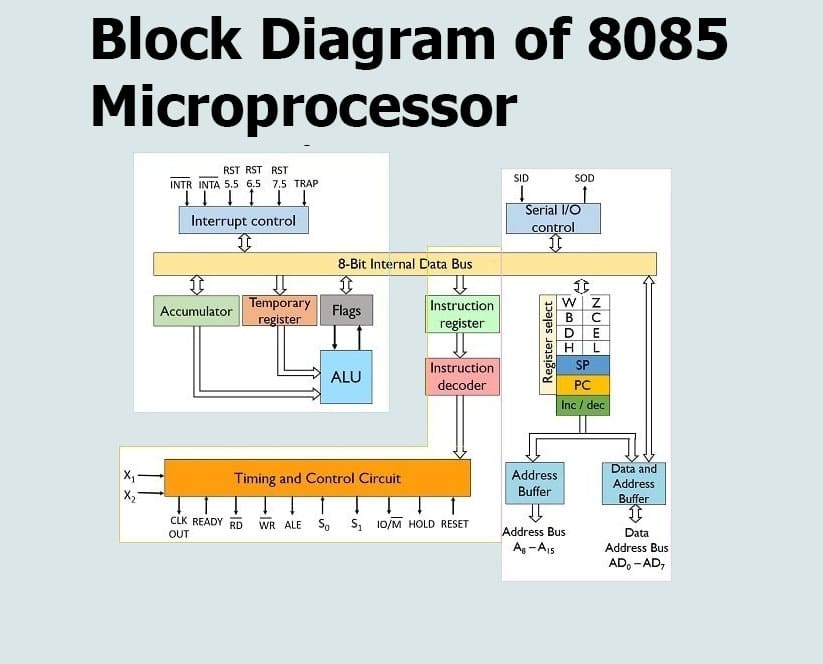
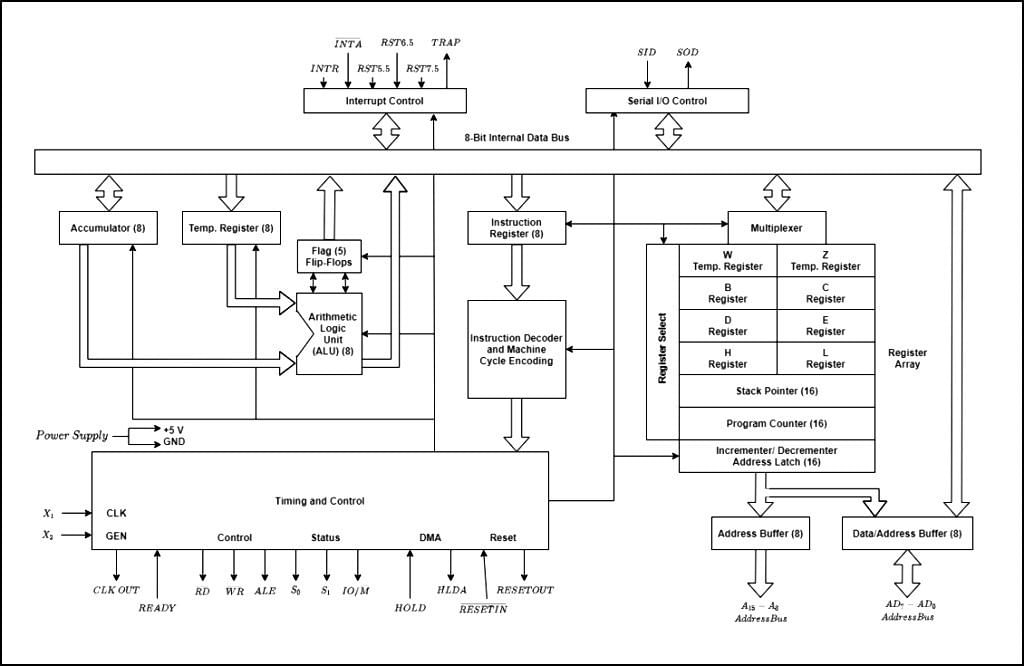
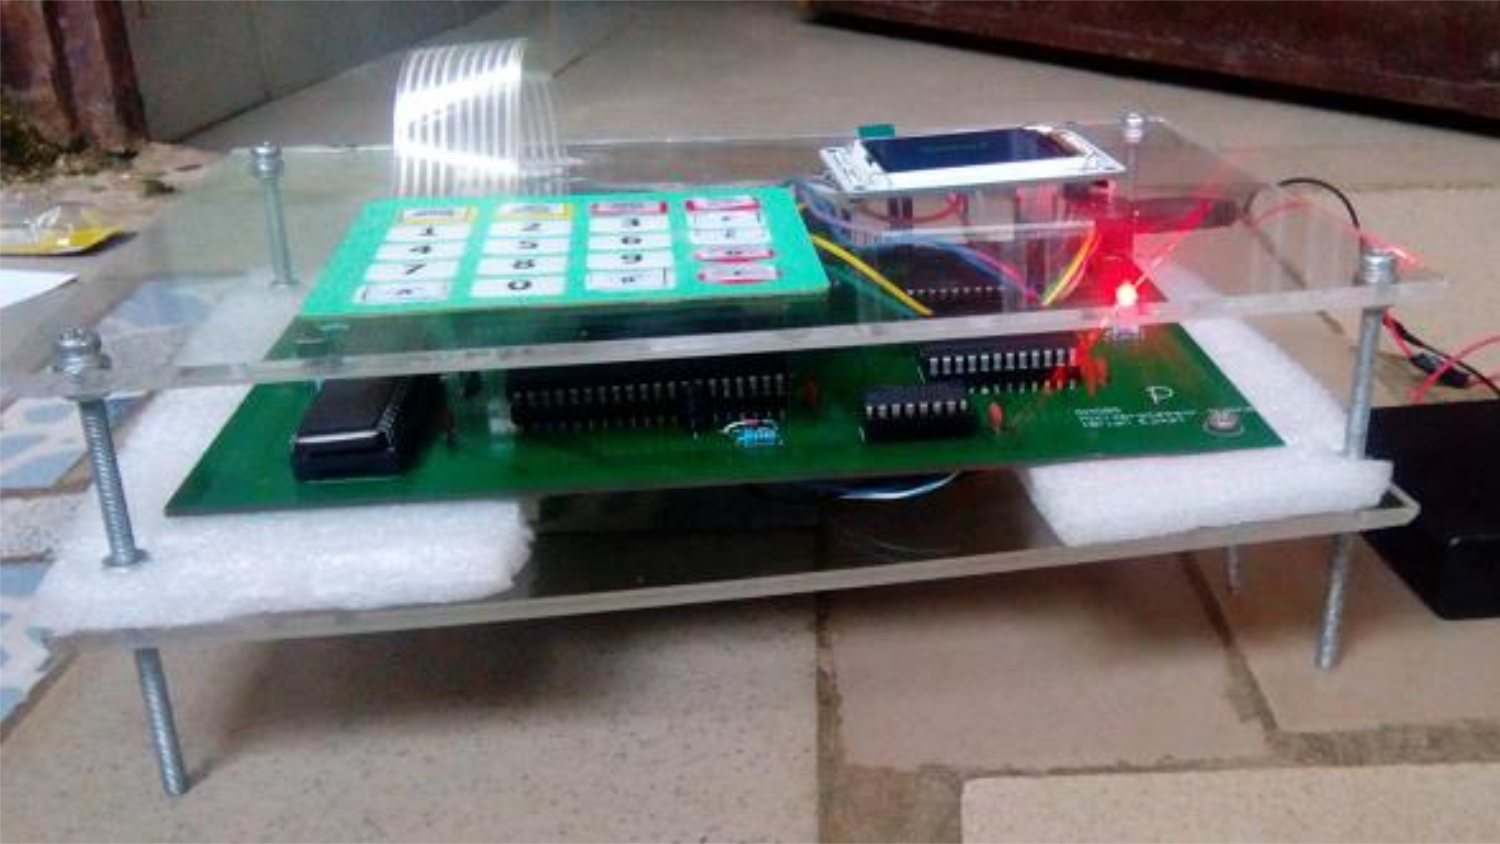
The 8085 is an 8-bit microprocessor from the early 1980s. It runs at 3 MHz, has a 16-bit address bus, and uses a multiplexed address-data bus. That last detail matters more than most students realize because it trips people up on timing during project work. I have built and debugged more 8085 setups than I care to count. The hardware is old, the documentation is scattered, and the learning curve is real. You do not need a fancy kit to get started. A basic 8085 development board with RAM, ROM, and I/O ports is enough for most beginner projects. I picked up a secondhand IPTECH or VMC board on eBay years ago for about thirty dollars. It had some cold solder joints and a cracked crystal socket, but it worked after I reflowed a few joints and replaced the 12 MHz crystal. Those boards are still sold new from Indian electronics suppliers at around eighty to one hundred twenty dollars. For software, you will need an assembler. Macroassembler or EMU8085 are both free and get the job done. I use Macroassembler mostly because it handles relative jumps better than most alternatives. Some people prefer TASM or NASM with 8085 extensions, but the syntax differences add unnecessary friction when you are just trying to verify that ADD B actually increments the accumulator.
Here is what I actually did wrong on my first pass: I tried to interface a 74LS373 latch without accounting for the multiplexed bus timing. The address latch enable signal was arriving too late relative to the data valid window. The result was garbage being latched into my peripheral addresses. The fix was adding a small RC delay on the ALE line and verifying the timing with a logic probe. I spent about four hours on that before I figured it out. You can save yourself that time by reading the 8085 datasheet timing diagrams carefully before wiring anything up.
Practical Project Ideas and Implementation Notes
One of the simplest projects is a digital clock using BCD counters and a 7-segment display driver. The 8085 reads a real-time clock IC like the RTC 8564 or even builds the timing from scratch using delay loops. The delay loop approach is crude but educational. You set up a subroutine that burns cycles through nested loops, then increment seconds, minutes, and hours registers stored in RAM at known addresses. I used memory locations 2000H through 2005H for this. Reading back from those addresses with a monitor program confirmed the values were updating correctly. A stepper motor controller is another straightforward project. You write a lookup table in ROM that cycles through the winding activation sequence. The 8085 outputs one byte at a time to a port address, which drives a ULN2003 array connected to the motor. I ran into an issue where the motor would skip steps at higher speeds because the polling loop overhead was inconsistent. The solution was replacing the polling approach with a fixed-timing subroutine that used the RST 7.5 interrupt to gate step pulses at a regular interval. That stabilized the speed considerably. Temperature monitoring with an ADC0804 is a common intermediate project. You connect the ADC to the 8085 data bus through a 74LS244 buffer because the ADC needs a clean, stable data path. The ADC chip select and read signals come from the 8085's IO/M and RD lines decoded with a 74LS138. I found that grounding the LOCK pin on the ADC0804 and enabling the clock output avoided the need for an external clock generator. The conversion time is about 100 microseconds per sample, which is slow but perfectly adequate for temperature sensing.
Get the Full Details
Common Pitfalls and What Actually Works
Power supply noise is a real problem on these boards. The 8085 draws current spikes during instruction execution, especially on OUT and IN instructions that access external I/O. I measured up to 200 mA transients on a bare board with no decoupling capacitors. Adding a 100 nF ceramic capacitor near every VCC pin on each IC and a 10 microfarad tantalum capacitor near the 8085's power pins dropped the noise from about 150 mV peak-to-peak to under 20 mV. The processor stopped resetting sporadically after that change. Another issue people overlook is the behavior of the HOLD and HLDA pins. When an external DMA controller asserts HOLD, the 8085 tri-states its buses after completing the current machine cycle. If your design does not account for this, you will see data corruption on the bus lines. I once had a project where a relay driver circuit was feeding back noise into the HOLD pin through the PCB ground plane. The processor would freeze unpredictably. Adding a small signal diode between HOLD and ground and increasing the ground plane clearance fixed it. The SI/DI pins for serial communication are simple to use but limited. The SI pin receives serial data on the falling edge of the SIO signal. You can set up a character receive routine in about twenty lines of assembly. However, the 8085 serial interface has no hardware flow control and no baud rate generator built in. You need an external UART like the 8251 or an external RC network for bit timing if you are doing simple asynchronous communication. This limitation means the 8085 is not suitable for high-speed serial projects. If you need RS-232 at more than 9600 baud, move to an 8051 or a modern microcontroller.
Assembly Code Structure That Actually Works
When writing assembly for these projects, organize your code around memory-mapped I/O rather than relying heavily on IN and OUT instructions. The 8085 uses separate address spaces for I/O and memory, but in practice most student projects map peripherals to memory addresses anyway. This avoids the 10-bit I/O address limit and gives you more address space to work with. I typically reserve 2000H to 2FFFH for RAM, 3000H to 37FFH for I/O mapped peripherals, and F000H to FFFFH for ROM monitoring code. Using the RIM and SIM instructions for interrupt handling is more powerful than most textbooks suggest. The RIM instruction reads the state of all three hardware interrupts (RST 7.5, RST 6.5, RST 5.5) and the serial receive flag in a single operation. I used this in a project where I needed to detect which interrupt had fired without using separate flag variables. The SIM instruction lets you enable or disable individual interrupts and set the serial output bit, which is useful for toggling LED indicators directly from interrupt service routines. The main drawback of working with 8085 projects today is the lack of good simulation tools. Simulators like EMU8085 are functional but dated and occasionally produce incorrect results on edge cases like rotated instructions or flag behavior after certain arithmetic operations. I verified critical routines by downloading the code onto actual hardware rather than trusting the simulator output entirely. Physical debugging with a logic analyzer or even a cheap oscilloscope is faster in the long run than chasing simulator bugs.
If you want resource material, the Intel 8085 Microprocessor and Interfacing book by D.P. Vasudeva is still the standard reference. The assembly programming guide by Gaonkar is also solid. For schematic references and project code, the website 8085microprocessor.com has a collection of projects with working code. I downloaded several of those programs and used them as starting points rather than writing everything from scratch. The 8085 is not efficient by modern standards. It has only twelve instructions that directly manipulate flags, no hardware multiplier, and a maximum instruction cycle time of ten machine cycles for certain multiply-heavy operations. A simple signed multiplication routine can take over two hundred microseconds to execute. For academic purposes and learning microprocessor fundamentals, it is still useful. For anything that requires real-time performance or complex I/O handling, an 8051, ARM Cortex-M0, or ESP32 will do the same work faster and with less hardware clutter. The board-level debugging experience is genuinely valuable though. Troubleshooting a faulty address decode circuit or figuring out why a register pair is loading incorrect values teaches you more about how microprocessors actually work than any simulator can show you. I would recommend spending at least a few weekends with physical hardware before relying entirely on emulation software.