Where People Actually Get Stuck
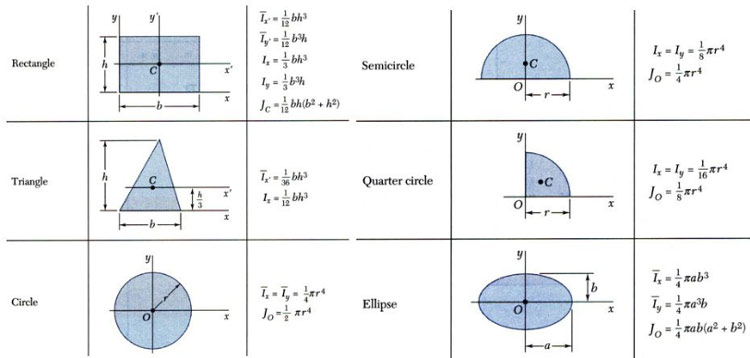
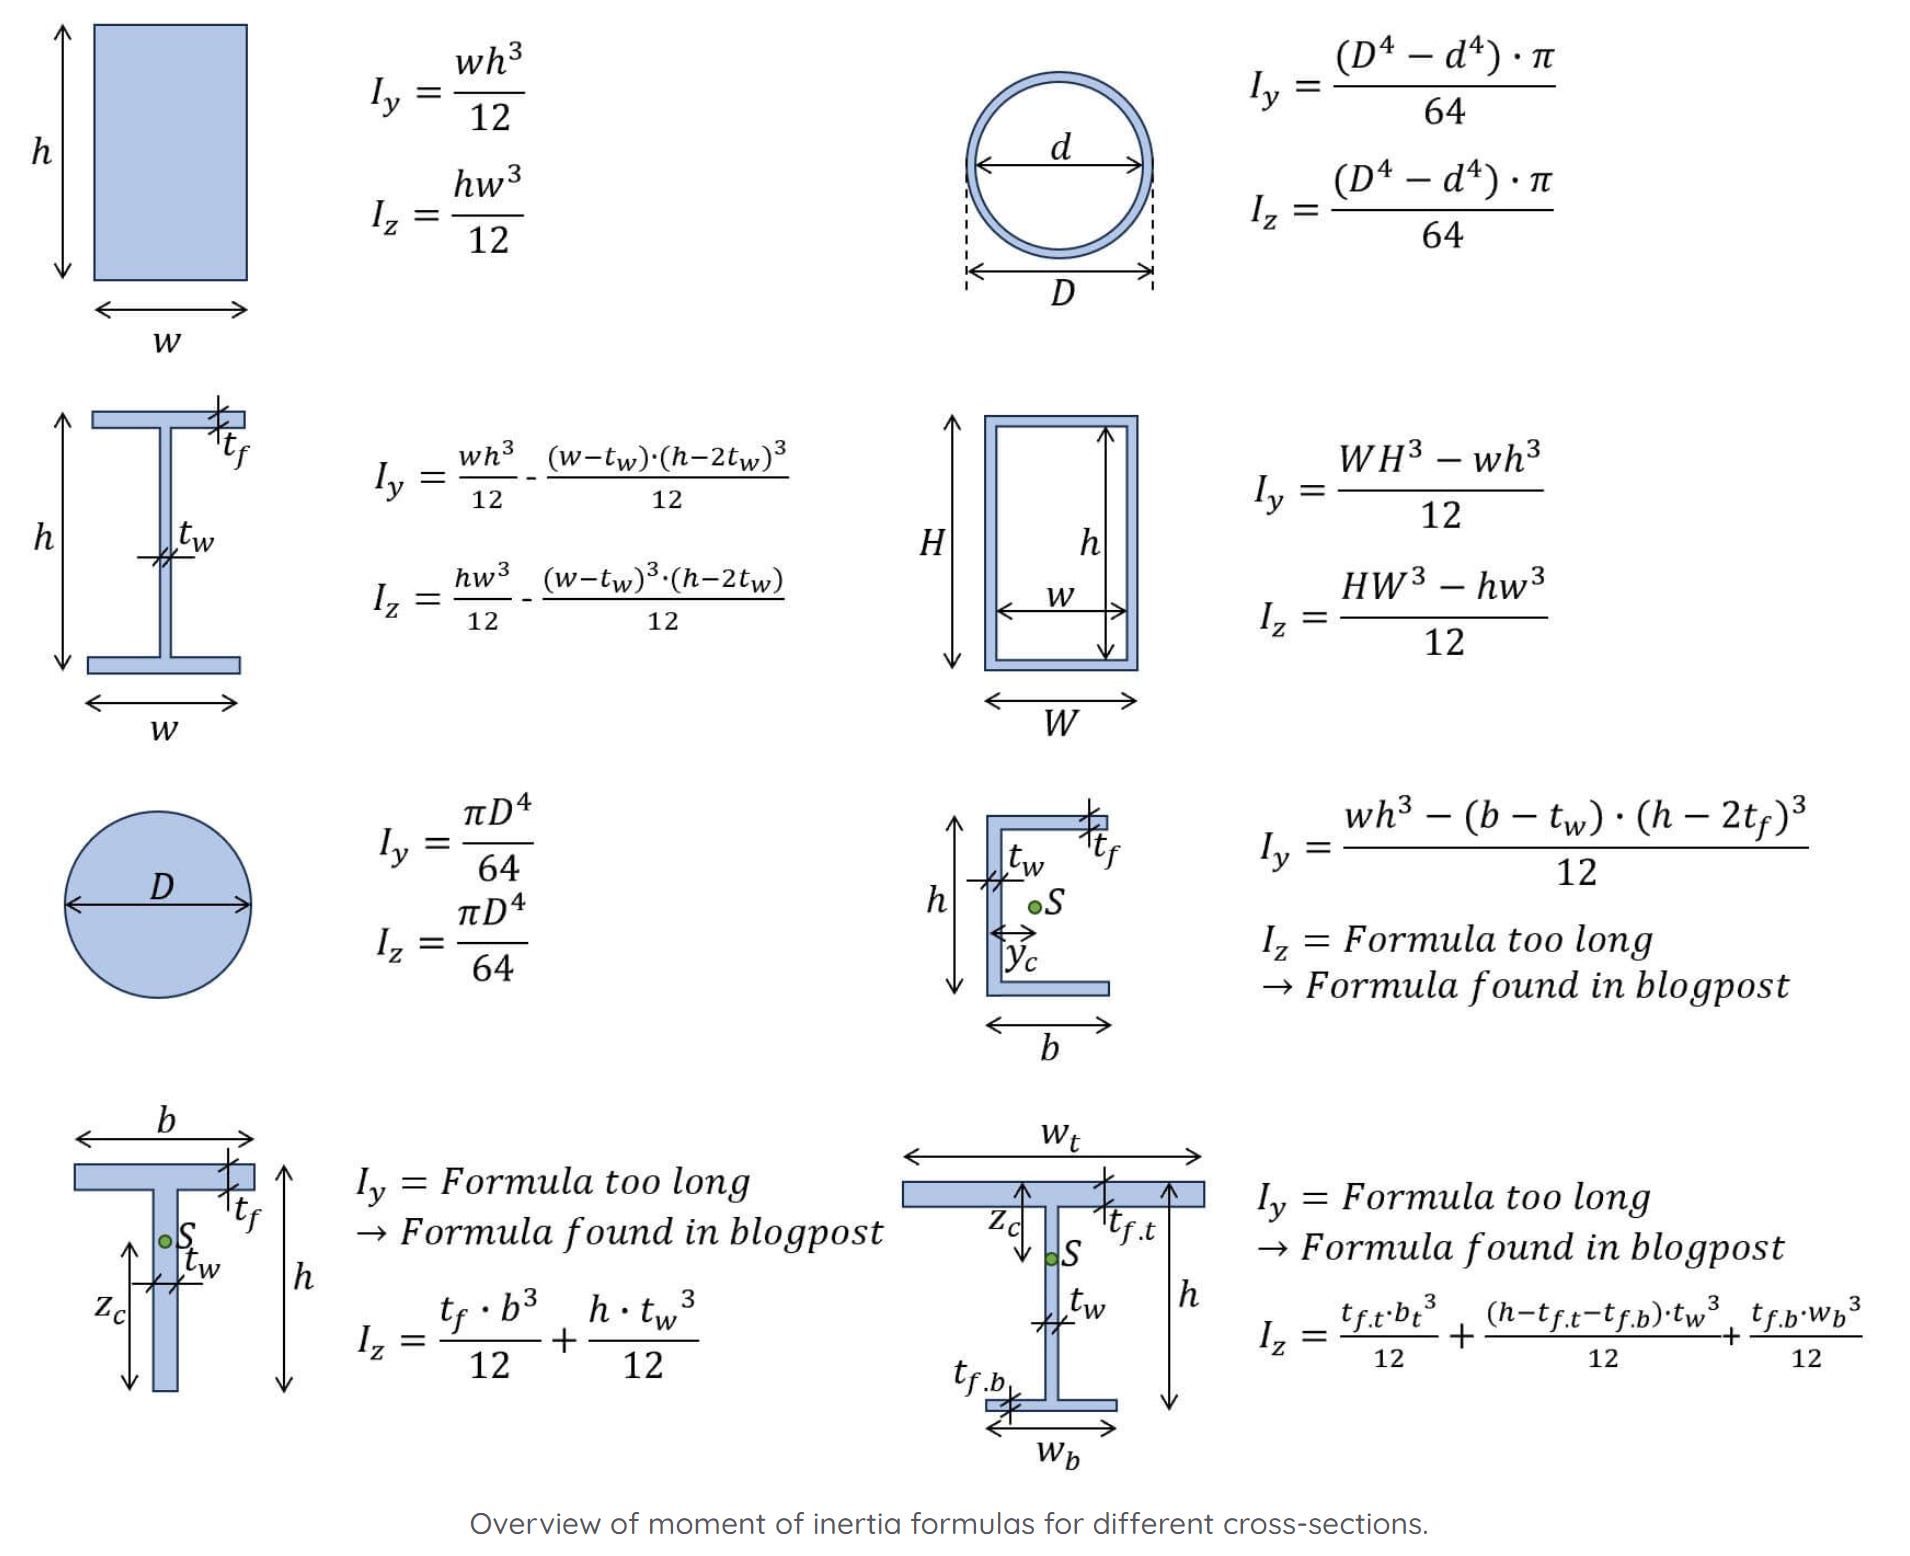
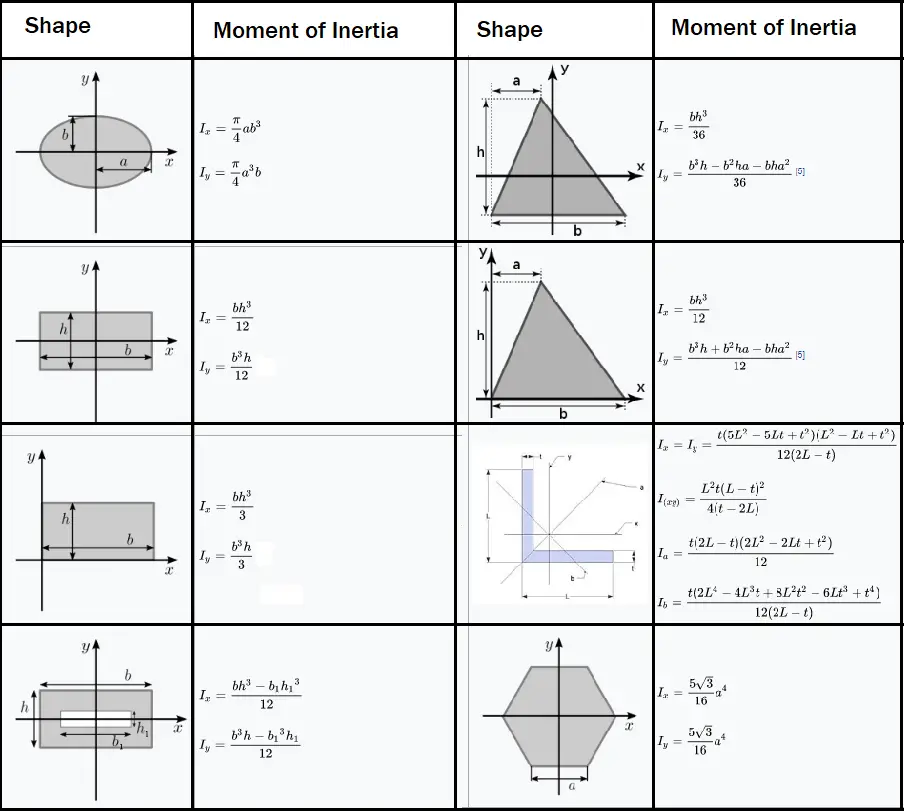
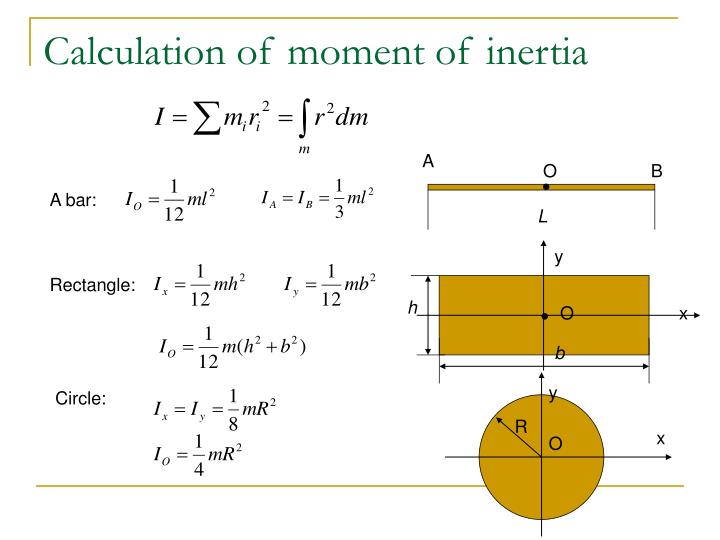
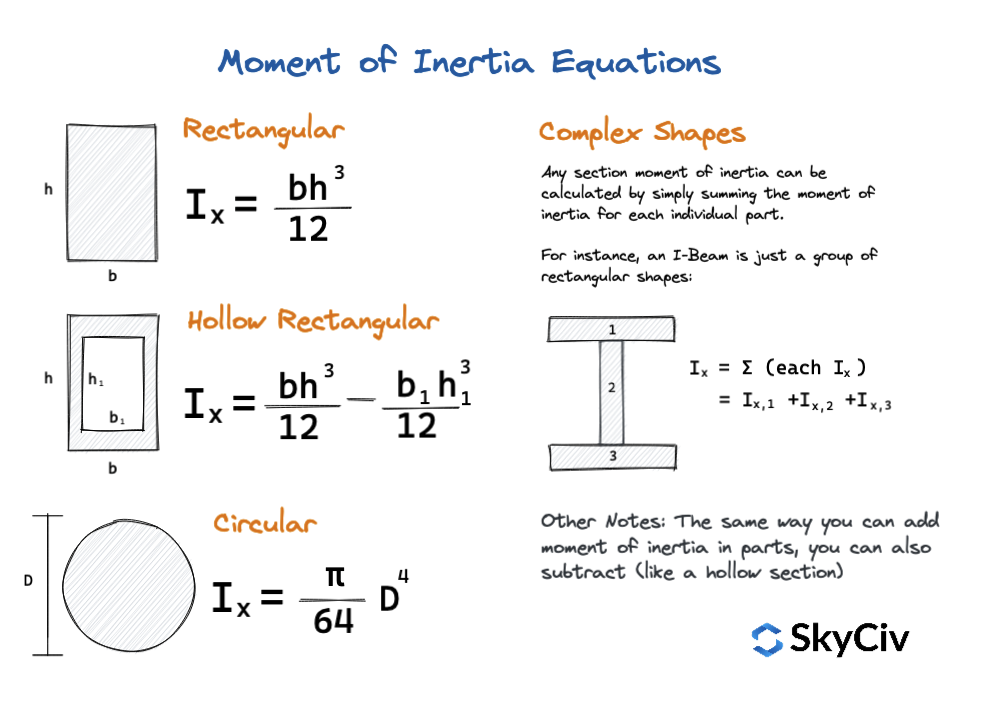
The parallel axis theorem is the tool you reach for first, and it works for exactly two things: moving a known moment of inertia to a parallel axis, and combining separate rigid bodies about the same axis. It fails immediately if your axis isn't parallel to the one your formula references, which is the mistake I keep seeing in forum posts from people who haven't yet calculated their own project. I started with the standard tables. Solid cylinder about its central axis is ½mr². Rectangular plate about its center is ma² for rotation about one edge, or ¹⁄m(a²+b²) about the centroid. You memorize enough of these and most problems become subtraction and addition. The shape isn't in your table? Find a simpler shape it came from and subtract the part you removed. I used this method on a custom flywheel once—a steel disc with four bolt holes and a keyway milled out. The bolt holes are just small cylinders. The keyway is more fiddly but close enough is a rectangular slot cut through the thickness. You calculate each feature's moment of inertia about the main axis using the parallel axis theorem, then subtract them from the solid disc value. One person online was getting 12% error on this exact configuration because they forgot to apply the parallel axis shift for the bolt holes. They just subtracted the hole values as if they were centered on the main axis. That's not how the theorem works. I should say something about units, because this trips people up constantly. Kilogram meters squared in SI. Pound-foot-second squared in imperial. If you're working with a CAD model that outputs mass in grams and dimensions in millimeters, your moment of inertia comes out in gram-millimeter squared. Divide by 10 to get kg·m². I've watched good engineers skip this step and end up with results off by a factor of a million, which is hard to notice if you're not double-checking against a known baseline.
There's a thing people miss about composite bodies. When you add parts together, every part's mass has to be shifted to the common reference axis using the parallel axis theorem before you sum them. I worked on a rotor assembly last year where someone added the moments of a hub, a rim, and six spokes without shifting anything. The spokes were modeled as point masses at their centroid distances, which is fine for approximation, but they're actually distributed along their length. The correct approach is to treat each spoke as a thin rod and use I = ml² about its own centroid, then shift it by the parallel axis theorem to the rotor center. For a 200-gram spoke 150 millimeters long mounted at a mean radius of 80 millimeters, the difference between the two approaches was about 4%, which sounded small until it caused a vibration issue at operating speed. Thin-walled assumptions are another place where people introduce errors without noticing. If your wall thickness is less than 10% of the radius, treating a hollow cylinder as a thin ring with I = mr² is acceptable for preliminary work. Beyond that, use I = ½m(R² + R²) where R and R are the inner and outer radii. I once saw a calculation where someone applied the thin-ring formula to a disk with a 40% thickness-to-radius ratio and the error was 18%. That's not a rounding issue, that's a formula misuse issue. Triaxial considerations come up when your part isn't symmetric. A generic 3D printed bracket doesn't have a single moment of inertia, it has three principal values and potentially products of inertia too. For most engineering work you only need the relevant axis, but if your assembly spins and you're balancing it, you need the full inertia tensor. CAD packages will give you this out of the box now. SolidWorks, Fusion, Onshape—all of them compute the tensor directly from the geometry. The question is whether you trust the result. I trust it for simple solids. For something with fillets, shells, and variable thickness, I cross-check with a manual calculation on a simplified version to make sure the numbers are in the right ballpark.
There's also the issue of material density variation. The formulas assume uniform density. If your part is made from a casting with porosity, or a composite with uneven fiber distribution, the actual moment of inertia will differ from the calculated value. I had a client who machined a titanium component and the theoretical calculation said one thing and the test rig measured something noticeably different. We ended up finding a density variation in the stock material. The fix wasn't better math, it was weighing the actual part and back-calculating the effective density from the measured mass versus the geometric volume. Dynamic problems introduce another layer. If you're dealing with a mechanism where parts move relative to each other, like a linkage or a deploying solar array, the moment of inertia changes during motion. You can't just calculate it once and move on. I've seen this handled in two ways: either you set up a function that recomputes the inertia at each time step, or you find an equivalent constant value that gives acceptable accuracy across the range of motion. The first approach is more accurate but requires more computational effort. The second is usually fine for control system design where you don't need exact trajectories, just stable behavior. A few hard limitations. The parallel axis theorem only works for parallel axes. If you need to rotate your axis to a different orientation, you need the full inertia tensor transformation, not just a simple shift. Composite body methods assume rigid connections between parts. If there's any flex or play in the joints, the calculated value won't match reality. And all of this assumes you know the mass and geometry precisely. If your part is a rough prototype with dimensional tolerances, your moment of inertia has the same tolerance propagation. A 2% dimensional uncertainty can easily produce a 4-5% uncertainty in the final result for complex shapes.
Get the Full Details
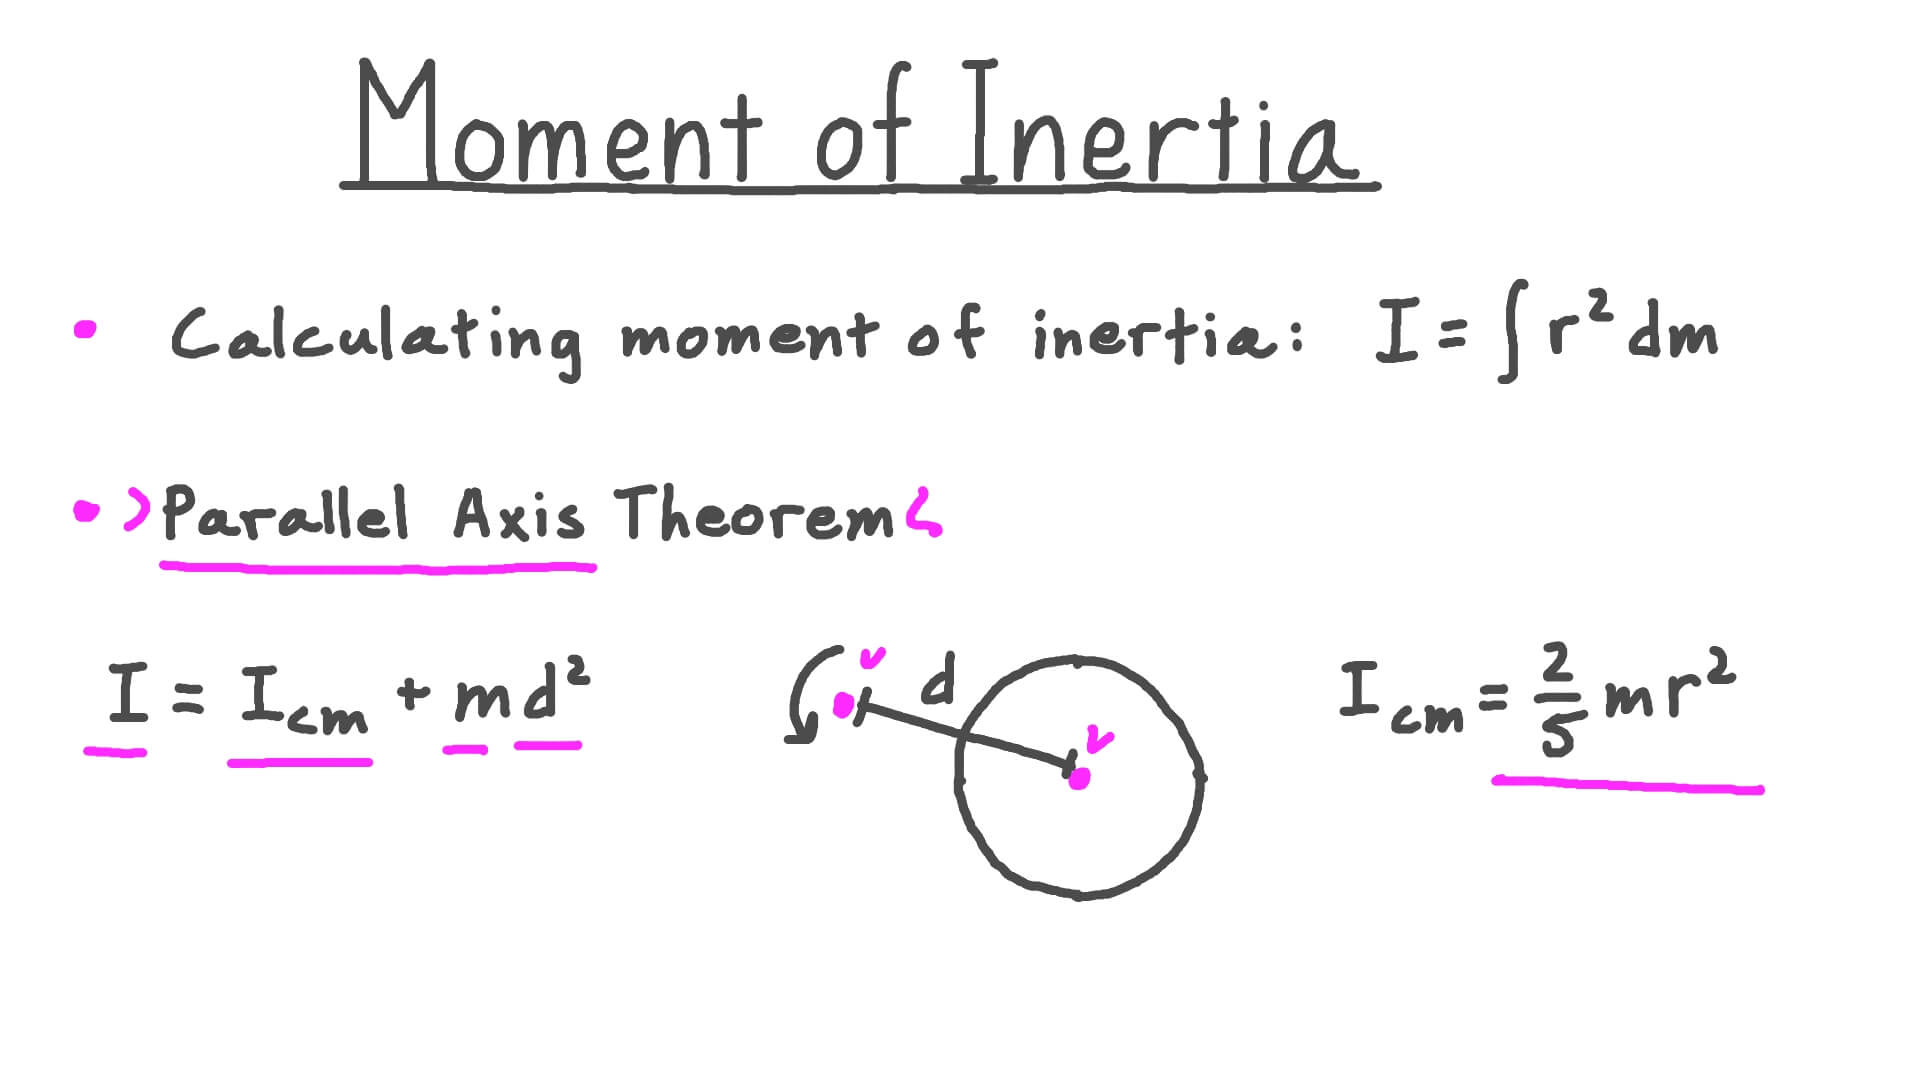
When the geometry gets complicated enough that manual calculation becomes impractical, numerical methods take over. Finite element tools can compute the inertia tensor directly from a mesh. The trick is making sure the mesh is fine enough in regions far from the axis of interest, since those regions contribute disproportionately to the moment of inertia. A coarse mesh near the outer edges of a large disc can under-predict the value significantly. I usually run a mesh convergence check: refine the mesh until the inertia value stops changing by more than my acceptable threshold, which is typically 0.5% for production work.