What You Actually Need to Know About Cylinder Inertia Calculations
Most people learn I = (1/2)MR² and move on. That formula is correct for a solid cylinder rotating about its central axis, assuming uniform density. In practice, that assumption rarely holds. I spent three years debugging rotational vibration issues in industrial machinery before I stopped treating inertia as a simple textbook problem. The real world has thick-walled cylinders, composite materials, off-center bores, and temperature-dependent density changes. The simple formula breaks down fast once any of those variables enter the picture. I used to see engineers waste half a day trying to match simulation results to physical tests because they used the wrong moment of inertia equation for a hollow shaft with uneven wall thickness.
Moment Of Inertia Cylinder Calculations That Actually Work
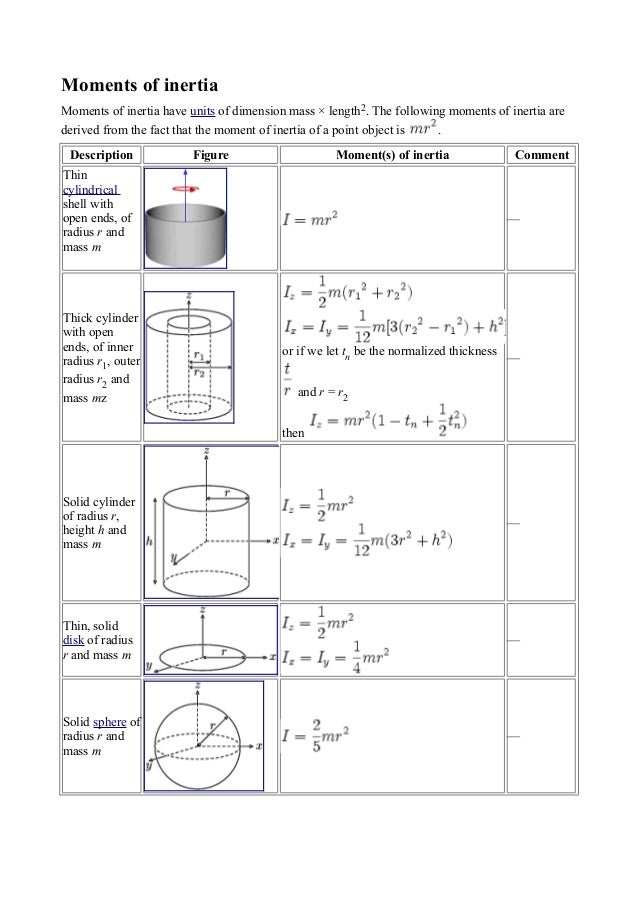
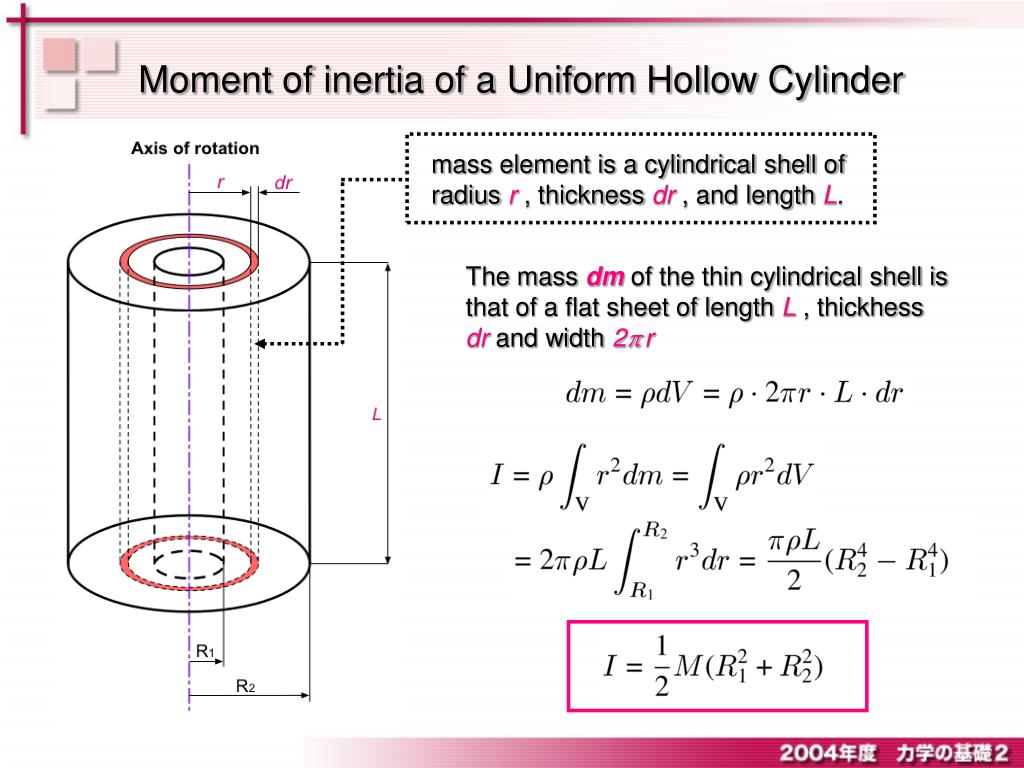
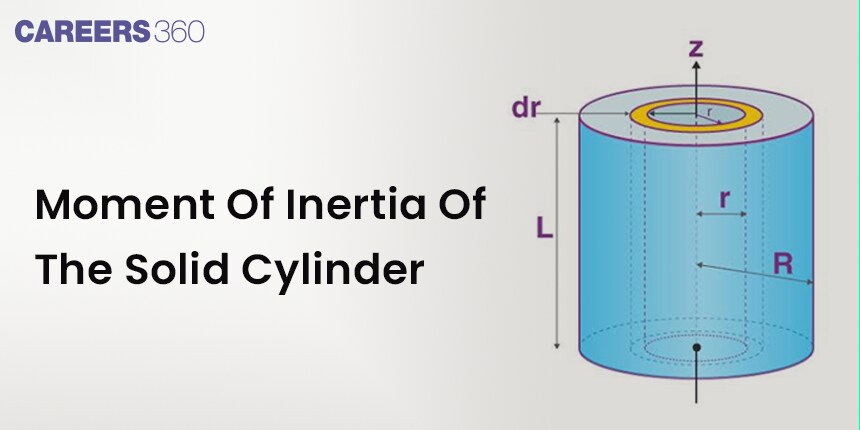
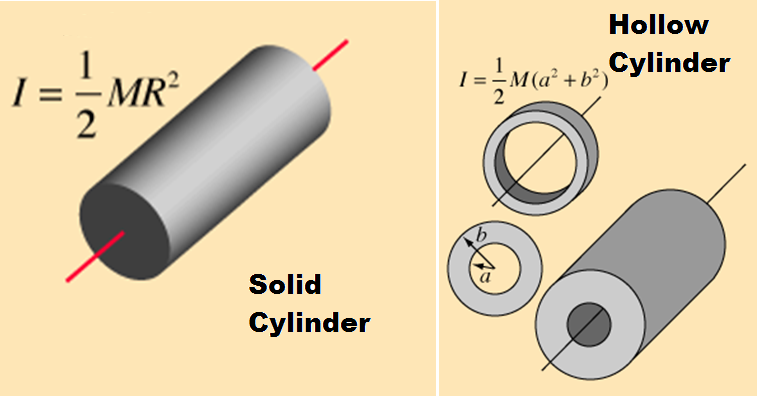
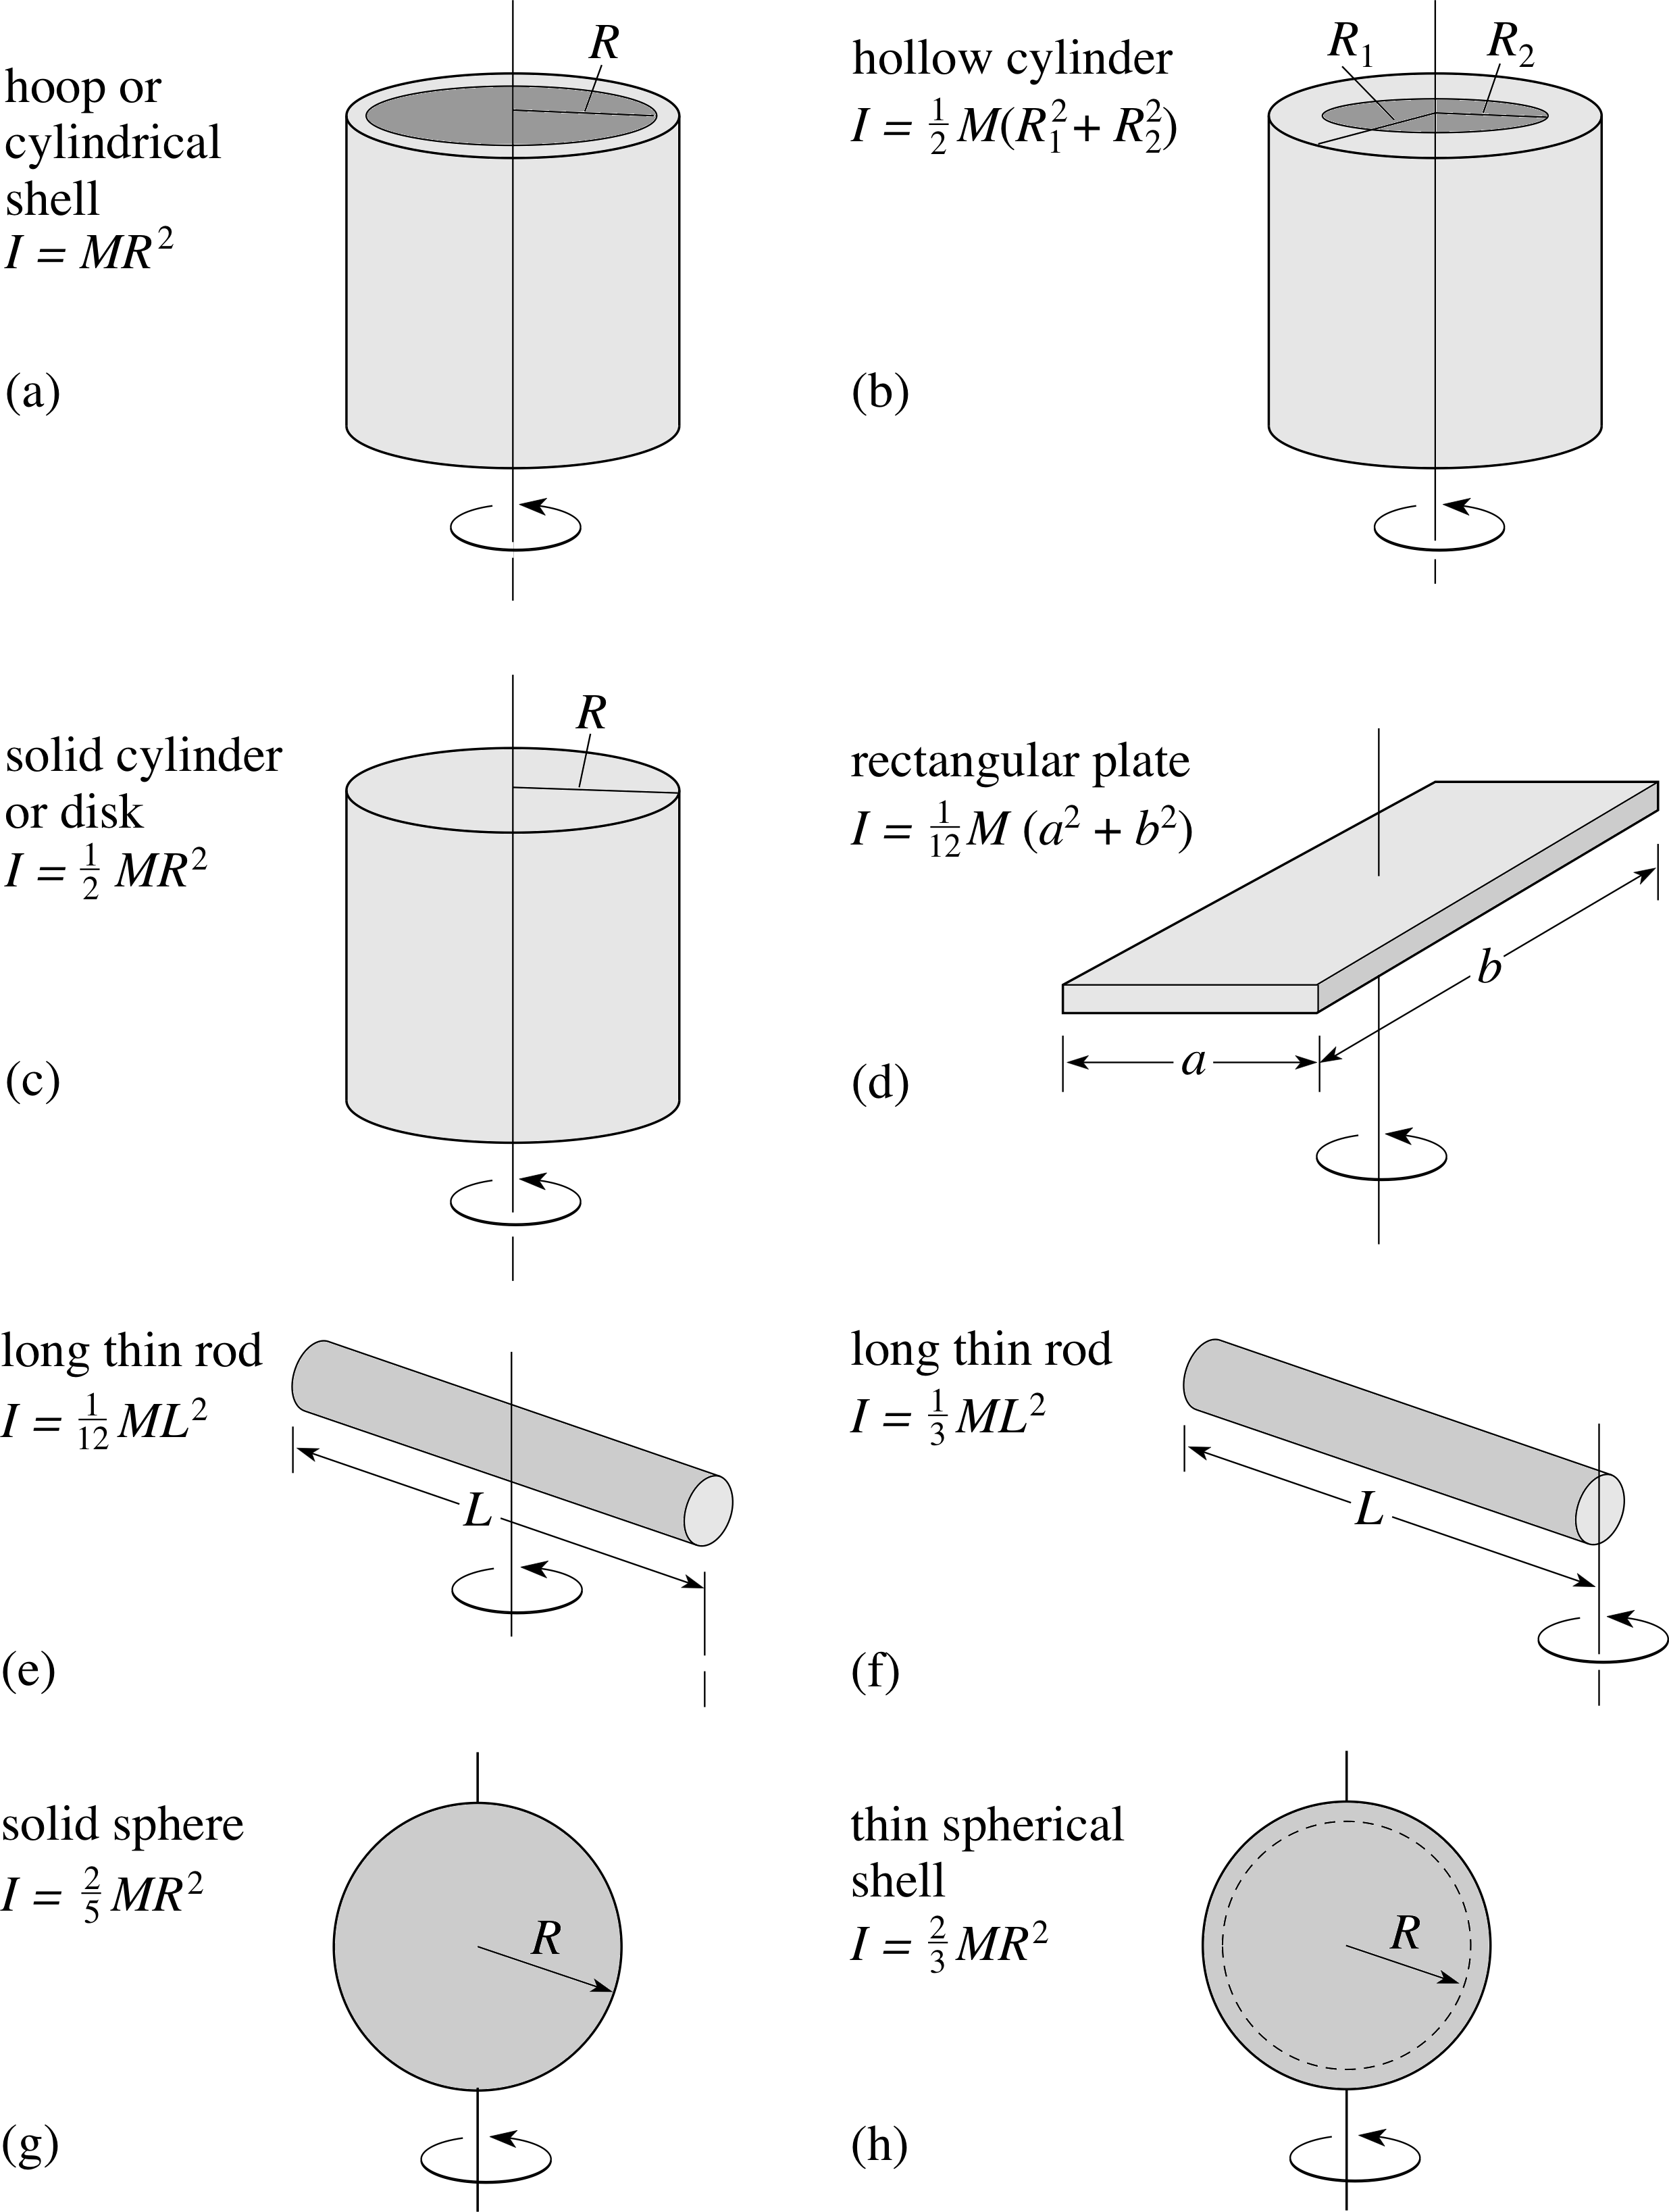
Start by defining the geometry precisely. A solid cylinder: I = (1/2)MR². A hollow cylinder (thick-walled tube): I = (1/2)M(R² + R²), where R is the inner radius and R is the outer radius. These are the two formulas you will use ninety percent of the time. Everything else is a modification of one of these. When you have a cylinder rotating about an axis that is not its central symmetry axis, you need the parallel axis theorem. I = I_cm + Md². That d is the perpendicular distance from the center of mass axis to your new rotation axis. Forgetting this is the most common error I see. People plug numbers into the basic formula without checking whether the rotation axis actually matches the formula's assumption. Density matters more than most people realize. If you are working with a forged steel cylinder versus a cast iron one of identical dimensions, the mass difference alone changes the inertia by roughly fifteen to twenty percent. I learned this the hard way when a client sent me drawings specifying only diameter and length for a flywheel application. They assumed I would know the material. I did not. The difference between the estimated and actual inertia caused a resonance issue that took us six weeks to track down. Now I always confirm material specification before running any calculation.
For non-uniform density distributions, you integrate. I = r² dm. If density varies radially, you express dm as (r)·2rL·dr and integrate from the inner to outer radius. This comes up frequently with functionally graded materials or cylinders that have been heat-treated unevenly. I had a case where a cylinder had a hardened outer shell with a softer core, creating a density gradient that shifted the effective inertia by about eight percent compared to a uniform material assumption. Standard formulas gave us wrong motor sizing, which meant we undersized the drive by roughly twelve percent torque margin.
Get the Full Details

Practical Calculation Workflow
Here is how I approach it now. First, get the exact dimensions including any bore, keyway, or mounting hole locations. Second, confirm the material and its density at operating temperature. Third, determine the actual axis of rotation and verify whether it is a principal axis. Fourth, choose the appropriate formula or set up the integral. Fifth, double-check by comparing against a CAD inertia property report if you have access to one. CAD software like SolidWorks or Fusion 360 will compute moments of inertia automatically for any geometry. The catch is that these tools assume uniform material density unless you assign a custom material. I have caught errors where a designer forgot to update the material library after switching from aluminum to steel, producing an inertia value that was roughly three times too low. The simulation looked fine. The physical system did not. For quick hand calculations, keep a reference table of standard shapes. Cylinder about central axis: (1/2)MR². Cylinder about a diametrical axis through the center: (1/4)MR² + (1/12)ML². The second one surprises people. The length term becomes significant for long thin cylinders. I once saw someone use the central axis formula for a rotor mounted on a pivot at its midpoint, which is completely wrong. The correct formula for that geometry includes the L² term, and for a slender rotor the length contribution can dominate the radial contribution.
Common Pitfalls and How to Avoid Them
Using diameter instead of radius is probably the single most frequent mistake. The formula requires radius. If you measure diameter and divide by two before plugging into the equation, you will get the right answer. If you plug diameter directly in, your inertia value will be four times too large. I do not know how many times I have seen this in emails from people who were frustrated that their calculations did not match test data. Another issue is confusing mass with weight. The inertia formulas use mass in kilograms, not weight in newtons or pounds-force. If you are working with a scale that reads in force units, divide by 9.81 to get mass. Working in imperial units adds another layer of confusion because pound-mass and pound-force are often used interchangeably in sloppy documentation. I stick to SI units whenever possible and convert at the end. It saves me from that particular headache. Temperature effects are usually ignored until something fails. Metals expand when hot, which increases the radius and therefore the inertia. For a steel flywheel running at elevated temperature, the radius increase might be small, but the density decrease compensates partially. The net effect is usually under one percent for most engineering metals in normal operating ranges. However, for precision applications like gyroscopic instruments or satellite reaction wheels, even that small change matters. I worked on a project where thermal inertia drift caused pointing errors in a deployment mechanism, and the fix involved active thermal management rather than just redesigning the structure.
When Formulas Are Not Enough
Sometimes you need experimental validation. The simplest method is a torsional pendulum test. Suspend the cylinder from a wire, twist it, and measure the oscillation period. The period relates directly to the moment of inertia through the wire's torsional stiffness. This is how I verify inertia values for custom components before they go into production. It takes about twenty minutes per part and catches errors that spreadsheet calculations miss, like unexpected mass distribution from machining operations or assembly tolerances. If you need inertia tensor data for a full 3D analysis, single-axis formulas will not cut it. You need the complete inertia tensor with all six independent components. Most CAD packages output this directly. The off-diagonal terms, called products of inertia, are zero when your coordinate axes align with the principal axes of the part. If they do not align, you get coupling terms that complicate the dynamics significantly. I have seen this cause instability in robotic arm simulations because someone modeled the links with misaligned coordinate frames and ignored the product of inertia terms. There is also the trifilar suspension method for flat or disk-shaped cylinders. Hang the object from three equally spaced wires and measure the oscillation period. The formula is more involved but gives you the polar moment of inertia directly. It is less common than the torsional pendulum but useful when your cylinder is too short or too wide for a simple wire suspension setup.
A Note on What This Approach Cannot Do
Hand calculations and standard formulas assume rigid bodies. If your cylinder is flexible, thin-walled, or made of a compliant material, the mass distribution shifts under rotation due to centrifugal forces. This is called elastic deformation and it changes the effective moment of inertia during operation. For high-speed rotors above certain thresholds, this effect is real and measurable. I encountered it with a carbon fiber composite cylinder spinning at fifteen thousand RPM. The calculated inertia based on the cold, unstrained geometry was about four percent lower than the effective inertia at operating speed. The motor controller was tuned to the static value, and we saw performance degradation at speed that we could not explain without accounting for the deformation. Another limitation is that all standard formulas assume the cylinder is homogeneous and isotropic. Composite cylinders, laminated structures, and additively manufactured parts with internal porosity or varying infill density do not fit this model. In those cases, you either segment the geometry into homogeneous sub-regions and sum their contributions, or you rely on CAD-based numerical integration with assigned material properties for each region. Neither approach is particularly fast, but they are necessary when accuracy matters. If you need a downloadable reference, most engineering handbooks like Shigley's Mechanical Engineering Design or the Meriam and Kraige Statics and Dynamics texts have tables of moments of inertia for standard shapes. Online, the HyperPhysics page at Georgia State University has a clean table with derivations. For practical work, I keep a one-page cheat sheet with the formulas I use most often, including the parallel axis theorem applications and the principal axis conditions. Laminating it and keeping it at my workstation has saved me more time than I can count.