Getting The Number Right
When I first started running finite element models for rotating machinery, I kept getting weird torque responses. The simulation would predict a gear shaft failing at 300 Nm when a hand calculation showed it should hold 800 Nm. Turns out, half the team didn't know which moment of inertia formulation they were feeding into the solver. The other half were mixing units without catching it. This happens more often than you'd think. The Moment Of Inertia Equation isn't one single thing. It's a family of related formulas, and using the wrong one quietly gives you wrong answers. Let me walk through what actually matters in practice, not just the textbook version.
What The Moment Of Inertia Equation Actually Is
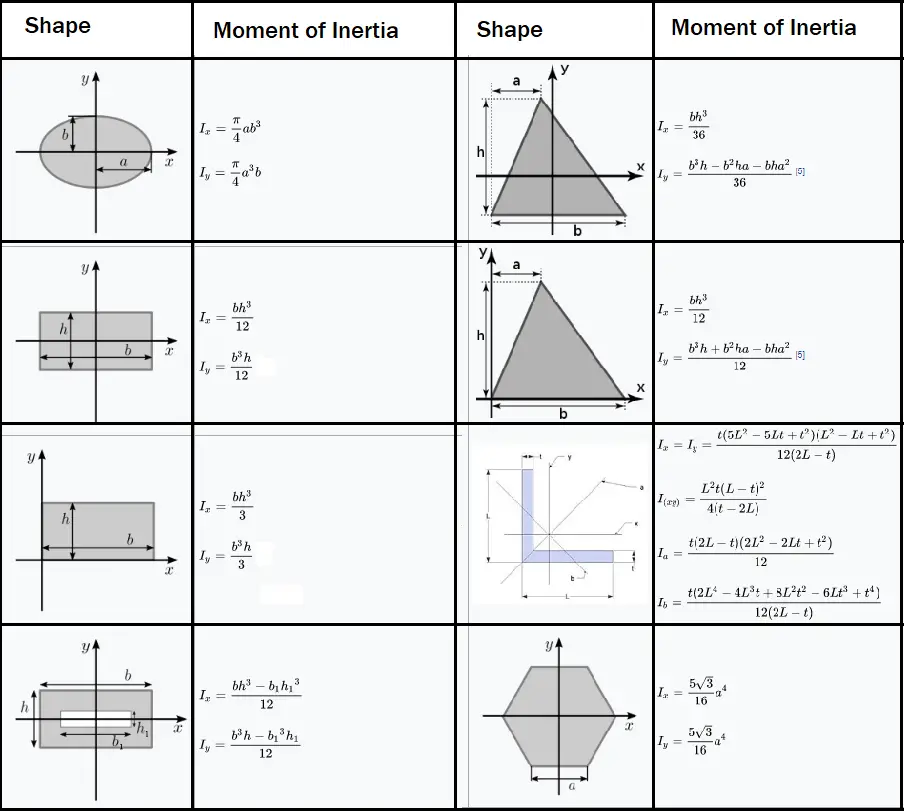
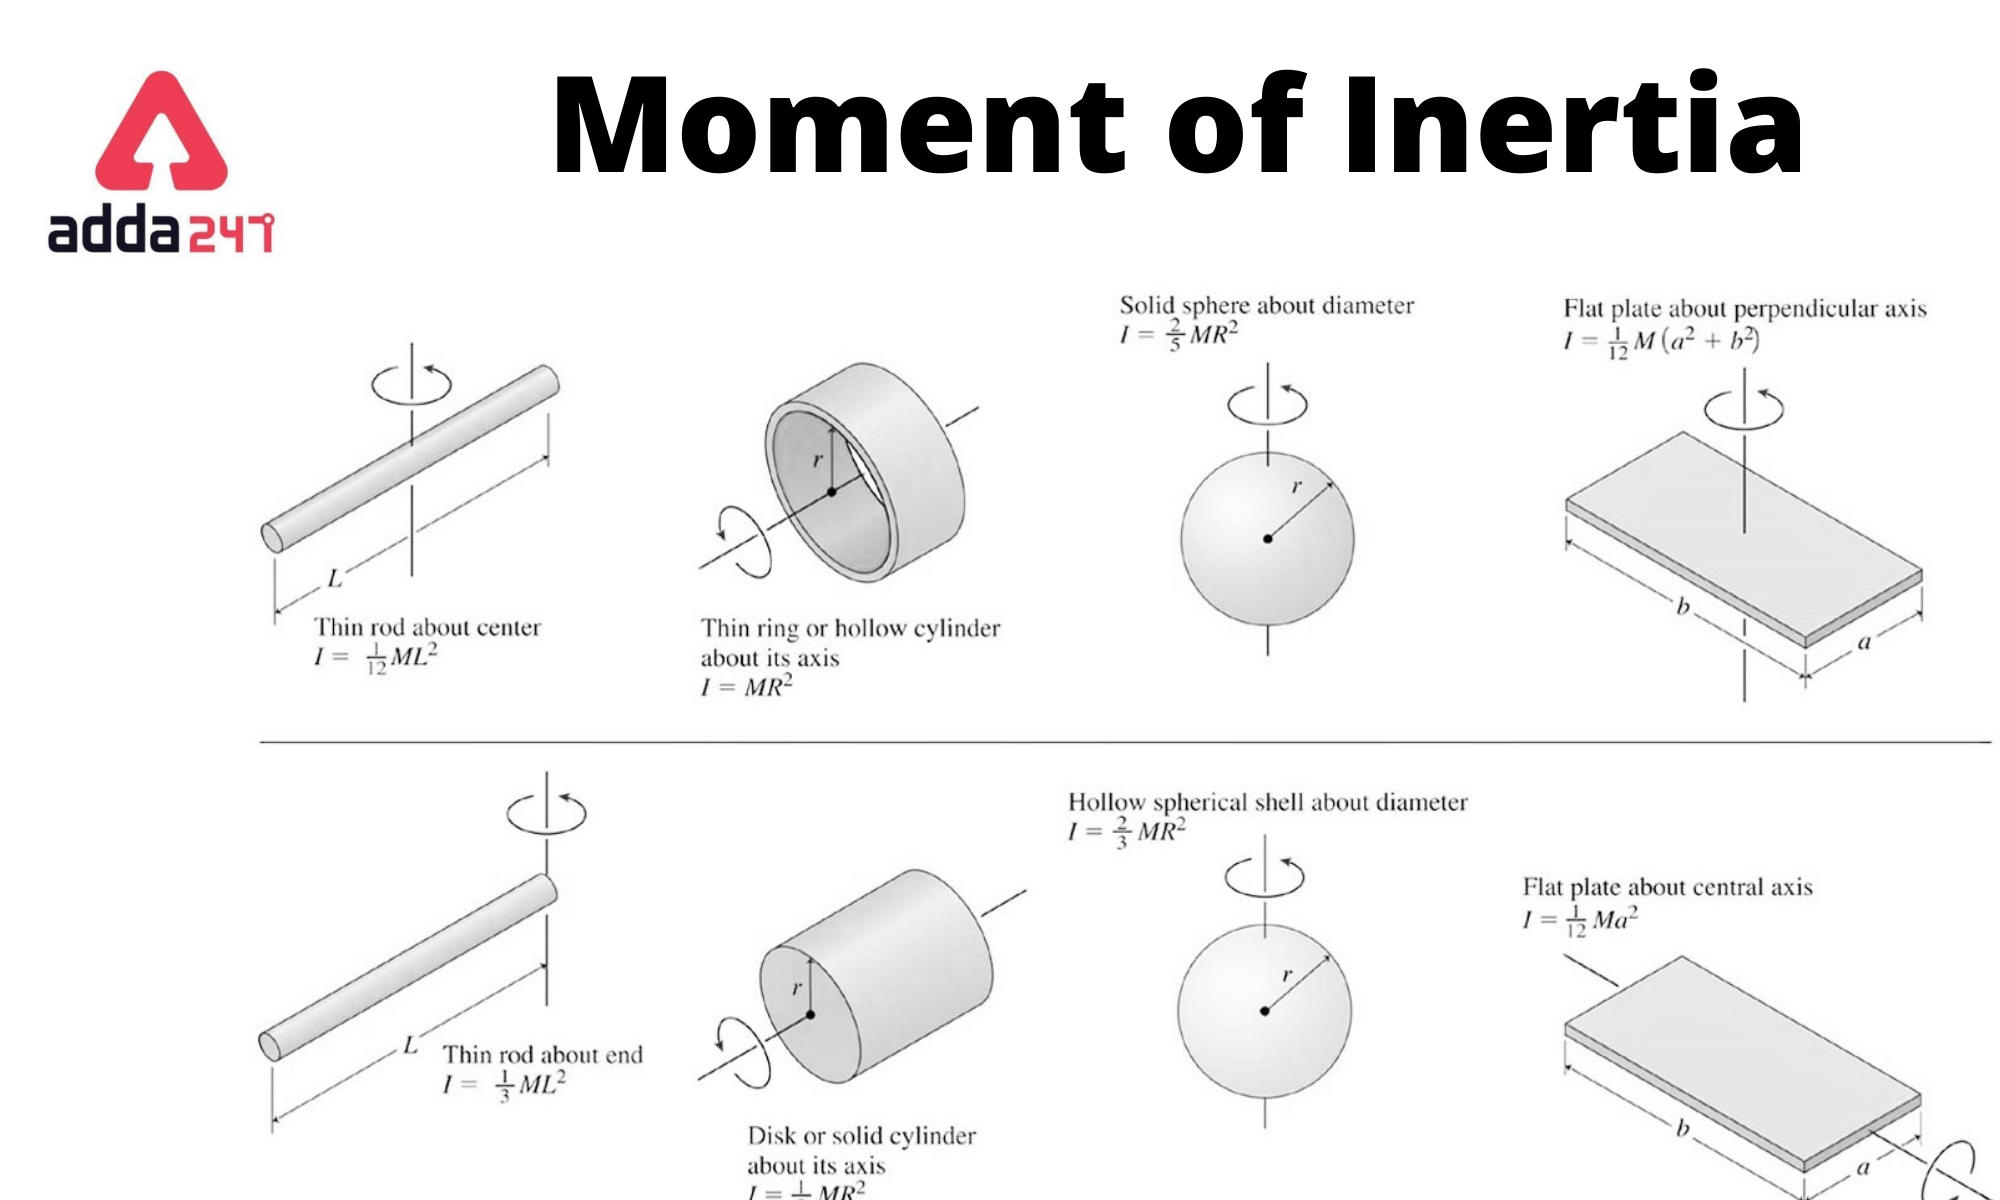
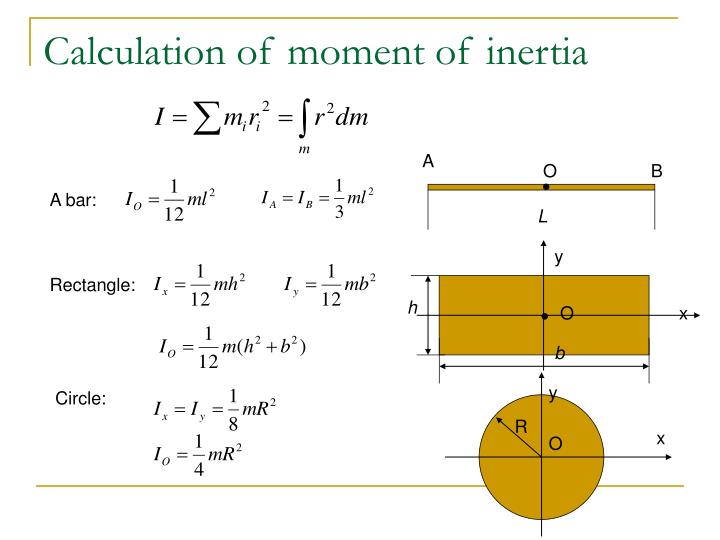
At its core, the equation measures how difficult it is to change rotational speed for a given shape and mass distribution. For a point mass, it is I equals m times r squared. That is the simplest form. For real objects, you integrate over the entire volume because mass isn't all sitting at one radius. The parallel axis theorem lets you shift that calculation when the rotation point isn't the center of mass. That theorem alone saved me weeks on a flywheel design project where the bearing offset was two centimeters and the hand calculations didn't match the FEA results by a factor of three. The standard equation for a solid cylinder rotating about its central axis is one-half m r squared. A hollow cylinder is one-half m times r1 squared plus r2 squared. A sphere is two-fifths m r squared. These are the ones you will use constantly. The ones you won't use often but need when you need them include thin rods about their center, which is one-twelfth m l squared, and about their end, which is one-third m l squared.
How I Actually Calculate It For Real Parts
I stopped doing integrals by hand years ago. The practical workflow looks like this: define the geometry in CAD, assign material density, extract the mass properties from the software, and verify with a quick hand calculation on a simplified shape. Most engineering packages give you the mass moments of inertia directly. SolidWorks, Fusion 360, Onshape, they all output Ixx, Iyy, and Izz along with the principal axes. The catch is that these are only as good as the material assignment and the body definition. Here is where people go wrong. They model a part with multiple materials, like a steel shaft with an aluminum hub shrunk onto it, and the software reports a single inertia tensor for the assembly. If you then use that number as if it were a homogeneous object in a dynamics equation, your angular acceleration will be off. You need the tensor for the full assembly, not individual parts summed loosely. Export the full inertia matrix and use it directly in your simulation input. For custom geometries that don't exist in the standard table, you have two paths. Numerical integration over a mesh gives you results in seconds if the mesh quality is reasonable. The alternative is splitting the shape into known primitives and summing their inertias using the parallel axis theorem for each offset component. I do this when I need to audit a CAD-exported value because I have seen too many cases where the software missed a fillet or a chamfer and the reported mass properties drifted by five to eight percent. That five percent difference is the reason a bearing cage fractured on the second prototype run.
Get the Full Details
The Edge Case That Broke My Schedule
I was working on a high-speed spindle for a machining center, roughly twelve thousand RPM. The inertia of the rotor assembly needed to be precise because the motor controller used it for field-oriented control tuning. The manufacturer provided the inertia as eight hundred gram-square millimeters. My hand calculation using the solid cylinder approximation came out to six-fifty. A difference of nearly twenty percent in a system where torque ripple directly affects surface finish. The problem was that the rotor was not a solid cylinder. It had longitudinal cooling channels running the full length, and the shaft had a keyway plus a taper lock fit section. Those features removed material near the outer radius, which actually reduced the inertia more than the inner geometry increased it. The manufacturer had modeled it as a solid disc. I remeasured the actual part, scanned the cooling channel cross-sections, and rebuilt the CAD model with the real features. The corrected value came to seven hundred and forty gram-square millimeters, which matched the measurement bench test within two percent. I recommend building a physical proof whenever the discrepancy between theory and vendor data exceeds ten percent, because something is always modeled wrong.
Common Pitfalls That Waste Time
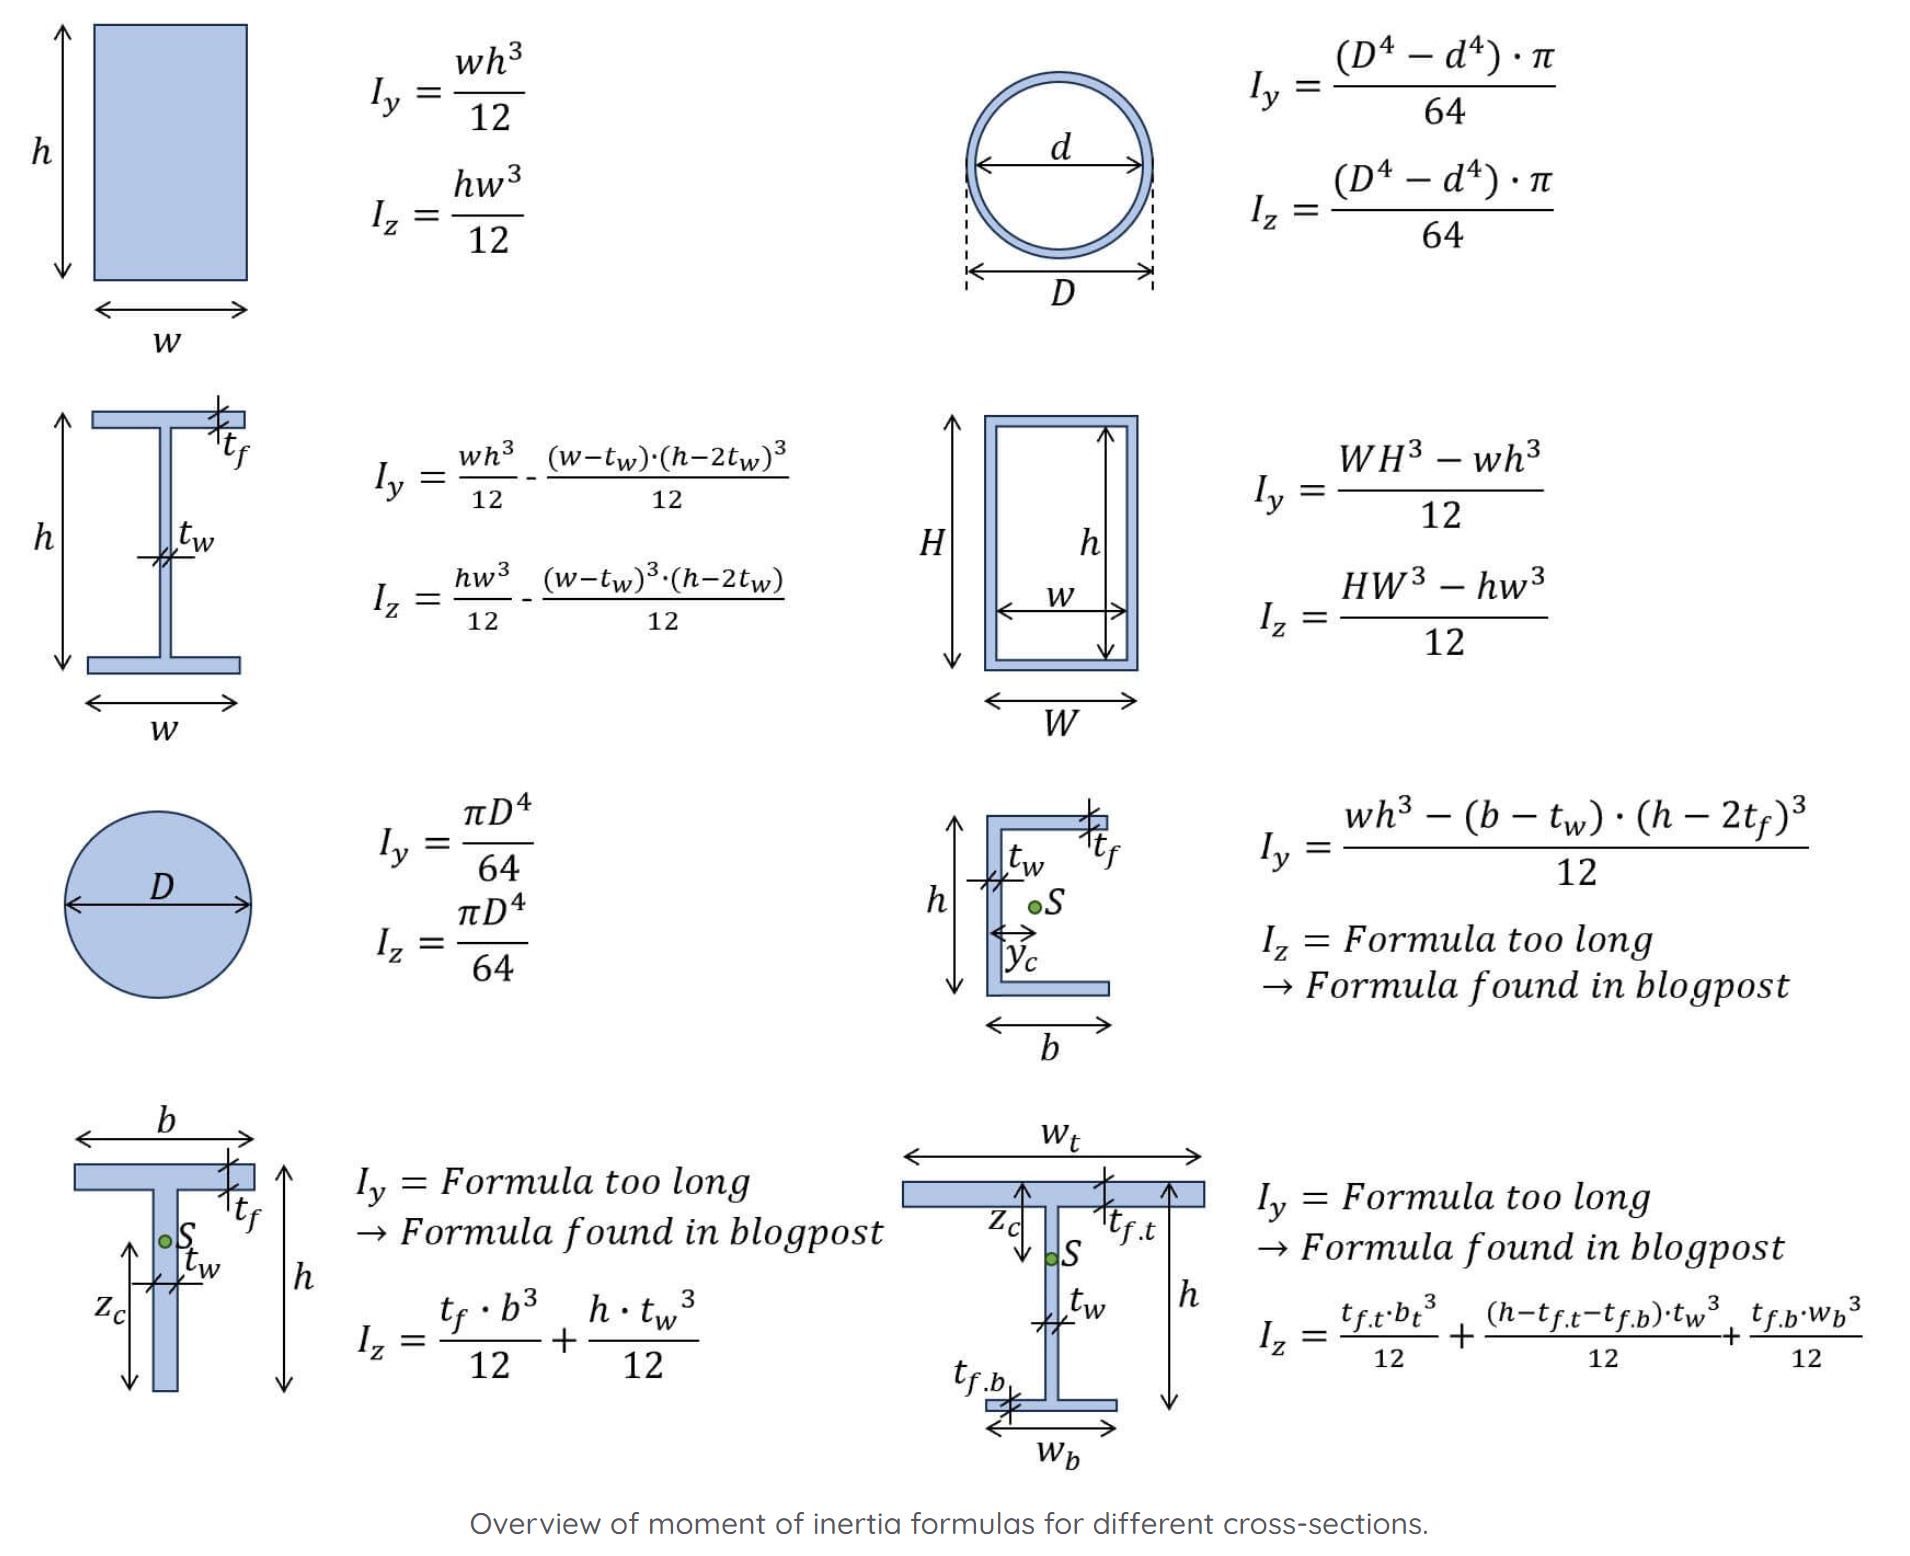
Unit inconsistency is the single most common error. Moment of inertia has units of mass times length squared, so kilogram meter squared, gram millimeter squared, slug foot squared, these are all different. If you feed kg mm squared into an equation expecting SI units, your result will be off by a factor of one million. I keep a conversion table open in my notes. Mass moment of inertia in kg m squared equals the value in g mm squared divided by one billion. Area moment of inertia, which is a different concept used in bending stress calculations, is in meters to the fourth power and should never be confused with the mass version. Another pitfall is assuming the moment of inertia is constant. For flexible or deformable bodies, the mass distribution shifts during operation, and the inertia tensor changes with orientation and elastic deformation. A folding solar array on a satellite is a real example where the inertia matrix evolves over time. If you are designing a robotic arm with extendable links, the inertia seen by each joint motor changes as the arm articulates. You need the full tensor as a function of joint angles, not a single scalar number. The third mistake is confusing radius of gyration with physical radius. The radius of gyration k is defined so that I equals m k squared. For a solid cylinder, k is r divided by root two, which is roughly point seven zero seven r. People sometimes plug k into equations meant for physical radius and get results that look plausible but are wrong. Always check whether the variable in your formula represents the actual geometry or the derived radius of gyration.
When The Standard Equations Stop Working
The closed-form Moment Of Inertia Equation works cleanly for uniform-density shapes with simple boundaries. It breaks down when you have non-uniform density, complex internal features, or anisotropic materials. A composite flywheel with carbon fiber wraps over a steel hub does not have a single density. A turbine blade has root slots, tip clearance features, and cooling holes that no standard formula covers. In those cases, the numerical approach is not optional, it is required. The limitation of the analytical method is that it assumes perfect geometry. In manufacturing, every part has tolerances. A cast iron flywheel might vary in density by three to five percent across the disc due to cooling rate differences during casting. That variation translates directly into inertia variation. If your application involves precision timing or synchronous rotation, you should measure the actual part rather than trusting the calculated value from a drawing. A simple swing test on a known-length pendulum attachment gives you the effective inertia within one to two percent, and it takes about ten minutes to perform.
A Practical Workflow That Saves Hours
I run every inertia value through a three-step verification now. First, I derive a quick estimate by approximating the part as the closest standard shape. Second, I run the CAD export. Third, I check whether the two values are within fifteen percent. If they are, I accept the CAD number and move on. If they are not, I go back and inspect the model for missing features, wrong material assignment, or incorrect coordinate system alignment. The coordinate system issue is subtle and expensive. The software reports inertia about the global origin by default, not about the part center of mass or the actual rotation axis. You need to either move the reference frame to the rotation point or apply the parallel axis theorem manually. For rotating assemblies, I also verify that the principal axes align with the expected geometry. A rotor that is symmetric about its shaft should have equal Ixx and Iyy values and a zero product of inertia in the properly oriented frame. If the off-diagonal terms are significant, the model is misaligned or the part has asymmetric features you were not aware of. That asymmetry causes vibration at operating speed, and catching it before assembly is cheap compared to balancing a rotor after the fact. The bottom line is that the equation itself is straightforward. The difficulty is in knowing which version applies, keeping units consistent, and verifying that your model matches reality. Most errors I see come from skipping the verification step, not from misunderstanding the math.