Calculating the Moment Of Inertia Of Rod — The Way It Actually Works
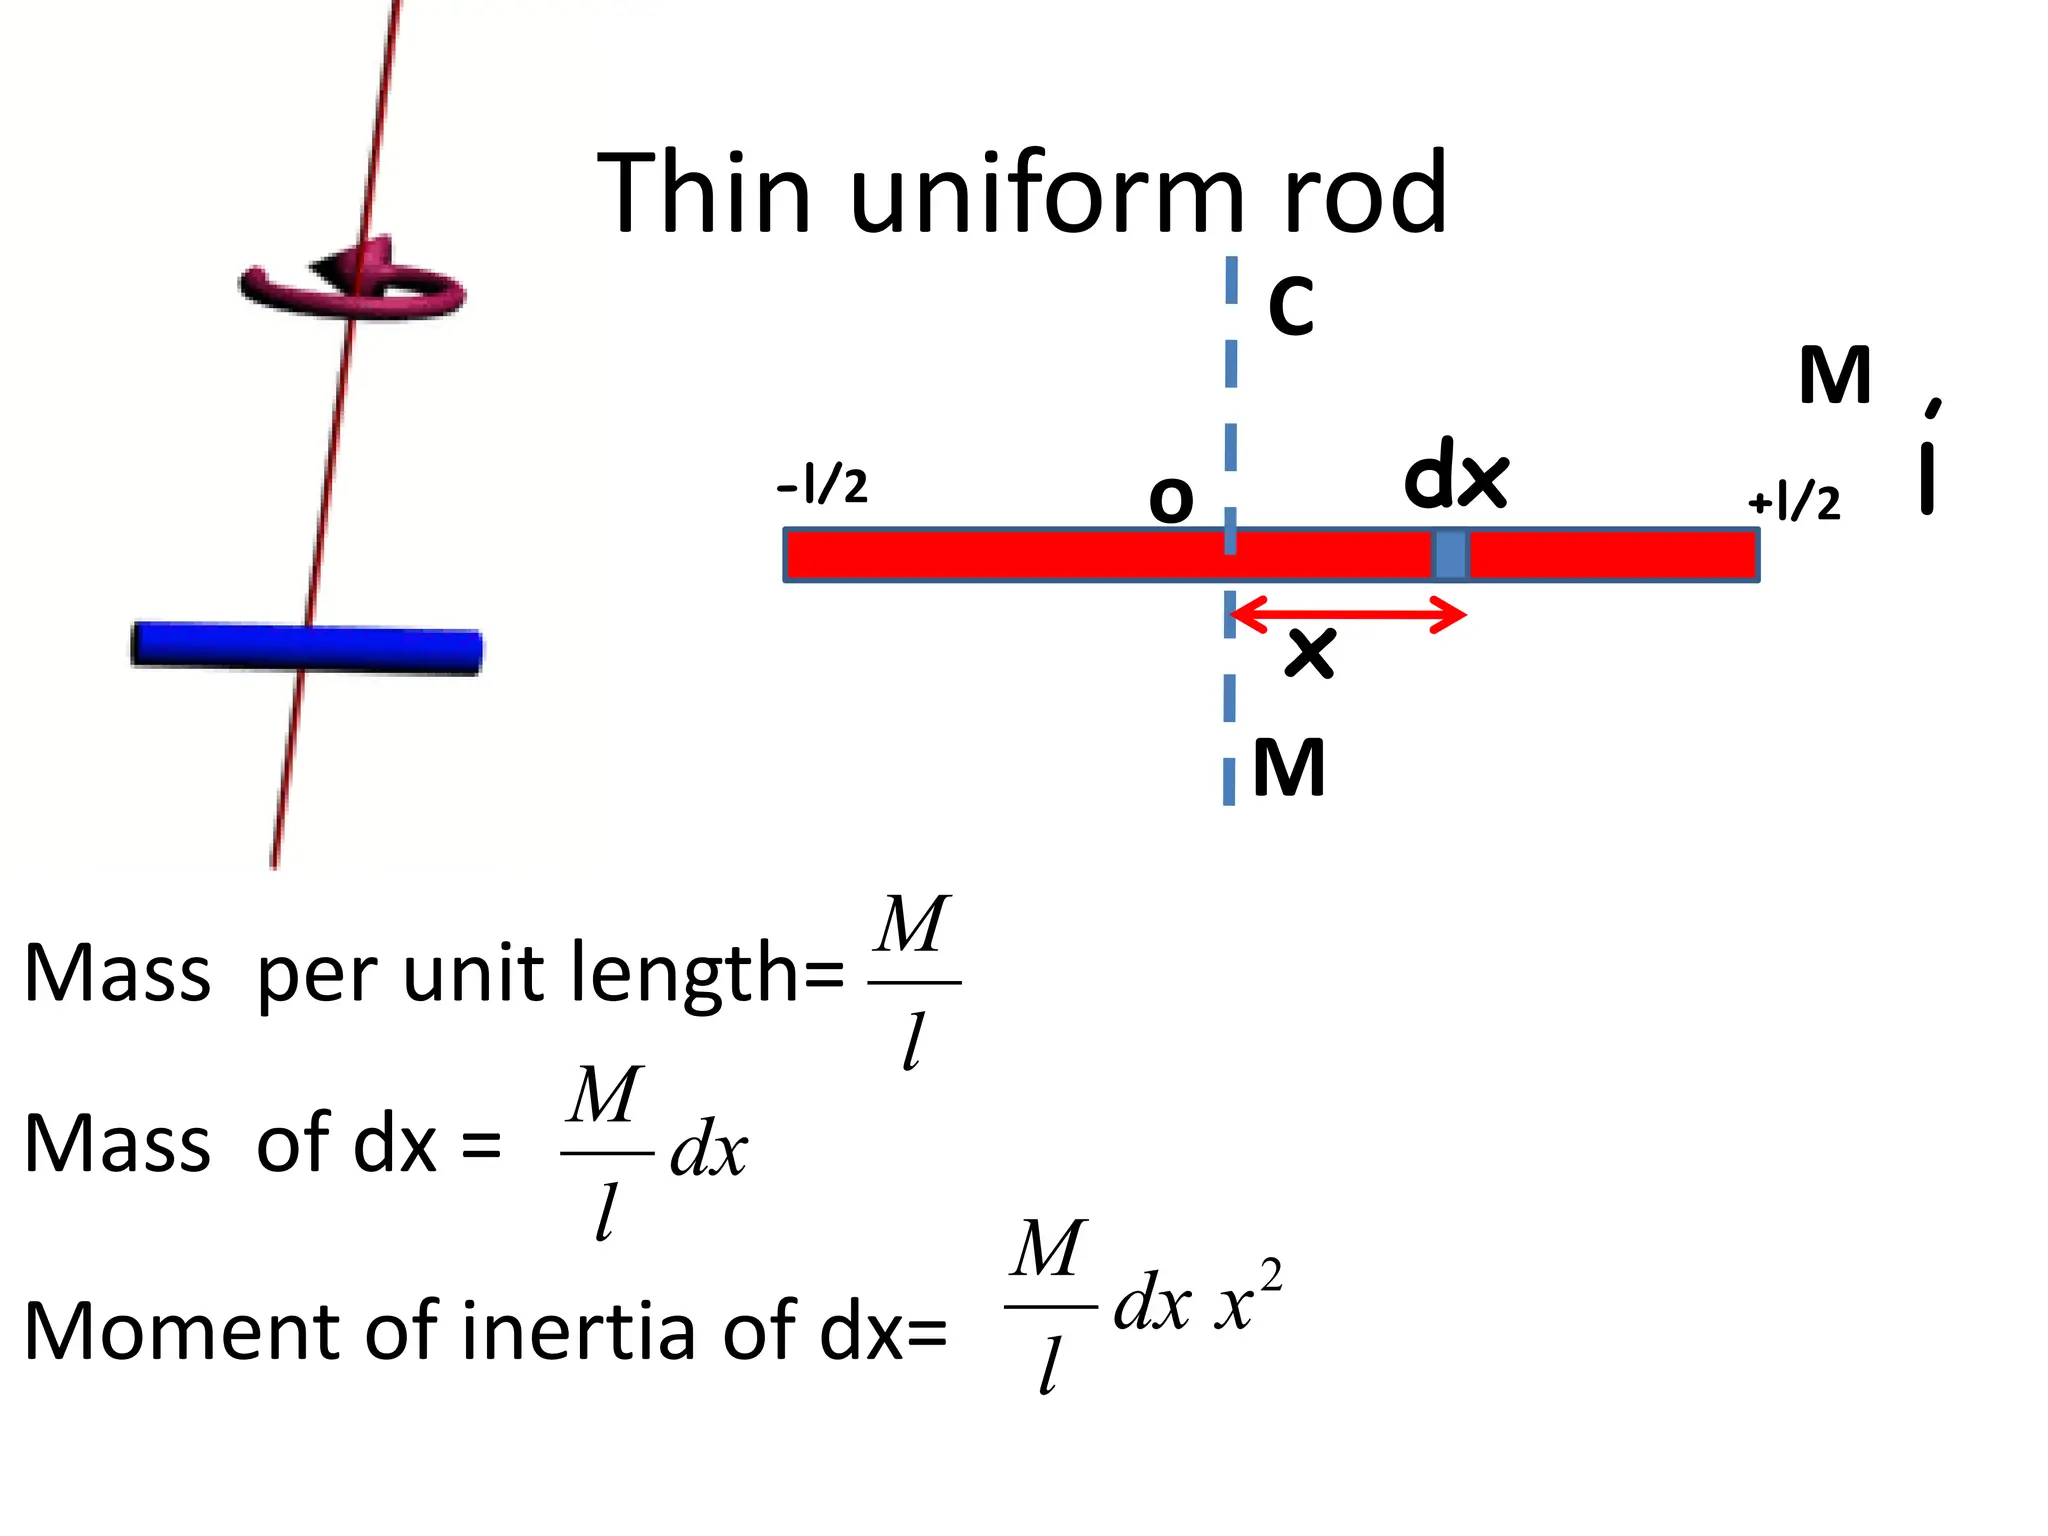
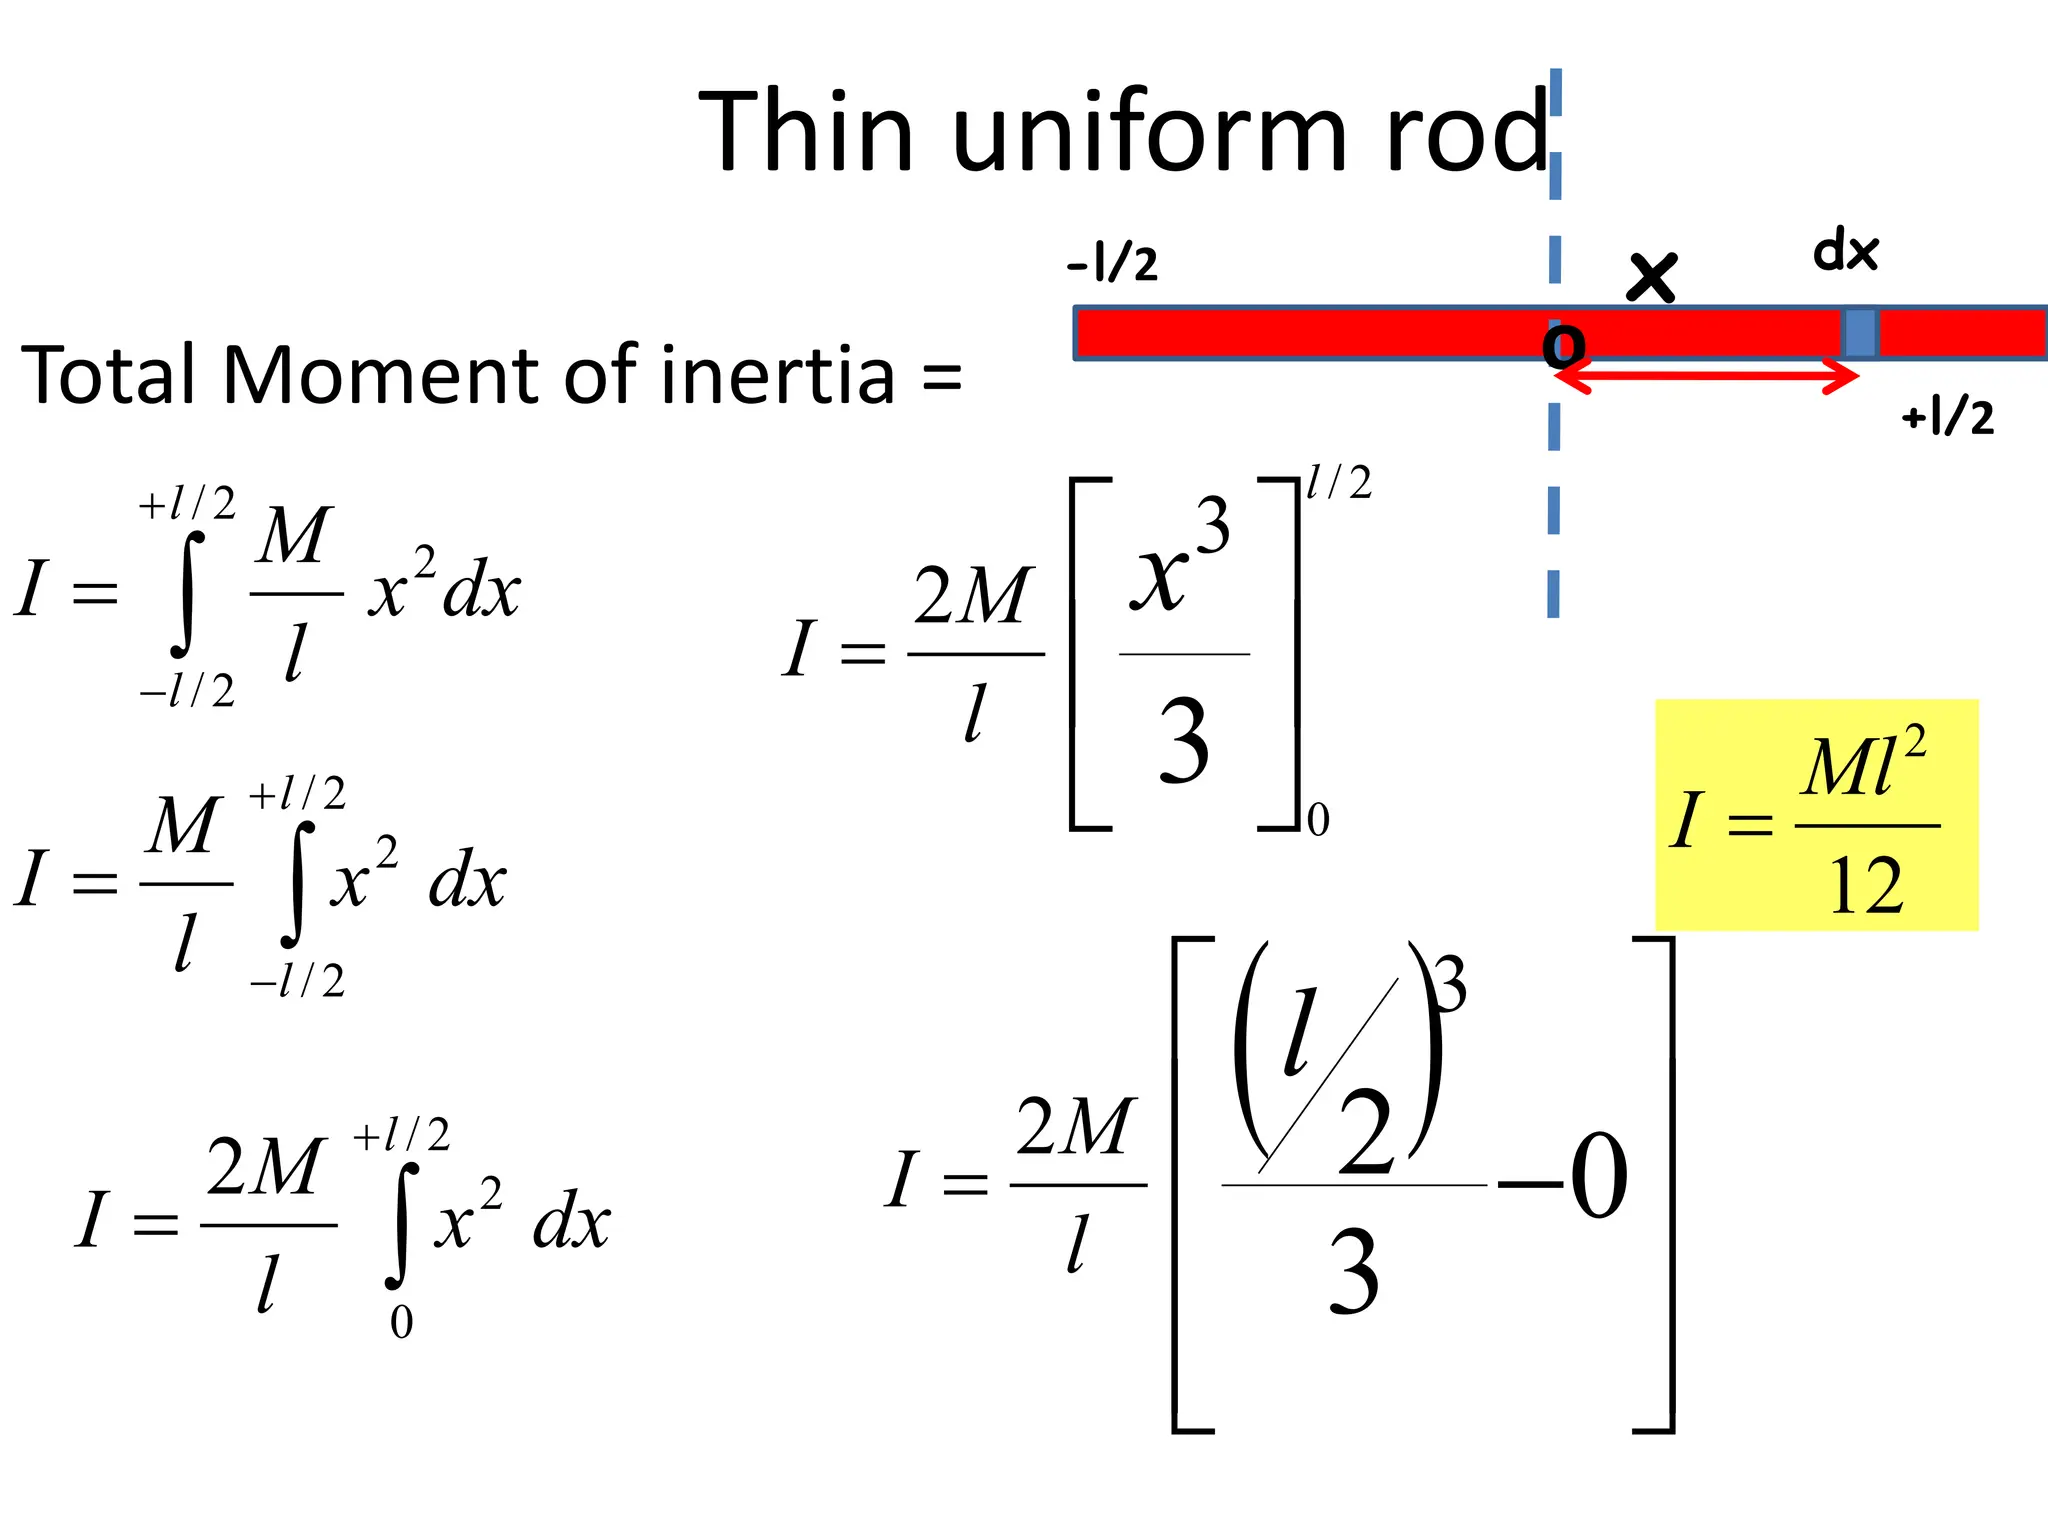
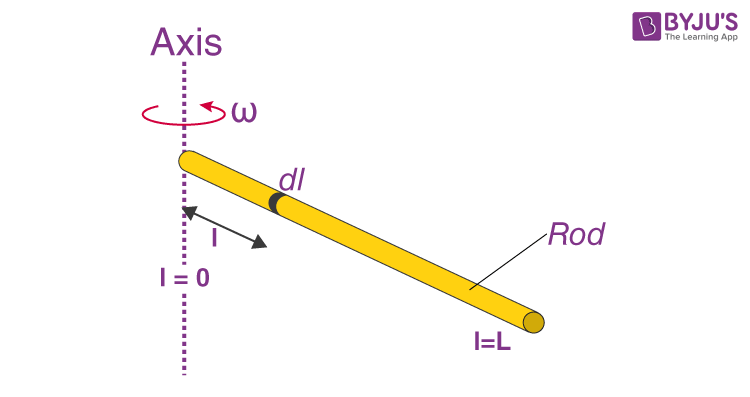
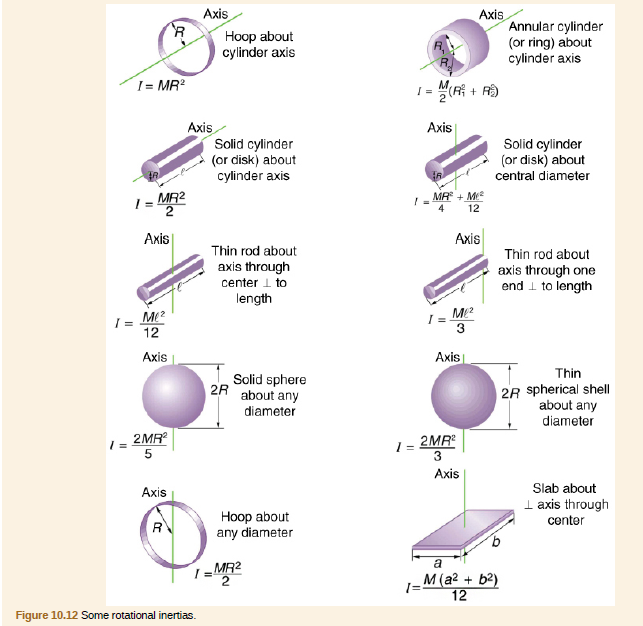
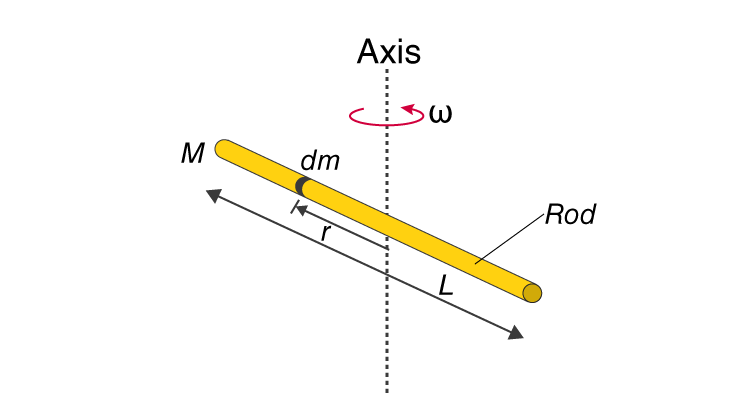
Most textbooks hand you two formulas and pretend that's enough. It's not. The moment of inertia of a rod depends entirely on where the axis of rotation is, and getting that wrong is the single most common mistake I see in dynamics problems. I've sat through more midterms where students blindly applied I = (1/12)mL² to a rod pivoting at its end. It doesn't work. You'll get the answer wrong by a factor of three, and you won't know why until you check the parallel axis theorem. Let me walk through this the way I'd actually use it in a real problem set or a design calculation. The baseline formula for a uniform thin rod of mass m and length L, rotating about an axis through its center of mass and perpendicular to its length, is I_cm = (1/12)mL². That's the one you memorize first. The second one you need is I_end = (1/3)mL² for rotation about one end. You can derive that second one from the first using the parallel axis theorem, which states I = I_cm + md² where d is the distance from the center of mass to your new axis. For a rod, d = L/2, so I = (1/12)mL² + m(L/2)² = (1/12)mL² + (1/4)mL² = (1/3)mL². The math is straightforward. The mistake people make is assuming that covers everything.
When the Rod Isn't Uniform or the Axis Isn't Perpendicular
This is where things get messy and where textbook examples stop helping. I ran into this recently on a project involving a composite cantilever beam — basically a steel rod with a heavier alloy sleeve pressed over half its length. The standard rod formulas don't apply to that. You have to split it into segments, calculate the moment of inertia for each segment about the common axis, and then sum them. I did it by treating the bare section and the sleeved section as two separate rods, each with its own mass and its own I_cm, then using the parallel axis theorem to shift each to the pivot point. Took about twenty minutes of careful bookkeeping instead of the thirty seconds a single formula would have given you if the geometry were simple. Another edge case that bites people: the axis isn't perpendicular to the rod. If the rod rotates about an axis that's at an angle to its length, you need the perpendicular component of the distance from each mass element to the axis. For a thin rod, this effectively means you're working with an projected length. The moment of inertia drops as the angle approaches zero — when the rod spins along its own longitudinal axis, the moment of inertia for a thin rod is essentially zero because all the mass is near the axis. That's counter-intuitive to a lot of students who think "rod" always means "large moment of inertia." It doesn't. Orientation matters more than shape in that scenario.
Moment Of Inertia Of Rod — Practical Calculation Method
Here's the procedure I use when I need to be sure. First, confirm the rod is uniform. If it's not, you need the linear density function (x) and you integrate: I = x²(x)dx over the length of the rod. For a uniform rod, is constant and you get back the familiar formulas. Second, identify the exact axis. Draw it. Label the distance from the center of mass to that axis — call it d. Third, pick the right base formula. Center axis: (1/12)mL². End axis: (1/3)mL². Any other axis along the rod's perpendicular plane: use the parallel axis theorem. Fourth, check whether the rod has significant thickness. If the diameter is more than about 5% of the length, you should account for the rod's own radial moment of inertia, which adds (1/4)mr² to the result where r is the radius. Most introductory problems ignore this. Real engineering problems don't. I've also seen people misuse the perpendicular axis theorem here. That theorem only applies to planar laminas — flat 2D objects. A rod is not a lamina. Don't try to apply I_z = I_x + I_y to a rod. It won't work and it'll confuse your axes. Stick to the parallel axis theorem and direct integration.
Get the Full Details
Pitfalls and Where This Approach Breaks Down
The biggest limitation of the standard rod formulas is that they assume the rod is thin and rigid. If you're dealing with a flexible rod, a vibrating shaft, or anything where the mass distribution changes during rotation, these static formulas are useless. You'd need to model it as a continuous system with distributed mass and use either finite element analysis or at minimum a modal approximation. I had a case once where someone was trying to use I = (1/3)mL² for a carbon fiber rod that was flexing significantly under load. The effective moment of inertia was completely different because the mass was redistributing as the rod bent. The formula gave them numbers that were off by roughly 40% from the measured response. We ended up using a lumped-mass model with spring elements instead, which took about two hours to set up but matched the test data within 5%. Another hard limit: these formulas assume rotation in a single plane. If the rod is part of a 3D rotating assembly with precession or gimbal motion, you need the full inertia tensor, not a scalar moment of inertia. The scalar I = (1/3)mL² is just one component of that tensor. Using the scalar in a 3D dynamics simulation will give you qualitatively wrong results. I learned that the hard way on a project involving a rotating sensor boom on a satellite mockup. The attitude dynamics software flagged inconsistencies immediately once I fed it scalar moments instead of full tensors.
Quick Reference for Common Cases
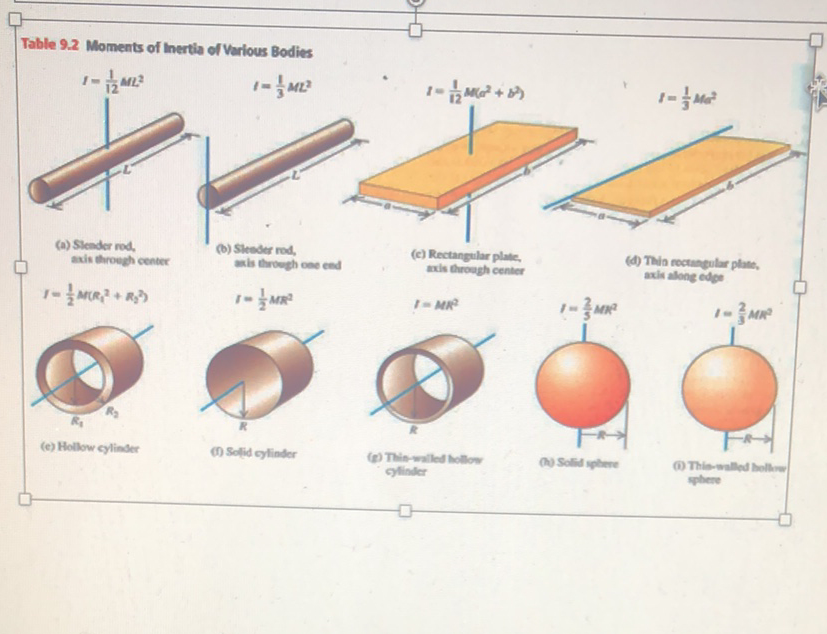
Axis through center, perpendicular to rod: I = (1/12)mL² Axis through end, perpendicular to rod: I = (1/3)mL² Axis through center, along the rod's length: I 0 for a thin rod, exactly (1/4)mr² for a solid cylinder of radius r
General axis at distance d from center: I = (1/12)mL² + md² Non-uniform rod with linear density (x): I = x²(x)dx with appropriate limits depending on the axis location If you need to look up derived values or check your work against standard tables, the engineering handbooks from Roark or the Meriam & Kraige dynamics reference both have comprehensive moment of inertia tables that cover rods under various axis configurations. The tables save time but they don't teach you when not to use them. That part comes from making the mistakes yourself and learning which assumption each formula quietly requires.