The formula is F = ma. That's it. Force equals mass times acceleration. But using it correctly in real problems requires understanding what each variable actually represents and what assumptions are baked into the equation. Most people get tripped up on the vector nature of force and acceleration, or they forget when the formula breaks down entirely.
I ran into this last year when a client asked me to calculate the force needed to accelerate a 2,400 kg forklift from rest to 1.8 m/s in roughly 3.5 seconds on an incline. The straightforward F = ma approach gave one answer, but when I accounted for the grade angle, rolling resistance, and the fact that the forklift's center of gravity shifts under load, the required motor torque was about 18 percent higher than the textbook calculation. I ended up using a free-body diagram with friction coefficients from the tire manufacturer's data sheet and added a safety factor of 1.3 before specifying the motor.
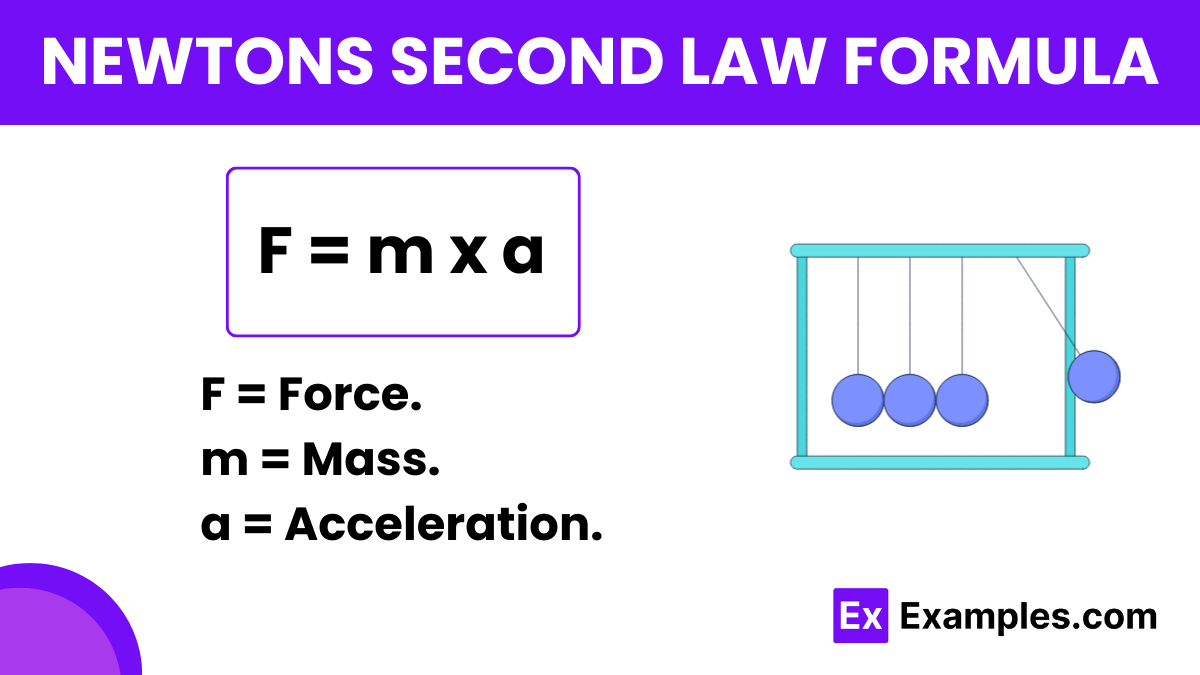
Newton S Second Law Formula
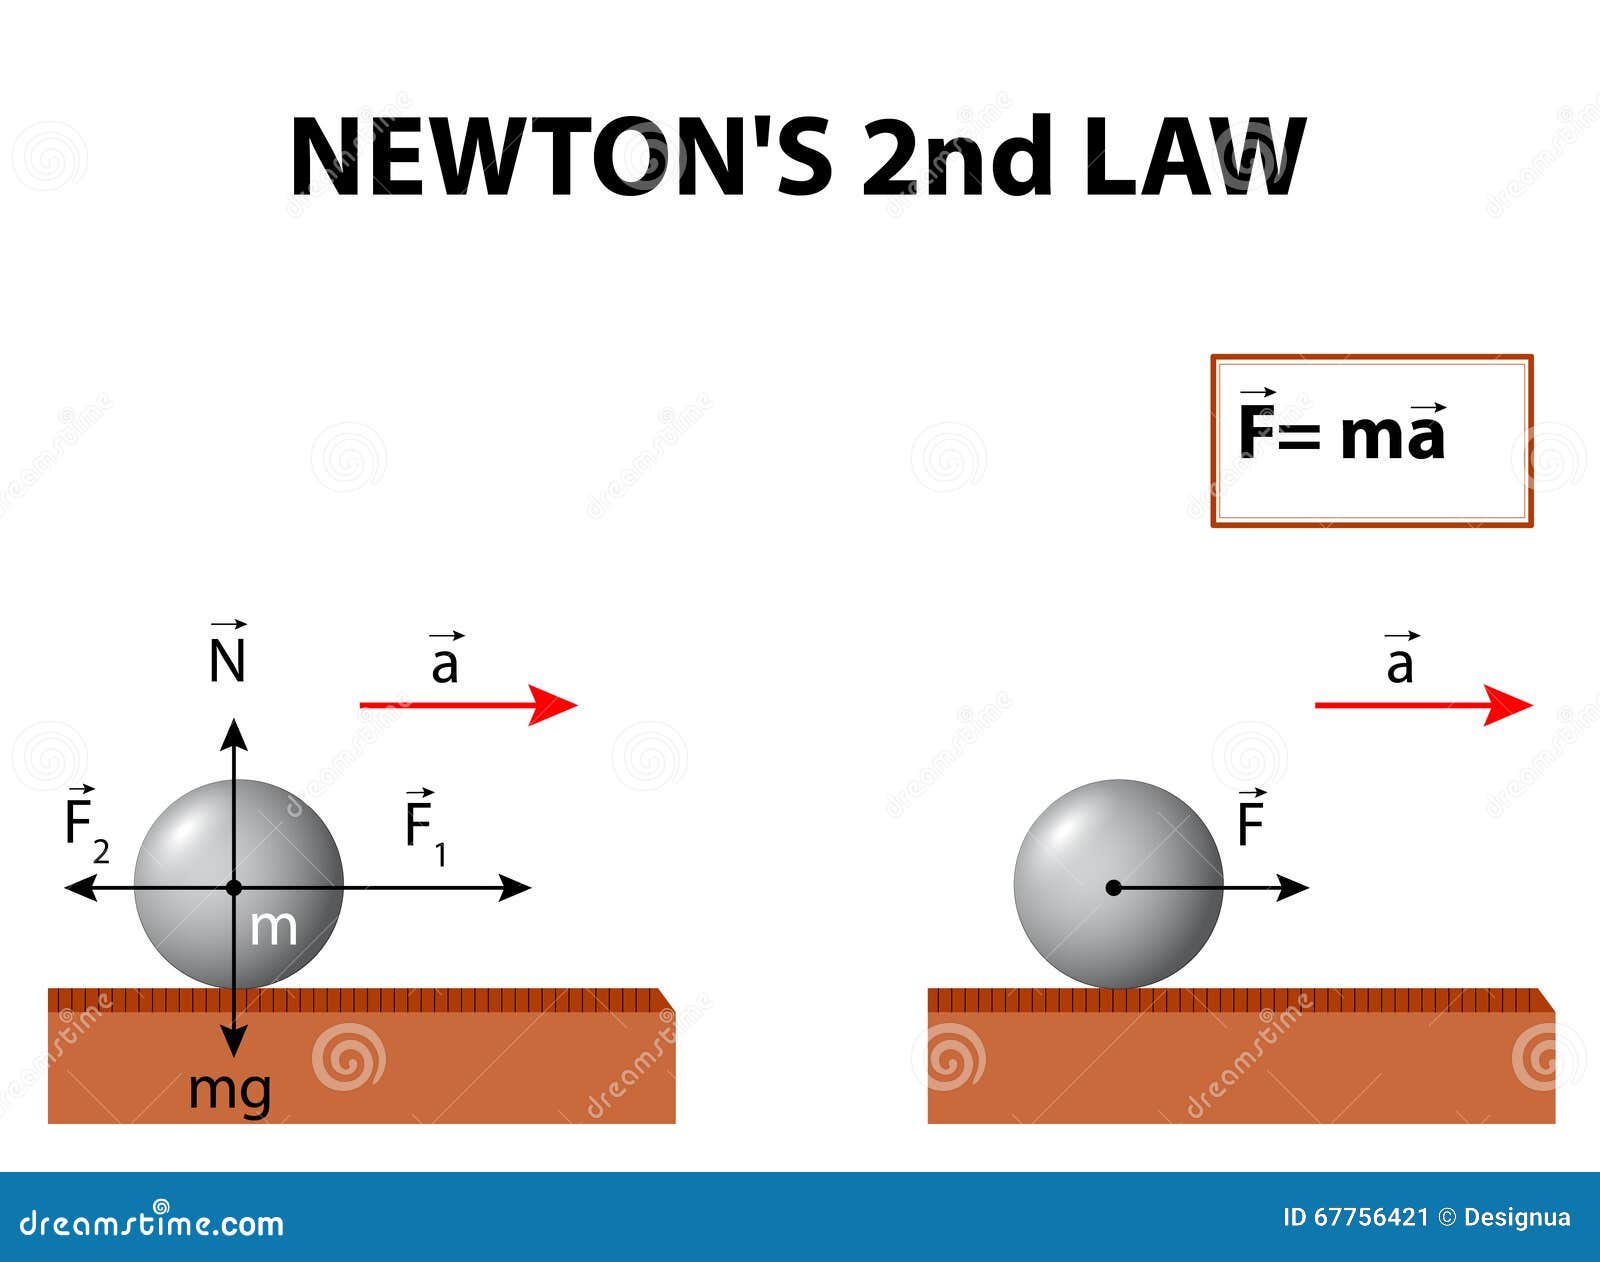
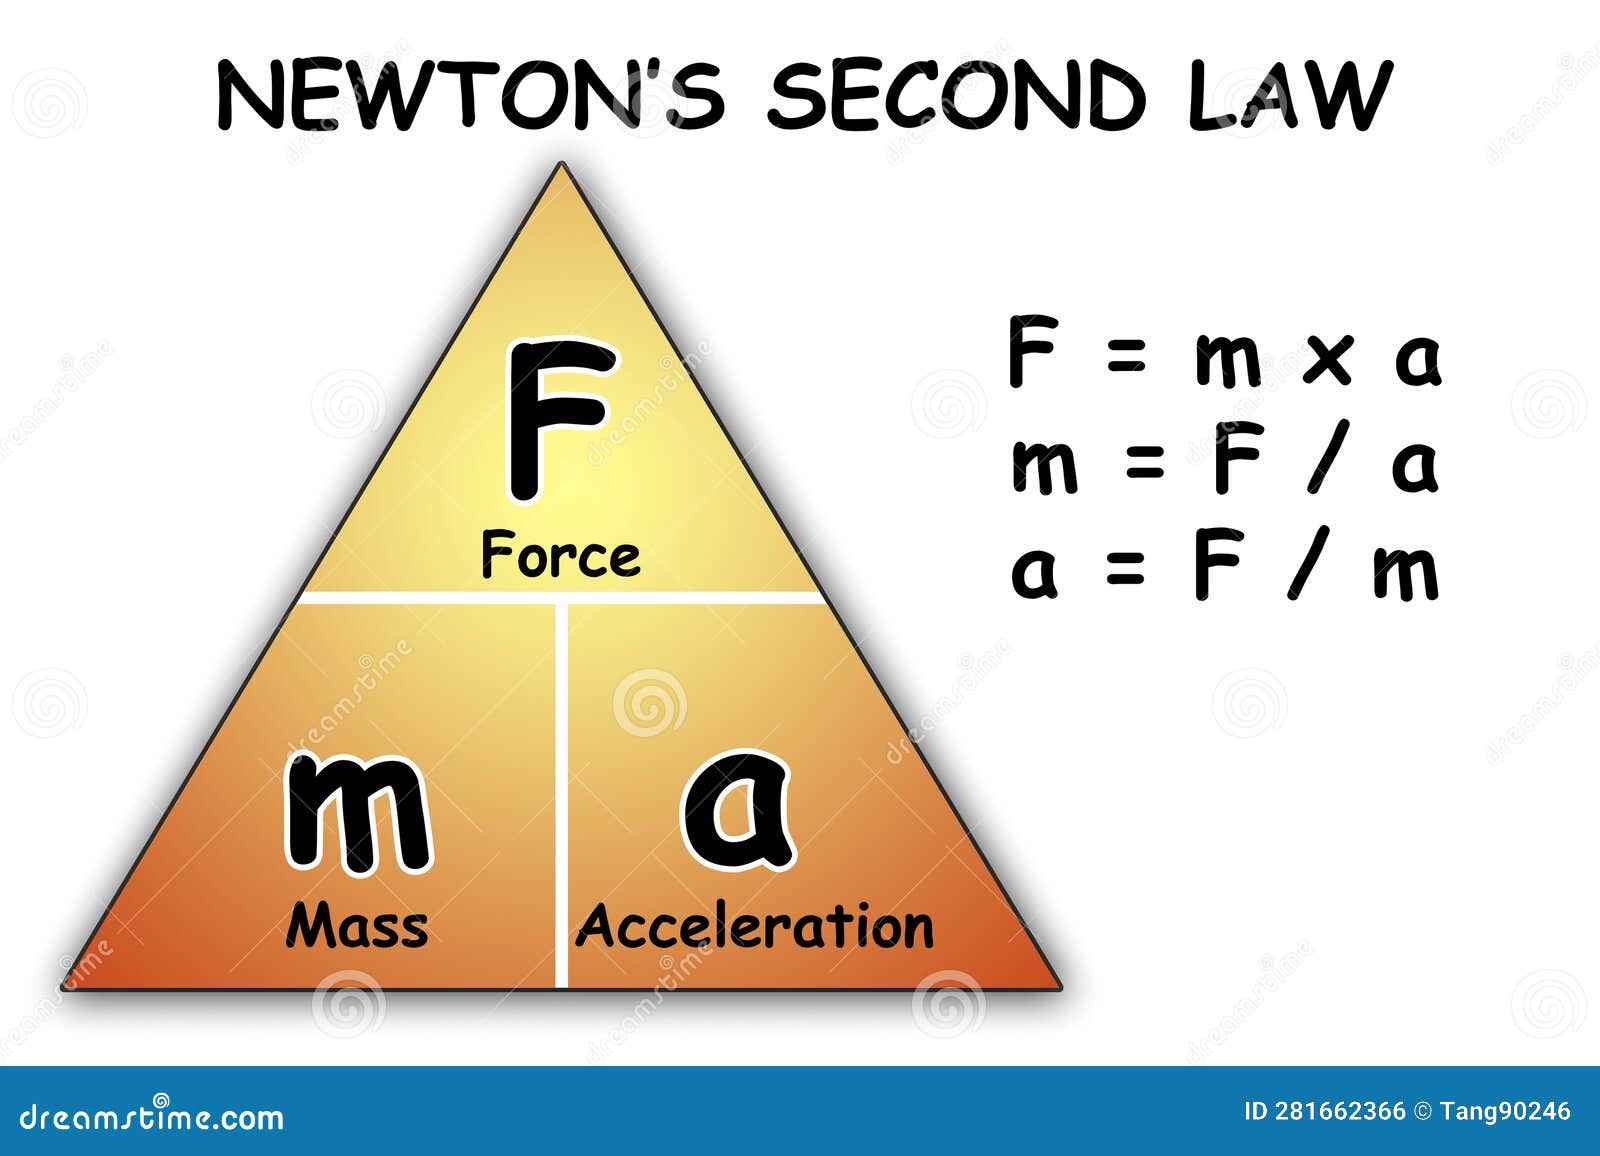
F = ma is the standard form you will see everywhere. It means the net force acting on an object is equal to the mass of that object multiplied by its acceleration. The direction of the force vector is the same as the direction of the acceleration vector. If the force is not aligned with your axis of motion, you resolve it into components and apply the formula separately along each axis.
A common mistake is treating force and acceleration as scalars when the problem involves angles or multiple directions. I always draw a quick coordinate system first, even on simple problems. It catches errors before they propagate through three pages of calculations.
Another thing beginners miss is that mass in this formula is rest mass, not relativistic mass. At everyday speeds this distinction is irrelevant, but if you are working on anything approaching significant fractions of the speed of light, F = ma gives wrong answers and you need the relativistic form instead.
How to Apply It Step by Step
Start by identifying every force acting on the object. Draw them as vectors on a free-body diagram. This alone solves about half the problems students struggle with. Then pick your coordinate system and break every angled force into components. Sum the forces along each axis. Set those sums equal to mass times acceleration along that same axis. Solve for whatever unknown you need.
When dealing with friction, use the normal force from your diagram, not just the object's weight, because on an incline the normal force is mg cos(theta). I have seen people skip this step and end up off by factors of two on steep slopes.
For variable mass systems like rockets, the basic formula does not work directly. You need F = v_rel (dm/dt), which accounts for the changing mass as propellant burns. This comes up more often than people expect in engineering work.
Units and Conversions
Stick to SI units unless you have a good reason not to. Force in newtons, mass in kilograms, acceleration in meters per second squared. If your mass is in grams, convert it first. If your acceleration is in km/h/s, convert it too. Mixing units is the fastest way to get numbers that look plausible but are completely wrong.
One newton is the force required to accelerate one kilogram at one meter per second squared. That definition is worth keeping in mind because it makes unit conversion almost automatic.
Where the Formula Falls Short
The formula assumes rigid bodies and inertial reference frames. If the object deforms significantly under load, or if you are analyzing from an accelerating frame like a turning car, you need to introduce pseudo-forces or switch to a Lagrangian approach. Neither is a huge deal, but both require more work than plugging numbers into F = ma.
It also assumes constant mass. Variable mass problems exist and are not rare in practice, especially in aerospace and fluid dynamics. The standard form will give you wrong results if you apply it blindly to those situations.
If you are working with very small scales where quantum effects matter, or very strong gravitational fields where general relativity applies, Newton's second law in any simple form is inadequate. In those domains you are looking at completely different equations.
Gallery Newton S Second Law Formula
What Is Newton S Second Law Of Motion Formula - Free Worksheets Printable
Newton Second Law Equation Formula Mathematic: เวกเตอร์สต็อก (ปลอดค่า ...
Newtons Second Law Physics Formula On Stock Vector (Royalty Free ...
newton’s second law of motion formula. force mass and acceleration ...
Newtons Second Law Newton S Law 2 Nd Example Science Physics Vector ...