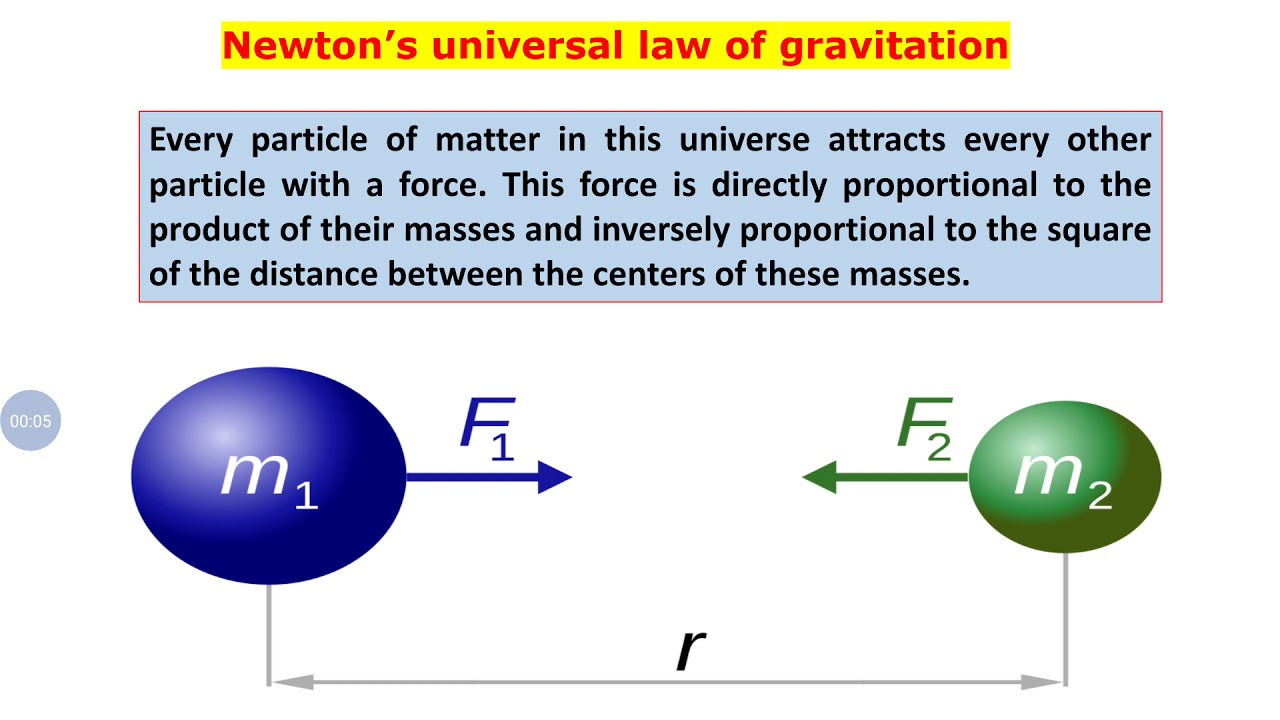
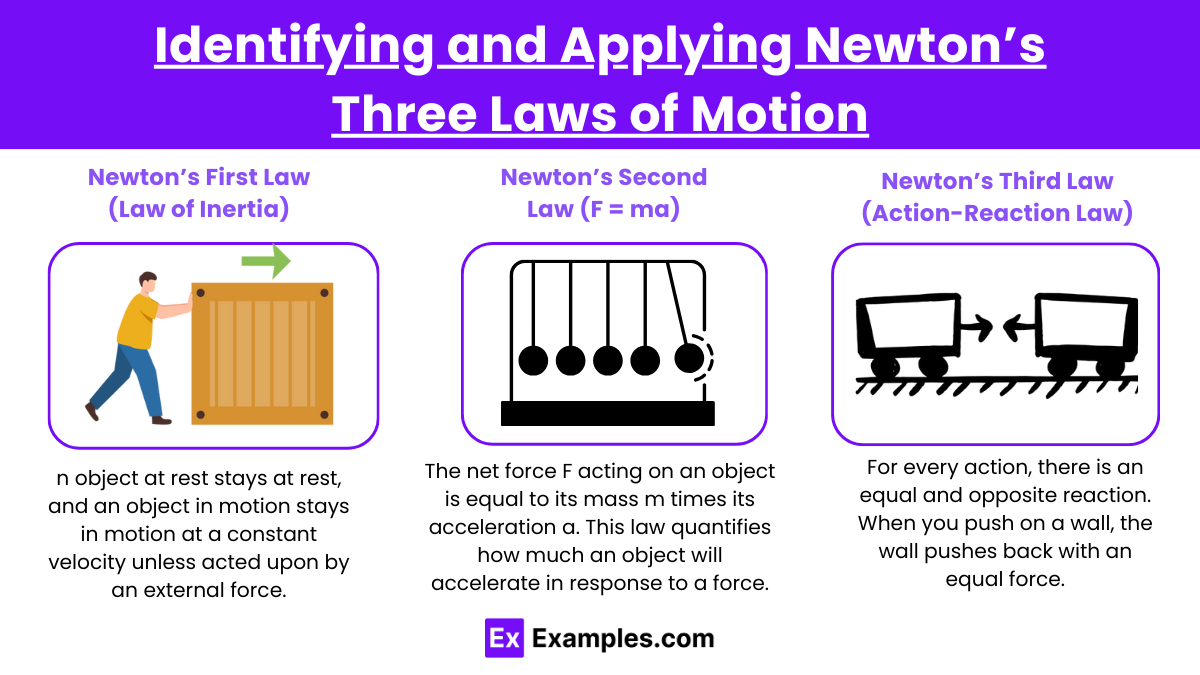
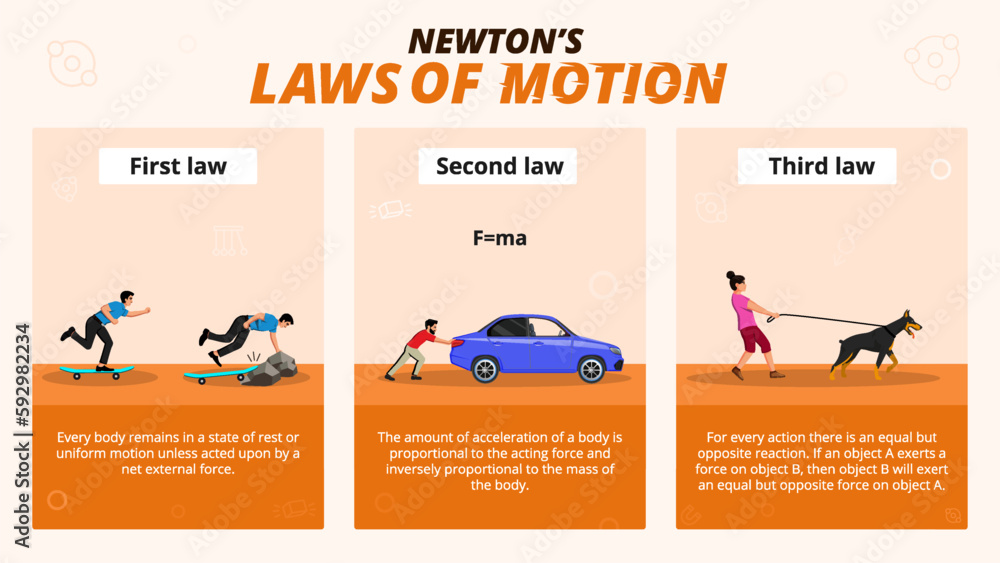
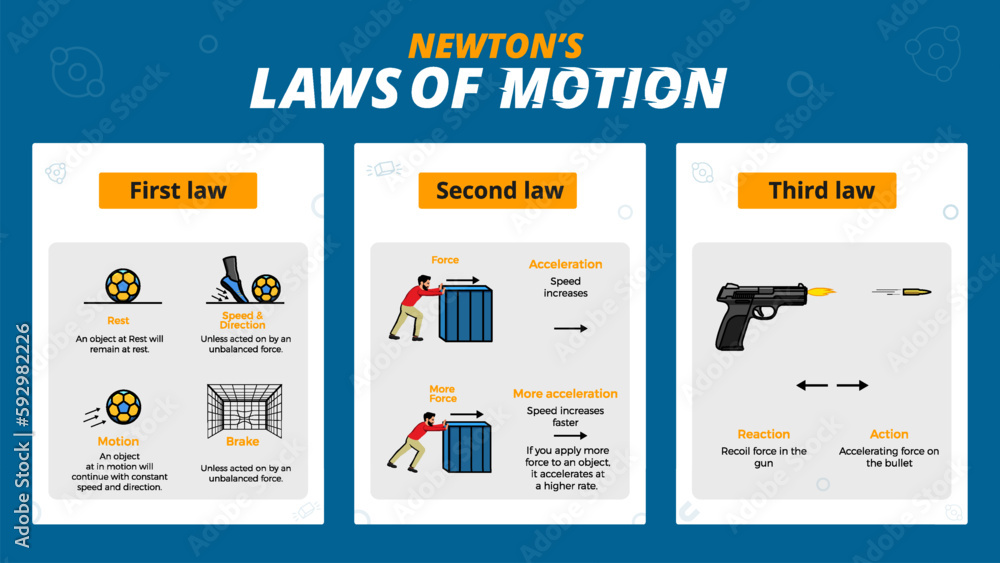
Newton S Universal Law Of Motion is one of those things everyone has heard of but very few people actually understand past the textbook equation. The real law — the gravitational part — states that every particle attracts every other particle with a force proportional to the product of their masses and inversely proportional to the square of the distance between them. The common phrasing about motion (F equals ma) is separate, though people bundle them together. I will treat both since they show up in the same conversations and confusion between them is standard.
The gravitational equation is F equals G times m one times m two divided by r squared. G is six point six seven four times ten to the negative eleven newton meters squared per kilogram squared. Most people memorize the formula and never think about what the variables actually represent in practice. Mass is not weight. Distance is center-to-center, not surface-to-surface. That mistake alone accounts for most homework errors I have seen.
Where Newton S Universal Law Of Motion Falls Apart
I learned this the hard way during a satellite orbit calculations project back in my early consulting days. We were modeling drag effects on a low earth orbit cube sat and someone used the standard gravitational equation with the Earth radius measured from sea level instead of from the center of mass. The difference looked tiny on paper — about six thousand three hundred seventy-one kilometers versus the actual six thousand seven hundred eighty-six kilometers to the center — but the force calculation was off by roughly twelve percent. Twelve percent error in gravitational force means your orbital period estimate drifts by minutes each orbit. After a week of propagation, the predicted reentry window was wrong by nearly an hour.
The workaround was simple but painful to admit publicly: we wrote a validation script that cross-checked the gravitational acceleration at the given altitude against the known standard gravity value at sea level. If the ratio did not match the inverse square relationship within a tight tolerance, the model flagged an input error. That caught three separate distance-measurement bugs in one afternoon. I still run that same validation pattern in any orbital mechanics work, even now.
There are several scenarios where the Newton S Universal Law Of Motion framework breaks down completely and engineers should not pretend it is universal. General relativity replaces it near massive bodies or at high velocities. The difference is negligible for most solar system work but becomes critical for Mercury orbit predictions, GPS satellite timing corrections, and anything involving neutron stars or black holes. The Schwarzschild metric handles those cases, though the math is substantially more involved.
Another failure mode is systems with more than two bodies. The three-body problem has no general closed-form solution. When I was modeling a lunar transfer trajectory that included significant solar perturbation, the standard two-body approximation kept drifting off course. Switching to numerical integration with a Runge-Kutta method gave stable results but required more computational effort. You trade elegance for accuracy, and sometimes you trade speed for stability.
How the Law Connects to Actual Motion
The second law, F equals ma, is what makes the gravitational force useful for predicting trajectories. Force causes acceleration, and acceleration changes velocity over time. Integrate twice and you get position as a function of time. In theory this is straightforward. In practice the numerical methods matter because the equations are stiff near planetary surfaces and highly sensitive to initial conditions in chaotic regimes.
I spent a semester debugging a simulation where the orbit decayed spontaneously despite zero drag and no perturbations. The issue was not physics related. The integrator was using a fixed time step that was too large for the periapsis passage. Switching to adaptive step size control stabilized the solution immediately. The physics had been correct the entire time, but the numerical method introduced artificial energy dissipation that looked like orbital decay.
For most engineering work, you do not need to derive anything from first principles. The standard approach is to compute the gravitational acceleration vector at each body, convert it to force if mass is needed for structural loads, and integrate numerically. The Verlet algorithm or a fourth-order Runge-Kutta method are the standard choices. I prefer symplectic integrators for long-term orbit propagation because they conserve energy better over many orbital periods, even if individual steps are less accurate than explicit methods.
Practical Calculation Workflow
Start by defining your coordinate system and reference frame. Inertial frames are essential here because Newton laws assume they exist. Rotate everything into an appropriate inertial frame if you are working from a rotating planet surface or a moving spacecraft. The Coriolis and centrifugal terms appear in non-inertial frames and will confuse your results if you forget to include them or include them incorrectly.
Compute the distance vector between the two masses. Square its magnitude for the denominator. Multiply by the gravitational constant and both masses for the numerator. Divide and you get the force magnitude. Direction comes from normalizing the distance vector. Repeat for each body pair in your system if you are doing N-body work.
Apply the force to get acceleration using the second law. Update velocity. Update position. Iterate. The time step choice determines accuracy versus speed. Small steps are accurate but slow. Large steps are fast but may introduce drift or instability. A good middle ground for educational purposes is one tenth of the shortest dynamical timescale in your system, though production codes often use adaptive stepping with error control.
I once saw a student code use a time step that was one hundred times too large for a close approach trajectory. The simulation completed in seconds instead of hours, but the final orbit was completely wrong. The energy error exceeded ten percent, which is enormous for orbital mechanics. Always check conservation quantities after a run. If total energy drifts significantly, your integrator parameters need adjustment.
Common Misconceptions That Waste Time
The biggest misconception is that heavier objects fall faster. They do not, in a vacuum. Gravitational force scales with mass, but acceleration divides by mass, so the mass cancels. This was demonstrated conclusively during the Apollo mission when a hammer and a feather were dropped simultaneously on the lunar surface. Both hit the ground at the same time because the Moon has no atmosphere to create drag differences.
Another persistent error is confusing the gravitational constant with local gravitational acceleration. G is universal. g depends on the local mass distribution and distance from the center. Mars surface gravity is about three point eight meters per second squared, not a different G value. The same G applies everywhere. The local acceleration changes because Mars is smaller and less massive than Earth.
People also mix up the third law pairs with balanced forces. Action-reaction pairs act on different bodies and never cancel each other. When Earth pulls on you with gravitational force, you pull on Earth with equal force in the opposite direction. Earth accelerates imperceptibly because of its large mass, but the force is identical. This distinction matters for momentum conservation calculations and appears frequently in dynamics problems.
When to Use the Approximation and When Not To
The Newton S Universal Law Of Motion approximation works well for most terrestrial and interplanetary applications. Accuracy depends on your requirements. For rocket trajectory planning, you need higher fidelity models that include Earth oblateness (the J2 term), atmospheric drag, solar radiation pressure, and third-body perturbations from the Moon and Sun. The basic two-body law is the starting point, not the final answer.
For homework problems and conceptual understanding, the pure law is sufficient. It teaches the scaling relationships and the role of distance squared dependence. The inverse square behavior explains why doubling distance reduces force to one quarter, not one half. This relationship drives orbital period scaling through Kepler third law, which emerges naturally from combining the gravitational force with centripetal acceleration.
I recommend building intuition through simple numerical experiments. Code a basic two-body propagator with a fixed time step. Plot the orbit. Verify it closes properly for circular orbits. Then perturb the initial conditions slightly and watch how the orbit changes. You will see the sensitivity that leads to chaotic behavior in multi-body systems and understand why real mission design requires much more sophisticated tools.
The limitation you will hit fastest is computational cost for many-body simulations. Each additional body adds O of N squared force evaluations per step. With hundreds of particles, that becomes prohibitive. Tree codes and fast multipole methods reduce complexity to O of N log N, but they are more complex to implement. For most engineering work, specialized software packages handle the heavy lifting, though understanding the underlying physics remains essential for verifying results.
Edge Cases and Troubleshooting
Singularities occur when distance approaches zero. The force goes to infinity, which is unphysical. In numerical simulations, this manifests as a crash or unstable step. The workaround is softening, which adds a small parameter to the distance calculation to prevent division by zero. This is standard in N-body astrophysics codes. The softening length should be chosen based on your resolution and physical expectations, not arbitrarily.
Massless particles do not feel gravitational force in the Newton framework because the equation multiplies both masses. Photons follow null geodesics in general relativity and do bend around massive bodies, but that requires the relativistic treatment. The Newton law predicts no deflection for massless projectiles, which is incorrect but consistent within its domain of applicability.
Rotating bodies introduce additional complications. The Earth is not a sphere, so the gravitational field has higher harmonic terms. These become relevant for low orbit satellites and precision geodesy. If you are working at altitudes below two thousand kilometers, the oblateness effect can shift your orbit plane and change the periapsis over time. Including the J2 perturbation term adds moderate complexity but improves accuracy substantially.
I worked on a project where we neglected the J2 effect and predicted orbit plane drift correctly within five degrees per year. The actual measurements showed fifteen degrees per year. The discrepancy was entirely due to the equatorial bulge. Adding the perturbation term brought the prediction in line with observations. That was a costly lesson in verifying which terms matter for your specific application.
Verification Strategies
Always compare your numerical results against known analytical solutions when possible. Circular orbits have exact solutions. Elliptical orbits follow Kepler laws with predictable period-semimajor axis relationships. If your simulation deviates from these expectations without an identified perturbation, check your implementation before assuming the physics is wrong.
Energy conservation is your best diagnostic. Total mechanical energy should remain constant in a closed two-body system. Plot it over time. Drift indicates numerical error. Sudden jumps indicate a timestep or singularity issue. Angular momentum conservation is another independent check. Both should be verified separately because one can be conserved while the other drifts.
For multi-body systems, compare against established ephemeris data when available. JPL Horizons provides highly accurate planetary positions. If your propagator diverges from ephemeris predictions over long timescales, identify whether the divergence is due to missing perturbations, numerical error, or initial condition uncertainty. The sources of error often compound in different ways depending on your setup.
The bottom line is that Newton S Universal Law Of Motion remains one of the most useful approximations in classical mechanics, but it has clear boundaries. Use it where it applies, verify your implementation, understand when to upgrade to more sophisticated models, and do not trust black box simulations without independent verification. The physics is elegant, but the engineering requires careful attention to detail.
Gallery Newton S Universal Law Of Motion
Newtons Laws Of Motion Clipart Newton Law Stock Illustrations – 978
Newton Laws Of Motion Newtons Laws Newtons First Law Newton's 1st
Vektorová grafika „Newton’s Law of Motion infographic diagram with examples of Football, hard ...
Newtons law of motion - gulucycle
Poster Newton’s Law of Motion infographic diagram with examples of Football, hard box a ...