What Actually Keeps Things Moving
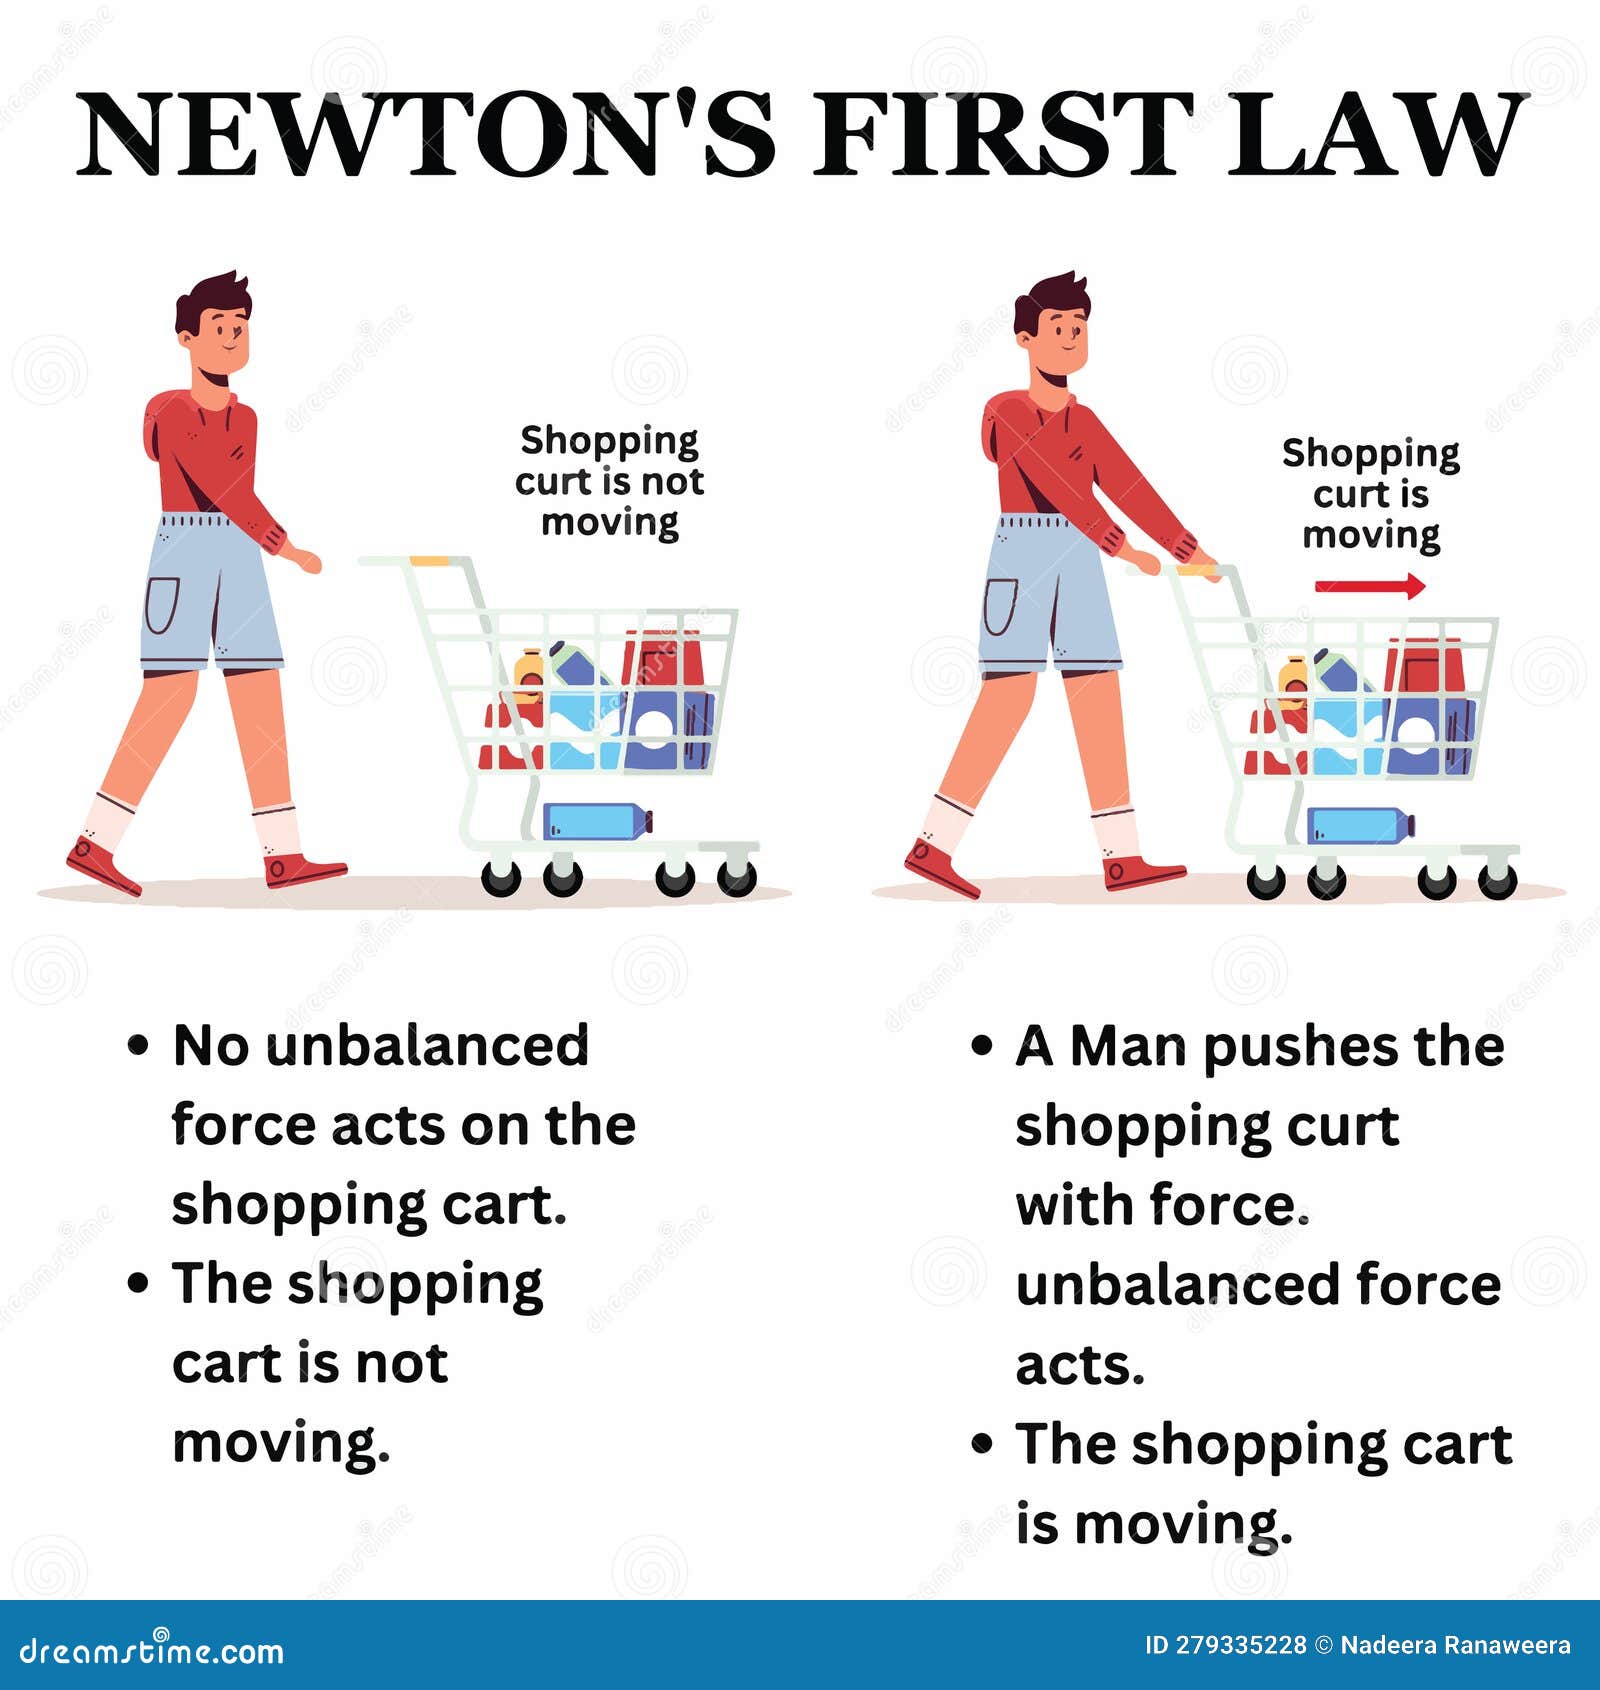
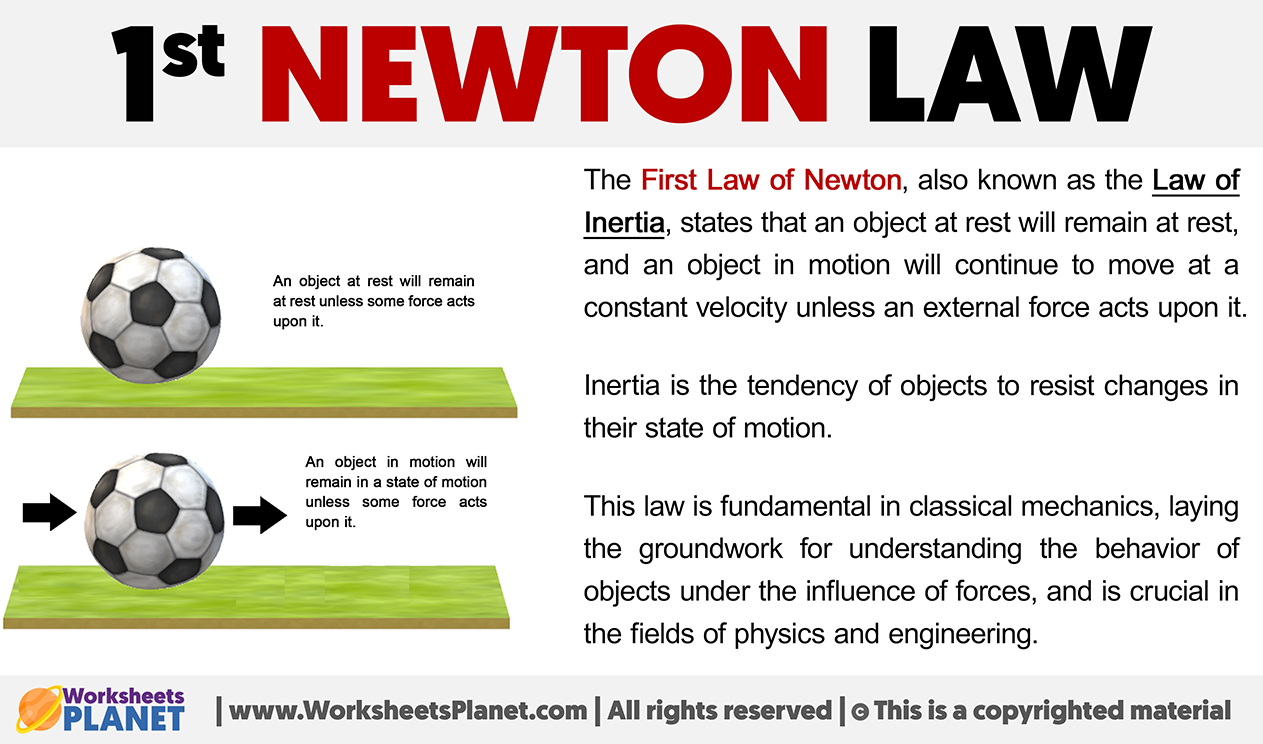
Newtons First Law Of Motion states that an object at rest stays at rest and an object in motion stays in motion with the same speed and in the same direction unless acted upon by an unbalanced force. That is the textbook version. The version you actually use when building anything that moves involves a lot more friction than the textbook admits. The first thing people get wrong is treating this law as just a definition to recite. It is really a tool for drawing free body diagrams and checking whether your assumptions about forces are sane. I once spent three days debugging a conveyor system where a 45 kilogram metal plate was supposed to slide smoothly across a polyurethane belt. The plate kept jerking forward instead of moving steadily. The issue had nothing to do with the motor being weak. It was kinetic versus static friction mismatch. The belt was accelerating faster than the static friction threshold could hold, the plate slipped, then caught again, then slipped again. That cycling between static and kinetic friction is what the first law describes in practice, not the clean constant velocity you see in problem sets. I solved it by adding a thin layer of textured rubber between the plate and the belt, which raised the static friction coefficient enough that the plate tracked with the belt instead of hopping. That changed the system from an oscillating jerk to a steady slide in about ten minutes. If you are designing anything that slides, rolling, or floats, spending an hour characterizing the actual friction coefficients of your materials will save you weeks of trial and error later. Datasheets lie about friction. Measuring it yourself does not take long if you have a simple spring scale and a flat surface.
When Inertia Matters More Than You Expect
People think of inertia as just mass resisting acceleration. It is more annoying than that. Inertia is also what makes things resistant to changes in direction, and that matters a lot in anything rotating or pivoting. A large flywheel does not just resist speed changes. It resists directional changes too, and that is why balancing rotating equipment is so much harder than balancing linear equipment. I worked on a vibration isolation project where a motor mounted on rubber isolators started self-exciting at certain speeds because the isolation system was not accounting for the gyroscopic precession of the rotor. The first law was still the foundation, but the moment you add rotation, the equations get longer and the intuitive shortcuts stop working. The workaround I used was treating the rotor as a gyroscope in the simulation rather than as a point mass. That shifted the resonant frequency calculations enough to let us move the isolator placement to a region where the coupling between vertical and lateral modes dropped below acceptable thresholds. Running those simulations took about two days on a basic laptop. Testing the physical prototype took another three. The final fix ended up being a simple change in isolator stiffness that cost under sixty dollars per unit.
The Limits of This Law
The first law works perfectly in inertial reference frames. It does not work in accelerating reference frames without adding fictitious forces, and that is where most people hit problems. If you are analyzing a vehicle braking and trying to figure out why a loose object slides forward, you need to either stay in the ground frame and account for the deceleration of the vehicle explicitly, or move into the vehicle frame and introduce a pseudo force. Both approaches give the same result. Picking the wrong one without adjusting your math is what causes errors in real designs. Another limitation is that the law assumes rigid bodies or at least clearly defined centers of mass. Flexible structures, fluids, and compliant mounts do not behave like point masses, and applying the first law directly to those systems will give you answers that look correct on paper but fail in practice. For flexible systems, you need to switch to distributed parameter models or finite element analysis. The first law still underpins everything, but it is no longer the whole story.
Get the Full Details
A Practical Checklist
Before running any calculation involving Newtons First Law Of Motion, verify these items. Confirm your reference frame is inertial or that you have added the appropriate pseudo forces. Characterize friction for your actual materials instead of trusting published values. Separate static from kinetic friction and check whether your system crosses the transition during operation. For rotating parts, include gyroscopic effects if the angular velocity is significant relative to the support stiffness. For flexible components, recognize when a rigid body assumption breaks down and move to a distributed model. This checklist cuts the typical iteration cycle from several rounds of testing down to one focused round, usually reducing development time by roughly half for mechanical systems in the size range I deal with.