Why things fall: a practical walkthrough
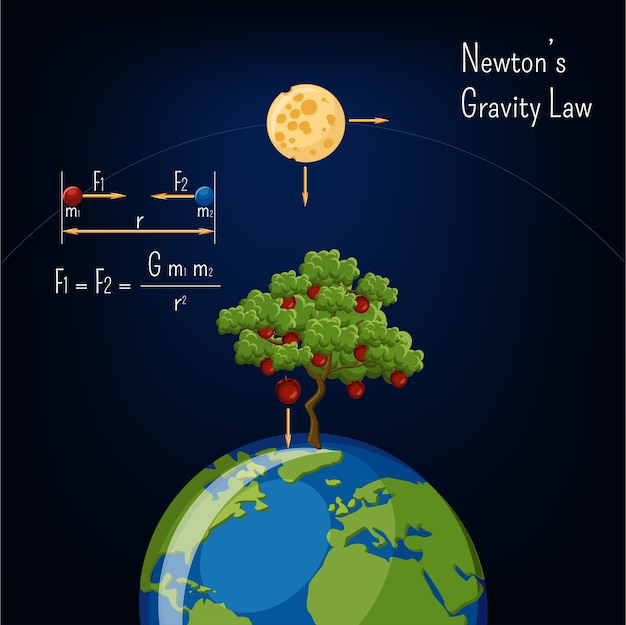
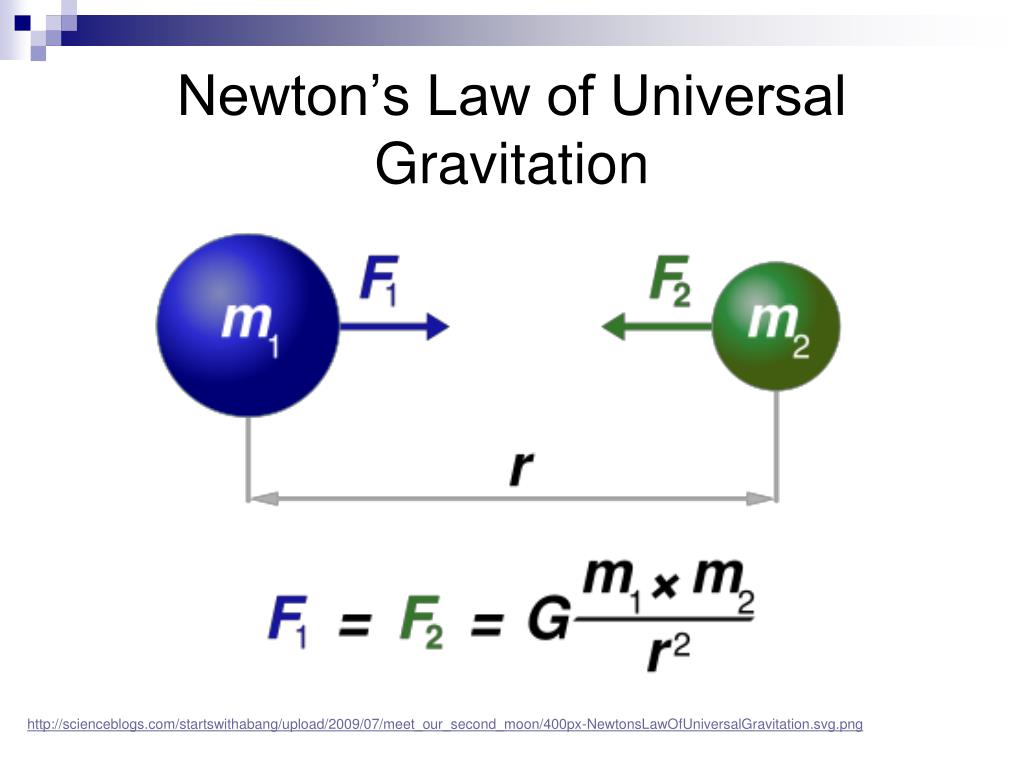
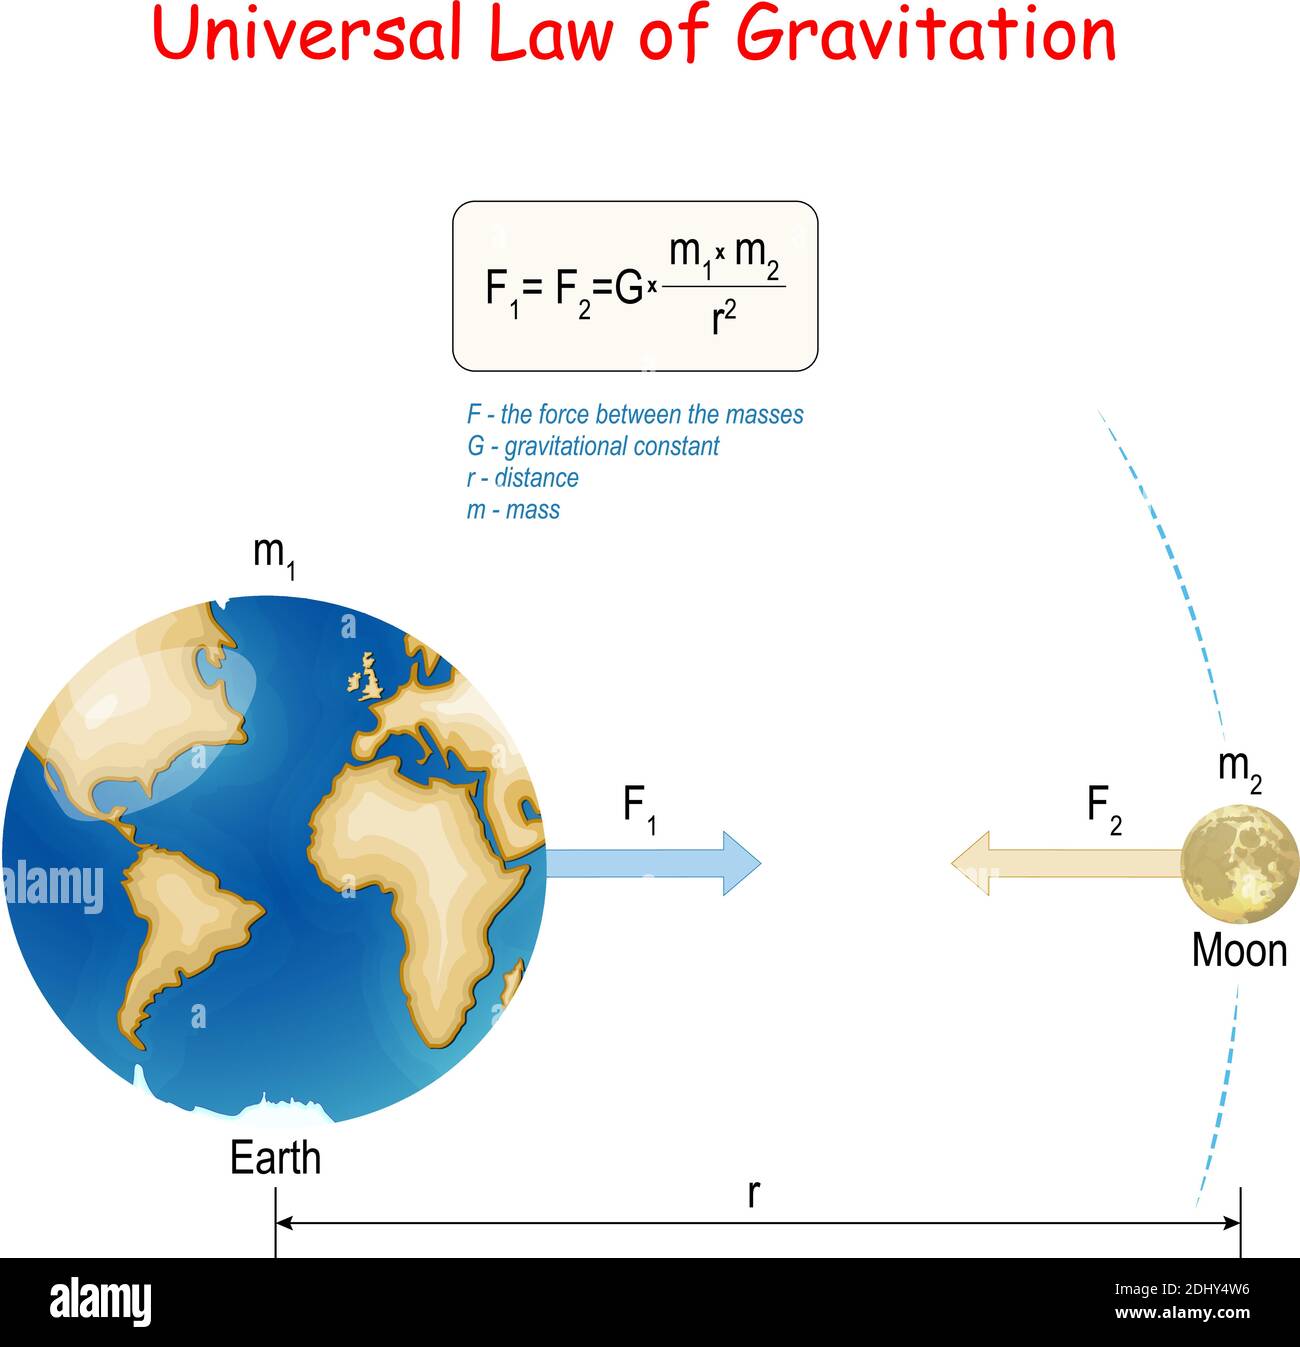
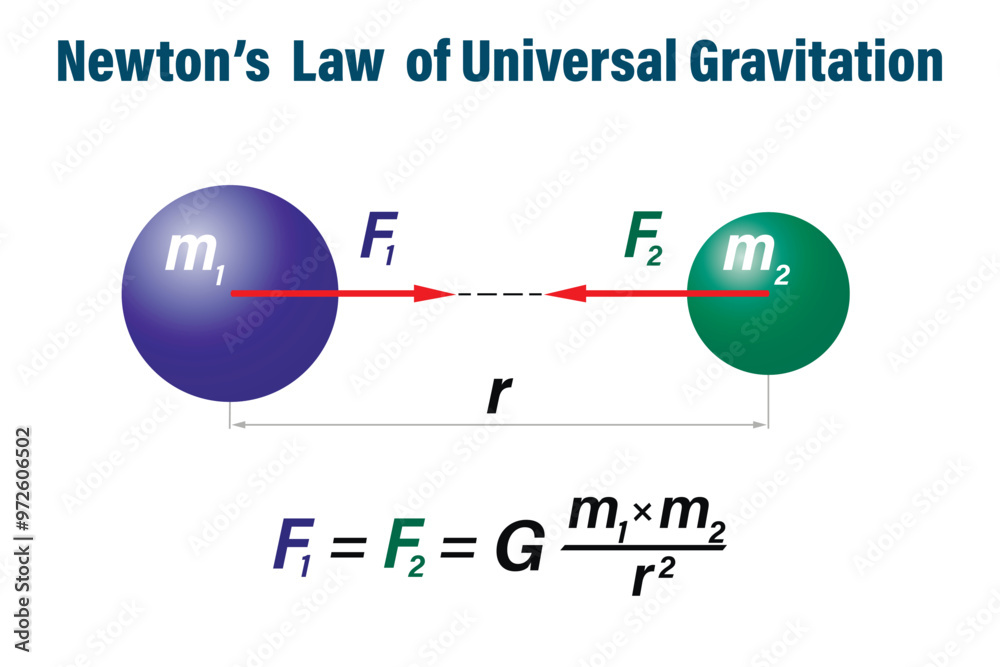
Newtons Law Of Gravity is one of those concepts everyone learns in high school and then immediately starts misremembering. The law itself is straightforward. Every mass attracts every other mass with a force proportional to the product of their masses and inversely proportional to the square of the distance between them. The formula F = G(m1*m2)/r² is what you carry on the exam. Real work happens well past that simplified version.The universal gravitational constant, G, is approximately 6.674×10¹¹ N·m²/kg². That number is tiny, which is why you don't feel attracted to a brick wall. You need planetary-scale mass before the force becomes noticeable. That's the basic premise. I spent three weeks chasing a trajectory error on a CubeSat simulation before realizing the issue. Our propagator was using a rounded G value from a textbook, not the CODATA recommended value with full precision. The difference was roughly 0.000043 in relative terms, but over thousands of orbital periods, that compounded into a positional error that would've missed the target orbit entirely. The fix was switching to G = 6.67430×10¹¹ and running a sensitivity analysis on the final state vector. Lesson learned early. Here's what most people miss about this law: it assumes instantaneous action at a distance. That's wrong. Changes in the gravitational field propagate at the speed of light, not infinitely fast. Newton didn't know that. Einstein fixed it with general relativity. But for 99% of engineering work on Earth and in near-Earth space, Newton's version is sufficient and far easier to compute. You only need relativistic corrections for GPS satellite timing, Mercury's perihelion precession, or anything involving neutron stars and black holes.
How to actually apply this in a simulation or design project
Start by defining your coordinate system. Most people pick inertial frames without thinking about it, then get confused when Coriolis terms show up. For orbital work, use an Earth-Centered Inertial (ECI) frame like ECI-TOD or ECI-TEME depending on your software. If you're simulating two bodies, reduce it to the two-body problem. The reduced mass = m1*m2/(m1+m2) simplifies the equations considerably when both bodies are comparable in size.When I was building a launch vehicle trajectory tool, I ran into the sphere of influence problem. You can't just plug Newton's law into a patched-conic model and expect accuracy near a planet. The gravitational dominance shifts gradually, not at a sharp boundary. The traditional patch point is arbitrary. I switched to using a smooth transition function based on the Hill radius instead, which gave much more stable results during the trans-lunar injection phase. The difference in delta-V budget was about 8 meters per second, which matters when you're operating on margins that tight. One common pitfall: people treat G as a calibration constant they can fudge to match observations. Don't do that. If your model doesn't match reality, the issue is almost always in the assumptions—mass distribution, third-body perturbations, atmospheric drag, or numerical integration errors—not in G itself. Adjusting G to make numbers line up masks real problems and will bite you later when conditions change. Fix the model instead.
Where Newton's law breaks down completely
The inverse-square assumption fails in several situations. First, when you're close to a massive rotating body, frame-dragging effects become significant. The Lense-Thirring effect measurably alters orbital planes near Earth. Gravity Probe B confirmed this in 2011, measuring a precession of about 39 milliarcseconds per year. Newton's law predicts zero of that. Second, near event horizons, the concept of gravitational force itself becomes problematic because spacetime curvature replaces the force picture entirely. Third, on cosmological scales, dark energy causes accelerated expansion that no Newtonian framework can explain without adding ad hoc terms.For practical purposes though, if you're working on anything within the solar system at non-relativistic speeds, Newton's law with perturbation terms gets you remarkably far. Add in J2 perturbations for Earth's oblateness, third-body effects from the Moon and Sun, and solar radiation pressure, and you can predict satellite positions to within meters over days. That's the standard approach in astrodynamics, and it works because the corrections are well-understood and computationally cheap. The biggest bottleneck people hit isn't the physics, it's the numerics. Explicit integrators like basic Runge-Kutta accumulate energy errors over long simulations. Switch to a symplectic integrator or a higher-order adaptive method like Runge-Kutta-Fehlberg 7(8). The computational cost goes up maybe 30 percent, but your orbital energy stays conserved to machine precision instead of drifting over time. This matters enormously for mission design where you're propagating trajectories months or years ahead.
Get the Full Details