What PLC Motor Control Actually Looks Like on the Floor
You pick up a training program and it promises you will go from zero to running a VFD in an afternoon. That is not how it works. Real Plc And Motor Control Training involves learning why the contactor is still energized after the program says stop, why the interlock did not do what you expected, and why the motor runs in reverse when the HMI button says forward. I spent three weeks on a packaging line where the Siemens S7-1200 kept tripping the safe torque off on a Bosch Rexroth IndraDrive. The fault only appeared after forty minutes of continuous cycling. The manual said nothing about thermal drift in the digital input module. I traced it to a 3ms pulse from a mechanical relay that barely cleared the debounce threshold. The workaround was adding an explicit timer block and re-rating the safety chain. That is the kind of thing no quick-start guide covers.
Plc And Motor Control Training: What You Actually Need to Learn
The core material falls into four buckets that overlap more than textbooks admit. First, you need ladder logic or structured text that can handle real timing. Not the textbook one-second delay, but actual scan-time-aware code that does not leave a window where a motor can restart during a fault condition. Second is the power side. Contactors, overload relays, VFD parameter sets, torque limits, regenerative braking. You need to understand why a 15 kW motor with a soft starter draws different inrush current than the same motor through a vector drive, and how that changes your breaker sizing and thermal protection settings. Third is the safety layer. ISO 13849 performance levels, Category 0 versus Category 1 stopping, safe torque off functions. Most training programs gloss over this. They show you a stop button that lights up. They do not show you what happens when the safety relay welds contacts due to coil arcing from an undersuppressed flyback diode on a 24 VDC circuit.
Fourth is the commissioning process. Tuning a PID loop for a pump that has variable head pressure. Matching encoder feedback to a motion profile. Setting up CANopen or EtherNet/IP parameter maps. This is where training separates into theory and practice very quickly.
Get the Full Details
The Programming Side: How It Actually Works
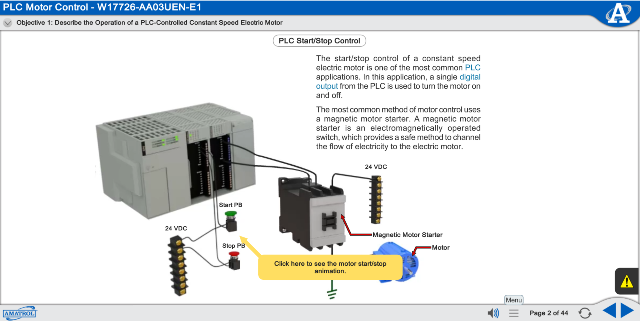
Start with a simple motor start stop circuit using a PLC. Most beginners write a latching rung that keeps the output on after the start button releases. The problem is that this does not handle the case where the stop button is a momentary contact wired to a safety circuit that expects a proven safe state. I worked on a conveyor system where the Allen-Bradley CompactLogix kept dropping the run output when the operator hit the E-stop. The logic was correct in simulation. It failed because the E-stop circuit used a two-channel safety relay with cross-monitoring that required both channels to open within 50 ms. The third-party E-stop button had a mechanical bounce of about 15 ms per contact, which caused the cross-monitor to detect a mismatch and latch the fault. The fix was adding a hardware RC snubber across the button contacts and adjusting the relay debounce time in the safety module parameters. Here is a basic structure that actually handles this correctly.
Rung 1: Start conditions Network 1 checks that the motor is not already running, the safety circuit is valid, and the start command is asserted. The start command must be edge-triggered so a held button does not cause a retrigger on every scan cycle. The motor run bit then latches through a seal-in contact that is gated by the same conditions. Rung 2: Stop and fault handling
Network 2 monitors the stop command, overload trips, and safety faults. Any of these conditions immediately de-energize the motor run bit and set a fault latch that requires a manual reset. The reset must be explicitly requested through a separate input so the motor cannot restart without operator acknowledgment. This is non-negotiable for any application above Category B. Rung 3: VFD command mapping Network 3 translates the PLC logic into VFD control words. The run command becomes a parallel command to the VFD start input. The direction bit becomes the forward reverse input. The frequency reference becomes an analog output or communication parameter. Most beginners skip this mapping and wire the PLC directly to the VFD. This causes problems when the VFD expects a specific protocol like Modbus RTU or CANopen instead of simple discrete I O.

The Power Side: What You Cannot Skip
Motor control training falls apart if you ignore the electrical side. A PLC output cannot drive a 15 kW motor directly. You need contactors, overload relays, and a VFD or soft starter. Each component has specifications that affect the others. The contactor must be rated for the motor full load current plus a service factor. For a 15 kW 400 V motor, that is about 30 A nominal. With a 1.15 service factor, you need a contactor rated for at least 35 A. Most beginners size the contactor for the nameplate current and skip the service factor. This causes contact welding under repeated starts, especially with high inertia loads. The overload relay must match the motor thermal curve. Electronic overload relays offer adjustable trip curves and ground fault protection. Thermal overload relays are simpler but less accurate. For a training program, electronic overloads teach better because you can adjust the trip curve to match the motor ANSI NEMA design class.
VFD parameterization is where most training programs fail. The VFD manual lists hundreds of parameters. Most are irrelevant. The critical ones are acceleration deceleration times, current limits, torque boost, and slip compensation. Wrong acceleration time causes overcurrent faults during ramp up. Wrong current limit causes nuisance tripping during load transients. Wrong torque boost causes motor heating at low speed. Wrong slip compensation causes speed regulation errors under variable load.
Safety Systems: The Part Everyone Rushes
Safety circuit training usually gets a single chapter in the course manual. It should get three. The reason is that safety circuits behave differently than regular control circuits under fault conditions. ISO 13849 defines four performance levels from a to e. Category 0 stopping means uncontrolled stop by removing power to the motor driving equipment. Category 1 stopping means controlled stop followed by power removal. Most applications require Category 1. The difference matters when a motor coasting into a hazard is worse than a hard stop. I trained a maintenance team on a robotic cell where the safety circuit used a two-channel safety relay with redundant contact pairs. The relay had a built in self test function that monitored contact welding. The self test ran every 5 seconds by briefly opening one channel and checking the other responded. The problem was that the contactor coil had a hold in current of 80 mA but the self test only sourced 50 mA during the test pulse. The relay detected a fault on every self test cycle and latched a safety stop. The fix was upgrading the relay to a model with 100 mA test current and reparameterizing the safe torque off function to use hardware interposing relays instead of software monitoring.

Commissioning: Where Training Becomes Real
The final stage of Plc And Motor Control Training is commissioning. This is where you connect the PLC to the motor and see if everything works. Most programs fail here because the training was too focused on theory. PID loop tuning for a pump station is a good example. You need to set the proportional gain, integral time, and derivative time. Too much gain causes oscillation. Too little gain causes slow response. Integral windup causes overshoot during setpoint changes. Derivative kick causes noise sensitivity. The Ziegler Nichols method gives you starting values. You then adjust based on actual process response. Encoder feedback matching is another common problem. The PLC must know the encoder pulses per revolution, the gear ratio, and the unit of measure. Wrong pulses per revolution causes incorrect speed calculation. Wrong gear ratio causes incorrect position calculation. Wrong unit of measure causes incorrect motion profile execution. Most encoders have 1024 pulses per revolution for standard applications. High precision applications use 10000 or more. The PLC encoder input must be configured for the correct resolution.
Network configuration is the final hurdle. EtherNet/IP, Profinet, Modbus TCP, CANopen. Each protocol has different message structures, update rates, and error handling. Most beginners copy a network configuration from a previous project. This fails when the new device uses a different message format or requires a specific parameter set. Always verify the device communication manual before deploying a network configuration.
Common Pitfalls and How to Avoid Them
Most Plc And Motor Control Training failures come from the same root causes. I have seen the same mistakes repeat across dozens of projects. The first mistake is ignoring scan time. A PLC scan takes 10 to 100 ms depending on the program size. If your motor control logic assumes instant response, it will fail under load. Always test your program with a logic analyzer or trace tool to measure actual response times. The second mistake is skipping the wiring diagram. I have seen technicians wire a motor control circuit from memory. The result was always wrong. Always follow the wiring diagram. Verify each connection with a multimeter before powering up.

The third mistake is not documenting parameter changes. When you adjust a VFD parameter or PLC timer value, record the change in a log. Future troubleshooting depends on knowing what was modified and when. A parameter changed six months ago can cause a fault today. The fourth mistake is underestimating ground faults. A motor cable run across a facility often picks up induced voltage from nearby power cables. This causes ground fault trips that appear random. Use shielded cable and verify ground continuity at both ends. A ground fault tester can find insulation problems that a multimeter misses.
What Good Training Actually Looks Like
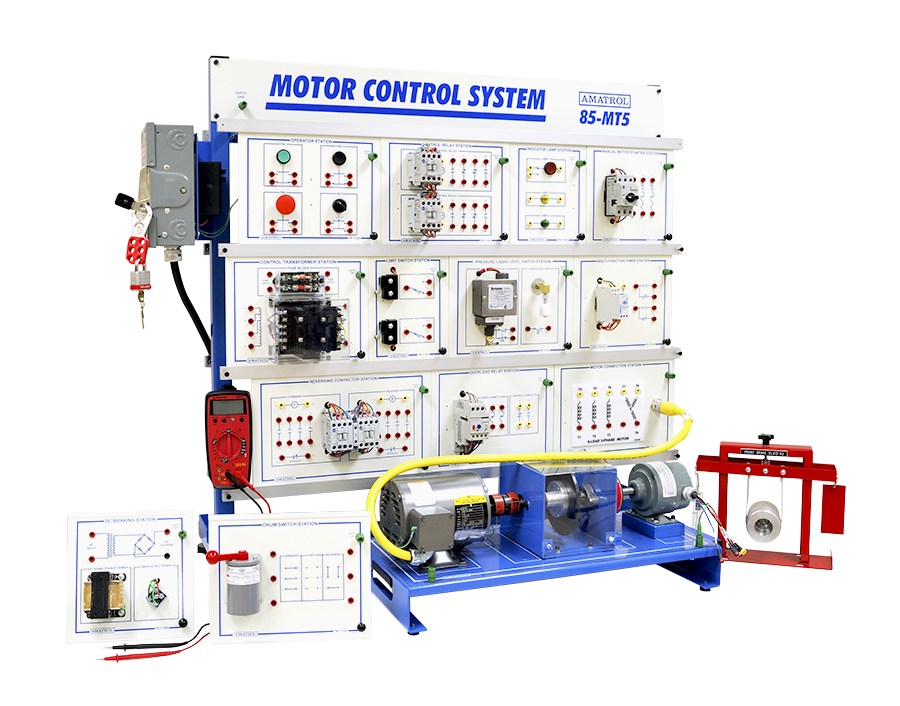
The best Plc And Motor Control Training programs share a common structure. They start with the basics and build up to real applications. They include hands on labs where you wire a circuit, program a PLC, and commission a motor. They cover safety systems as a core subject, not an afterthought. They include troubleshooting exercises that simulate real faults. Online resources like manufacturer training portals, YouTube channels, and technical forums can supplement formal courses. SIEMENS offers free S7-1200 training modules. Allen Bradley provides CompactLogix labs through Rockwell Automation University. Bosch Rexroth publishes IndraDrive parameter guides that cover most application scenarios. Physical training kits are worth the investment. A basic kit includes a PLC, a VFD, a contactor, an overload relay, a motor, and wiring accessories. The cost ranges from two thousand to five thousand dollars depending on brand and capacity. The ROI comes from reduced downtime when you can troubleshoot a motor control circuit without calling a consultant.
Real world experience cannot be replaced. Every project teaches something new. A motor that trips on overcurrent might need a slower acceleration ramp. A PLC that drops outputs under vibration might need DIN rail mounting instead of panel mount. A VFD that generates electromagnetic interference might need a line reactor or filtered power supply. The field does not care about your certification. It cares whether the motor runs when you press start and stops when you press stop. Good training gets you to that point reliably. The rest is just practice.