Getting Started With RSLinx and the 5000 Environment
RSLogix 5000, now called Studio 5000 Logix Designer, is the programming environment for Allen-Bradley CompactLogix, ControlLogix, and GuardLogix controllers. It has been around since the mid-2000s. If you are coming from Ladder Logic in the older RSLogix 500 world, the jump is not huge but there are enough structural differences that you will burn a weekend figuring them out. The good news is that the core concepts translate directly. The bad news is that Rockwell changed enough naming conventions to make Googling a pain. You need three things before anything else: the software, the RSLinx Classic communications driver, and a valid license key. Studio 5000 runs on Windows 10 or 11, preferably 64-bit. The license part is where people trip up. Rockwell moved to a Sentinel USB key system years ago. If you are buying used or borrowed software off a forum, it will not work unless the dongle is included. The free 30-day evaluation does not require a key and is perfectly fine for learning the interface, but you cannot download code to a real controller without an activated license.
Plc Programming With Rslogix 5000: What It Actually Looks Like
PLC Programming With Rslogix 5000 is organized around projects, tasks, programs, and routines. That hierarchy matters more than you might think at first. A project is the top container. Inside it you define tasks, which are scheduling containers. Tasks hold programs, and programs hold routines. When you place a timer or an counter inside a routine, it lives there until you move it. The scheduler decides when each task runs, and within a task the program executes top to bottom unless you use branches or calls. Understanding this structure early saves you from debugging something that looks wrong but is actually just a scheduling issue. The programming language support includes ladder logic, structured text, function block diagram, and sequential function chart. Most people in the field stick with ladder because it is what they were trained on. Structured text is available and useful for math-heavy or string-based logic, but it is rarely the primary language on a factory floor. Sequential function chart is powerful for batch processes but underutilized because most engineers do not know how to use it properly. Here is a practical example. Say you are building a conveyor sort system. You create a project, add a ControlLogix processor, define a periodic task at 100 milliseconds, put a MainProgram inside it, and then create routines for StartStop, ConveyorLogic, and FaultHandling. You rung-call StartStop from the main program and call ConveyorLogic next. Every routine is separate. This keeps things readable when the file grows to a thousand rungs. You do not want a single routine with five hundred rungs unless you enjoy hunting for bugs at 2 AM.
Connecting to the Controller
RSLinx Classic is the communications layer between your PC and the PLC. Without it working, nothing else matters. Open RSLinx, go to Communications > Configure Drivers, and add the AB EtherNet/IP Driver. Set the port to default and scan your network. If your PLC is on a known IP, you can also type it in manually rather than scanning the whole subnet, which is faster and less noisy on busy networks. Once the driver is running, you need a virtual node in the tree. Right-click the driver, add a new module, and type the IP of the PLC. After a few seconds the scan should show the backplane path. If it does not, check that your PC and PLC are on the same subnet and that no firewall is blocking UDP port 44818. That is the CIP port. It is easy to overlook because firewalls sometimes allow TCP traffic and block UDP on the same rule set, and then you spend two hours wondering why the software sees the controller on the network but cannot talk to it. To establish communication from Studio 5000, go to Communications > Download Communication Settings or select the target processor and choose to go online. If the software connects, the controller state will show as Remote Program or Run depending on its current mode. If you cannot connect, verify the slot configuration matches what is physically in the rack. An I/O assembly mismatch will prevent online access even if the network path is correct.
Get the Full Details

Creating Your First Routine
Start simple. Create a new project for a CompactLogix 5380L3 controller. The processor comes with some default folders already present. Right-click the Programs folder and insert a new program called MainControl. Inside that program, add a routine named StartStop. Double-click the routine to open the ladder editor. At the top of the rung, add an XIC instruction and assign it to a boolean tag called StartButton. Add another XIC for StopButton but use the negated form by right-clicking and selecting Invert, or just use a XIO instead. On the same rung, add an OTE coil labeled MotorRun. That is a latched start-stop circuit. The problem is it does not latch yet because you did not add a seal-in contact. Add a second rung with an XIC on MotorRun and an OTE on MotorRun again. This time, when you click into the address field of the XIC, type MotorRun and confirm. The compiler will create the tag if it does not exist. Rockwell's tag creation is automatic in most cases, but it can be annoying when you are typing fast and create a tag with a slightly wrong name. Always check the Tag Database after writing a few routines to catch typos. Download the program to the controller. Switch the processor to Program mode first, then download. If the controller is in Run mode, Studio 5000 will warn you and may force a mode switch. The download time depends on project size. A small routine like this takes about three seconds. A full plant-wide project with fifty programs and thousands of tags can take fifteen to twenty minutes. Do not walk away during a large download.
After the download completes, switch the processor to Run mode and test the logic. Press StartButton and MotorRun should energize. Press StopButton and it should de-energize. If it does not, check the I/O status panel in Studio 5000 to see the live values of each tag. The online monitoring feature shows rung execution in real time. Energized instructions turn green. This is far more useful than adding debug output tags and waiting for the next scan cycle.
Tag Management and Data Types
Tags are where most projects either stay clean or become unmanageable. Studio 5000 uses a centralized tag database. You can create tags individually or import them from Excel, which is the realistic workflow for anything larger than a demo project. Rockwell provides a template format for Excel imports that works reliably if you follow the column structure exactly. The common data types you will use are BOOL, INT, DINT, REAL, and STRING. BOOL is for discrete I/O and internal bits. INT is a 16-bit signed integer. DINT is 32-bit signed and is the default for most counters and timers. REAL is floating point and takes four bytes. STRING is variable length and limited to 8192 characters in Logix controllers, though typical usage stays well under that. Avoid using STRING tags for high-speed logging. They are slow compared to array-based approaches. One thing beginners miss is that tag scope matters. A tag created inside a program is local to that program unless you make it global. Local tags cannot be accessed from other programs. This is intentional and prevents namespace collisions, but it also means you need to think about where a tag lives before you create it. If you find yourself referencing a tag from multiple programs, make it global from the start instead of creating duplicates and trying to synchronize them later. Duplicate tags are the easiest way to introduce a logic error that takes hours to find.
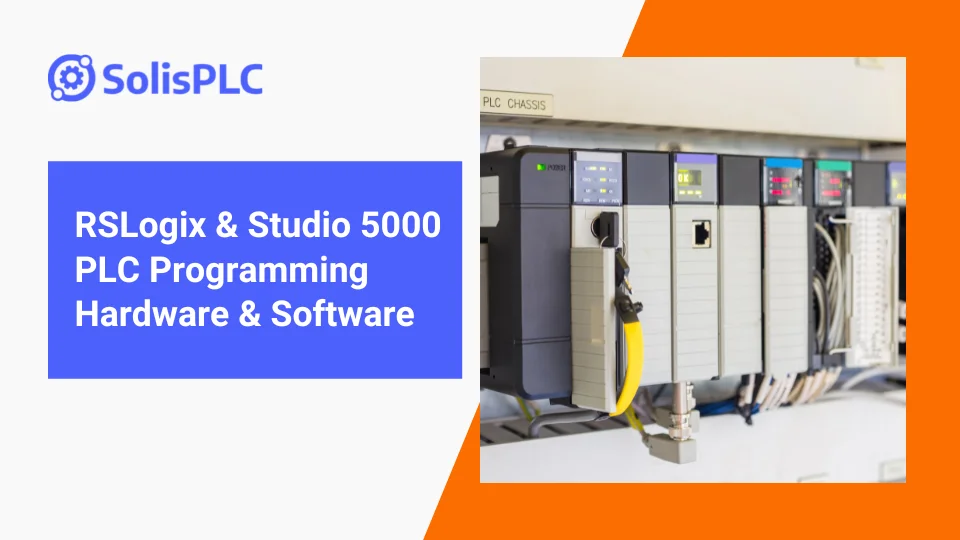
Allen-Bradley also supports user-defined data types. If you are managing a motor with several properties like status, fault code, speed reference, and run command, create a UDT called MotorData and instantiate it. This keeps your ladder logic cleaner and your tag database organized. A well-designed UDT structure reduces routine complexity significantly compared to scattering individual tags everywhere.
Common Pitfalls and What I Learned the Hard Way
I spent an entire shift once trying to debug a logic issue where an output would not stay energized. The latch contact looked correct. The start signal was present. The coil was addressed properly. The problem turned out to be that the routine was being called inside a conditional branch that only closed during certain timing windows. The routine executed correctly when it ran, but it did not run every scan because the branch condition was false part of the time. I had overlooked the branch entirely because I was looking at the routine in isolation. This happens all the time. Always check the calling context, not just the routine itself. Another issue that comes up repeatedly is the difference between instructions that execute conditionally and those that do not. An OTE only writes when the rung is true. An OTL and OTU are latch and unlatch instructions that set or reset a bit regardless of rung truth on subsequent scans. Mixing these up causes outputs to behave erratically. If you need a bit to stay set until explicitly cleared, use OTL and OTU. If you need it to follow the rung logic, use OTE. This is basic but it is surprising how often it comes up in code reviews. Timer accumulation is another area where people get burned. The TON timer accumulates elapsed time while the enable bit is true. If you reset the timer by negating the enable, the accumulated value holds. Some engineers expect the timer to reset automatically when the enable goes false. It does not. You have to explicitly reset the ACC or use the RTO timer if you want retention across power cycles, though retention requires a battery-backed or non-volatile memory configuration on the controller.
Limitations You Should Know About
Studio 5000 is not free, and the licensing model is frustrating. Rockwell sells it per feature set and per version. Upgrading your software version does not automatically let you open projects made in a newer version. A project created in Studio 5000 version 34 cannot be opened in version 32. This is a real constraint if you work with multiple sites that run different software versions. You will need multiple licenses or a standardized version policy across your organization. The software is resource-heavy. It runs slowly on older laptops. You will want at least 16 gigabytes of RAM and a solid-state drive. Opening a large project with thousands of tags and dozens of programs on a machine with 8 gigabytes and a spinning hard drive is painful. Compilation alone can take several minutes. This is not a minor inconvenience. It affects your daily workflow noticeably. Another limitation is the lack of native support for non-Rockwell hardware. If your system includes third-party drives, vision systems, or safety controllers from other vendors, you will rely on Modbus TCP or Ethernet/IP generic messaging to communicate with them. Generic messaging works but it is clunky compared to dedicated library support. You have to manage message polling, timeout handling, and error recovery yourself. For simple data exchange it is fine. For complex interoperability it becomes a maintenance burden.

There is also the issue of backup and version control. Studio 5000 projects are stored as files with a .APD extension. These files are not source-controlled by default. If you are working on a team, you need a separate version control process because two people editing the same project file will corrupt it. I have seen this happen. The workaround is to use a shared network drive with strict check-out procedures or migrate to a source control system like Git with a custom merge strategy, which is non-trivial for binary project files.
Alternatives Worth Considering
If you are starting a new project and do not have a legacy Allen-Bradley constraint, Codesys-based environments like Schneider Electric’s Unity Pro or Beckhoff’s TwinCAT offer similar functionality at lower licensing cost. TwinCAT in particular has a very capable integrated development environment and supports IEC 61131-3 natively across all five languages. Beckhoff hardware is more expensive upfront but the software side is considerably less restrictive for multi-site deployments. For small systems where ControlLogix is overkill, the Micro800 series with Connected Components Workbench is simpler and cheaper. It lacks the advanced features of Studio 5000 but covers the basics well. If you are doing a standalone machine with under ten I/O points, Micro830 with CCW is the pragmatic choice rather than reaching for a ControlLogix setup. If your application is purely software-based or you are doing simulation-heavy work, Node-RED with Modbus nodes can handle basic logic prototyping without any PLC hardware. It will not replace a real controller for production, but it is useful for designing and testing logic before committing it to a physical system.
Practical Steps to Get Functional
Install RSLinx Classic and Studio 5000 from your Rockwell account portal. You will need a login tied to a purchased or trial license. The evaluation version from the Rockwell website is sufficient for learning. Create a new project for a CompactLogix 5370L3 controller. Define at least one periodic task at 100 milliseconds. Write a simple latching circuit with start, stop, and an output coil. Connect to the controller via RSLinx and download the program. Monitor the routine online while actuating inputs. Verify the output responds correctly. Once that works, add a timer. Create a TON timer with a preset of 5000 milliseconds and a 100-millisecond resolution. Hook the timer enable to a contact and the done bit to an output. Download and observe the timing. Then add a counter. Use a CTU with a preset of ten and tally pulses from a manual I/O point. Observe the accumulated value incrementing in the I/O status panel. From there you can expand into analog scaling with the NSR instruction, motion control with simple positioning blocks, and messaging for HMI communication. Each of these topics is its own deep dive. The foundation is solid once you understand the project structure, tag scope, and how the scanner interacts with your routines.

Rockwell's documentation is adequate but fragmented. The online help is better than it used to be but still jumps between topics without clear navigation. The Logix5000 Help PDF is the most reliable reference and covers instruction semantics thoroughly. Keep a copy bookmarked. When you hit an instruction behavior you do not understand, the manual entry for that instruction will usually clarify it within a paragraph. Searching forum posts for the specific symptom is often faster than reading the manual cover to cover, but the manual is more authoritative when you need to be certain.