Understanding How Helicopters Stay in the Air
Helicopter aerodynamics is one of those subjects where everyone thinks they understand it because they've seen a helicopter, and then they try to explain it and immediately run into contradictions. The main issue is that fixed-wing aerodynamic intuition fails you the moment you start thinking about rotors. A helicopter wing is constantly moving through the air in a circle, and that changes everything about how lift behaves. The core problem you're dealing with is that a rotor blade sees drastically different airspeeds depending on which direction it's pointing. When the blade moves forward into the relative wind, it's generating significantly more lift than the blade on the retreating side, which is moving away from the direction of travel. This asymmetry is what makes helicopter flight fundamentally different from airplane flight, and it's the reason helicopters have a hard ceiling and a maximum forward speed. In practice, the pilot manages this through cyclic input and collective pitch adjustments. The rotor disk tilts to direct thrust where needed, and the pitch of all blades changes together when you need more or less total lift. But there are secondary effects that most beginner resources completely skip over. Autorotation for instance, is not just an emergency procedure. It's the natural state of the rotor when the engine isn't driving it, and understanding how it works is essential for anyone who actually flies these machines rather than just studying them on paper.
I ran into a specific issue while working through flight dynamics simulations a few years back. I was modeling forward flight performance and kept getting unrealistic results at high forward speeds. The problem turned out to be compressibility effects on the advancing blade tip. At around 400 knots equivalent airspeed, which is well within the realm of what some modern helicopters can achieve, the airflow over the advancing blade tip approaches transonic speeds. The lift distribution shifts dramatically, and your standard incompressible flow assumptions break down completely. The workaround was switching to a blade element momentum theory combined with compressibility corrections for the advanced azimuth positions, which gave results much closer to actual flight test data. Another thing that trips people up is ground effect. You've probably noticed a helicopter seems easier to hover close to the ground. That's not because the air is different down there, it's because the ground plane interferes with the tip vortices and reduces the induced velocity through the rotor disk. Below about one rotor diameter, you get a measurable reduction in the power required for hover, typically somewhere between ten and twenty percent depending on the exact ground conditions and rotor design. Once you climb out of that zone, the power requirement increases noticeably, and pilots feel it immediately on the collective. Vortex ring state is another area where textbook explanations fall short of the practical reality. This happens when a helicopter descends into its own downwash, typically at descent rates above five hundred feet per minute with low forward speed. The rotor starts working in turbulent air that it just generated, and lift efficiency drops sharply. The old pilot trick of applying forward cyclic to escape is correct, but the underlying reason is that forward motion takes the rotor out of the disturbed air column and into relatively undisturbed air. Without forward speed, you're just recycling your own wake.
Retreating blade stall is the limiting factor for forward speed in most helicopter designs. As forward speed increases, the retreating blade has to operate at higher angles of attack to maintain symmetric lift production. At some point, that angle of attack becomes so high that the airflow separates from the upper surface of the blade, and you get a sudden loss of lift on that side of the disk. This manifests as a vibration and a rolling moment that gets progressively worse as speed increases further. The maximum forward speed of a typical utility helicopter sits somewhere around one to one and a half times the tip speed of the rotor, but the actual limit is usually set by retreating blade stall long before you hit any structural constraints. There's also the issue of dissymmetry of lift during translation, which is the reason the cyclic is needed even in a simple hover-to-forward-flight transition. When a helicopter starts moving forward, the blades that are on the advancing side of the disk see higher relative wind speeds than the retreating blades. Without some mechanism to balance this, the helicopter would roll violently. The flapping hinge or equivalent flexible system allows blades to move up and down, automatically adjusting their angle of attack through the rotation cycle. A blade flapping up sees a reduced angle of attack, and flapping down increases it, creating a natural stabilization mechanism. One counter-intuitive point that nobody seems to emphasize enough is that high altitude doesn't just reduce performance, it changes the fundamental aerodynamic behavior of the rotor. Air density affects both the mass flow through the disk and the Reynolds number of the blade sections. At high density altitude, the lower Reynolds number means poorer airfoil performance, more drag for the same lift, and a tendency for the boundary layer to separate earlier. This is why a helicopter that can hover out of ground effect at sea level might not be able to do it at elevation, even if the weight hasn't changed.
Get the Full Details
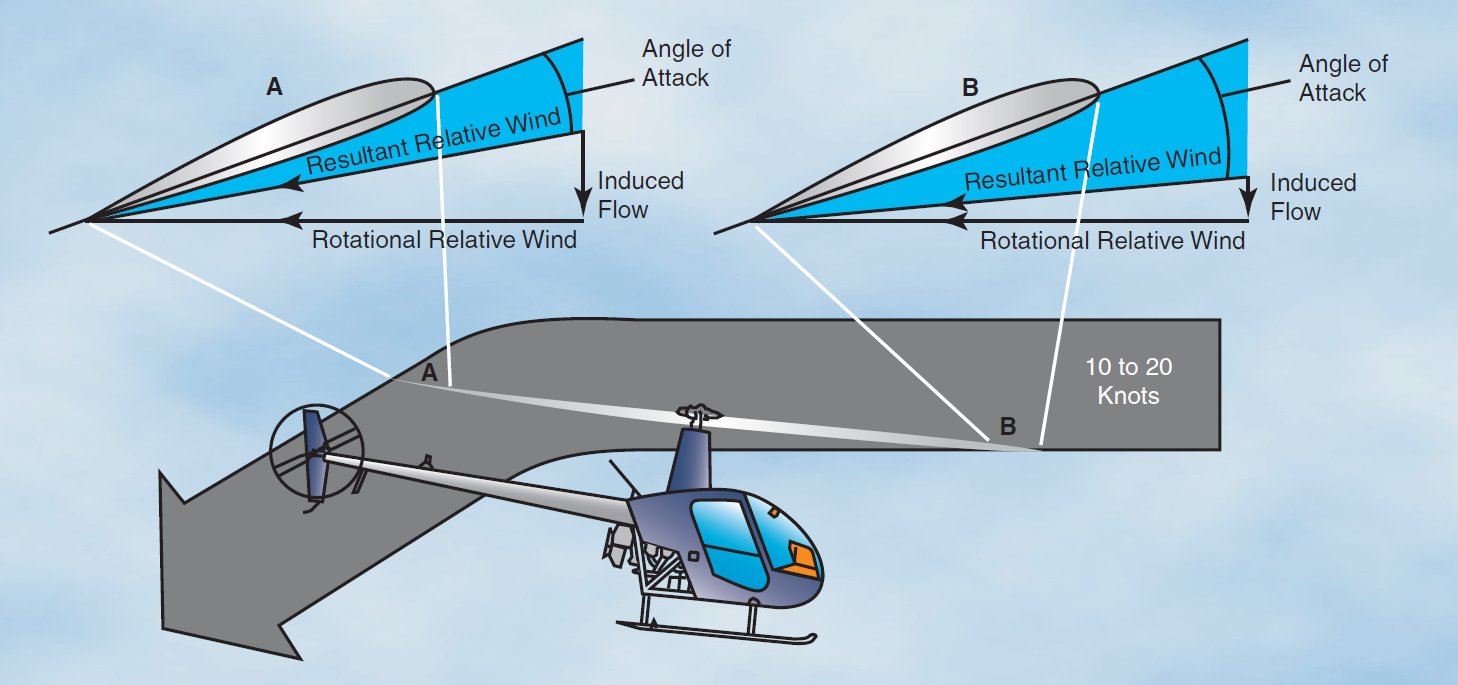
Teetering rotors versus hingeless rotors handle these forces very differently. A two-bladed teetering rotor, like you find on a Bell 206, relies on the entire rotor head oscillating like a seesaw to compensate for dissymmetric lift. This creates gyroscopic coupling effects that make the control response feel quite different from a four-bladed hingeless rotor system found on something like an AH-64. The teetering design is simpler and lighter but has a hard limit on how much lateral cyclic authority you can have without the blades hitting the stop. For anyone actually working with these principles, whether it's for simulation, design, or flight training, the useful takeaway is that helicopter aerodynamics is inherently three-dimensional and time-varying. Every blade element experiences a continuously changing angle of attack, airspeed, and flow direction as it rotates. Any analysis that treats the rotor as a simple actuator disk will miss critical phenomena like dynamic inflow, where the induced velocity through the disk doesn't change instantaneously with control inputs but lags behind due to the inertia of the air mass being accelerated. The lag in induced flow response is particularly important during maneuvers like rapid collective pulls or autorotative landing approaches. When you change the pitch of the blades quickly, the rotor disk doesn't instantly adjust its induced velocity field. There's a transient period, usually on the order of one or two rotor revolutions, where the induced flow is catching up to the new equilibrium. During that window, the helicopter can behave in ways that feel unpredictable if you're not expecting it.
If you're looking to go deeper into the mathematical treatment, blade element theory combined with momentum theory gives you a solid foundation, but you'll eventually need to account for wake effects, nonlinear inflow distributions, and compressibility corrections for any analysis that needs to be accurate across the full flight envelope. Simple models work fine for preliminary sizing and basic performance estimation, but they break down when you need to predict handling qualities or maneuver limits.