Direct Proportion vs Inverse Proportion.webp)
Working with Proportionality in Real Systems
I still remember the time I spent three days debugging a pressure transducer reading that looked completely fine at mid-range but was wildly off at the low end. The issue turned out to be that I was treating a nonlinear device as if it followed a straight proportional line. Once I stopped forcing the math and instead mapped the actual curve, the whole thing resolved in about twenty minutes. This is why getting the fundamentals right matters before you even touch code. Proportional And Inversely Proportional describes two of the most common relationships you will encounter in engineering, data processing, and basic system modeling. They are simple in theory, but they behave in ways that trip people up repeatedly once you move past textbook examples.
What Proportional Actually Means in Practice
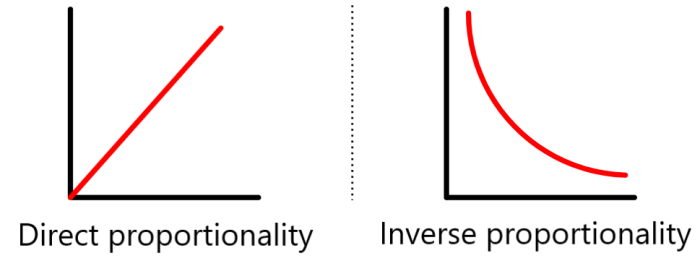
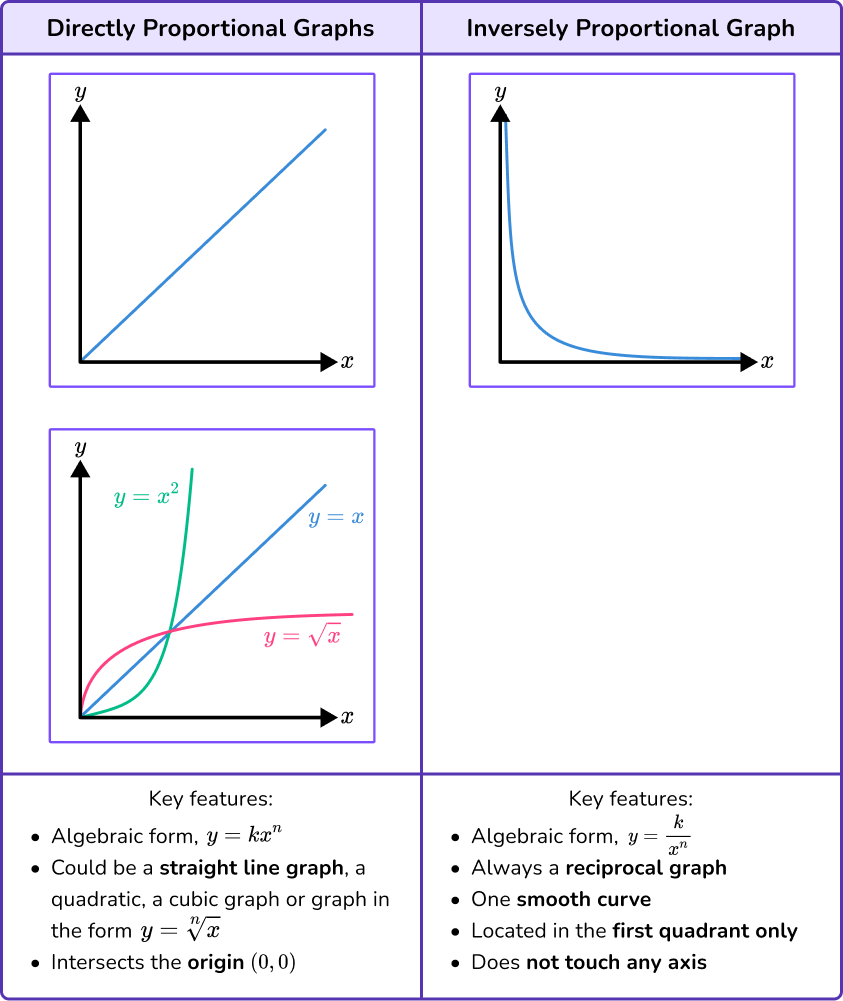
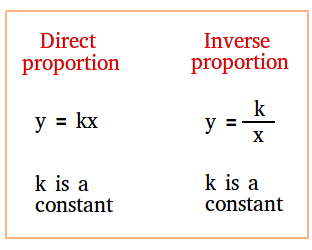
A proportional relationship exists when two variables change at a constant rate relative to each other. The mathematical form is straightforward: y equals k times x, where k is the constant of proportionality. If x doubles, y doubles. If x halves, y halves. There is no offset, no curvature, nothing else happening. But in the real world, very few physical systems are perfectly proportional across their entire operating range. What usually happens is that a system is approximately proportional within a defined window, and that window is often much narrower than you assume. I learned this the hard way with a flow meter that claimed a linear output. Between thirty percent and eighty percent of its range it behaved linearly. Below thirty percent, the relationship degraded noticeably due to internal friction and valve deadband. Above eighty percent, turbulence introduced a slight upward curve. The workaround I ended up using was simple enough. I mapped the full range against a calibrated reference, fit a piecewise linear approximation with three segments, and stored the coefficients in the controller. This added maybe five minutes of setup time but eliminated the systematic error across the entire range. It is not elegant, but it works consistently.
The constant of proportionality carries units. That detail is easy to overlook and easy to regret. If you are converting an ADC reading from a ten-bit register to a physical pressure value where the sensor spans zero to ten bar, the proportional constant is not just the number 0.00244. It is 0.00244 bar per ADC count. Mixing up the units is one of the fastest ways to produce a result that looks numerically plausible but is physically meaningless.
Get the Full Details
Inverse Proportionality and Why It Feels Counter-Intuitive
Inversely proportional relationships follow the form y equals k divided by x. The product of the two variables remains constant. As one increases, the other decreases in a hyperbolic curve, not a straight line. This is where people commonly make mistakes because the intuition that "one goes up and the other goes down" applies to many situations, but only inverse proportionality produces the specific hyperbolic shape. I worked on a project involving optical sensors where the received signal strength decreased inversely with the square of the distance from the source. The inverse-square law is well known in physics, but applying it operationally requires you to recognize that doubling the distance does not halve the signal. It reduces it to one quarter. A technician who assumed linear inverse behavior would end up with readings that were consistently wrong by a factor of four at doubled distances, and the error compounds rapidly at larger ranges. The same confusion shows up in control systems. Process gain is often not constant across operating points. A chemical reactor might have a proportional gain of 2.5 degrees Celsius per percentage point of heater output near the nominal setpoint, but that gain drops to 1.1 at lower temperatures and climbs to 4.8 at higher temperatures. Tuning a single proportional controller for the entire range without accounting for this variation produces oscillation at one end and sluggish response at the other.
Identifying Which Relationship You Are Dealing With
The most reliable method is to collect data across the full operating range and plot it. A proportional relationship produces a straight line through the origin. An inversely proportional relationship produces a hyperbola when plotted directly, but if you plot y against one over x, the result should be a straight line. This linearization trick is useful because it lets you verify the relationship type and extract the constant simultaneously. I typically use a spreadsheet for this kind of check, though any tool that can do basic scatter plots works. The process takes about ten to fifteen minutes for a dataset of reasonable size, and it prevents you from spending hours debugging an equation that was never the right model in the first place.
Common Pitfalls When Applying These Concepts
The first pitfall is assuming proportionality applies where it does not. Human bodies tend to project linear intuition onto nonlinear systems. This is especially common in temperature control, where thermal resistance and heat loss vary with temperature difference. A simple proportional controller will track reasonably well near the setpoint, but during large disturbances the error grows faster than the controller output can compensate, and recovery becomes slow and overshooting. The second pitfall is ignoring the boundary conditions of the proportionality constant. In instrument calibration, the constant is only valid within the manufacturer's specified range. Pushing beyond that range, even slightly, introduces errors that are not proportional anymore. The sensor may still output a value, but the underlying relationship has shifted, and applying the original constant gives you a number that looks precise while being systematically wrong. A third issue arises when combining proportional and inverse relationships. A system might have a component that is inversely proportional and another that is directly proportional, and the net effect depends on which dominates at a given operating point. I encountered this in a pump control application where flow rate was proportional to pump speed but the system head loss increased with the square of flow. The effective relationship between speed and delivered flow was neither purely proportional nor purely inverse, and treating it as either one produced consistently incorrect predictions.

When These Models Break Down Completely
There are scenarios where neither proportional nor inversely proportional models are adequate, and continuing to force one of them into your work will produce unreliable results. Hysteresis is a common culprit. Magnetic cores, mechanical linkages with backlash, and certain types of sensors all exhibit behavior where the output depends on the direction of change, not just the current input value. No constant of proportionality can account for this. Another case is saturation. Many sensors and actuators have hard limits built into their design. Once you reach those limits, increasing the input further produces no corresponding change in output. A proportional model will predict output values beyond the saturation point that simply do not exist. The solution here is to model the saturation region explicitly, either by clamping the output in software or by redesigning the system to operate within the linear region more consistently. For systems with significant hysteresis or saturation, a piecewise model or a look-up table is usually more practical than trying to derive a single proportionality constant. The trade-off is that these approaches require more data upfront and more memory in the implementation, but they are significantly more accurate than a naive proportional or inverse model applied outside its valid range.
A Note on Inverse Proportionality in Signal Processing
In signal processing, inverse proportionality shows up in noise calculations and filter design. The signal-to-noise ratio often improves inversely with bandwidth in certain configurations, which means narrowing the bandwidth improves the ratio but also slows the system response. There is a direct trade-off here that a proportional model would not capture accurately. I once configured an ADC sampling rate for a vibration monitoring system without accounting for this relationship properly. The initial readings looked clean, but when I compared them against a known reference source, the amplitude measurements were about twelve percent too low at higher frequencies. The issue was that the anti-aliasing filter was interacting with the sampling rate in a way that introduced a frequency-dependent attenuation that followed an inverse relationship, not a proportional one. Reconfiguring the filter cutoff and adjusting the sampling rate to maintain the proper relationship brought the measurements back within acceptable tolerance. This took about an hour of work after the initial two days of troubleshooting under the wrong assumption.
Practical Steps for Getting It Right
Start by collecting data across the full range you intend to use. Do not assume the relationship holds everywhere just because it holds in a narrow band. Plot the raw data, then try the linearization tricks: plot y against x for proportionality, and plot y against one over x for inverse proportionality. Whichever plot gives you a straight line tells you which model applies, and the slope of that line gives you the constant. Validate the model with a separate dataset if possible. Even a small validation set of five to ten points taken at different operating conditions is better than nothing. If the validation points fall outside a reasonable tolerance band, the model is not applicable across the range you assumed, and you need to reconsider your approach. Document the valid operating range and the associated constant explicitly. This sounds trivial, but I have seen countless cases where the constant was derived from a datasheet example that used different units or a different reference condition, leading to results that were off by orders of magnitude. The constant is not an abstract number. It is tied to specific units, a specific range, and a specific set of conditions. Noting all of that at the time of derivation saves significant time later.
Finally, be prepared to use a more complex model if the data demands it. A proportional relationship is easier to work with, but it is not universally applicable. Inverse proportionality, piecewise linear approximations, and look-up tables are all valid tools in the same toolkit. The goal is accuracy, not simplicity, and choosing the right model for the actual relationship you are dealing with is usually worth the extra effort.