The Practical Physics of Electromagnetic Interaction
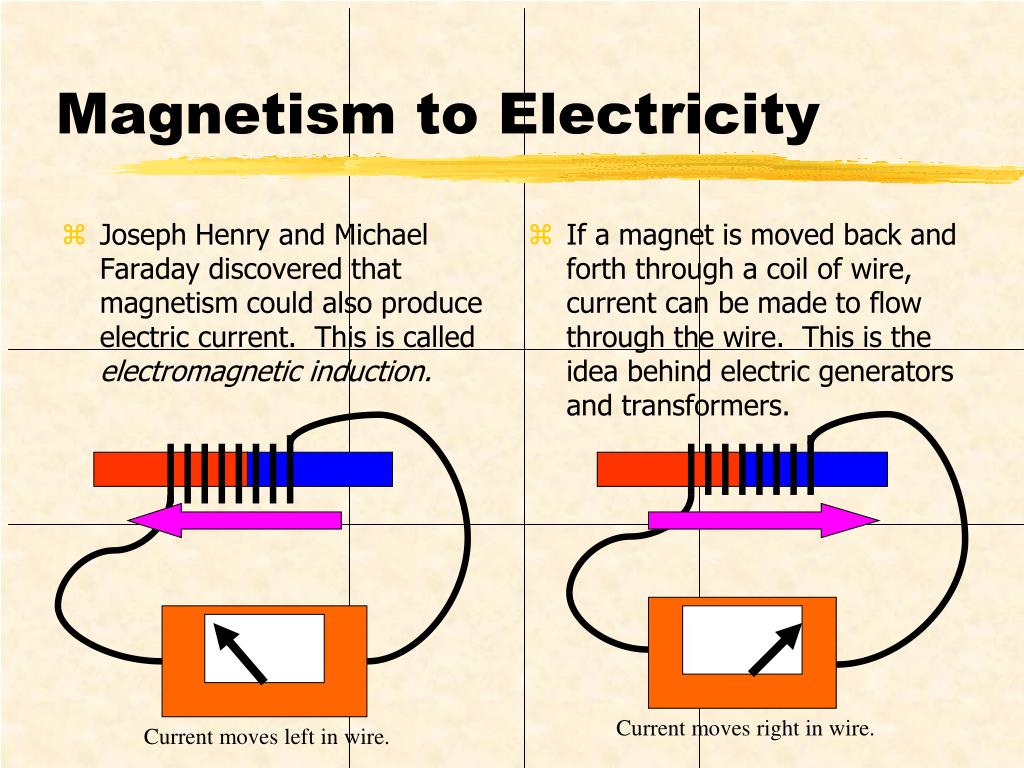
Moving a conductor through a magnetic field generates voltage across that conductor. This is Faraday's Law in its most basic form. The reverse is equally straightforward: running current through a coil creates a magnetic field around it. These two observations are the foundation of practically everything involving motors, generators, transformers, and inductors. The mathematical relationship is captured by Maxwell's equations, specifically Faraday's Law of Induction and Ampere's Law with Maxwell's addition. I spent months working on a small-scale wind turbine controller last year, and the electromagnetic theory collapsed the moment I tried to implement it. The lab bench simulation showed clean sinusoidal output from the generator. The real-world unit produced something closer to a sawtooth wave with significant harmonic distortion. The gap between textbook electromagnetism and actual hardware comes down to core saturation, parasitic capacitance, and the fact that permanent magnets degrade slightly under continuous thermal cycling. The core issue was magnetic hysteresis. The iron core in the generator stator retained residual magnetism from the previous rotation cycle. This meant the second half of each AC cycle wasn't a clean inversion of the first half. When I measured the B-H curve with a flux meter, the hysteresis loop was visibly asymmetric. The fix was swapping to a grain-oriented silicon steel laminations with lower coercivity and adding a small air gap to the magnetic circuit. The air gap reduced overall flux density but linearized the response enough that the rectification stage could handle it without excessive ripple.
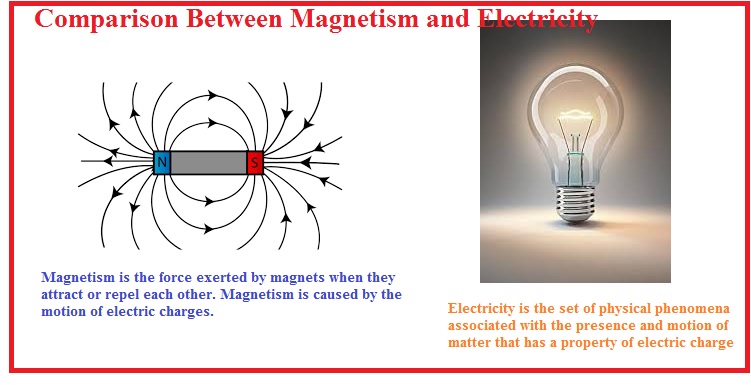
Here is what most introductory resources leave out. Magnetic fields and electric fields are not separate phenomena that occasionally interact. They are components of a single electromagnetic field tensor. A purely electric field in one reference frame becomes a mixture of electric and magnetic components in a moving reference frame. This is not philosophy. It is the operational reason why a stationary charge near a current-carrying wire experiences a force that can be described either as magnetic attraction or as an electric field resulting from relativistic length contraction of the moving electrons. Both descriptions yield identical measurable results. Another thing beginners consistently get wrong is the assumption that magnetic fields store energy in the same way capacitors store energy. A capacitor stores energy in an electric field between conductors. An inductor stores energy in the magnetic field surrounding the conductor. The key difference is that magnetic fields require continuous current flow to exist. Remove the current and the field collapses almost instantly, returning energy to the circuit. Remove the voltage from a capacitor and the field persists until you provide a discharge path. This distinction matters enormously when you are designing flyback converters or snubber circuits because the energy recovery timing is completely different. For anyone building projects around electromagnetic induction, the most common failure point is neglecting skin effect at higher frequencies. A solid copper wire carrying high-frequency AC current effectively uses only the outer layer of the conductor. The inner material contributes nothing to current carrying capacity but still adds resistance and weight. At 100 kilohertz, the skin depth in copper is approximately 0.2 millimeters. Using solid wire above this frequency is essentially wasting material. Litz wire or hollow conductors solve this problem. I found this out the hard way when my switching power supply module ran noticeably hotter than the thermal model predicted because the inductor winding resistance was twice what DC calculations suggested.
The direction of induced current follows Lenz's Law. The induced current creates a magnetic field that opposes the change that produced it. This is conservation of energy expressed through electromagnetism. If it worked the other way, you would get perpetual motion from a magnet and a coil, which does not happen. Every generator in the world relies on this opposition. You have to mechanically input energy to overcome the magnetic drag. That input energy becomes the electrical output plus losses. There is no free lunch in the equation.
Get the Full Details

How to Calculate Induced Voltage in a Real Coil
The formula for induced electromotive force is EMF = -N × d/dt, where N is the number of turns and d/dt is the rate of change of magnetic flux through the coil. Flux is measured in webers. One weber equals one tesla-square meter. The negative sign represents Lenz's Law. In practice, you rarely know the exact flux change rate, so you work backward from geometry and rotational speed. Take a simple case. A coil with 500 turns rotates in a uniform magnetic field of 0.1 tesla. The coil has an area of 0.02 square meters and spins at 1800 revolutions per minute. The angular velocity is 188.5 radians per second. The peak induced voltage equals N times B times A times omega, which gives 500 × 0.1 × 0.02 × 188.5 = 188.5 volts peak. The RMS value is 133.3 volts. This is the ideal case. Real coils have winding resistance, leakage flux, and core losses that reduce the actual output by somewhere between 10 and 30 percent depending on the design. When you move from theory to actual construction, three parameters dominate performance: the quality of the magnetic core material, the precision of the air gap, and the temperature stability of the permanent magnets if you are using them. Neodymium magnets lose approximately 0.04 percent of their flux density per degree Celsius rise in temperature. A motor running at 80 degrees Celsius with N52 grade magnets will produce roughly 4 percent less torque than the same motor at room temperature. This is a small number on paper but it is the difference between a device that meets its specifications and one that does not.
I once designed a magnetic coupling for a fluid transfer system where the driving and driven halves were separated by a stainless steel barrier. The calculation suggested a torque transmission of 12 newton-meters at a 3 millimeter gap. The actual coupling delivered about 8 newton-meters. The discrepancy came from the barrier material. Stainless steel is non-magnetic but it is not magnetically transparent. The 304 grade barrier absorbed a portion of the flux. Switching to 316L reduced the loss slightly but not enough. The real solution was increasing the gap calculation to account for the barrier's effective permeability, which is roughly 1.001 for austenitic stainless steel, meaning the magnetic circuit sees it almost like air but not quite. Adding two extra turns to the primary coil brought the output to the target torque.
Common Applications and Where They Break Down
Transformers are the most direct application of electromagnetic induction. A changing current in the primary winding creates a changing magnetic flux in the core, which induces a voltage in the secondary winding. The voltage ratio equals the turns ratio. This works beautifully at 50 or 60 hertz with a properly designed laminated core. It falls apart quickly at frequencies above 100 kilohertz unless you switch to ferrite cores and account for inter-winding capacitance, which becomes significant and can cause resonance problems that ring the transformer like a bell. Electric motors operate on the principle that a current-carrying conductor in a magnetic field experiences a force. The force equals current times length times magnetic flux density times the sine of the angle between them. Brushed DC motors use mechanical commutators to reverse current direction. Brushless DC motors and stepper motors use electronic commutation. Each approach has tradeoffs. Brushes wear out and create electromagnetic interference through arcing. Electronic commutation requires a controller and position sensing, usually Hall effect sensors or back-EMF detection. Induction cooktops are another practical application. A high-frequency alternating current through a coil beneath the cooktop surface creates a rapidly changing magnetic field. This field induces eddy currents in the ferromagnetic cookware, and the resistance of the pan converts those currents into heat. The cooktop itself stays relatively cool because glass is non-conductive and non-magnetic. The limitation is that only certain cookware works. Aluminum and copper pans will not heat efficiently because they lack the ferromagnetic properties needed for strong eddy current generation. Magnetic cookware testing with a refrigerator magnet is a crude but functional screening method.

Wireless charging pads for phones and electric vehicles use resonant inductive coupling. The transmitter coil and receiver coil are tuned to the same resonant frequency, which dramatically increases the efficiency of power transfer across an air gap. The efficiency drops sharply as the gap increases beyond the design point. Most phone chargers are optimized for a gap between 5 and 15 millimeters. Place a metal object between the pads and the system can overheat because the metal acts as a shorted turn, circulating large eddy currents with nowhere for the energy to go except heat. I discovered this when a customer complained about a charging pad getting uncomfortably warm. A loose washer had slipped under the phone during placement.
Measurement and Testing Approaches
To measure the strength of a magnetic field, you use a gaussmeter or teslameter with a Hall effect probe. The Hall voltage developed across a thin semiconductor plate is proportional to the perpendicular magnetic flux density. These instruments are calibrated against NIST-traceable standards and typically have an accuracy of about 1 percent in the range of 0 to 1 tesla. For stronger fields, search coil magnetometers are more appropriate. A search coil measures the induced voltage when the coil is moved through or removed from a magnetic field, and the flux density is calculated from the voltage integral. Measuring inductance requires an LCR meter or an impedance analyzer. The simplest method is to apply a known AC voltage, measure the resulting current, and calculate inductive reactance. X_L equals 2fL, so L equals X_L divided by 2f. At low frequencies the measurement is straightforward. At high frequencies parasitic capacitance between winding turns creates a self-resonant frequency above which the component behaves capacitively rather than inductively. Always check the impedance curve before assuming your inductor is acting like an inductor at the frequency you are testing it at. Characterizing a magnetic core involves measuring its B-H loop on a hysteresigraph. This gives you the saturation flux density, coercivity, retentivity, and core loss at a given frequency and flux density. The area inside the hysteresis loop represents energy lost as heat per cycle. For transformer and inductor design, minimizing this area while maintaining adequate saturation flux density is the central optimization problem. Amorphous metal cores and nanocrystalline cores have significantly narrower hysteresis loops than traditional silicon steel, which is why they are preferred in high-efficiency power applications despite being more expensive and mechanically fragile.
The Relationship Between Magnetism And Electricity is not just an academic concept. It is the operating principle behind the infrastructure that powers modern systems. Understanding it requires moving past the simplified textbook explanations and accounting for real material properties, frequency effects, temperature dependencies, and the inevitable gap between ideal calculations and physical hardware. The formulas are correct. The world they describe is not.