Getting the Direction Right Without Second-Guessing Yourself
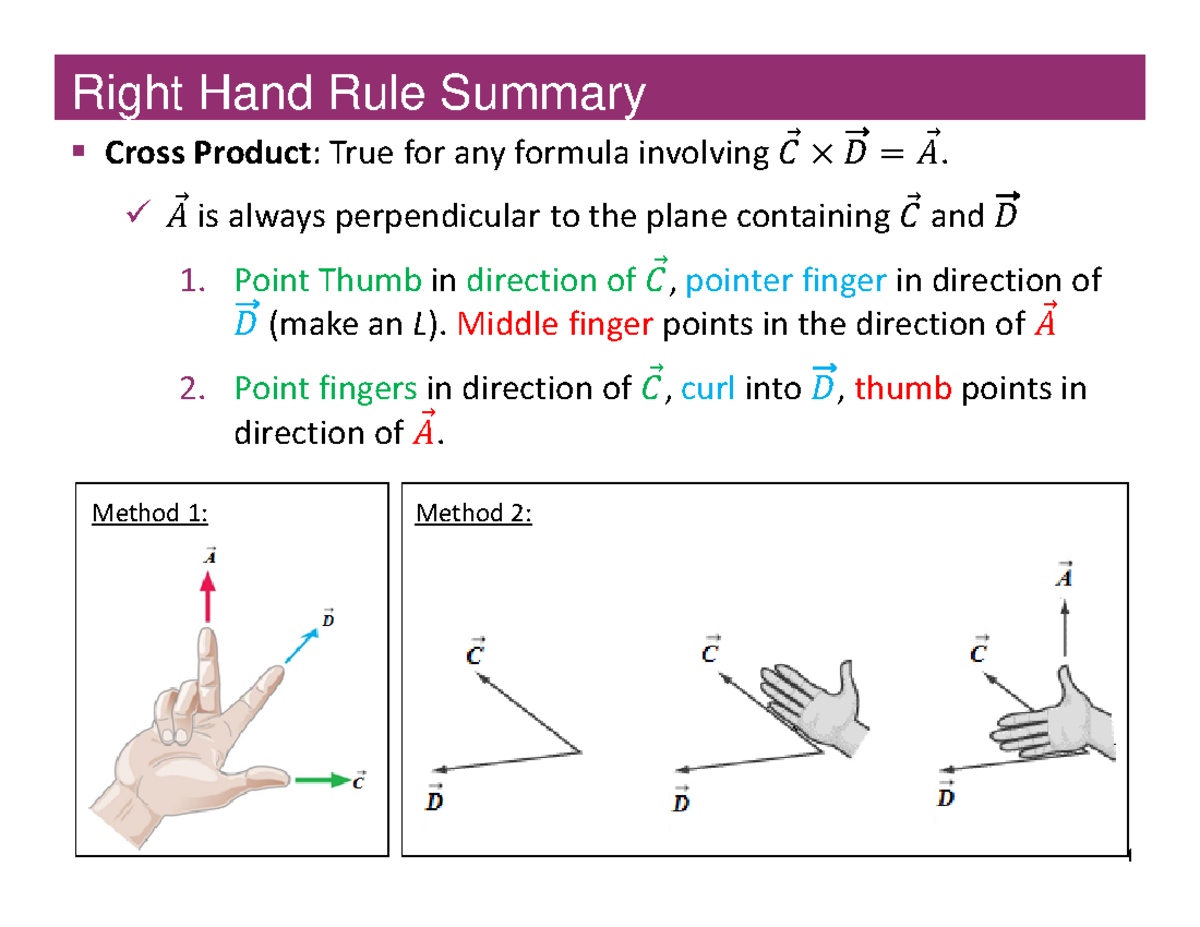
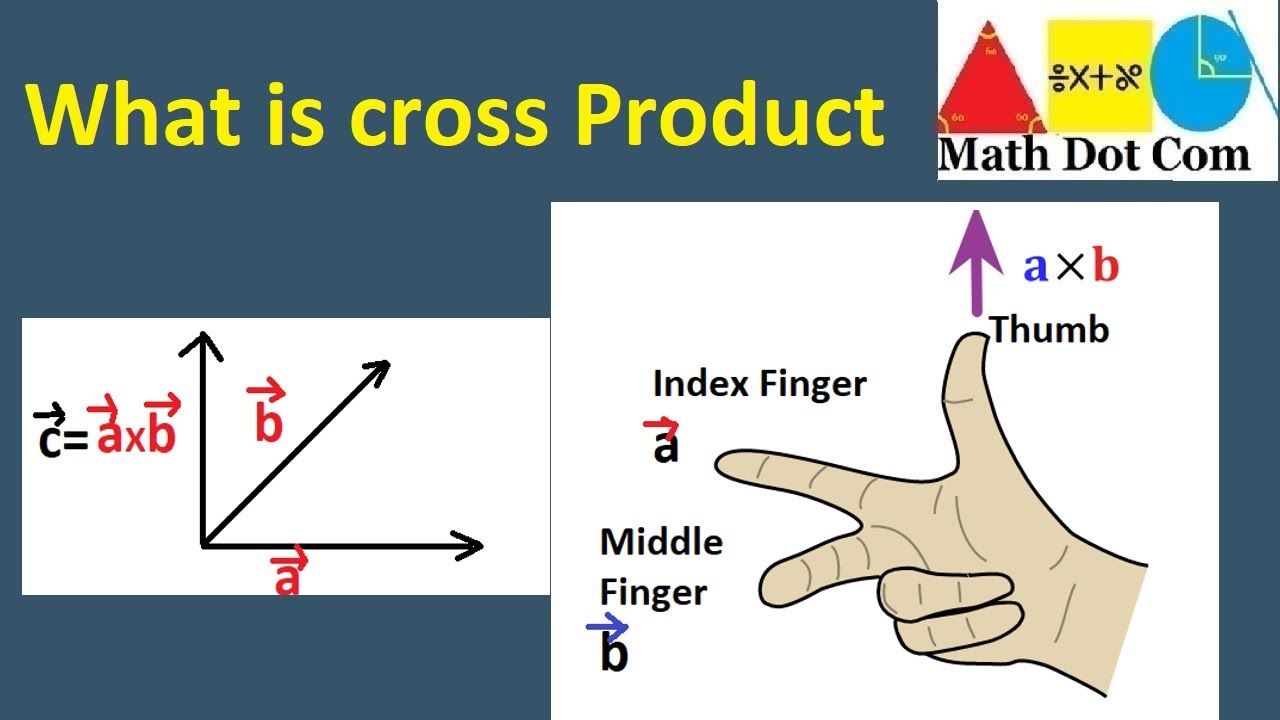
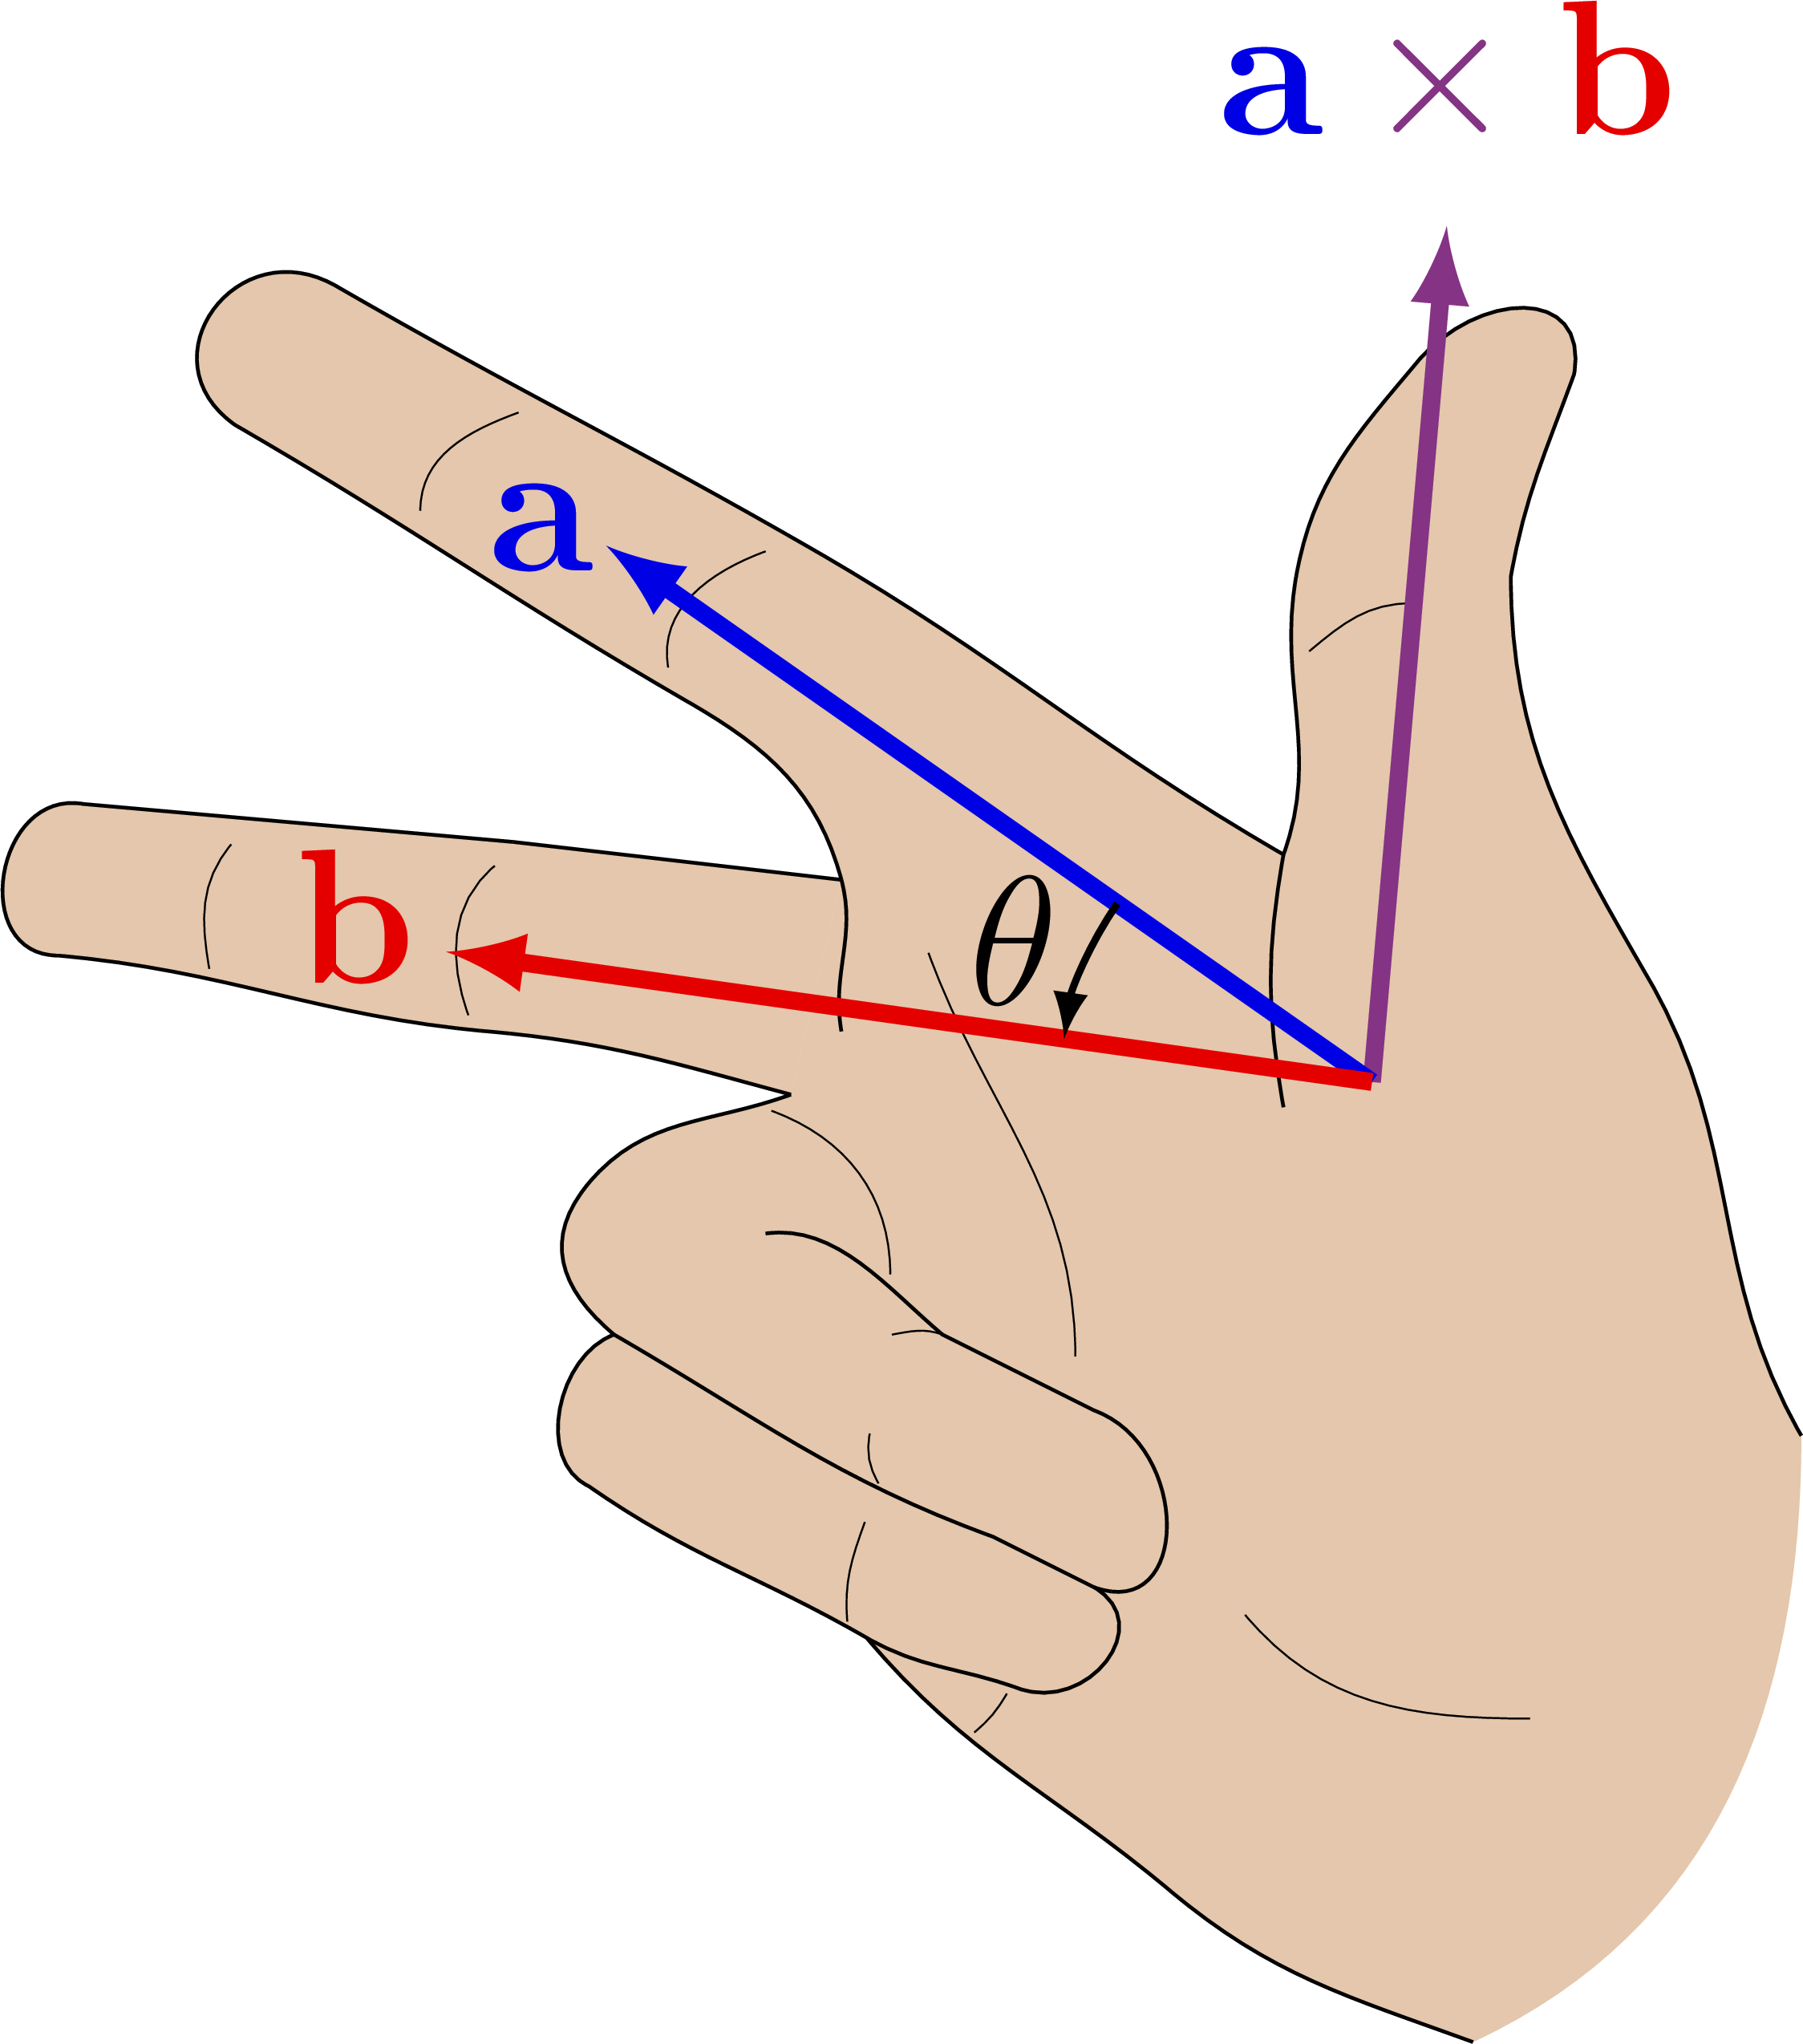
The cross product gives you a vector perpendicular to two input vectors, and the Right Hand Rule Cross Product is just the convention you use to figure out which of the two possible perpendicular directions is the correct one. It comes up constantly in mechanics, electromagnetism, and computer graphics. You will use it roughly every other day if you work in any of those fields. Here is how it actually works when you are not looking at a textbook diagram. You point your fingers in the direction of the first vector, curl them toward the second vector, and your thumb points in the result. That is the whole thing. The "first" and "second" matter enormously. Swap the order and your thumb flips. The cross product is anti-commutative, meaning a × b equals negative (b × a). I spent way too many hours in grad school debugging a torque simulation because I had the vectors backwards in a single function call. The math was clean, the code compiled, the result was just pointing in the opposite direction and nobody noticed for a week. One thing people miss immediately: your hand has to physically represent the angle between the vectors, not just point them somewhere vaguely close. If the two vectors are 170 degrees apart, your fingers need to curl almost flat. If they are 10 degrees apart, the curl is tight. This matters because when you are working in three dimensions on paper and trying to mentally rotate your wrist, the small-angle cases are where most people get the wrong direction. I keep a habit of literally drawing a quick arrow for the result before I trust my mental image. It takes three seconds and saves me from re-running a solver.
Another thing textbooks do not stress enough is that the rule only works for right-handed coordinate systems. If you are in a left-handed system, which some older CAD packages still default to, the whole thing reverses. I ran into this when porting a physics engine from a game SDK that used a left-handed convention. Every torque and angular momentum calculation was wrong until I switched the handedness flag. The cross product formula itself does not change, but the perceived direction of the output does because your coordinate frame is flipped.
The Mechanical Way to Do It Step by Step
Write down or visualize vector a and vector b originating from the same point. Orient your right hand so your extended fingers point along a. Without rotating your wrist, curl your fingers toward b through the smaller angle between them. Your thumb now points along a × b. If the angle is greater than 180 degrees, you curl the other way and the thumb still points correctly because the smaller angle is what the rule uses by convention. When the vectors are given as components, say a = (ax, ay, az) and b = (bx, by, bz), you can skip the hand entirely and use the determinant method: a × b = (aybz azby, azbx axbz, axby aybx)
Get the Full Details

This is faster for computation and eliminates hand-contortion errors. I use it for everything except quick checks during exams or whiteboard sessions. The component formula is easy to mess up on the middle term sign. I have seen people write axbz azbx by mistake, which flips the y-component. Keep the cyclic pattern in mind: x, y, z, x, y... and subtract the crossed terms. That keeps the signs straight without looking it up. For the special case where both vectors lie in the xy-plane, the result only has a z-component. That is one of the quickest mental shortcuts available. a = (3, 1, 0) and b = (2, 4, 0) gives a z-component of 3×4 1×(2) = 14. The answer is (0, 0, 14). Doing this by hand every time reinforces that the rule is consistent with the algebra.
Where It Breaks Down and What to Do Instead
The Right Hand Rule Cross Product fails in two specific scenarios that are worth knowing about upfront. First, if the two vectors are parallel or anti-parallel, the cross product is zero. The direction is undefined because there is no unique perpendicular. This shows up constantly in rigid body simulations when two contact normals align perfectly. The workaround is a simple magnitude check: if |a × b| is below a threshold like 1e-8, skip the direction assignment and handle it as a degenerate case. Otherwise your code will divide by zero downstream when it normalizes the result. The second failure mode is when you need the cross product repeatedly in a performance-critical loop. The right hand rule is a conceptual tool, not an algorithm. For GPU work or real-time physics, you rely on the component formula or a SIMD-optimized routine. I once replaced a software-rendered cross product chain with a vectorized version and saw frame times drop from 11ms to 4ms on a scene with roughly 40,000 collision checks per frame. The rule still tells you what the answer should mean. The hardware does not care about your hand. A third practical limitation: the rule does not generalize cleanly beyond three dimensions. In four or more dimensions, there is no single perpendicular vector, only a perpendicular plane. Some people try to force the right hand rule into higher dimensions and end up with inconsistent results. If you ever need this, look into the wedge product or exterior algebra instead. It is the proper generalization and it does not require you to contort your fingers.
A Real Case That Took Me Longer Than It Should Have
During a project building a magnetic field visualizer for a university lab, I needed the force direction on a charged particle moving through a known field. The formula is F = q(v × B). I had v along the positive x-axis and B pointing roughly up and to the right in the xy-plane. My hand gave me a result pointing into the page. The simulation showed the particle curving outward instead. I checked the determinant, recalculated by hand, rotated my wrist, flipped my hand to the left out of habit, and still got the same answer. The problem turned out to be that the particle was an electron, so q was negative. The cross product was correct the whole time. The force direction was reversed by the charge sign. I wasted about ninety minutes on that before I stopped blaming the rule and started blaming the sign convention. If you are doing any EM work, always carry the charge separately and apply it after the cross product. Do not fold it into the vector directions beforehand. i × j = k. j × k = i. k × i = j. These are the canonical basis vector relationships and they follow directly from the rule. Reverse the order and you get the negative. I keep these memorized because they come up in almost every calculation and they save you from pulling out your hand for something that should be instant. When both vectors are unit vectors, the magnitude of the result equals sin(), where is the angle between them. This is useful for estimating whether your directional answer makes sense. If you get a magnitude greater than 1, you made an arithmetic error. If you get zero and the vectors are clearly not parallel, you used the dot product by accident. Both mistakes happen more often than you would think.
The Right Hand Rule Cross Product is a convention, not a law of nature. It is arbitrary in the sense that someone could have chosen the left hand and everything would still be consistent internally. The important part is picking one system and sticking with it for the entire problem. Mixing conventions within a single calculation is how you get answers that look plausible but are off by a sign. That is usually the hardest bug to find because nothing in the code complains. The numbers just behave strangely.