Building a Robot Tour Team for Science Olympiad
The Robot Tour event is one of those competitions where most teams come in with a half-finished car and hope for the best. It tests students' ability to build a robot that completes multiple autonomous missions on a single match day, and the scoring is brutal because there's no room for mid-event fixes. I've seen teams spend weeks building something that looks impressive in the garage and then completely fall apart under tournament conditions. The core task is straightforward: you construct an autonomous robot that can navigate a course, interact with physical objects, and complete tasks across multiple stations. The event typically runs on a regulation mat with various challenges—things like pushing weights, picking up geometric shapes, navigating through gates, and sometimes dealing with elevation changes. Your robot has to do all of this without human input during the run. That means your programming has to be reliable enough to handle the actual tournament environment, not just the smooth floor you practice on.
Robot Tour Science Olympiad: What Actually Wins Matches
Most beginners focus entirely on speed. They build the fastest robot they can and then crash it into a wall during their first trial run because they never accounted for wheel slip or uneven flooring. The teams that consistently place well are usually running slower, more deliberate robots that complete every task reliably. A completed mission at medium speed beats a flashy robot that misses one checkpoint and gets a zero on that segment. I spent three seasons watching teams blow their runs because they optimized for one specific mat layout and then got a different one at regionals. The mat texture, tile seams, and lighting conditions vary significantly between venues. One season, my team built a light-sensor-based navigation system that worked perfectly under our gym's fluorescent lights but completely failed at a competition held in a building with warm LED overheads. The color readings were shifted enough that the robot couldn't differentiate between black and dark blue lines. We ended up switching to an encoder-based odometry system for our final builds, which was slower to implement but didn't care about lighting at all. That change moved us from a D- average at our first tournament to top-five placements the rest of the year. The other thing nobody talks about enough is weight distribution and center of mass. When your robot picks up an object, its center of gravity shifts. If you've built a tall, top-heavy chassis, the act of lifting or pushing can cause your robot to tip over or lose traction on its drive wheels. I've watched entire matches lost because a team's robot kept flipping forward when it engaged with the final objective. The fix isn't always obvious. Sometimes you need to redistribute internal components toward the rear and bottom of the chassis, not just add weight to the front bumper like most beginners would suggest.
The Build Process That Actually Works
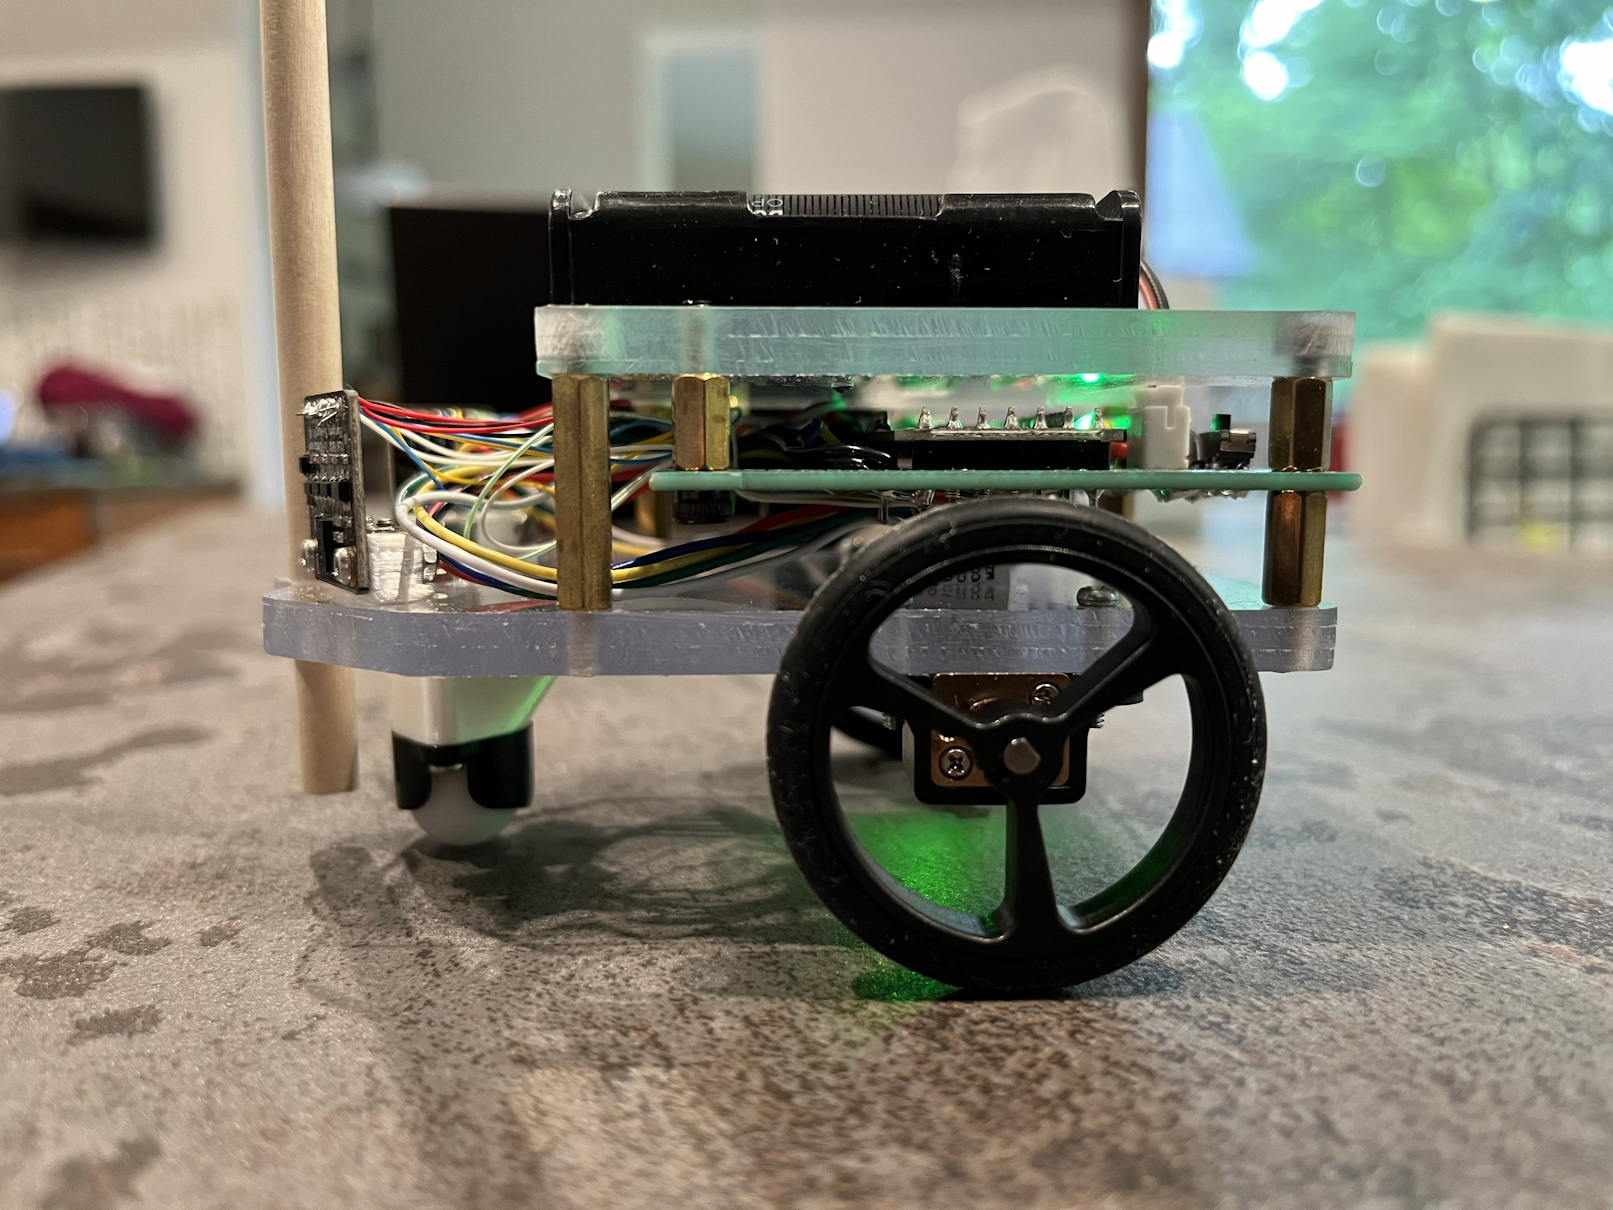
Start with your drivetrain. This is the foundation everything else hangs on. Omni-wheel setups look cool and give you holonomic movement, but they are fragile under competition conditions and tend to lose traction when pushing anything heavier than a few hundred grams. Tank treads or standard differential drive with rubber tires give you far more predictable behavior, especially when you're pushing or lifting. If your school has a 3D printer, start prototyping your chassis frames early. Laser-cut acrylic or basswood from a makerspace works too, but printed parts let you iterate faster when something breaks mid-season. For the robotic arm or manipulator, keep it simple. Complex multi-degree-of-freedom arms introduce failure points and calibration headaches. A two-stage arm with a gripper mechanism handles maybe ninety percent of tour tasks adequately, and it's significantly more reliable than a seven-axis setup that requires real-time PID tuning mid-match. Servo selection matters more than people realize. MG996R metal gear servos will strip their gears under load if you push them too hard. For anything involving lifting or pushing, use higher-torque servos or a mix of servo and stepper motors depending on your budget. Your code architecture should separate navigation from manipulation. A lot of teams write one giant monolithic loop that tries to handle everything, and then debugging a missed turn requires scrolling through fifty lines of unrelated logic. Structure your code with distinct functions or classes for movement, sensor reading, object detection, and task execution. This makes it trivial to isolate whether a problem is a sensor issue, a motor issue, or a logic issue. If your robot keeps overshooting a turn, you know to look at your PID constants for the drive function rather than wondering if the arm is somehow interfering.
Get the Full Details

Testing Strategy and Common Pitfalls
You need to test on surfaces that approximate tournament conditions, not just your garage floor. Carpet versus linoleum versus tiled concrete will change your robot's speed and turning radius by noticeable margins. Record baseline measurements for straight-line distance and turning angles on each surface type. A robot that travels exactly one meter on smooth tile might travel ninety centimeters on a carpeted gym floor due to rolling resistance, and your programs need to account for that variance or you'll be correcting on the fly during matches. Another pitfall is over-programming the first test run. Teams will write fifteen different scenario branches into their initial code and then spend hours debugging interactions between them. Start with a bare-bones version that completes one task reliably, then add complexity one module at a time. Each addition should be tested independently before combining it with the existing system. This approach cuts debugging time dramatically compared to writing a complete program and then figuring out which of the twenty features broke when you added the twenty-first. Battery management is another silent match-killer. Most teams use standard LiPo packs for robotics, and under the sustained current draw of multiple servos and motors, voltage sag becomes a real issue near the end of a run. If your microcontroller brownouts midway through a match, you get a zero and the match is over. Monitor your battery voltage during extended testing sessions and factor in a voltage cutoff safety margin. Having a spare fully charged battery on hand is mandatory, not optional, because you'll burn through multiple practice runs in a single afternoon and every run drains the pack.
The event also has strict size and weight constraints depending on your division level. Middle school tournaments typically have tighter restrictions than high school, so check your league's official rulebook before you commit to a design. Some regions allow powered arms while others don't, and the scoring rubric can change slightly from year to year. The Science Olympiad rulebook gets updated annually, and last year's winning strategy might not apply this season if the event designers changed the mission requirements. Always reference the current year's document.
What This Event Doesn't Reward
Aesthetic presentation doesn't affect your score. A robot wrapped in decorative tape and covered in school logos scores the same as one that looks like it was assembled from spare parts at 2 AM. Don't waste competition build time on appearance unless you're also entering a separate style or poster component. The judges evaluate functional performance only in Robot Tour. Similarly, speed alone is not the primary scoring metric in most tour formats. Completion percentage dominates the scoring rubric, and speed only serves as a tiebreaker. A robot that finishes every task in four minutes beats a robot that skips one task but finishes the rest in two minutes and thirty seconds. This inversion of intuition is why so many teams leave point deductions on the table—they optimize for velocity instead of reliability. The other limitation worth noting is that this event heavily favors schools with consistent coaching and lab access. Students who build their first robot from scratch with no mentor guidance will generally lag behind teams that have iterative experience across multiple seasons. That isn't a criticism of the event format. It's just the reality of a competition that demands both mechanical fabrication skills and software engineering ability simultaneously. If your team is starting from zero, budget the first four to six weeks purely for foundational learning before expecting competitive results.