Rotation Rules In Geometry
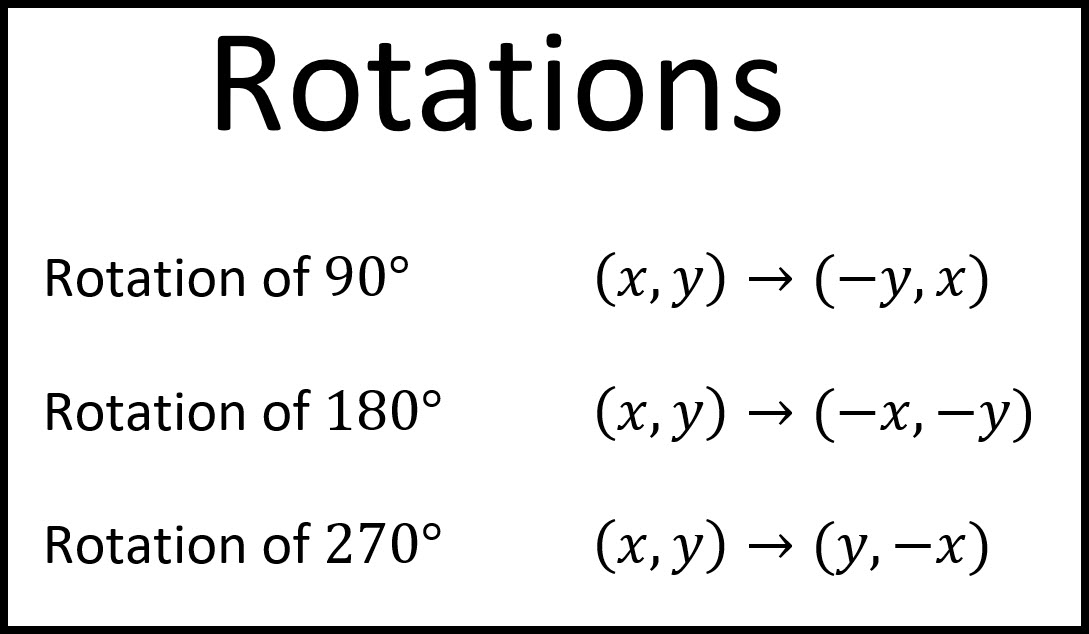
Most people learn rotation rules by memorizing a table of coordinate shortcuts. That approach works fine for homework and multiple-choice tests, but it breaks down the moment you're asked to prove something or work with an arbitrary angle that isn't 90 or 180 degrees. I learned that the hard way when I was tutoring a student who could recite every rotation shortcut perfectly, then froze the second I gave them a rotation about a point that wasn't the origin. A rotation is a rigid transformation that turns every point of a figure around a fixed center by a specified angle. The center stays put. Everything else moves along a circular path. That's the whole thing, stripped down. The standard coordinate rotation rules you'll find in any textbook assume the center of rotation is at the origin. Here's what those actually are:
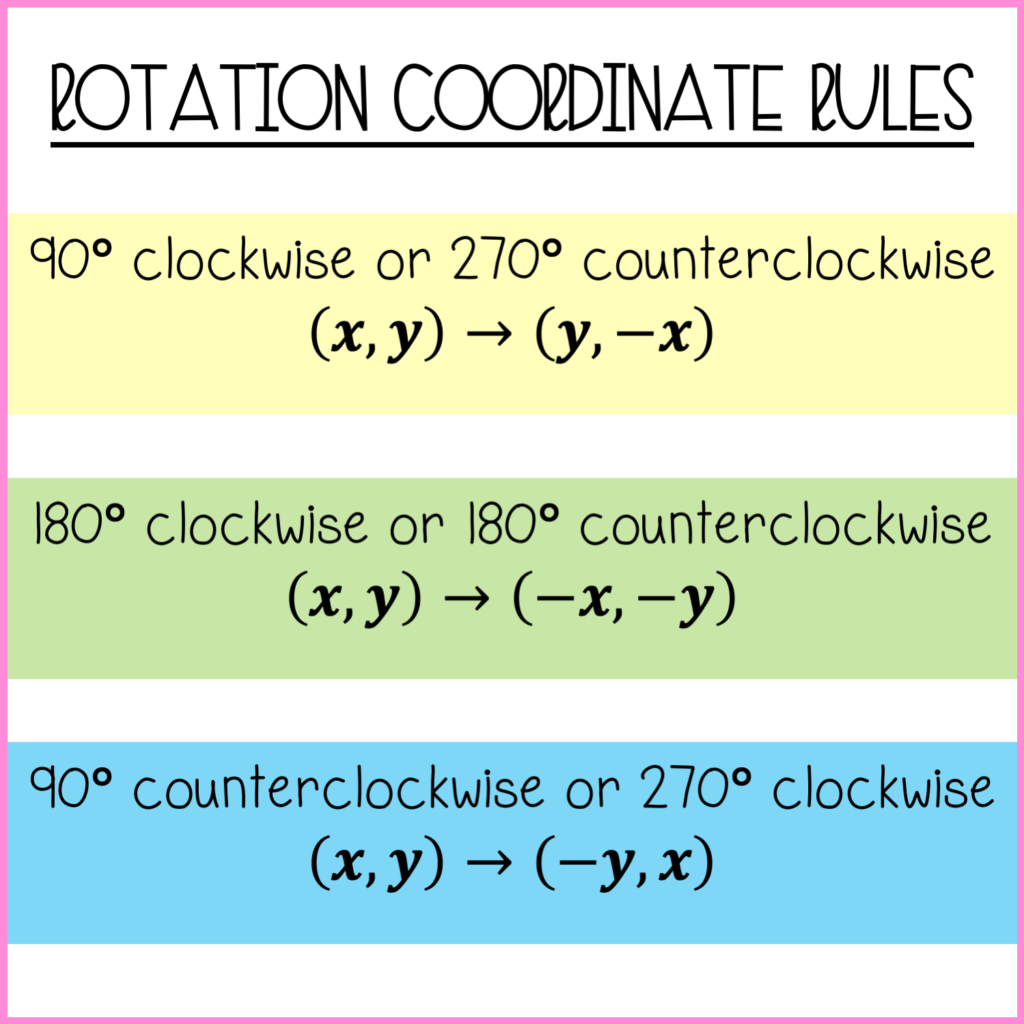
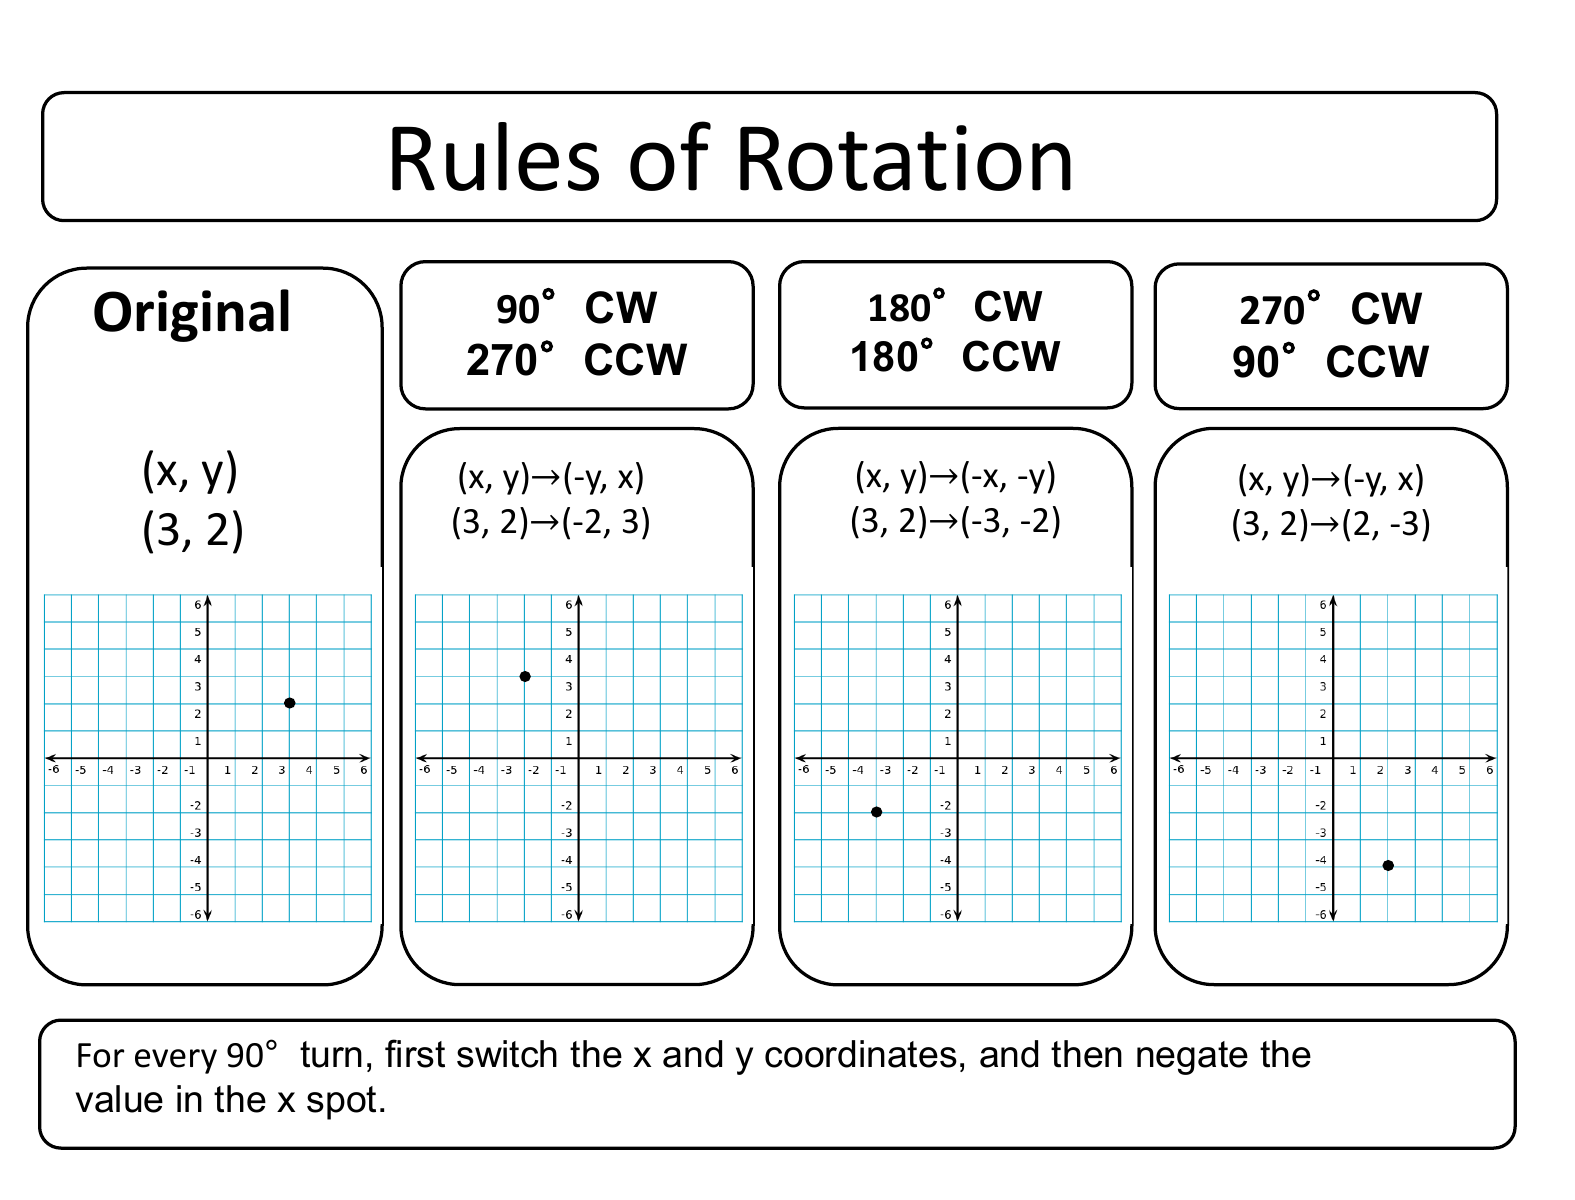
Rotation 90° clockwise (or -90°): (x, y) becomes (y, -x). So the point (3, 5) lands at (5, -3). Rotation 90° counterclockwise (or +90°): (x, y) becomes (-y, x). The point (3, 5) goes to (-5, 3). Rotation 180°: (x, y) becomes (-x, -y). Simple sign flip on both coordinates. The point (3, 5) becomes (-3, -5).
Rotation 270° clockwise (or +270°): This is the same as 90° counterclockwise, so (x, y) becomes (-y, x). Rotation 270° counterclockwise (or -270°): Same as 90° clockwise, so (x, y) becomes (y, -x). Those five rules cover most introductory geometry problems. But they're only valid when the center is exactly at (0, 0). If your center is anywhere else, you can't just plug into these formulas and expect the right answer. That's where most students get tripped up.
Get the Full Details
Working With an Arbitrary Center of Rotation
The correct approach for any rotation, regardless of where the center sits, follows a three-step sequence that actually makes geometric sense instead of relying on a memorized trick. You translate the center to the origin, apply the rotation formula, then translate back. In practice that means subtracting the center coordinates from every point in your figure, doing the rotation, and then adding those same center coordinates back. I ran into a real issue last year with a high school geometry course that was preparing students for a competition. The problem set included a triangle with vertices at (2, 3), (7, 1), and (4, 8), and the assignment was to rotate it 120° counterclockwise about the point (1, 4). None of the standard rotation shortcuts apply here because 120° isn't one of the friendly angles and the center isn't at the origin. A lot of students just tried to guess or use the wrong formula. The right way is to shift everything so the center (1, 4) becomes the origin, apply the general rotation formula, then shift back. The general rotation formula for any angle theta around the origin is:
x' = x cos(theta) - y sin(theta)
y' = x sin(theta) + y cos(theta) For 120° counterclockwise, cos(120°) = -0.5 and sin(120°) = sqrt(3)/2, which is approximately 0.866. So the formula becomes x' = -0.5x - 0.866y and y' = 0.866x - 0.5y. You apply that to each translated point, then add (1, 4) back to the result. The vertex (2, 3) translates to (1, -1) relative to the center, rotates to approximately (0.366, 1.366), and then translates back to approximately (1.366, 5.366). This process takes about 3 to 5 minutes per point with a calculator. It's not elegant, but it's reliable. The coordinate shortcut table takes about 10 seconds per point, but only when the angle and center line up perfectly. If they don't, the shortcut gives you the wrong answer every single time, and you won't know it until you check.
What People Get Wrong About Rotations
The biggest misconception I see repeatedly is the assumption that rotation preserves orientation in the way people intuitively think it does. A 90° clockwise rotation and a 90° counterclockwise rotation are not the same operation, obviously, but students often confuse the direction because the coordinate swap looks similar. The difference between (y, -x) and (-y, x) is a sign change that's easy to miss under time pressure. I once graded a test where every single answer for a 90° counterclockwise rotation had the wrong signs because the student had applied the clockwise formula. They got the coordinate swap right but the direction wrong, which means their fundamental understanding of which axis is which in the coordinate plane was fuzzy. Another common error is forgetting that rotations preserve distances and angles. This matters when you're asked to prove that two triangles are congruent after a rotation. Students sometimes try to use the distance formula to verify congruence when the definition of a rigid transformation already guarantees it. That wastes time and opens the door to arithmetic errors that shouldn't exist if you just invoked the definition directly. There's also the issue of composite rotations. If you rotate a figure 90° around point A and then 90° around point B, the result is not the same as rotating 180° around any single point unless A and B happen to be positioned in a very specific way. The composition of two rotations is itself a rotation, but the center and angle of the resulting rotation aren't found by simply adding the angles and averaging the centers. I saw a problem in a textbook that claimed a 90° rotation about (2, 0) followed by a 90° rotation about (0, 2) was equivalent to a 180° rotation about (1, 1). It looked plausible but it's wrong. The actual composition here is a 180° rotation about (2, 2), not (1, 1). You can verify this by tracking where a single point goes through both rotations and finding the unique fixed point.
When Rotation Rules Fail Completely
The coordinate rotation shortcuts based on sin and cos break down if you're working in a non-Cartesian coordinate system without first converting. Lattice-based geometry problems sometimes appear in competitions where points are given in grid units but the rotation is about a grid intersection that doesn't align with the standard axes. The formulas still apply, but you have to be careful about what "up" and "right" mean in your particular setup. Numerical precision is another real bottleneck. When you're rotating by an angle that doesn't have a clean trigonometric value and you're doing it by hand, rounding errors compound. After three or four composite rotations, your final coordinates can drift enough to change which region of the coordinate plane your point ends up in. In practical applications like computer graphics or robotics, this is why quaternions exist instead of raw rotation matrices for sequential operations. The math students learn in geometry class is exact in theory but approximate in practice, and nobody tells them that. For most classroom purposes, this imprecision isn't a problem because the work is checked against idealized answers. But if you're using rotation rules to simulate physical motion or generate procedural geometry, you need to be aware that each rotation step introduces a small error. A single rotation around an arbitrary center with an arbitrary angle will give you results accurate to about 4 to 5 decimal places with standard calculator precision. Eight or nine successive rotations and you might be off by 0.01 or more. That sounds small until it's the difference between a polygon closing properly and having a visible gap.
A Faster Way for Repeated Rotations
If you're rotating the same figure multiple times around the same center, precomputing the rotation matrix and applying it repeatedly is significantly faster than recalculating sine and cosine each time. For a 45° rotation, for instance, both sin and cos equal sqrt(2)/2, which is approximately 0.7071. Once you have that value, every rotation step is just a matter of multiplication and addition. I use this approach when I'm generating test problems that require a figure to be rotated through eight steps, and it cuts the total time from about 20 minutes down to roughly 3 or 4 minutes because you're not constantly reaching for the calculator. Here's a quick reference for the most common exact trigonometric values you should memorize instead of looking them up. They save time and reduce rounding error: 0° gives (1, 0), 30° gives (sqrt(3)/2, 1/2), 45° gives (sqrt(2)/2, sqrt(2)/2), 60° gives (1/2, sqrt(3)/2), and 90° gives (0, 1). The supplementary angles follow from symmetry. Having these values locked in means you can do a 60° or 120° rotation by hand without a calculator in about 30 seconds per point. The core principle that ties everything together is that rotation is defined by a center and an angle, not by a coordinate trick. The shortcuts are useful for what they are, but they're derived from the general formula, not the other way around. If you understand the three-step translation-rotate-translate process, you can handle any rotation problem that shows up, including the ones that are designed to punish people who only know the shortcuts.