Working With Rotational Inertia Of Disk
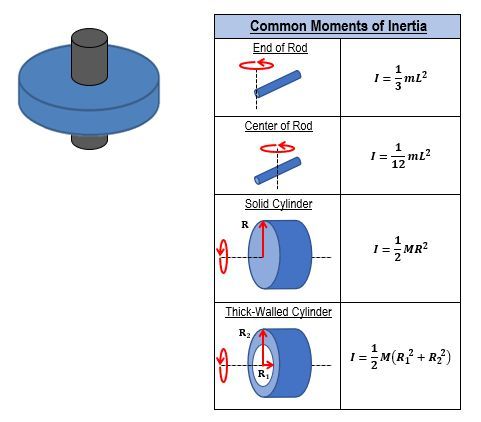
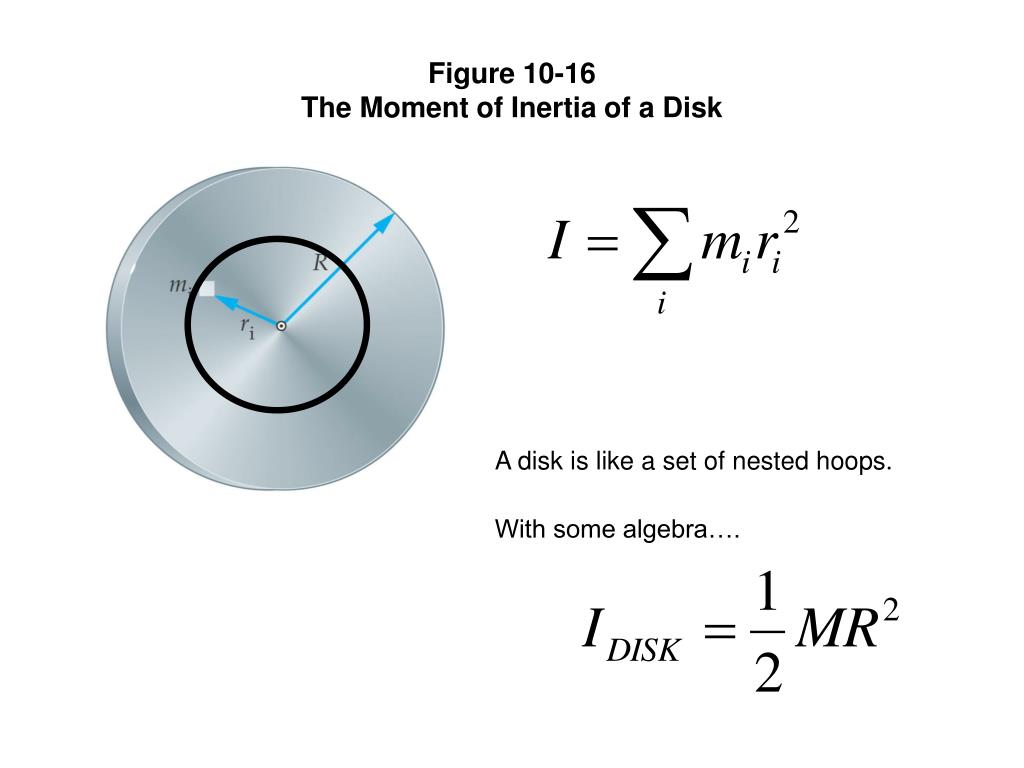
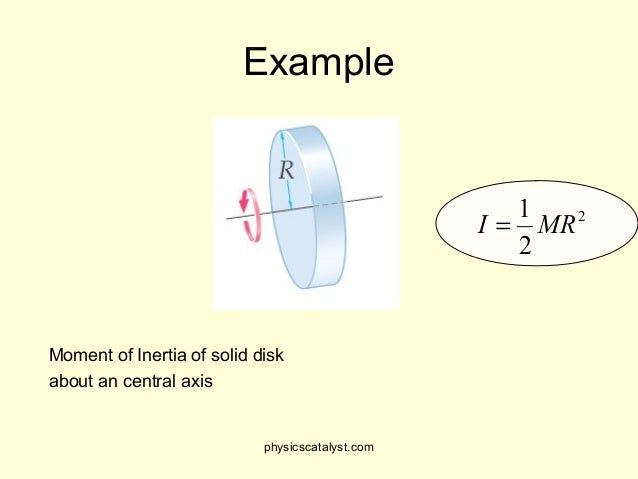
When you're actually building something that spins, the formula I = 1/2 MR² isn't just textbook filler. It's the difference between your motor controller tuning working on day one and spending three weeks chasing oscillations. I used to treat it as background math until I built a rotary indexing table for a small assembly line and the stepper motor kept missing steps under load. Turned out the driver was sized for the payload I was shipping, not the inertia of the disk itself sitting on top of it. Rotational inertia, sometimes called moment of inertia, measures how much torque you need to change the angular velocity of a body. For a solid uniform disk rotating about its central axis, it's one-half mass times radius squared. That radius term is the reason geometry matters more than weight. A disk with the same mass but a larger diameter can have twice the rotational inertia, and that changes everything about your drive system design. The standard equation is straightforward enough:
I = ½ × M × R² Where I is the rotational inertia in kgm², M is the mass in kilograms, and R is the radius in meters. You plug numbers in, you get a number out. The confusion starts when people treat this as the final answer without accounting for what else is attached to the shaft.
Setting Up The Calculation Correctly
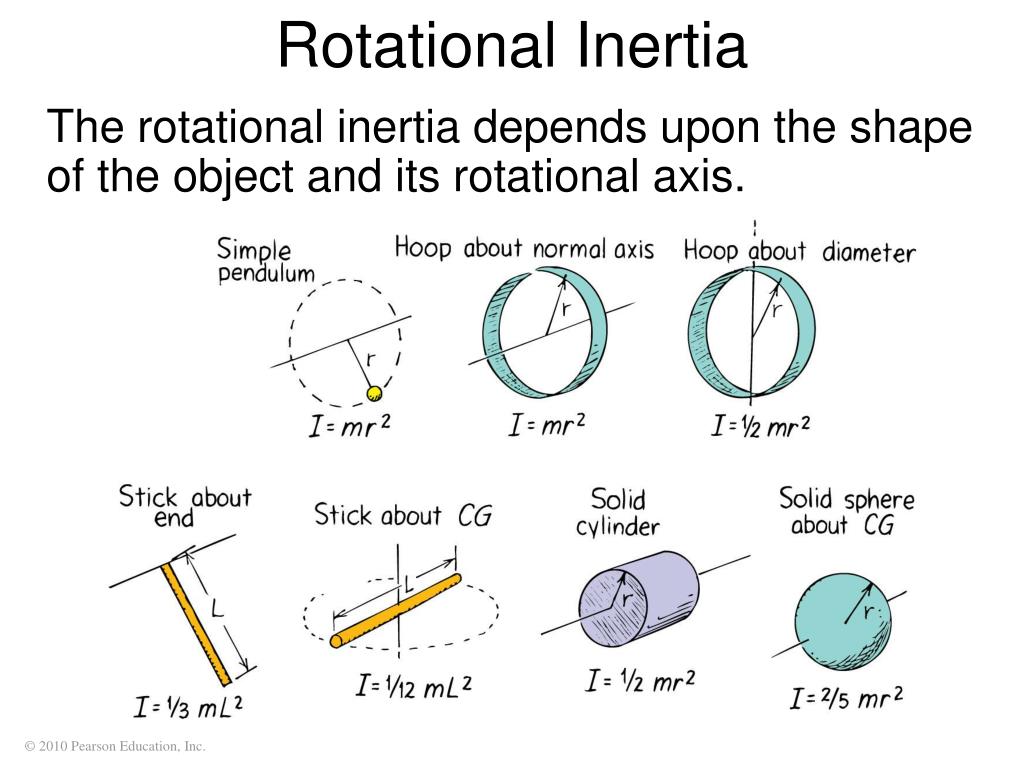
Here's where most people get burned. You measure or look up the mass of your disk. You measure the radius from center to edge in meters, not millimeters. Square the radius. Multiply by mass. Divide by two. That gives you the disk's own contribution. But your system almost certainly has more going on than just a bare disk. If you have a flange bolted on, a hub, a belt pulley, or a magnetic coupling, each of those adds its own inertia and they stack. The rule is simple: total rotational inertia equals the sum of every component's individual rotational inertia referred to the same axis. I used to just add them up carelessly until I ran into a case where someone had bolted a steel collar onto an aluminum disk and the total inertia came out nearly double what the motor spec sheet assumed. For components that aren't disks, you use their respective formulas. A solid cylinder is the same ½MR². A thin hoop or ring is MR², which is noticeably higher for the same mass. A sphere is MR². If your component has a non-uniform density profile, like a forged part with a heavier rim, you either break it into uniform sections and sum them or run a CAD-based inertia calculation. Most modern CAD tools will spit out the polar moment of inertia directly if you ask.
Get the Full Details
Common Pitfalls I Still See People Make
The first mistake is mixing units. Put the mass in grams and the radius in centimeters and you'll get a number that looks reasonable but is off by factors of a thousand. Always convert to kilograms and meters before you calculate. The second mistake is using diameter instead of radius. It's an easy typo but it doubles your result because diameter is twice the radius and then you square it, so you end up with four times the correct value instead of two. The third mistake is ignoring the shaft itself. A solid steel shaft 20 millimeters in diameter and 300 millimeters long contributes roughly 0.00014 kgm² to the total. That sounds small until your disk only weighs half a kilogram and has a radius of 80 millimeters, at which point the shaft is adding nearly ten percent to your total inertia and your acceleration calculations are quietly wrong. I ran into a particularly nasty edge case last year with a high-speed spool that had a hollow core for cable routing. The basic disk formula doesn't apply to a hollow cylinder. I had to use the annular disk formula instead: I = ½ × M × (R² + R²), where R is the inner radius and R is the outer radius. The difference between using the solid disk formula and the correct hollow one was about twenty-three percent on that part. That's enough to send your PID tuning completely off.
Applying This To Motor Selection
Once you have your total rotational inertia, the next step is figuring out whether your motor can actually accelerate the load fast enough. The torque required for a given angular acceleration is simply = I × , where is torque in newton-meters and is angular acceleration in radians per second squared. This is where the whole calculation pays off. Motor datasheets give you a rated continuous torque and a peak torque, usually for very short durations. You need both numbers. The continuous torque determines whether the motor will overheat during sustained operation. The peak torque determines whether you'll slip or stall during acceleration transients. If your required torque exceeds the peak at any point in your motion profile, you need a bigger motor or a gear reducer to multiply the available torque. There's a rule of thumb in motion control that the inertia ratio between the reflected load inertia and the motor's own rotor inertia should stay below ten to one for good controllability. Some precision applications want it below five to one. When your load inertia dwarfs the motor inertia, your system becomes sluggish and sensitive to parameter variations. The motor effectively becomes a heavy flywheel trying to drag something much heavier around.
When The Simple Model Breaks Down
The ½MR² formula assumes a uniform, homogeneous disk rotating about a perfect central axis. Real parts don't always meet those conditions. If your disk is made of a composite material with varying density, or if it has slots, cutouts, or mounting holes that aren't symmetrically distributed, the actual inertia will differ from the calculated value. Symmetrically placed holes on a disk are usually fine to account for by subtracting their individual inertias, but asymmetric features require a different approach. For asymmetric masses or complex geometries, the practical solution is experimental measurement. You can mount the part on a known torsional spring and measure the natural frequency of oscillation. The period relates directly to the moment of inertia through the equation T = 2(I/k), where k is the torsional spring constant. I used this method on a carbon fiber disk with an irregular cutout pattern where the CAD model couldn't accurately capture the material distribution. The measured inertia came out four percent higher than the theoretical calculation, which was close enough for our purposes but the gap mattered for our vibration analysis. Thermal effects are another consideration that gets ignored. If your disk operates at significantly different temperatures than when you calculated its mass properties, thermal expansion changes the radius and therefore the inertia. Aluminum disks expand noticeably with temperature. For precision equipment where inertia matching is tight, this can shift your tuning over the course of a shift.
There's also the matter of effective inertia when gearing is involved. A gear reducer divides the reflected load inertia by the square of the gear ratio. A 5:1 reducer makes a 5 kgm² load feel like only 0.2 kgm² to the motor. This is why gear reducers are standard in high-inertia applications even when the motor itself is capable of producing enough torque without one. The motor sees a much lighter load and responds faster, while the gearbox takes the mechanical advantage. The core calculation remains simple, but the applications around it are where things get complicated. Get the disk inertia right, account for everything bolted to it, verify your assumptions against the real world when it matters, and you'll save yourself a lot of troubleshooting down the line.