3D Rotation Representations: What Actually Works in Production
I spent three weeks debugging a character rig where the arms would spontaneously flip orientation during certain poses. The animator swore the IK solver was broken. It wasn't. I was using Euler angles for intermediate rotation blending, and at those poses the gimbal lock singularity was causing wild interpolation jumps. Switched the whole pipeline to quaternions and the problem vanished overnight. This is why most people working with 3D rotations end up here. You've hit the wall where Euler angles stop making sense, rotation matrices are too expensive for what you need, and you're wondering what the hell a quaternion actually is beyond the math textbook definition.
What Quaternions Actually Are
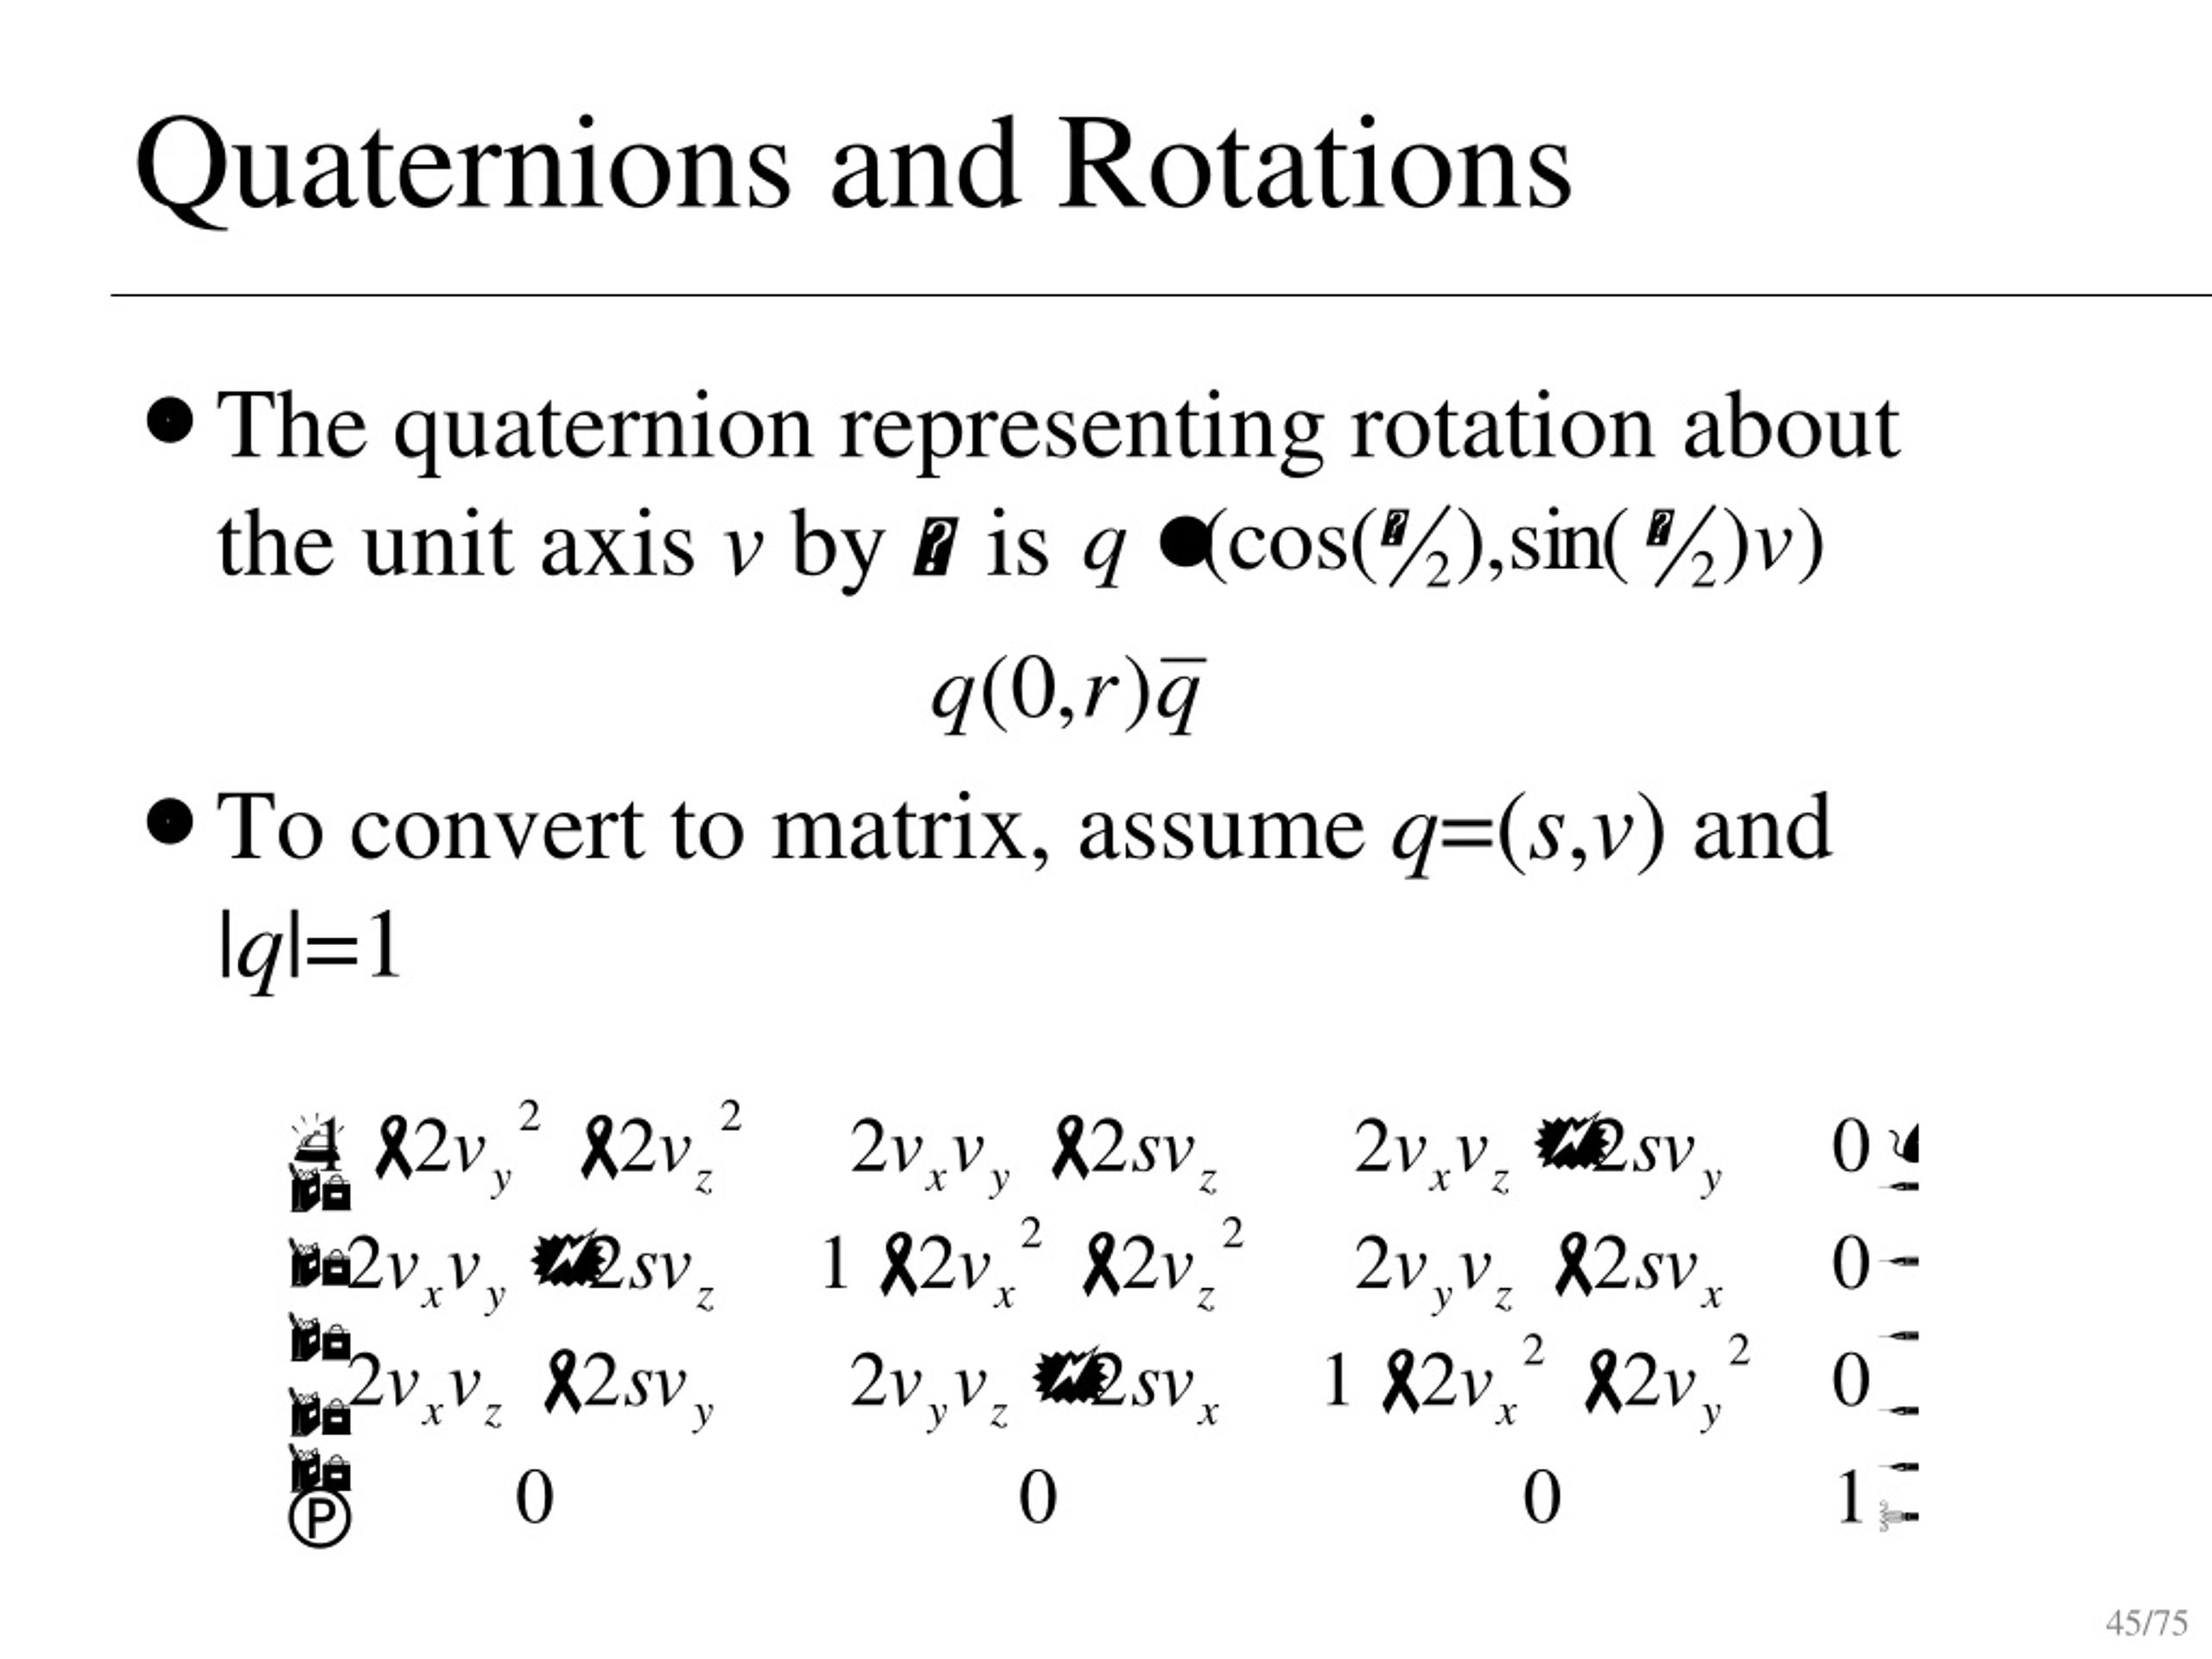
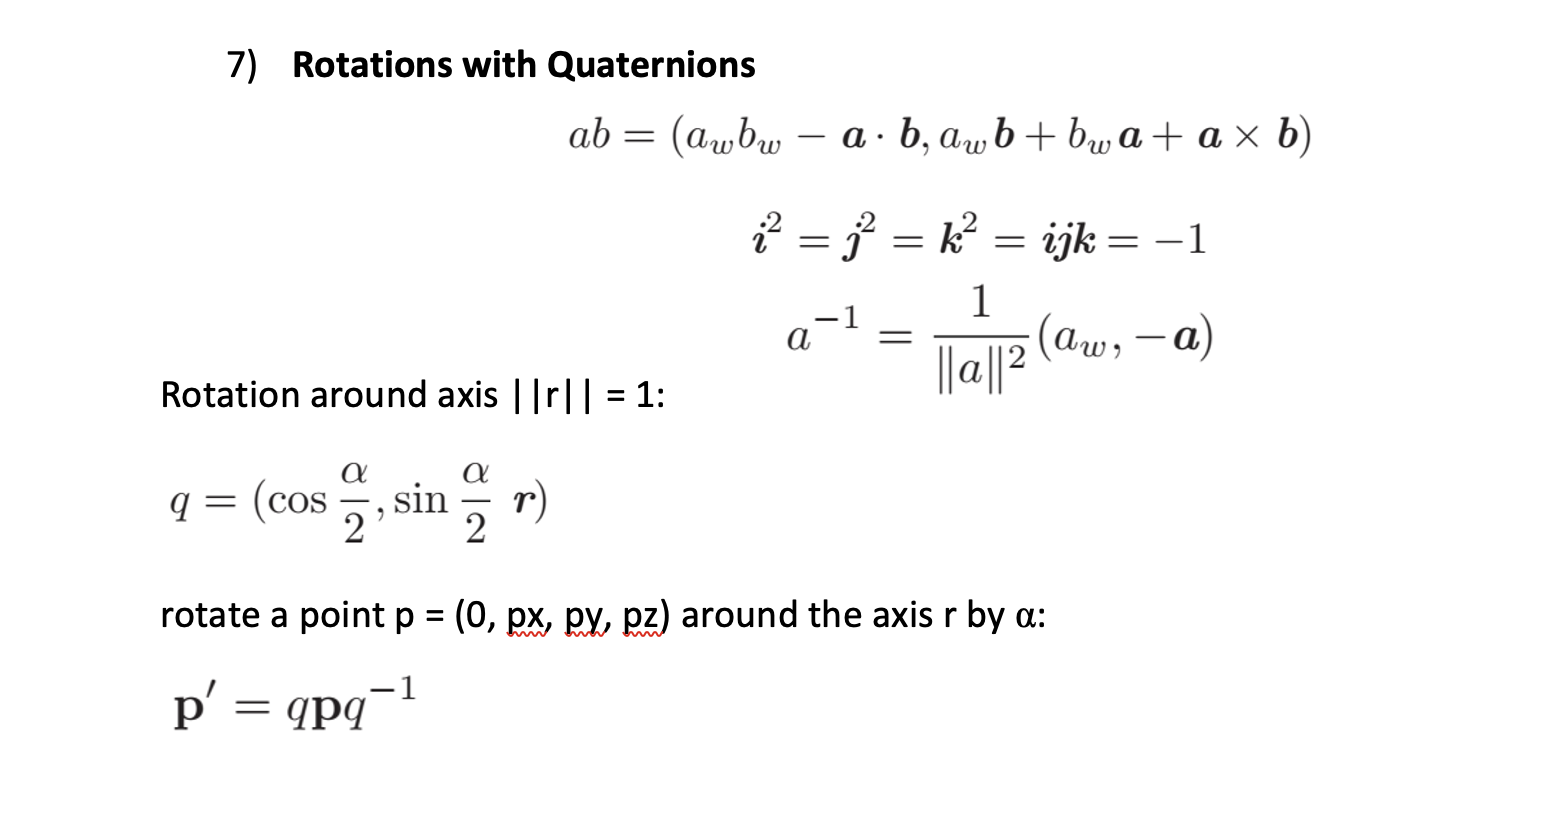
A quaternion is a four-component number system. You write it as q = w + xi + yj + zk, where w is the scalar part and (x, y, z) is the vector part. The i, j, k components follow specific multiplication rules: i² = j² = k² = ijk = -1. That's it. That's the whole thing. The multiplication rules are non-commutative, meaning ij ji, which is exactly what makes them useful for rotations rather than just another way to store four numbers. For representing rotations, you use a unit quaternion where w² + x² + y² + z² = 1. The relationship to a rotation axis and angle is straightforward: if you want to rotate by angle around unit axis (a, a, a_z), the quaternion is w = cos(/2)
(x, y, z) = sin(/2) · (a, a, a_z) Notice the half-angle. That's not arbitrary. It comes directly from the double cover relationship between the quaternion group and SO(3), which is where double groups enter the picture.
Get the Full Details

Rotations Quaternions And Double Groups
The connection between quaternions and rotation groups goes deeper than most programmers ever need to know, but understanding it matters when your application involves spinors, molecular symmetry, or anything where the topology of the rotation group becomes relevant. SO(3), the group of all 3D rotations, has a topological property that makes it awkward to work with directly: it's not simply connected. A loop of rotations that returns to the identity can sometimes not be continuously shrunk to a point. The fundamental group of SO(3) is Z, which means there are two classes of loops. The double cover of SO(3) is SU(2), the group of 2×2 unitary matrices with determinant 1. Unit quaternions are isomorphic to SU(2). This isomorphism means every rotation in 3D space corresponds to exactly two unit quaternions: q and -q. Rotate by around axis n, or rotate by + 2 around the same axis — same physical rotation, different quaternion. That's the "double" part.
Double groups extend this idea to crystallographic point groups. When you have a point group G acting on 3D space, the double group G* is the preimage of G under the covering map from SU(2) to SO(3). In practical terms, this means every symmetry operation in your point group lifts to two elements in the double group. This is essential for classifying electronic states in systems with half-integer spin, because spin-1/2 particles pick up a minus sign under a 2 rotation. Standard point group representation theory doesn't capture that. Double group theory does. I ran into this explicitly when working on a quantum chemistry code that needed to classify Kramers degeneracies in a crystal field. The standard character tables from any textbook were insufficient. I had to construct the double group character table for Dd, which required listing all 24 elements (12 from the original group plus 12 from the same operations composed with a 2 rotation, which in the double group is -E, not E). The irreducible representations split differently than you'd expect from the single group alone. Specifically, the E and T representations of Dd decompose into pairs of double-group representations labeled with a subscript 1/2 or similar notation to indicate their spinor nature.
How Quaternion Rotation Multiplication Actually Works
To rotate a vector v by a unit quaternion q, you compute qvq* where v is treated as a pure quaternion (0, v, v, v_z) and q* is the conjugate (w, -x, -y, -z). The result is another pure quaternion whose vector part is the rotated vector. Composing rotations is where quaternions shine. To apply rotation q then q, you multiply q · q (note the order — opposite of matrix notation convention in most graphics APIs). The composition is a single quaternion multiplication, which takes 16 multiplications and 12 additions. A full matrix composition requires 27 multiplications and 18 additions, plus you have to re-orthogonalize if you're doing repeated compositions to avoid drift. Interpolation is the killer feature though. Slerp (spherical linear interpolation) between two unit quaternions q and q gives you a smooth constant-angular-velocity rotation path. The formula is:

Slerp(q, q, t) = q · sin((1-t)) / sin() + q · sin(t) / sin() where is the angle between q and q. For small angles this degenerates numerically, so you fall back to linear interpolation with normalization. Most implementations handle this branch automatically.
Common Pitfalls That Will Waste Your Time
The biggest issue I see repeatedly is the sign ambiguity. Since q and -q represent the same rotation, if you're interpolating between quaternions from different sources, you might end up slerping the long way around the sphere. The fix is simple: before interpolating, check the dot product of the two quaternions. If it's negative, negate one of them first. This ensures you're always taking the shortest path. Another gotcha: when converting from a rotation matrix to a quaternion, the naive formula that computes all four components using square roots can hit division-by-zero or catastrophic cancellation when the trace is near zero. The robust approach checks which component has the largest magnitude first and computes from there, avoiding the degenerate case entirely. I use a switch on the trace sign and magnitude as the initial branch point. Double groups introduce a separate layer of complexity. If you're doing representation theory work with them, you need the full multiplication table of the double group, not just the original group. The projective representations of G become ordinary representations of G*. For computational purposes, this means your basis functions (typically spinor-valued) transform under the double group, and you need to track both the rotation and the sign change carefully. In practice, I found that constructing the double group elements explicitly as 2×2 complex matrices and working entirely in SU(2) was cleaner than trying to carry around the group multiplication rules abstractly. The matrices make the sign behavior transparent.
When Quaternions Are the Wrong Tool
Quaternions aren't a universal solution. They don't compose nicely with reflection operations — if your transformation includes improper rotations (determinant -1), you need to handle those separately, typically by tracking a reflection parity bit alongside the quaternion. They also don't generalize to non-unit quaternions in an intuitive way for rotation purposes; scaling and rotation mixed together requires dual quaternions, which are a completely different beast. For pure rotation interpolation and composition in 3D, unit quaternions are still the best general-purpose tool. Rotation matrices are better when you need to combine rotations with non-uniform scaling or shearing in a single transformation. Euler angles still have their place in user interfaces where someone needs to intuitively specify yaw-pitch-roll values, but they should never be the internal representation. If you're working on something that genuinely requires double group theory — band structure calculations, molecular term symbols, topological quantum computing — the standard quaternion rotation toolbox isn't enough. You need representation theory of compact Lie groups, and the software support for that is sparse outside of specialized packages like GAP or MAGMA. For everything else, quaternions will serve you well as long as you respect the sign ambiguity and keep your quaternions normalized.