Getting The Physics Right Before You Build Anything
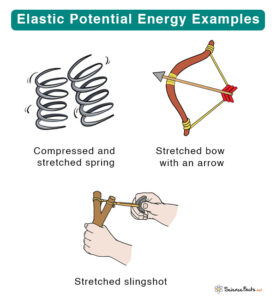
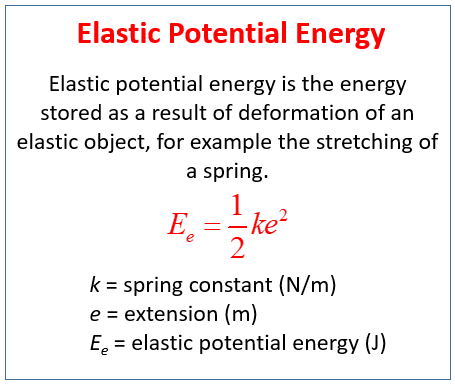
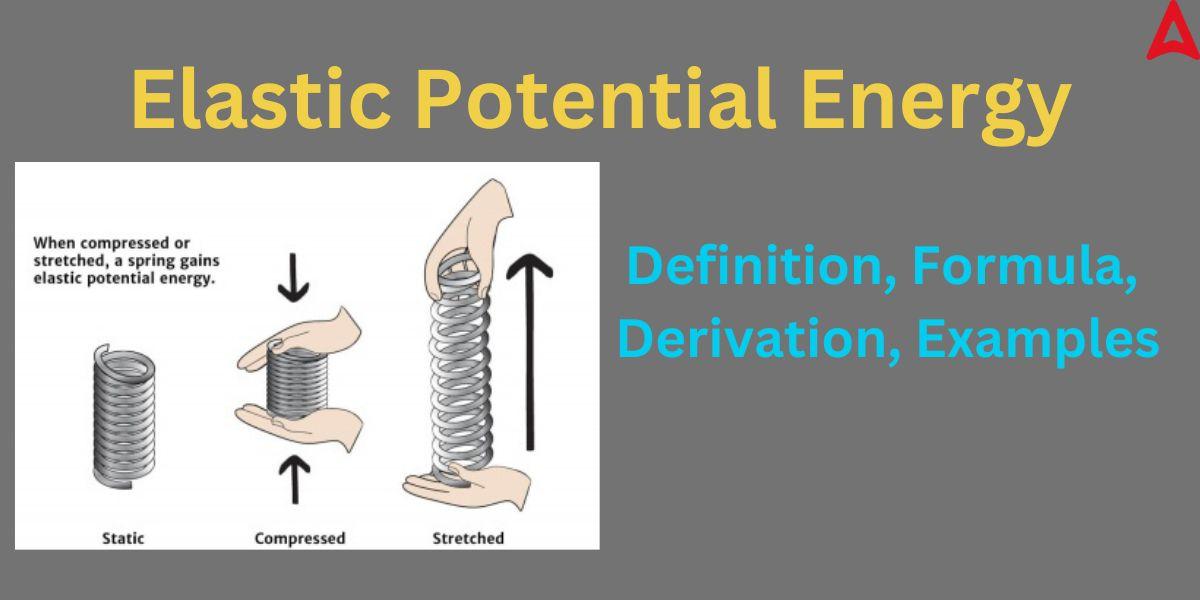
I spent way too many hours debugging simulations where the energy accounting didn't balance. The root cause was almost always a sloppy understanding of how elastic potential energy actually behaves under non-ideal conditions. Most textbooks present it as a clean formula. Real-world applications are messier than that. The scientific definition of elastic potential energy describes the energy stored in an object when it is temporarily deformed by a force and returns to its original shape once that force is removed. It is the energy held within an elastic body or material as a result of work performed to distort its volume or length.
The Scientific Definition Of Elastic Potential Energy
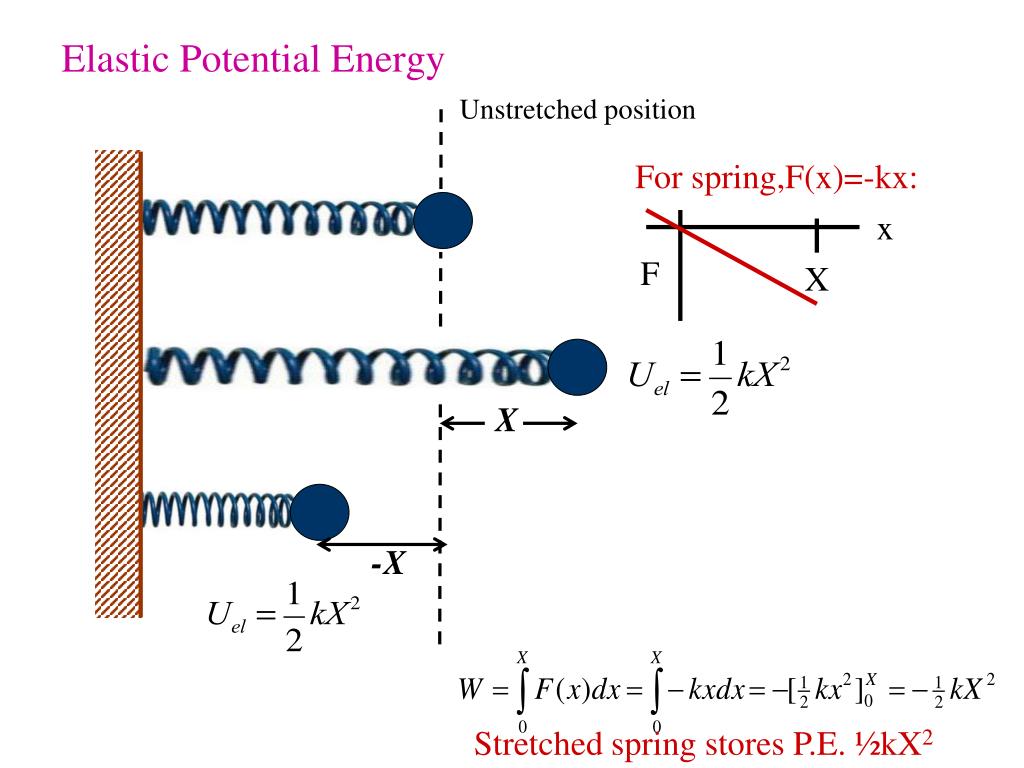
Formally, for a linear spring obeying Hooke's law, the elastic potential energy stored is U equals one-half k x squared, where k is the spring constant and x is the displacement from the equilibrium position. This derivation assumes the force is directly proportional to displacement. That assumption breaks down fast when you move beyond small deformations or into materials with non-linear stress-strain relationships. Here is where people get tripped up. The formula U equals one-half k x squared only applies when the material stays within its elastic limit. Push past that and you are no longer storing reversible energy. You are doing plastic deformation. The energy gets dissipated as heat, microstructural changes, or permanent shape distortion. It does not come back when you release the load. I ran into this repeatedly when designing suspension systems for off-road vehicle prototypes. The spring rate charts from the manufacturer assumed linear behavior up to a certain point. In practice, the coils began binding around two-thirds of maximum compression. The effective spring constant jumped nonlinearly. Using the standard formula at that point gave me energy estimates that were off by roughly forty percent compared to actual dyno measurements. The workaround was to map the actual force-displacement curve at incremental points and integrate numerically rather than rely on the closed-form equation. A simple trapezoidal integration over the measured data points brought the error down to under five percent.
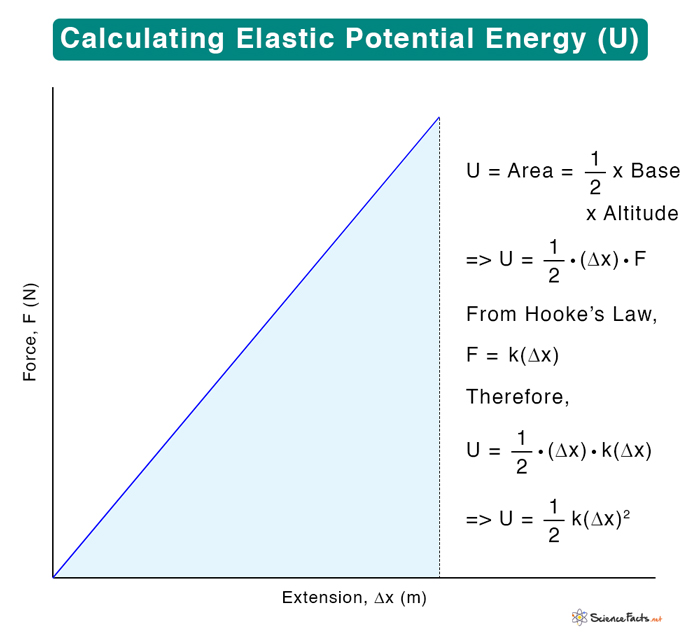
Another nuance that rarely gets emphasized. The one-half factor in front of k x squared exists because the force is not constant during compression. It ramps up linearly from zero to kx. The average force over that displacement is one-half kx. Multiply by x and you get one-half kx squared. If you assumed the full force kx applied across the entire distance, you would double the correct value. This seems obvious until you see someone apply the maximum force across the full displacement in a simulation and wonder why the energy numbers are inflated. For non-spring elastic systems like rubber bands, polymers, or biological tissues, the Hookean model is basically useless. These materials show hysteresis. The loading curve and unloading curve do not overlap. Energy is lost during each cycle. The area between the two curves represents heat dissipated. When I worked on prosthetic feet design, the rubber-based elastic elements recovered only about sixty-five percent of the input energy per step. The rest became thermal energy. Any model using simple one-half kx squared for those components would significantly overestimate the returnable energy and produce unrealistic performance predictions. Shear deformation also stores elastic potential energy but requires a different formulation. Instead of one constant k, you deal with shear modulus and geometric factors. A rectangular block undergoing simple shear stores energy per unit volume as one-half times shear stress times shear strain. Engineers working on vibration dampers and seismic isolation bearings need to account for this separately from axial compression energy. Mixing them up leads to incorrect total energy calculations.
Get the Full Details
The practical takeaway is that the standard formula is a starting point, not a complete solution. It works well for metal springs within their linear range, small deformations of stiff materials, and textbook problems. It fails or requires modification for large strains, viscoelastic materials, non-Hookean polymers, combined loading states, and any scenario involving plastic deformation. When accuracy matters, measure your actual force-displacement behavior and integrate. Don't trust the formula blindly. I have seen projects derailed because someone treated a rubber mount as a linear spring and sized it using one-half kx squared. The mount failed within months under cyclic loading. The real issue was fatigue from repeated plastic deformation that the simple model never predicted. Characterize the material properly first. Then decide whether the standard equation applies or whether you need a more complete constitutive model.