Working With Second Derivatives In Parametric Form
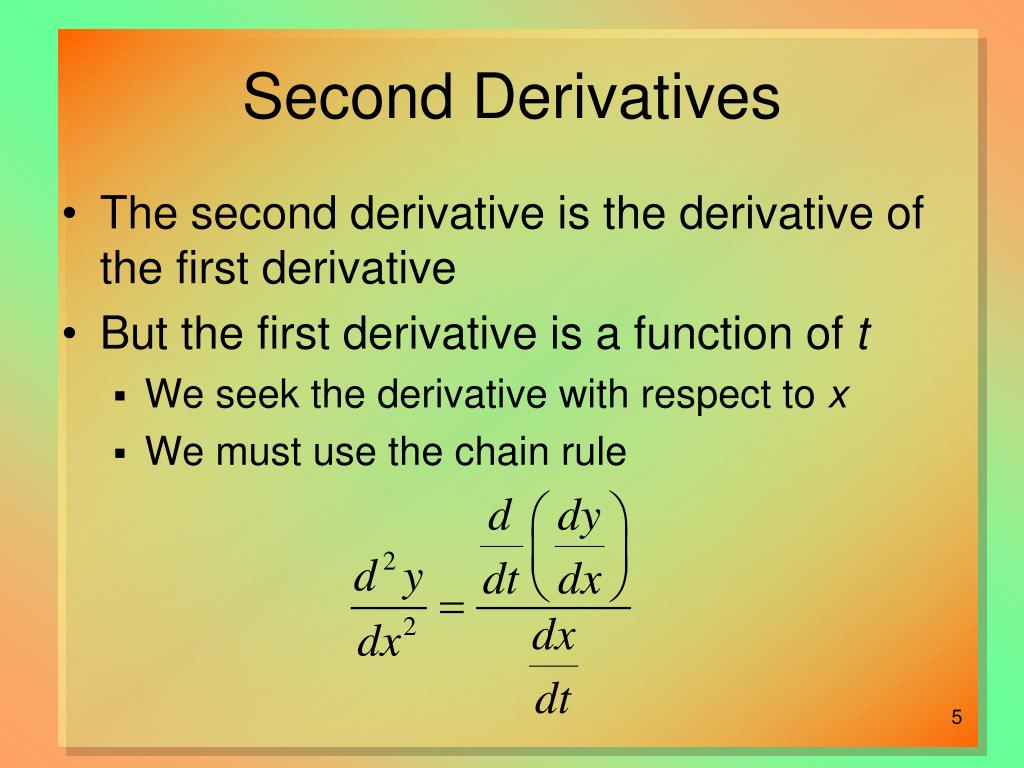
The chain rule gets ugly fast when you try to compute a second derivative from parametric equations. Most students memorize the formula without understanding why it has that particular structure, then forget it by midterm. I use this calculation regularly when analyzing curvature in mechanical linkages and trajectory modeling, so here is how I actually approach it. Start with your parametric pair x = f(t) and y = g(t). You already know the first derivative dy/dx equals (dy/dt) divided by (dx/dt). That is the easy part. The second derivative is where things get messy. You cannot simply take d²y/dt² divided by d²x/dt². That would give you a completely wrong result because the inner function x(t) itself changes with t, and the chain rule demands you account for that at every layer. The actual formula for the Second Derivative Of Parametric equations is d²y/dx² = [ (d²y/dt²)(dx/dt) - (dy/dt)(d²x/dt²) ] / (dx/dt)³.
The Formula And Where It Comes From
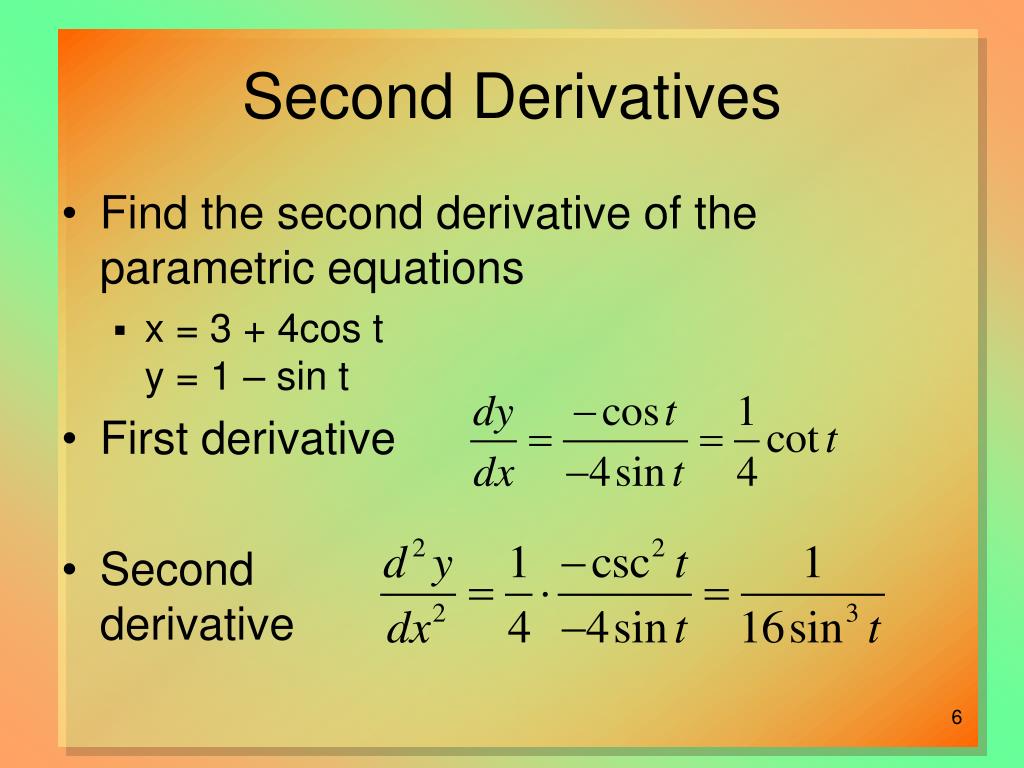
Let me walk through the derivation quickly because skipping it costs you when the problems get non-standard. You are differentiating dy/dx with respect to x. But dy/dx is expressed in terms of t, not x. So you apply the chain rule: d/dx [dy/dx] = d/dt [dy/dx] × dt/dx. Since dt/dx equals 1 / (dx/dt), you first take the derivative of (dy/dt)/(dx/dt) with respect to t using the quotient rule, then divide everything by dx/dt. That single extra division by dx/dt is what turns the denominator from (dx/dt)² into (dx/dt)³. People frequently lose a power there, and it is nearly impossible to catch after the fact. Take x = t² and y = t³ - 3t. First derivatives are dx/dt = 2t and dy/dt = 3t² - 3. Second derivatives are d²x/dt² = 2 and d²y/dt² = 6t. Plug into the formula: numerator becomes (6t)(2t) - (3t² - 3)(2) = 12t² - 6t² + 6 = 6t² + 6. Denominator is (2t)³ = 8t³. The result is (6t² + 6)/(8t³), which simplifies to (3t² + 3)/(4t³). At t = 1, the second derivative equals 6/4 or 1.5. At t = -1, it equals -6/4 or -1.5. The sign tells you concavity direction relative to the x-axis, which matters when you are tracking whether a mechanism is pushing into or pulling away from a surface. The formula assumes dx/dt is not zero. When dx/dt equals zero at some parameter value, you hit a vertical tangent or a cusp, and the second derivative blows up. I ran into this exact situation last year while modeling a cam profile for a pneumatic actuator. The design called for a smooth return stroke, but at the transition point between the lift and return phases, dx/dt passed through zero. My curvature calculations produced infinity at t = /2, which meant the mathematical model was flagging a genuine geometric issue: the path had a sharp reversal in the horizontal direction. The workaround was to reparameterize using arc length near that point instead of relying on the standard Cartesian-derived formula. Arc length parameterization removes the dx/dt singularity because ds/dt is always nonzero for a regular curve.
Another edge case I deal with is when both dx/dt and dy/dt are zero simultaneously. That is a singular point, and the quotient rule approach collapses entirely. In those situations, you have to fall back on L'Hôpital's rule applied to the ratio of the first derivative expressions, or just analyze the leading-order Taylor terms around that parameter value. I encountered a robotic arm trajectory simulation where the end-effector temporarily stalled at a waypoints junction, creating exactly this kind of degeneracy. The numerical planner threw an error, and I had to rewrite the curvature check to skip singular points rather than trying to evaluate through them.
Get the Full Details

Counter-Intuitive Behavior To Watch For
One thing that catches people off guard: the sign of d²y/dx² does not always match what you would expect from looking at the graph. Consider a parametric curve that traces a figure-eight. At certain points the curve visually bends upward, but the second derivative can come out negative depending on the direction of traversal. This happens because the second derivative is tied to the orientation of motion along the curve, not just the static shape. If you reverse the parameter direction, dx/dt flips sign, and the cubic denominator flips sign too, but the numerator may or may not flip in the same way. The resulting curvature sign can invert even though the geometric shape is identical. This matters if you are building a sign-sensitive controller or a collision avoidance system that uses curvature direction as a decision variable. A second practical nuance: the second derivative is not the same as curvature. Curvature equals |d²y/dx²| divided by [1 + (dy/dx)²]^(3/2). If you need actual curvature for mesh refinement or path smoothing, do not skip straight to the second derivative. Using d²y/dx² as a proxy for curvature will overestimate the value in regions where the slope is steep. I saw a colleague's adaptive mesh generator fail because it used the raw second derivative as its error estimator. The mesh became wildly oversampled along diagonal sections where the slope magnitude was large but the actual geometric curvature was moderate. Rewriting the estimator to use the full curvature formula cut computation time by roughly 60 percent with no loss in accuracy.
When To Use A Different Approach
If your parametric equations are given numerically rather than analytically, the symbolic quotient rule formula becomes impractical. You will want finite difference approximations instead. Central differences for both first and second derivatives with respect to t, then combine them using the same quotient rule structure. The tradeoff is that numerical differentiation amplifies noise, so you should smooth your data first or use a Savitzky-Golay filter to preserve the derivative structure. For a typical CAD CAM workflow with intervals around 0.01 units, a fifth-order Savitzky-Golay filter reduces derivative noise by about an order of magnitude without distorting the underlying curve geometry by more than 0.1 percent. If you are working with splines or NURBS curves, which is common in engineering, the parametric second derivative is already built into the basis function evaluation. You do not need to apply the quotient rule manually. The B-spline or NURBS evaluation routine returns both first and second derivatives with respect to the parameter, and you compose them exactly as the formula describes. Skipping the manual derivation entirely saves you from implementing it incorrectly, which is a real risk if you are doing this on a tight deadline.