Why Your F equals m a Calculations Keep Failing in Real Simulations
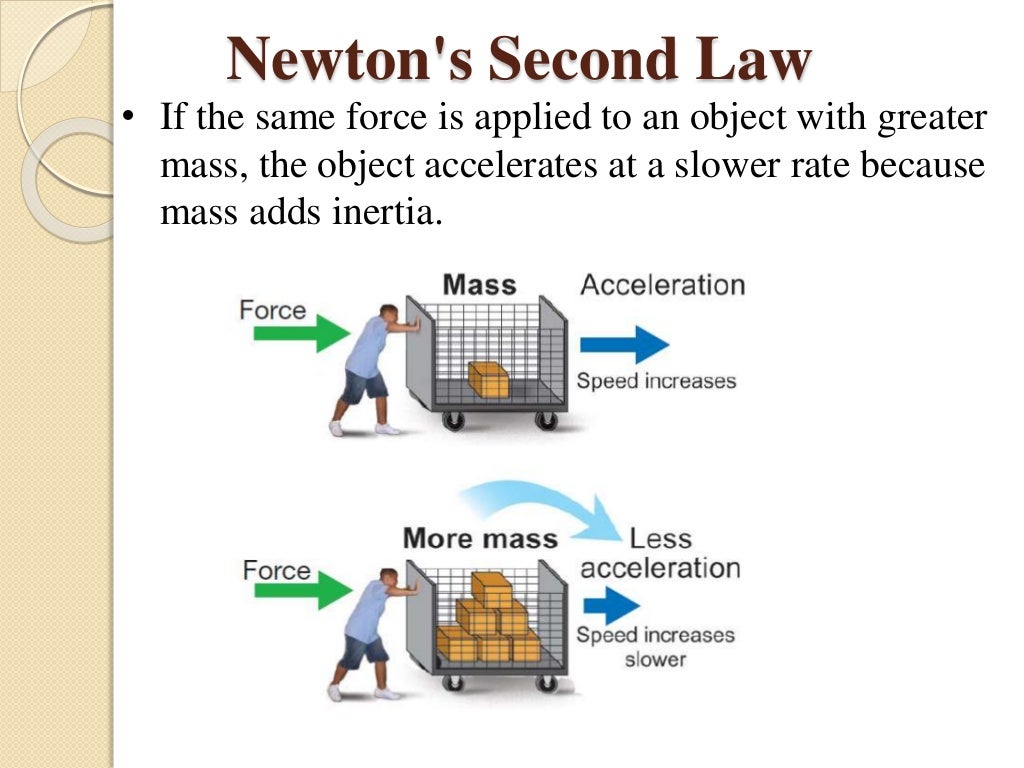
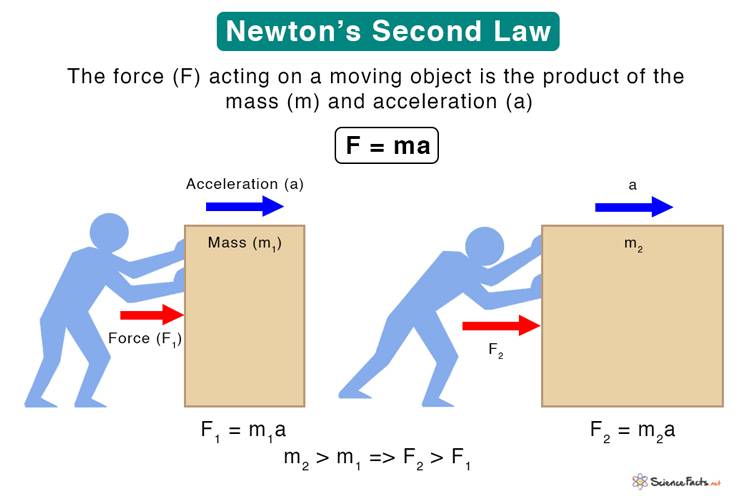
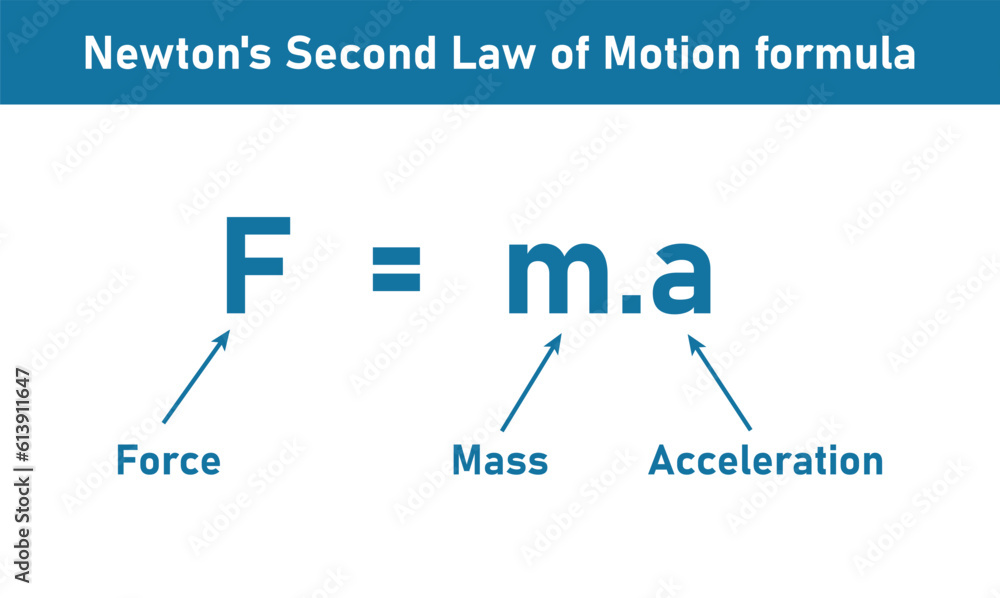
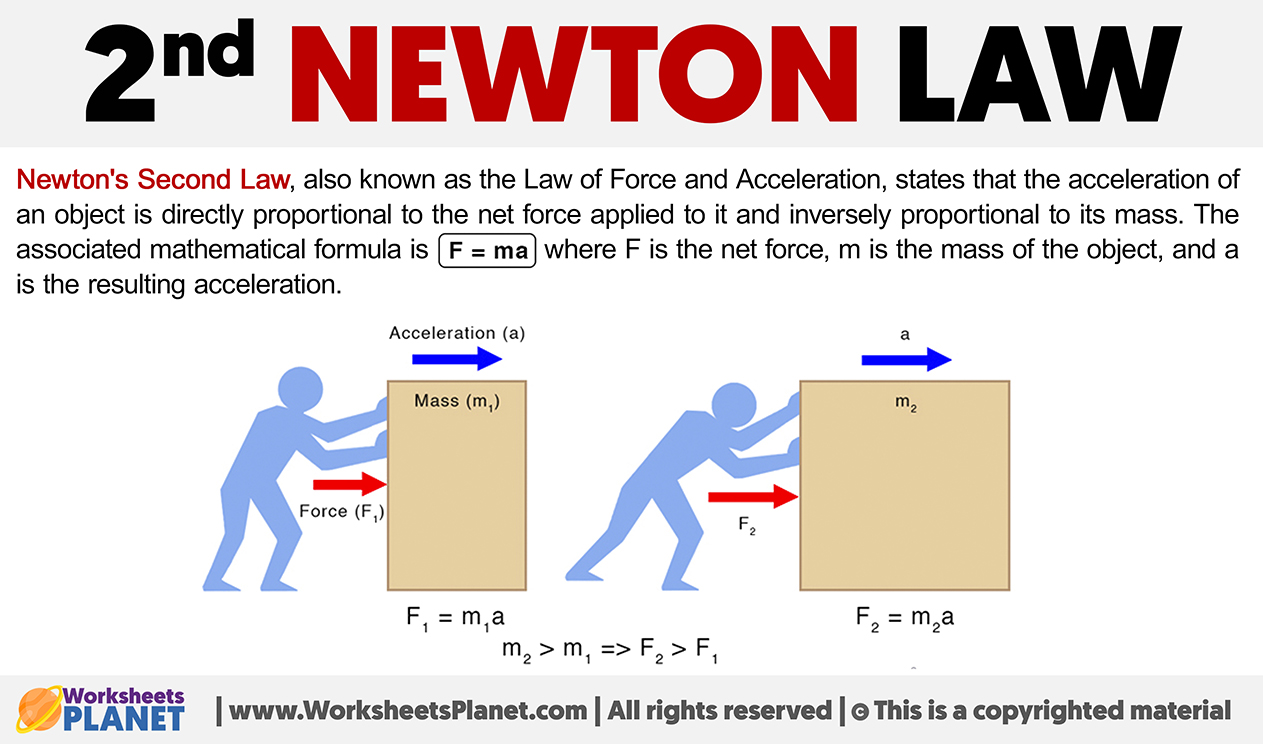
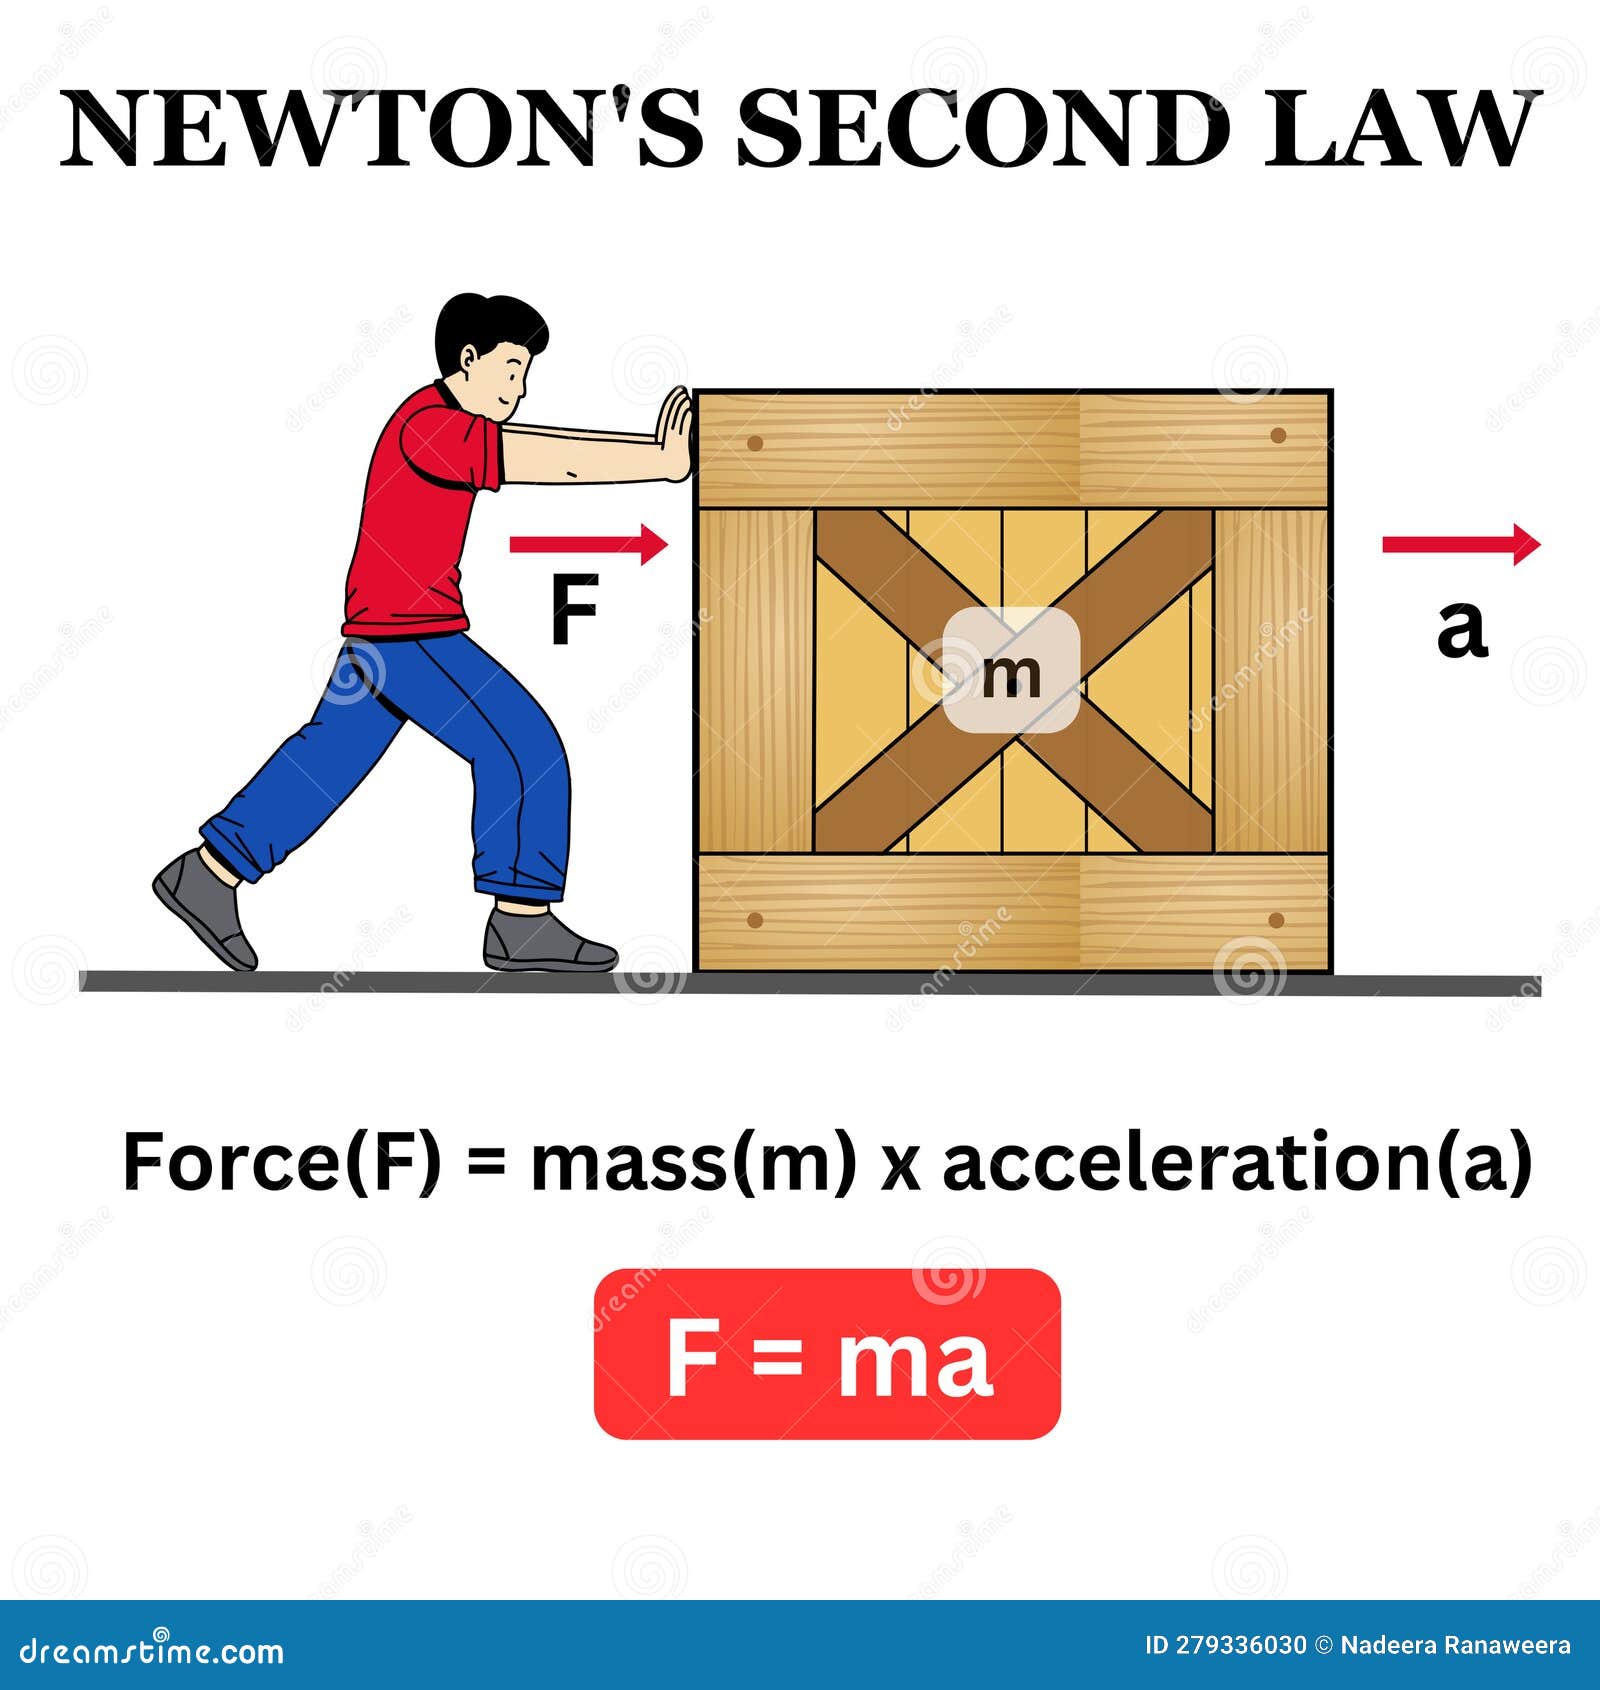
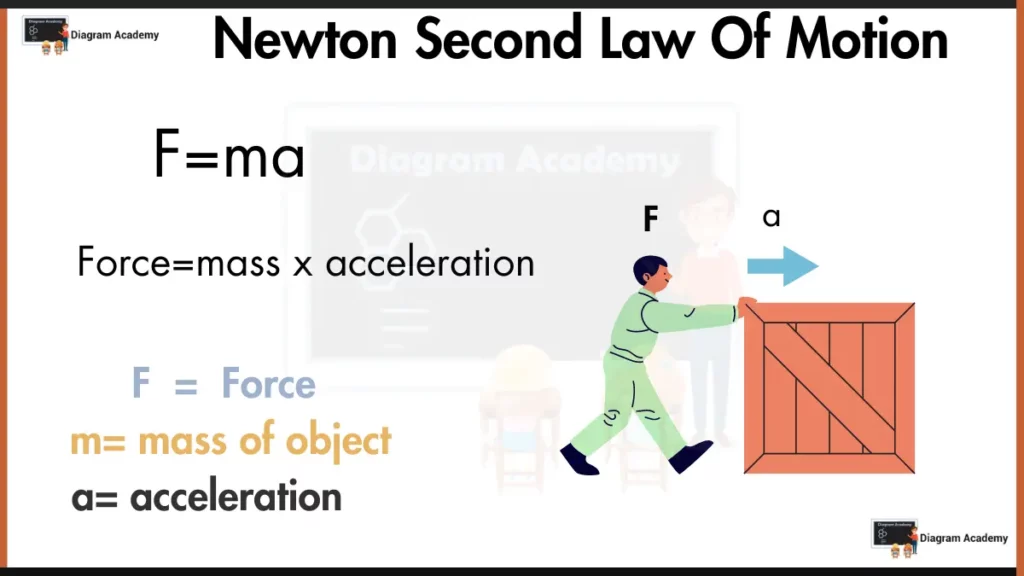
You probably learned Newton's Second Law as F equals m times a and moved on. That equation works fine for textbook problems with point masses on frictionless planes. Real mechanics doesn't care about your textbook assumptions. I spent three weeks debugging a simulation last year where every test case matched the analytical solution until I introduced variable mass, and then the entire system diverged because nobody told me to use the full form before reverting to the simplified version. The shortcut kills you in edge cases. The correct form isn't F equals m a. It's force equals the time derivative of momentum, written as F equals d over dt of m v. When mass stays constant, that collapses to the familiar F equals m a that everyone memorizes. When mass changes, like in a rocket burning fuel or a conveyor belt picking up material, the simplified form gives wrong answers immediately. The expanded form becomes F equals m times dv over dt plus v times dm over dt, and that second term is what people forget until their project blows up. I ran into this exact problem while modeling a granular flow system where particles accumulated mass as they fell through a powder stream. Using F equals m a produced trajectories that drifted by nearly forty percent over a ten second simulation window. Switching to the momentum form corrected it in under an hour of adjustment. The acceleration of the center of mass equals the net external force divided by the instantaneous mass, but only if you're tracking mass correctly at each timestep.
What Actually Determines Acceleration in Practice
Force and acceleration are vectors. Direction matters as much as magnitude, and most errors in practical applications come from ignoring the directional component or projecting forces onto the wrong axis. If you have a block on an incline with friction, the normal force isn't equal to mg. It's mg cos theta, and the friction force scales from that normal, not from the full weight. Students and hobbyists miss this constantly because they treat gravity as if it always acts perpendicular to the surface underneath an object. Net force means the sum of all forces acting on the body, not just the applied force you're interested in. Friction, drag, tension, normal forces, and any constraint reactions all count. In a typical undergraduate lab setup with a pulley and hanging mass, the tension in the string isn't equal to the weight of the hanging mass. It's less, because the hanging mass itself accelerates downward. The correct tension works out to two m one m two over m one plus m two times g for the standard Atwood machine configuration.
When Classical Newtonian Mechanics Stops Working
At velocities approaching the speed of light, F equals dp over dt still holds, but momentum is no longer m v. You need the relativistic form where p equals gamma m v and gamma is one over the square root of one minus v squared over c squared. The acceleration doesn't point in the same direction as the force when velocities get high enough. Force parallel to velocity produces different acceleration than force perpendicular to velocity, which is completely counter-intuitive if you only learned the classical version. On atomic and subatomic scales, quantum mechanics takes over and the concept of a definite trajectory breaks down. You can't meaningfully assign a position and momentum simultaneously with arbitrary precision. Newton's Second Law has no place in that domain unless you're doing semi-classical approximations, and even those have strict validity boundaries. Most people who ask about applying Newtonian mechanics to quantum systems don't realize they've walked into a regime where the entire framework needs replacement.
Get the Full Details
Common Pitfalls That Waste Time
The biggest mistake I see repeatedly is treating systems with changing reference frames as if they were inertial. If you're analyzing motion from an accelerating platform, you need fictitious forces like the Coriolis and centrifugal terms, or your equations are wrong. A common real-world example is trying to apply F equals m a directly in a rotating frame without correction. The results will be off by amounts that scale with the square of the angular velocity, which can be enormous even at moderate rotation rates. Another frequent error is assuming constant acceleration when forces depend on position or velocity. Spring forces, drag forces proportional to velocity squared, magnetic forces on moving charges—all of these make acceleration a function of state variables rather than a constant. You can't use kinematic equations in those cases. You need to set up and solve differential equations, usually numerically for anything beyond the simplest configurations. Analytical solutions exist for linear drag but disappear quickly once you add quadratic terms.
How to Set Up a Correct Analysis Step by Step
Draw a free body diagram before writing any equations. Every force acting on the object, arrows pointing in the correct direction, labeled with magnitude and type. This sounds obvious but skipping it causes more errors than any conceptual misunderstanding. Identify the coordinate system and project all forces onto those axes. Check that your axes align with the natural constraints of the problem whenever possible. Write the equation for each axis separately. Sum of forces in x equals mass times acceleration in x, and do the same for y and z if needed. Solve for the unknowns systematically. If mass is variable, use the momentum derivative form from the start rather than deriving it after you've already made the wrong assumption. Verify your answer makes dimensional sense and check boundary conditions like zero force producing zero acceleration.
Practical Debugging When Results Don't Match Expectations
When your calculated acceleration doesn't match experimental data or a reference solution, check these items in order. Confirm you included every force, especially friction and normal forces that sometimes get overlooked. Verify your coordinate projections, particularly on inclined planes where sin and cos get swapped accidentally half the time. Make sure your mass value is the total mass of the system you're analyzing, not just a component. Check whether the frame of reference is actually inertial for the problem at hand. I once spent two days tracking down a discrepancy in a dynamics lab where our predicted and measured accelerations differed by about eight percent. The issue turned out to be that we hadn't accounted for the rotational inertia of the pulley. The pulley had mass and radius, and torque was required to angularly accelerate it. That drained energy from the linear system and reduced the acceleration of the hanging masses. Once we included the moment of inertia term, the prediction matched measurement within one percent. The textbook example we'd been following assumed a massless pulley, which is fine for simple exercises but lies to you in real applications.
Limitations You Should Accept Upfront
Newton's Second Law in its classical form applies strictly to point particles or rigid bodies in inertial frames. Extended deformable bodies require continuum mechanics and stress-strain relationships. Systems with significant relativistic speeds need Lorentz-covariant formulations. Quantum systems need entirely different mathematical structures. Even within classical mechanics, chaotic systems become practically unpredictable over long timescales despite being governed by deterministic equations, which means numerical integration errors compound rapidly in those cases. For most engineering and physics applications below relativistic speeds and above atomic scales, the classical form is sufficient and remains one of the most useful tools in the discipline. The key is knowing when you're inside its valid domain and when you've crossed a threshold that demands a different approach. That line isn't always obvious until you hit it.