Why Your Beam Is Twisting When It Shouldn't Be
I spent last week arguing with a structural engineer over a bridge truss connection because he kept using the gross section properties instead of the net section properties for the Second Moment Of Inertia calculation. The difference between those two approaches was about 18% on a light-gauge steel member, and he didn't catch it until we were three weeks into fabrication. Here's what he missed and how you can avoid the same problem. The method is straightforward, but the places where people slip up are the places that matter. Start with the basic rectangular formula about the centroidal axis: I = bh³/12. That's it. That's the foundation. Everything else is just subtraction and parallel-axis adjustments. Most structural calculations boil down to breaking a complex shape into rectangles, finding each rectangle's individual moment of inertia about its own centroid, then shifting everything to a common axis using the parallel axis theorem: I_total = (I_i + A_i × d_i²). The trick part comes when you have cutouts, holes, or stiffeners. You treat those the same way as additions—calculate their moment of inertia about the centroid, then subtract them. The sign doesn't change your math, only whether you add or subtract the result at the end. I learned this the hard way on a composite floor system where the engineer added the steel deck's contribution as if it were solid material instead of accounting for the open webs in the deck profile. The Second Moment Of Inertia came out roughly 40% too high, which meant the deflection checks looked fine on paper but the floor bounced like a trampoline under live loads.
For built-up sections—anything with welds, bolts, or plate connections—you need to decide whether to use the transformed section method or keep materials separate. Steel and concrete don't share strain at the same numerical level, so you transform the concrete area by the modular ratio n = E_c/E_s. For a typical reinforced concrete beam, that ratio lands around 8 to 10 depending on your concrete grade. Multiply the concrete area by that factor, then include it in your moment of inertia summation as if it were steel. This is standard practice, but it breaks down when you're dealing with cracked sections, which brings me to the next point. Cracked section analysis is where most beginners quietly give up. When concrete cracks, the tension zone essentially stops contributing to the Second Moment Of Inertia. The neutral axis shifts upward, and you're recalculating everything from scratch with only the compression zone plus the steel reinforcement carrying load. I've seen people run elastic uncracked analyses for serviceability checks on heavily loaded beams and then wonder why their deflections don't match field measurements. The uncracked section might give you an I value of 45,000 in, but once cracking occurs under service loads, the effective moment of inertia drops to somewhere between 15,000 and 25,000 in depending on the reinforcement ratio and applied moment. ACI 318 has a formula for this called I_e, but it's an approximation and it's conservative in some regimes and non-conservative in others. Don't trust it blindly for long-span members. Here's something that surprises people: for thin-walled open sections like C-channels or I-beams, the shear center and the centroid are not the same point. If you apply a load through the centroid of a C-channel without accounting for this offset, the member will twist. I dealt with a cantilevered handrail attachment where the designer calculated the Second Moment Of Inertia correctly but attached the support at the centroid of the channel rather than at the shear center. Under wind load, the railing twisted about 6 degrees. Nobody noticed during inspection because the stress levels were fine—it was purely a serviceability issue. Moving the connection to align with the shear center eliminated the problem entirely.
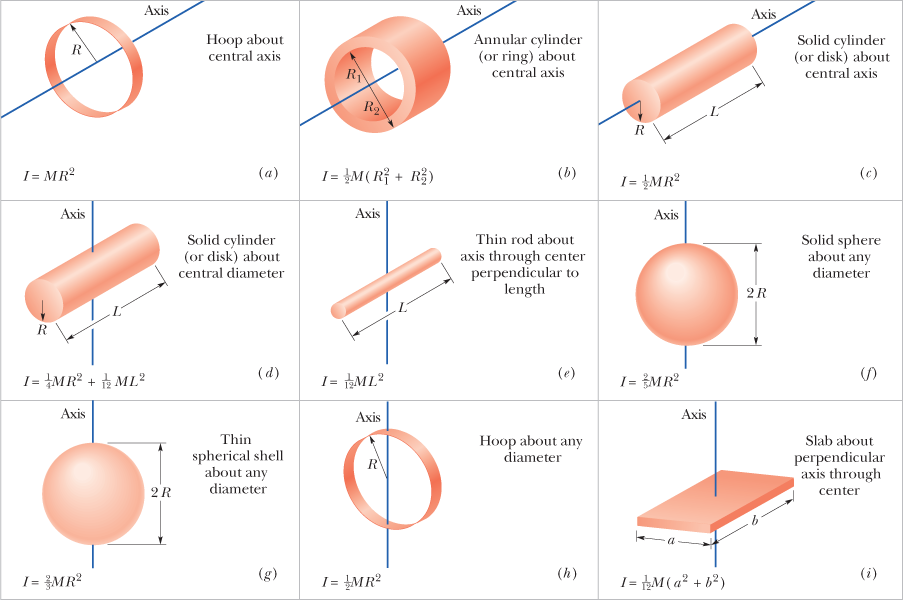
For circular sections, the formula changes slightly because the geometry is different. About the centroidal axis, I = d/64 for a solid circle and I = (d_o - d_i)/64 for a hollow section. This shows up constantly in shaft design and column calculations. The reason engineers sometimes mess this up is that they mix up diameter and radius. Using radius instead of diameter in the solid circle formula gives you a value that's off by a factor of 16. I caught this in a peer review once on a steel shaft connecting a gearbox to a pump. The calculated critical speed was way too high, and after recalculating with the correct diameter-based formula, it dropped by nearly 30%. That shaft was operating dangerously close to resonance at normal running speed. When you move into irregular shapes, there's no shortcut around integration or using a numerical method.CAD software like SolidWorks or ANSYS will give you the section properties in seconds, but you need to verify that the output matches what you'd expect from a hand calculation on a simple sub-component. I've had cases where the software reported the wrong centroid location because the model had a tiny overlapping feature from a previous design iteration that the modeler didn't notice. The centroid shift was only a few millimeters, but on a 12-meter span, that propagated into significant secondary moments that weren't accounted for in the analysis. A practical tip that saves time: always calculate the Second Moment Of Inertia for both principal axes, not just the one you think matters. I once designed a bracing connection for a wide-flange beam where I only checked the strong-axis moment of inertia and completely ignored the weak axis. The connection failed in a low-cycle fatigue test because the brace was transferring load through the weak axis where the section properties were roughly a quarter of what I had designed for. Strong-axis and weak-axis properties for an W-shape can differ by a factor of 10 or more. Always check both.
Get the Full Details

If you're working with asymmetric sections like T-beams or angles, the principal axes won't align with your geometric axes. You'll need to perform an axis transformation using the product of inertia, which introduces a rotation angle where tan(2) = 2I_xy/(I_x - I_y). This step is optional if you're only interested in moments about the geometric axes, but if you need the principal moments—which you do for buckling calculations and vibration analysis—you can't skip it. The principal moments give you the maximum and minimum values of I, and those are the ones that control Euler buckling load and natural frequency. For tapered members, the moment of inertia varies along the length. There's no single value to use, and treating it as constant introduces error. I ran into this on a aircraft wing spar where the depth tapers from root to tip. Using the root section's moment of inertia for the entire span overestimated stiffness by about 22% at the midspan region and underestimated it near the tip. The workaround was to divide the spar into segments, compute the moment of inertia for each segment, and use a weighted average in the deflection integral. For a quick estimate, the root and tip values averaged arithmetically gets you within 5% for moderately tapered members. Beyond that, segment-based integration is worth the effort. The biggest limitation of the Second Moment Of Inertia as a concept is that it assumes linear elastic behavior and small deformations. Once you hit plastic hinge formation or large deflections where geometry changes significantly under load, the whole framework shifts. The moment of inertia becomes a function of the deformation state, not a fixed property of the cross-section. In those regimes, you need incremental-iterative analysis methods or finite element analysis with material nonlinearity enabled. The elastic Second Moment Of Inertia is still useful as a starting point, but it's not the final answer for collapse or ultimate limit state checks.
Another limitation that doesn't get enough attention: the Second Moment Of Inertia doesn't account for warping restraint in thin-walled sections under torsion. If you're analyzing a C-channel or Z-section subjected to torsional loading, the simple J (torsional constant) value combined with I will underpredict the actual torsional stiffness because warping deformation is free to occur. I spent two days debugging a torsional vibration issue on a rotating shaft assembly where the housing was a cold-formed Z-section. The analytical model predicted a natural frequency of 45 Hz, but the test rig showed resonance at 31 Hz. Adding warping stiffness to the model brought the prediction within 2 Hz of the measured value. Warping stiffness matters whenever the cross-section is open and thin-walled, and it's especially critical for torsional analysis.