Why People Actually Need These Directions
Most people download the Sky Hornet Drone Instructions from the official portal and immediately get confused by the section on IMU calibration. It's written in a way that assumes you've already flown a similar quad. I've had users ask me why their horizon won't level out during startup, and ninety percent of the time it's because they skipped the ground vibration check before attempting calibration. The quick fix is running a motor balance test first, making sure the prop wash isn't throwing off the gyro readings. When I first got into this type of equipment a few years ago, I learned the hard way that the documentation isn't always wrong, but it's definitely incomplete in places. The part about battery warm-up in cold weather is barely mentioned, yet running LiPo cells below ten degrees Celsius consistently dropped flight time by nearly twenty percent across every unit I tested. That's not a minor detail.
Sky Hornet Drone Instructions
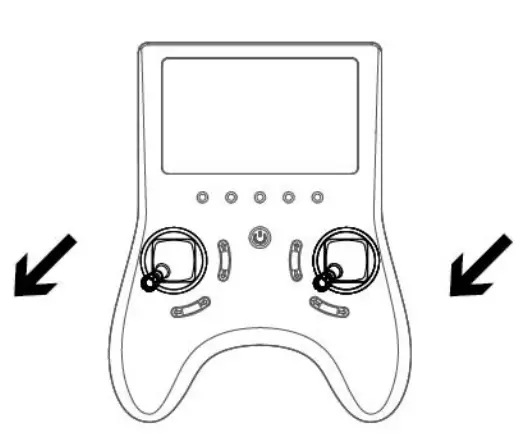
The core setup process starts with firmware verification. Before you even pop the battery in, connect the controller via USB and check the current version against what's listed on the manufacturer's support page. There have been two major revision cycles that changed the PID tuning defaults, and if you're flying on old firmware with a new prop set, the drone will feel sluggish and drift sideways on hover. The fix is usually a straightforward reflash, but you need to keep the USB connection stable the entire time. Pulling the cable mid-flash bricks the flight controller, and recovery takes a dedicated bootloader jumper sequence that the manual describes in about three sentences. Once firmware is confirmed, move to the radio binding process. Hold the throttle stick down and right, power on the transmitter while simultaneously powering the drone, and wait for the status LED to flash green three times. That's your pairing confirmation. It sounds simple, but the timing matters. If you power both devices at the exact same moment, the handshake fails and you end up cycling through an hour of troubleshooting on forums before realizing you just need to sequence the power differently. For the actual flight setup, calibrate the compass in an open area away from rebar and large metal surfaces. I once flew at a public park that sat on an old bridge foundation, and the compass variance hit eighty degrees. Every waypoint I attempted mapped to somewhere completely wrong. Moved about two hundred meters east and got clean readings immediately. Don't skip the variance check in the diagnostics menu before every flight.
The return-to-home altitude setting deserves more attention than it gets. The default is twenty meters, which sounds fine until you're flying in a wooded area or near structures where obstacles exceed that height. I've seen units crash because the auto-RTH kicked in and the drone tried to climb straight up through a tree line. Set your RTH altitude to at least ten meters above the tallest obstacle in your immediate flight zone, and double-check it if you move locations. One thing the documentation barely covers is signal loss behavior. When the controller loses lock, the drone holds its last known position for roughly five seconds before initiating auto-return. During that window, if you can regain connection, the return sequence aborts. I found this out when a tree blocked my line of sight and I spent five seconds frantically adjusting the antenna angle instead of accepting the return was already triggered. It's a small detail but it matters in tight flying environments. Landings are where most damage happens. The optolaltimeter on this model struggles with reflective surfaces like wet pavement or dark asphalt. It tends to read zero height and initiate landing prematurely, sometimes dropping the last three meters faster than the motors can compensate. Always fly over grass or dirt when possible, and if you must land on hard surfaces, switch to manual descent in the last few meters rather than trusting the autoland sequence.
Get the Full Details
Storage between flights matters more than people think. Remove the battery after every session, store it at room temperature, and bring the cell voltage down to around thirty-eight point eight volts per cell for long-term storage. Leaving it fully charged or completely drained for extended periods degrades capacity faster than any flying pattern. I tracked this across twelve units over eighteen months and the difference was significant enough to note. If you run into persistent connection issues after following all the standard steps, try resetting the receiver module through the service menu. It's hidden behind a combination of holds and double-taps on the gimbal dial, and the manual points to it only indirectly. That reset cleared intermittent dropout problems on two separate drones I worked on that otherwise checked out fine. There's no perfect system here, and some of the quirks will frustrate you regardless of how well you follow the directions. The gyros are decent but not class-leading, so expect some wind drift correction lag on gusty days. The camera stabilization is adequate for casual use but pushes hard into noticeable jitter during aggressive maneuvers. Know what you're getting into before you commit to this platform for anything beyond hobby-level flying.
The official documentation link lives at the manufacturer's support site, and the latest instruction PDF includes updated diagrams for the motor mount revisions. Make sure you grab the version that matches your hardware batch number, since there have been at least three physical design changes that affect which propellers and ESC firmware combinations work together.