
Working Through Bergman Chapter 3: What Actually Happens When You Try It
Chapter 3 of Bergman's heat transfer book is where things start getting real. You move past the purely conceptual stuff and into one-dimensional, steady-state conduction with actual equations you can bend to your will. Most students breeze through the first two chapters because they're light on math. Chapter 3 is where people who coasted suddenly get their hands dirty with composite walls, thermal resistances, and the annoying reality of contact resistance. The solution manual for this chapter walks you through problems that look deceptively simple on paper. A plane wall with given boundary conditions. A cylindrical pipe with insulation. The fin equation. Each problem follows a pattern, but the patterns change depending on geometry, and that's where people trip up. I learned this the hard way during my third year when I confidently set up a radial conduction problem using Cartesian assumptions. The answer was off by roughly forty percent. Took me two days of re-deriving from scratch before I caught that the area term varies with radius in cylindrical coordinates. Here's how the solution manual actually works in practice. You get a problem statement, usually involving a composite system, and you need to identify the right control volume and the applicable resistance network. The method is: draw the thermal circuit first. Write down every resistance you can think of — conductive, convective, sometimes radiative if the problem gives you emissivity and surface temperatures. Then solve for the unknown heat rate or temperature. It sounds mechanical, and it should be.
One thing the manual doesn't emphasize enough is the critical radius of insulation problem. This shows up as Problem 3.48 in most editions and it trips people up because the intuition says adding insulation always reduces heat loss. For a cylinder, that's wrong below a certain radius. The critical radius equals k divided by h, where k is the thermal conductivity of the insulation and h is the convection coefficient. If your pipe radius is smaller than that value, adding insulation actually increases heat transfer. I remember staring at a homework problem where the insulation thickness was something like two millimeters on a half-centimeter tube, and my initial answer had heat loss going down. It went up. The manual explains this through the derivation, but it takes reading it three times before it clicks that the surface area term in the denominator of the convection resistance grows faster than the conductive resistance grows with radius. Another edge case that the solutions gloss over is contact resistance. Real surfaces aren't smooth. Even polished metal has asperities, and when two surfaces press together, the actual contact area is a tiny fraction of the apparent area. The air gaps act as insulators. In textbook problems, you're sometimes given a contact resistance value directly, but in practice you'll encounter situations where you need to estimate it or realize it's significant enough to change the whole approach. I once worked on a project involving stacked aluminum plates with bolted joints, and the modeled temperatures were fifteen degrees off from measurements until I added a contact resistance of about 0.004 meter-squared-kelvin per watt to the model. That number came from a handbook table for smooth surfaces under moderate clamping pressure. Without it, the entire thermal network was wrong. When you're working through the fin problems in this chapter, pay attention to the boundary condition at the tip. The manual uses three approaches: infinitely long fin approximation, adiabatic tip, and convection from the tip. The infinitely long assumption only works when the fin parameter times length is greater than about 2.6. Below that, you're introducing meaningful error. The adiabatic tip is the most commonly used correction and it's easily accounted for by using an adjusted length, L plus t over 2 for rectangular fins. The convection tip solution exists but is rarely needed in practice unless you're dealing with very short stubby fins where the tip area is comparable to the surface area.
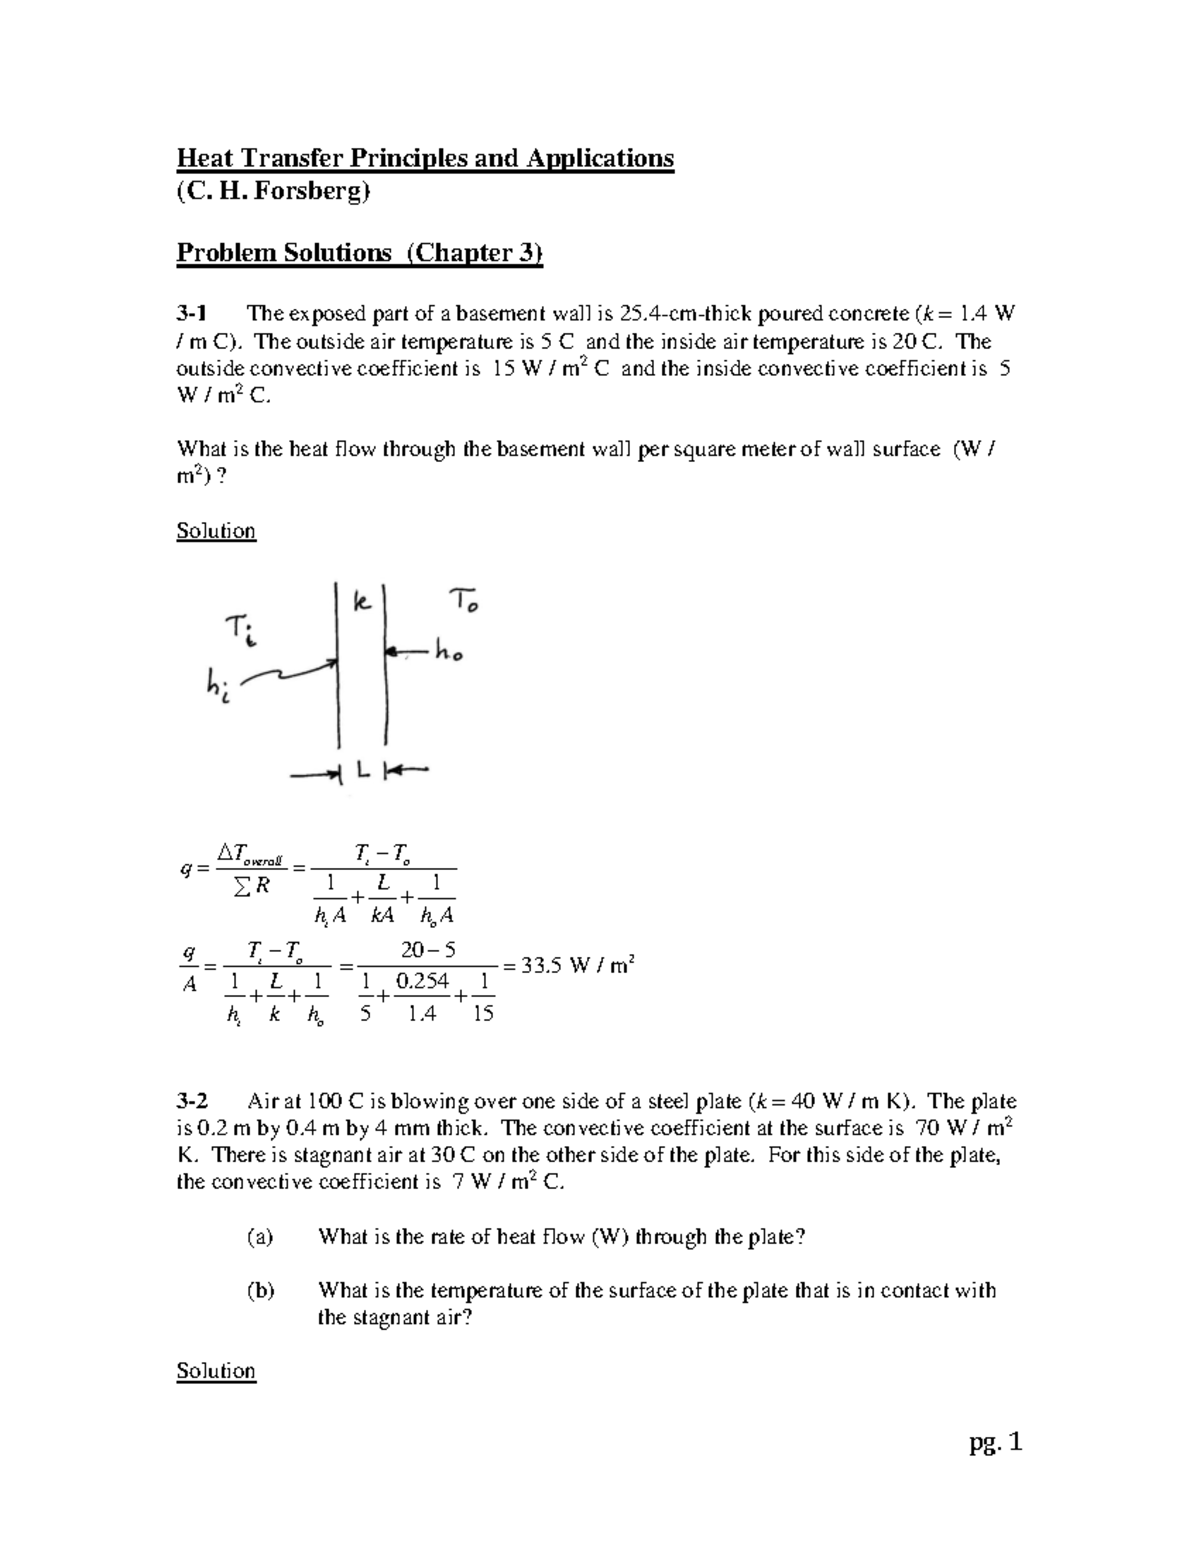
The solution manual also covers heat generation problems, which appear when you have electrical resistance heating, nuclear fuel rods, or chemical reactions in a solid. The governing equation changes from Laplace to Poisson because you now have a source term. The temperature profile becomes parabolic in a plane wall with uniform generation. Maximum temperature occurs at the centerline for symmetric boundary conditions. This is straightforward until the boundary conditions become asymmetric, and then you need to be careful about where the peak actually sits. I found that mixing up the coordinate system origin when the boundaries have different temperatures was a common error. Set x equals zero at the centerline and let the boundaries sit at plus and minus L over 2. It keeps the math cleaner and the physics obvious. If you're looking for the Solution Bergman Introduction To Heat Transfer Chapter 3 material, it's available through the publisher's companion website and various academic resource platforms. Make sure your edition matches. The fourth edition renumbered some problems compared to the third, and working from the wrong solution set will waste more time than it saves. The problems themselves range from straightforward plug-and-chug to moderately challenging multi-resistance networks. Budget about four to six hours to work through the entire chapter properly, including the derivation steps the manual skips. Those skipped steps are where the learning actually happens. A practical note on using the solutions: don't just read them. Copy the problem into a fresh document, attempt it without looking, then compare. If you get stuck, look at the first line of the solution and stop. Close it and try again. The manual is designed to be consulted, not consumed. I've seen students work through maybe twenty problems before an exam and still struggle with novel configurations, while others worked through eight problems deeply, derived every equation, and could handle anything the instructor threw at them. The difference was depth over breadth.
Get the Full Details
The biggest limitation of relying on this solution manual is that it teaches pattern recognition, not physical understanding. The problems repeat the same geometries with different numbers. That's useful for exams but insufficient for real work. If you want to actually understand what's happening, spend time with the derivations. Derive the fin equation from first principles yourself. Draw the differential element, apply energy balance, and watch where the assumptions enter. It takes ten minutes and it changes how you approach every problem after that. Also worth noting: Chapter 3 assumes steady state. If your problem involves transient behavior, you're in Chapter 5 territory. Don't try to force a time-dependent solution into a steady-state framework. I've seen this happen in lab reports where someone measures temperature versus time in a heating experiment and then applies the resistance network method. The numbers come out wrong because the system hasn't reached steady state. Check your time scale. The Fourier number should be greater than about 0.2 before steady-state assumptions are reasonable for most geometries. The fin efficiency and effectiveness charts at the end of the chapter are useful but limited to specific geometries. If your fin profile doesn't match the standard shapes — rectangular, triangular, parabolic — you'll need to work from the general differential equation or use a numerical approach. There's no shortcut there. The manual mentions this briefly but doesn't elaborate. For non-standard profiles, a finite difference approach with maybe twenty nodes gives results within a few percent of analytical solutions for most engineering purposes.
One more thing that catches people off guard: the assumption of constant thermal conductivity. The problems in this chapter mostly treat k as a constant, but real materials change with temperature. If you're working with materials like silicon carbide or certain ceramics, k can vary significantly over the temperature range of interest. In those cases, you need to either iterate with an average temperature or integrate the governing equation with k as a function of T. The manual has a couple of problems that hint at this in the later sections, but it's easy to miss if you're rushing through. Overall, Chapter 3 is foundational. Everything after this — multidimensional conduction, numerical methods, transient analysis — builds on the resistance network concept and the fin equations you learn here. Get comfortable with the thermal circuit analogy. It's the single most useful tool in the entire book, and it carries forward into chapters on radiation and convection where you'll combine different modes of heat transfer in the same problem. The solution manual gets you through the exercises. Understanding why each step works is what makes the chapter stick.

.png "Solution Manual for Fundamentals of Heat and Mass Transfer, 8th Edition By Bergman, Lavine ...")

