What You're Actually Getting Into With the A3230
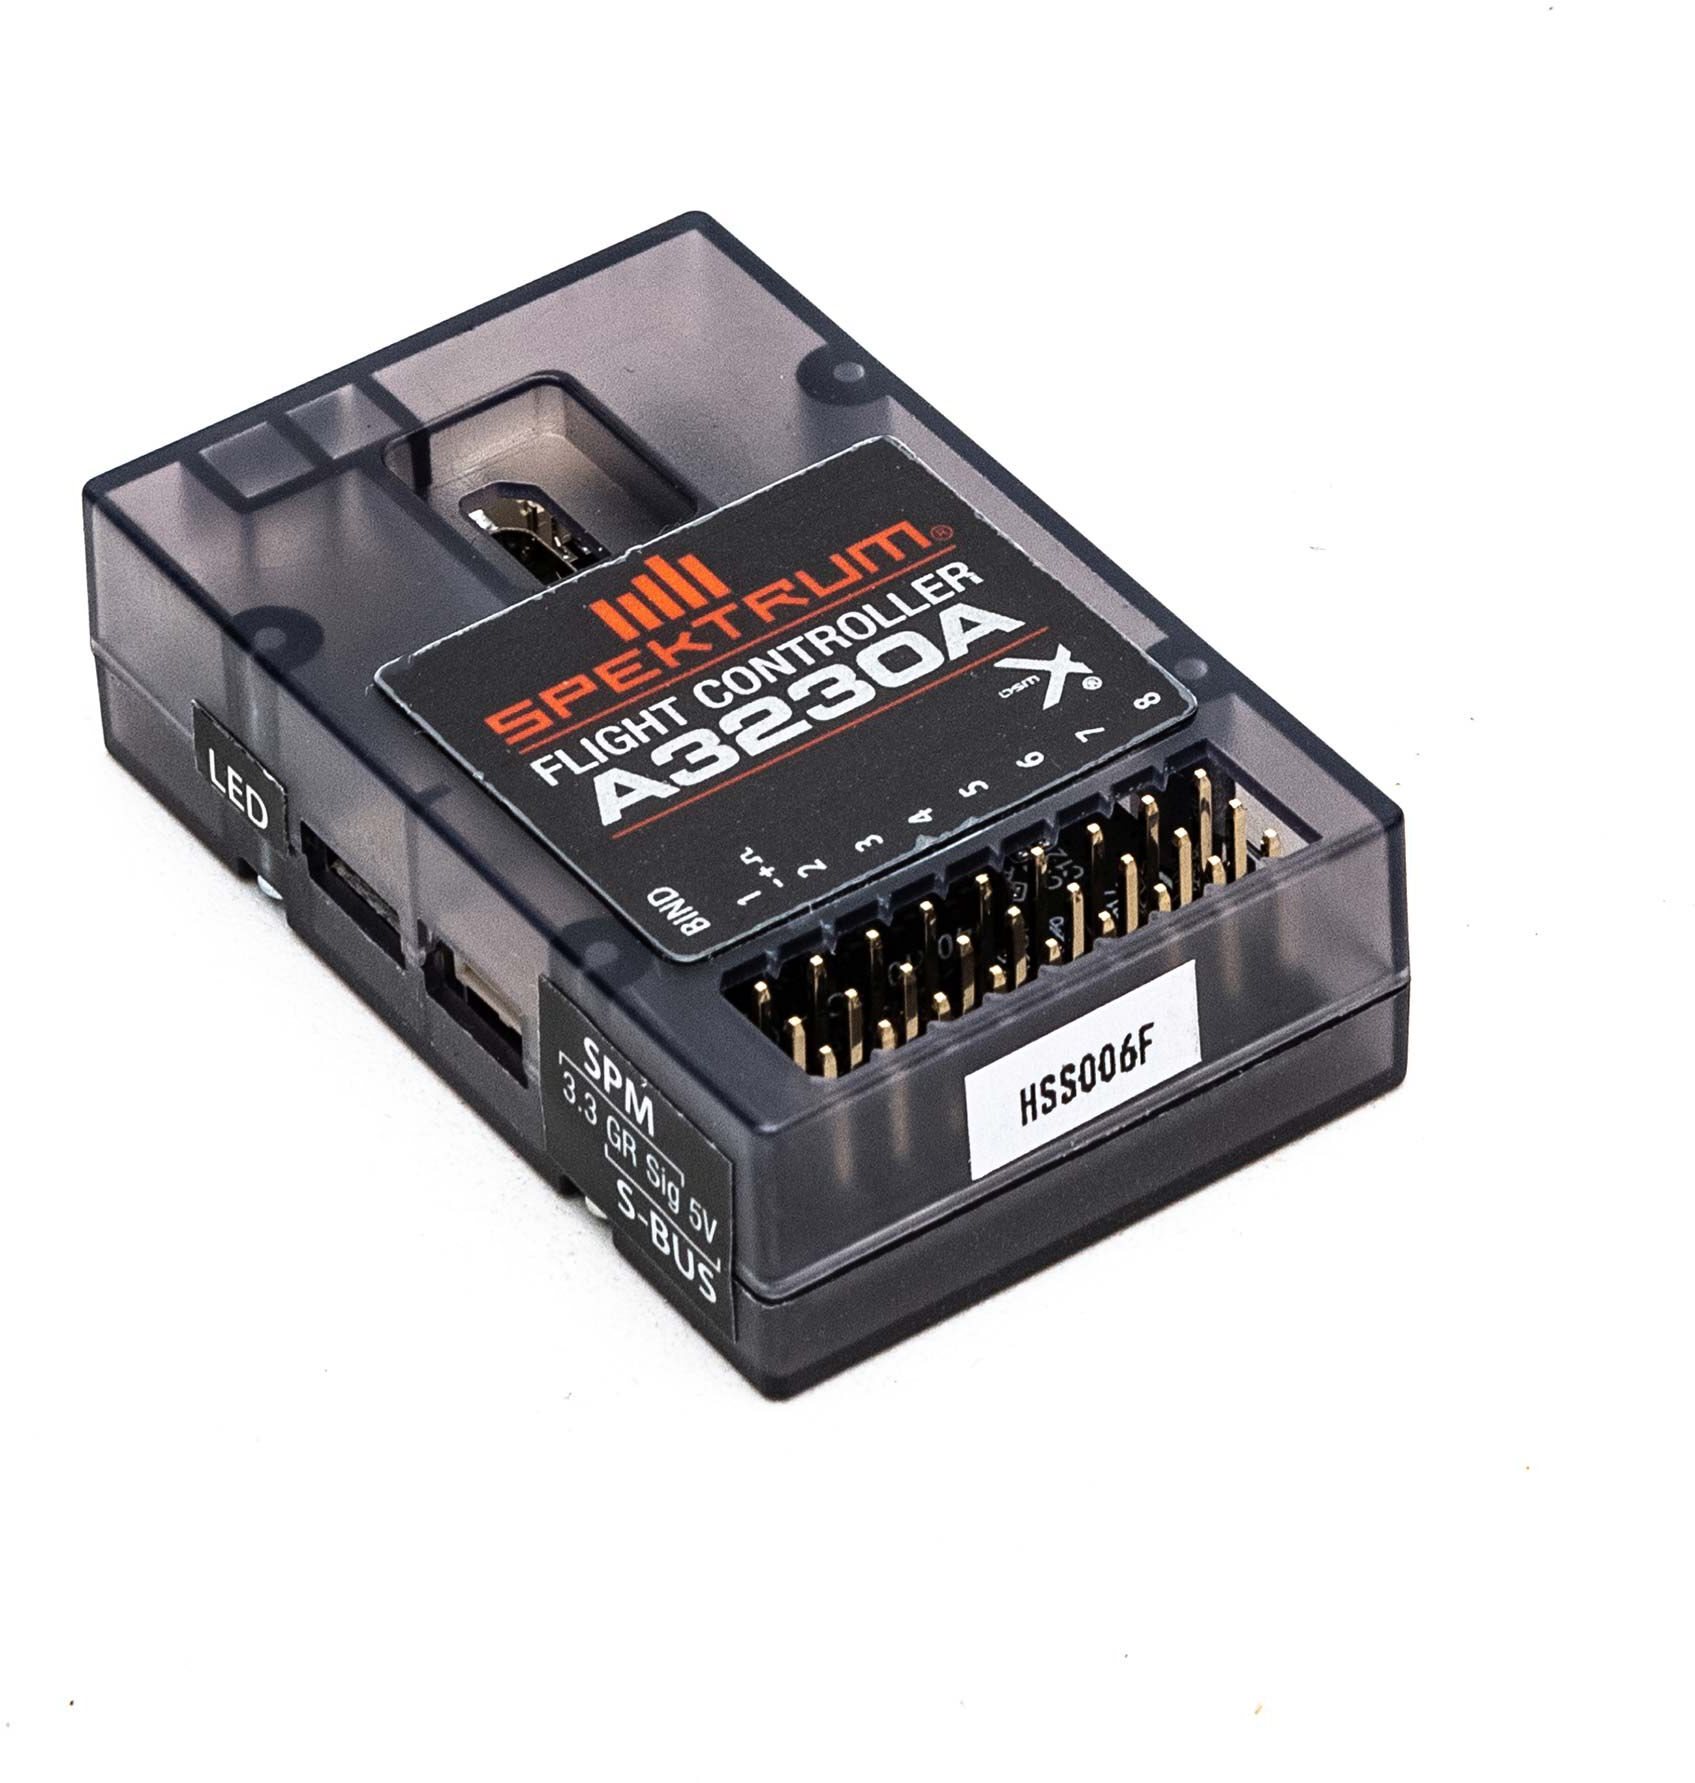
The Spektrum A3230 is a flight controller designed for small multirotor platforms, mainly quadcopters and hexacopters used in camera work and light aerial photography. It runs on Betaflight but ships with its own hardcoded defaults that don't always match what you actually need once the frame leaves the box. The manual covers the basics—binding, LED configuration, basic PID tuning—but it glosses over several things that trip people up repeatedly. I'm going to fill in those gaps based on actual build experience. Most people buy the A3230 assuming they can just flash it and fly. That's not how it works. The first issue you'll hit is the gyro orientation. The board has two mounting holes that are nearly identical, and if you mount it backwards relative to the manual's diagram, your roll axis flips during flight. I learned this the hard way on a build where my copter rolled left on every takeoff attempt, and I spent three hours checking esc outputs before realizing the IMU was rotated 180 degrees from what the manual assumed. The fix was simply flipping the board and re-running the gyro calibration with the copter level.
Spektrum A3230 Flight Controller Manual – What It Actually Covers (And Misses)
The official manual walks through Spektrum satellite binding, LED setup, and basic parameter changes via the Betaflight configurator. It does not address thermal issues, which is a real problem. The A3230's voltage regulator gets warm under sustained load, and in hot weather or during aggressive flips, the regulator can throttle the board's internal logic. I've seen it happen—smooth flights turning into violent oscillations around the eight-minute mark because the board was thermally entering brown-out territory. The workaround isn't in the manual. Add a small heatsink to the voltage regulator chip, and make sure there's at least minimal airflow over the board during operation. This alone resolves most thermal-related instability. Another thing the manual doesn't emphasize enough is the default PID values. They're set conservatively for stability, which means the copter feels sluggish and unresponsive on anything but calm conditions. If you're flying in wind or doing cinematic maneuvers, you'll want to bump the I-term gain slightly and adjust the D-term to match your motor and prop combination. The exact numbers depend entirely on your frame size and motor KV rating, so start with small adjustments—2 to 5 percent at a time—and test after each change. Large jumps will make the copter bark and vibrate aggressively. The RC channel mapping is another area where the manual assumes a certain binding order that doesn't always hold in practice. When I bound a new satellite to a board with mixed Spektrum gear from different years, the throttle channel came up on channel 3 instead of channel 1. Betaflight's port configuration section let me remap it, but you have to know where to look. Open the configurator, go to the Ports tab, and check that your receiver is on the correct UART. Then go to the Configuration tab and set the expected mode under the receiver section. If the channels are still wrong after that, use the Model Selection feature to load a preset that matches your input layout, then manually verify each channel in the RC tab.
One counter-intuitive detail that catches a lot of people off guard: the A3230 supports both Blackbox and OSD logging simultaneously, but enabling both drastically reduces available flash space and can cause logging dropouts mid-flight. I ran into this when I was trying to log a tuning session for a long-duration flight. The Blackbox data showed consistent vibration spikes that weren't visible in the OSD telemetry at all. The lesson is to pick one or the other based on what you're trying to accomplish. If you're tuning, Blackbox. If you need altitude and voltage readouts in the air, OSD. Don't run both unless your board has been upgraded with additional flash memory.
Get the Full Details
Setting Up the Board From Scratch
Before you even connect the board to your computer, make sure your firmware is current. Check the version number in the configurator's top bar, and compare it to what's available on the Spektrum or Betaflight website. Older firmware versions had known bugs with accelerometer drift that could accumulate over several minutes of flight and cause gradual tilt bias. Flashing the latest version typically resolves this, and the process takes about five minutes including the restart time. Once the firmware is up to date, calibrate the accelerometer with the copter completely level and stationary. This sounds obvious, but I've seen people skip it or do it on an uneven surface, which corrupts the entire attitude estimation pipeline. Use a physical spirit level or the leveling feature in the Betaflight configurator. The target roll and pitch values should read zero or within 0.5 degrees. If they don't, adjust the mounting surface until they do, then recalibrate. After calibration, run the motor test sequence to confirm each motor spins in the correct direction. The manual includes a diagram showing the expected rotation pattern for standard quadcopter configurations. If a motor spins opposite to what's shown, swap any two of the three phase wires between that motor and its esc. This reverses the direction without requiring you to reflash or reconfigure anything. I usually do this before installing props, obviously, because spinning the wrong direction with props attached is how you lose fingers or launch a prop into a wall.
Common Pitfalls and What to Do About Them
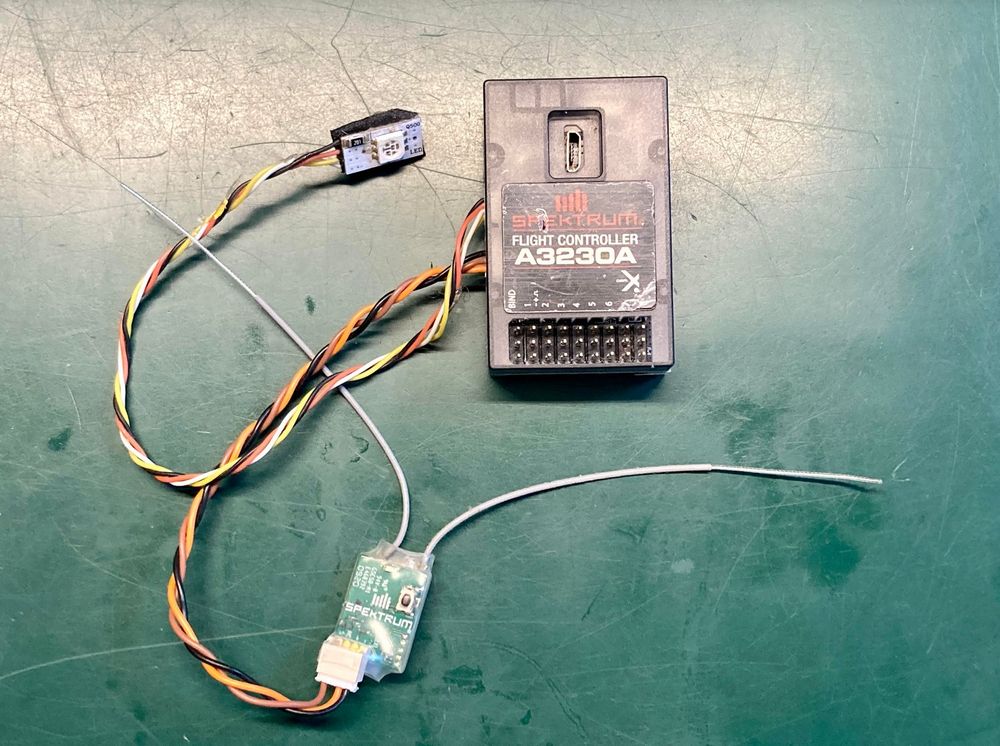
The biggest problem users run into with the A3230 is excessive vibration at high throttle. This usually isn't a flight controller problem—it's a mechanical one. Check your motor mounts, prop adapters, and frame integrity. A loose motor will create harmonic vibration that the D-term can't smooth out no matter how you tune it. Tighten everything, then add vibration isolation mounts between the board and the frame if your platform doesn't already have them. Silicone dampeners cost about three dollars and make a noticeable difference. A second common issue is receiver dropout during flight. The A3230 uses an onboard Spektrum receiver, and if your copter is flying beyond the recommended range or near sources of RF interference, you'll lose signal. This isn't something tuning can fix. The practical workaround is to position the board away from power distribution plates, large capacitor banks, and ESC noise sources. A simple wire antenna extension for the satellite connection can also improve range significantly, though it adds a small amount of weight. The board does not support GPS out of the box. Some forum threads suggest external GPS modules can be wired to the UART pins, but this requires custom cabling and firmware configuration that the manual doesn't cover. If GPS is important to your build, consider a different board that natively supports it, or budget extra time for the integration work. It's doable, but it's not plug-and-play.
Where to Find the Manual
The Spektrum A3230 Flight Controller Manual is available on the official Spectrum model aircraft support pages and on Betaflight documentation portals. The PDF version includes the wiring diagrams, parameter tables, and binding procedures. If you're building from scratch, having the PDF open alongside the configurator makes the whole process much faster than relying on memory or scattered forum posts. The manual is roughly forty pages and takes about twenty minutes to read through carefully, but you'll only need to reference specific sections depending on what stage of setup you're at. My general recommendation is to read the full manual once before starting, then refer back to specific sections as you work through the build. Skipping the manual entirely is how you end up with mismatched channel maps and reversed motor directions, both of which are easily avoidable with ten minutes of reading upfront.