SSR Testing and Mitigation: A Practical Field Guide
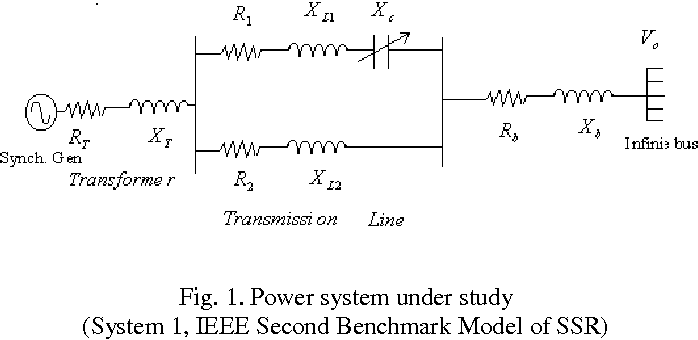
I spent three weeks chasing a false trip signal on a 345kV line that kept looking perfectly normal on the surface. The issue was subsynchronous resonance interacting with the series compensation capacitors, and it was buried so deep in the harmonic spectrum that standard protection settings missed it entirely. That kind of problem doesn't announce itself. You find it when a turbine shaft starts vibrating at frequencies the operators can't explain, or when protective relays pick up currents that look wrong but don't match any standard fault pattern.The process starts with building an accurate impedance model of your network across a range of frequencies, usually from 1Hz to 100Hz below the fundamental 50 or 60Hz. You need the Thevenin equivalent seen from the series compensation point, and you need it with real transformer tap positions, generator subtransient reactances, and the actual line parameters. Most of the mistakes I've seen in SSR studies come from using steady-state impedance data instead of frequency-dependent models. A transmission line's positive sequence impedance at 20Hz is not the same as at 60Hz. You need the full frequency sweep. At the core, SSR happens when a series-compensated transmission line creates an electrical resonant circuit whose natural frequency falls below the system fundamental. That frequency interacts with the turbine-generator shaft, and if it's close enough to a torsional natural mode of the shaft train, energy transfers from the electrical system into mechanical oscillation. The shaft sees a torsional stress that oscillates at the slip frequency, which is the difference between the electrical resonance and the rotor speed. Over time, even relatively small torques can accumulate fatigue damage if they're sustained. That's why it matters. There are two distinct mechanisms here and most people conflate them. One is torsional interaction, where the electrical network's subsynchronous currents produce a torque at a frequency that aligns with a shaft mode. The other is torsional impulse, which is the sudden torque your shaft sees when a fault occurs on a series-compensated line. The fault clears, the capacitor discharges, and the transient current exchange with the generator creates an instantaneous torsional kick. Both mechanisms need to be checked, but they require different analysis tools.
For torsional interaction, you use the Nyquist method or the frequency scan approach. Plot the network impedance magnitude and phase versus frequency, find the series resonant frequency, and then overlay the shaft impedance. If the electrical damping at the shaft modal frequency goes negative, you have a problem. Negative damping means the network is feeding energy into the shaft oscillation rather than absorbing it. For a given level of series compensation, there's a critical clearing time or a critical current level above which the interaction becomes unstable. That threshold is what your study has to establish. I ran into a situation a few years ago with a 500kV line that had 40 percent series compensation and two generators connected at either end. The frequency scan showed the series resonance sitting at about 22Hz, which was dangerously close to the first torsional mode of one of the turbine-generators at roughly 19Hz. The standard protection scheme wouldn't catch this because the subsynchronous currents were being filtered out by the line charging capacitance before they reached the relay. What I ended up doing was installing a dedicated subsynchronous trap filter upstream of the compensation bank, tuned to the problematic frequency range, combined with a tailored SSR relay that monitored the negative sequence current at the slip frequency. It cut the risk down from unstable to manageable in about three months of implementation time.
shaft interaction analysis setup
The shaft model is usually the hardest part to get right. You need a multi-mass model of the turbine-generator train, not a single equivalent mass. The high-pressure, intermediate-pressure, low-pressure, and generator masses each have their own inertia and stiffness, and the natural modes come from the coupling between them. If you collapse this into a two-mass representation, you'll miss modes that are local to individual sections of the shaft. I've seen studies where the actual dangerous mode was a localized bending mode between the LP rotor and the generator rotor, completely invisible in a simplified model. The standard reference for this is IEEE Standard 1110 and the accompanying guide 1142. You should be building your shaft model according to those. The input parameters include the inertia constants for each mass, the torsional stiffness between adjacent masses, and the damping coefficients. These values come from the manufacturer test data, usually torsional tests performed during commissioning where the shaft is excited with known torques and the response is measured. If you don't have the manufacturer data, the published approximations from IEEE or CIGRE give reasonable starting points but they carry significant uncertainty. For the network side, the frequency scan needs to cover the range from about 2Hz up to at least 50Hz below fundamental. You're looking for series and parallel resonances. Series resonance between the line inductance and the compensation capacitor is the usual suspect. But parallel resonance between the compensation bank and the downstream network impedance can also produce problematic currents, especially in meshed networks with multiple generation sources.
Get the Full Details

When you run a time-domain simulation to validate the frequency scan results, use a detailed electromagnetic transient program like EMTP-RV or PSCAD. The electromechanical transient programs like PSAF or BPA won't capture the subsynchronous phenomena accurately because they don't resolve the fast electromagnetic transients. The switching events, the capacitor discharge, and the interaction with the generator flux linkage all happen on a timescale that requires sub-cycle resolution. I typically run simulations with a time step of 50 microseconds or less for the initial fault period, then you can relax it after the transient settles.
mitigation approaches and what actually works
The most common mitigation strategy is adding a filter. There are two types: the tuned trap filter and the damped filter. A tuned trap is an LC branch connected in parallel with the series capacitor, tuned to the subsynchronous frequency. It presents a low impedance path at that frequency and shunts the subsynchronous current away from the generator. A damped filter adds a resistor to broaden the attenuation band. The tradeoff is that a tuned trap is more efficient at a specific frequency but narrowband, while a damped filter is less efficient but covers a wider range. In practice, I usually recommend a hybrid approach where you use a tuned trap for the dominant mode and a damped filter for the secondary frequencies. Another option is the thyristor-controlled series compensation, or TCSC. Instead of a fixed capacitor, you have a variable impedance that can actively damp subsynchronous oscillations. The TCSC changes its effective reactance in response to measured subsynchronous currents, effectively increasing the damping of the network at the problematic frequencies. This is more expensive than a passive filter but gives you active control. It's also harder to model correctly because the controller dynamics interact with the shaft in ways that a simple impedance scan won't capture. You need a time-domain simulation with the full TCSC control model to verify stability. There's also the fast valve closing technique, which involves opening and closing the breaker very quickly after a fault to reduce the duration of the subsynchronous current. This is more of an operational measure than a design fix, but it can be effective in reducing torsional impulse severity. The typical closing time needs to be under one cycle, and it has to be synchronized with the phase angle of the subsynchronous current. Getting the synchronization right is the hard part.
I should mention the limitations here. None of these mitigation strategies work well if the series compensation level is above the critical value for torsional instability. Once you're past that threshold, the interaction becomes self-sustaining and filters alone may not be sufficient. In those cases, you either need to reduce the compensation level, add a bypass reactor to shift the resonant frequency away from the shaft modes, or reconfigure the network topology. I worked on a study where the only viable solution was to split the series compensation bank into two stages with an intermediate substation, which moved the resonant frequency from 22Hz to 31Hz and cleared it from the dangerous shaft modes. That involved a major infrastructure change and significant cost, but it was the only thing that worked.

verification and acceptance criteria
After mitigation, you need to verify that the design meets the acceptance criteria. IEEE Std 1142 provides the framework. The key metric is the damping ratio at each shaft mode under the worst-case network conditions. If the net damping (electrical plus mechanical) is negative at any mode, the system is unstable. If it's positive but below a certain threshold, typically around 2 to 3 percent, the oscillations may decay too slowly and still pose a fatigue risk. The acceptable range depends on the specific shaft design and the operational conditions, so you need to discuss this with the turbine manufacturer. You should also check the thermal limits of the series capacitor bank under subsynchronous conditions. The subsynchronous currents can cause significant heating in the capacitor elements and the metal oxide varistors. The temperature rise can reduce the lifespan of the compensation equipment if it's not accounted for in the design. I've seen capacitor banks fail after a few years of service because the thermal design didn't consider the sustained subsynchronous currents that occur during certain network operating conditions. Finally, don't skip the protection coordination check. The subsynchronous frequencies can interfere with distance relay elements and overcurrent protection. Some relays misoperate or fail to operate during SSR conditions because their frequency response isn't flat across the subsynchronous range. You need to verify that every protection element in the zone sees the expected behavior during both torsional interaction and torsional impulse events. This is often where the last-minute surprises happen, and they're expensive to fix after commissioning starts.