
What Actually Goes Into Building a Physics System Model
Most people walking into this topic think they know what a system is in physics. It sounds simple on paper. You draw a boundary around something, label it an open system or closed system, and you are done. That is not how it works when you actually have to get numbers out of it. I spent years working with computational physics models, mostly in fluid dynamics and thermodynamics, and the gap between the textbook definition and the real thing is where everything falls apart. You pick a control volume, apply the conservation laws, and then discover that your boundary conditions are wrong, your mesh is too coarse near the walls, or your time step is blowing up because you did not account for stiff source terms. Here is the actual process I use now, and the one I wish I had followed from the start.
Defining the System in Physics Context
A system in physics is simply the region of space or collection of matter you choose to analyze. Everything outside it is the surroundings. The boundary between the two determines whether mass and energy can cross. That is the basic classification: open, closed, or isolated. The classification itself is not where the difficulty lives. The difficulty is in deciding what you actually include inside that boundary and what you deliberately leave out. I have seen engineers model an entire engine block as a closed system for thermal analysis and then wonder why their temperature predictions were off by dozens of degrees. The problem was not the math. It was the boundary choice. They left out the coolant channels because they thought those were secondary. Those channels were the primary heat removal mechanism.
Setting Up the Model Correctly
Start by writing down what quantities you care about. Energy? Momentum? Species concentration? Particle number? Whatever you pick becomes your conserved quantity, and you build the balance equation around it. The general form is straightforward: Rate of change inside the system = Net flow across the boundary + Generation or consumption inside
Get the Full Details

That equation applies to mass, energy, momentum, charge, probability amplitudes, whatever your domain requires. The form stays the same. The content changes completely. When I was first learning this, I made the mistake of treating every problem as if it were steady state until proven otherwise. That cost me three weeks on a heat transfer project where the transient response was actually the whole point. The system was cooling down, not sitting at equilibrium, and my boundary conditions assumed a constant surface temperature that never existed. I had to redo the entire mesh refinement and switch to an implicit time integrator because the explicit method was requiring time steps measured in microseconds to stay stable.
Practical Approach to Boundary Conditions
Boundary conditions are where most models die. Not because they are hard to specify, but because people specify the wrong ones and do not realize it until the simulation diverges or the results look suspiciously clean. I once ran a CFD case for a turbulent jet that produced perfectly smooth velocity profiles. That should have been the red flag. Turbulent jets do not look like laminar profiles. I had accidentally set a symmetry boundary where a far-field condition belonged. The solver was not broken. The physics was just constrained into an artificial cage. For a typical physics system problem, you will usually need at least one Dirichlet condition, which pins a variable to a known value, and one Neumann condition, which specifies a gradient or flux. Mixing them incorrectly across adjacent boundaries is a common failure mode. Check your condition types at every edge of your control volume before you run anything.
Numerical Implementation Steps
Once the analytical setup is solid, the numerical part follows a predictable path, even though the execution is rarely smooth. Step one: Discretize the domain. Whether you use finite difference, finite volume, or finite element depends on your geometry and the equations involved. Finite volume is the default for conservation laws because it preserves balance at the discrete level. That property matters more than people admit. Step two: Choose your time integration scheme. If your system has widely separated time scales, you will need a semi-implicit or fully implicit method. Explicit schemes are easier to code but become impractical fast when your smallest physical time scale drops below a millisecond and your largest is measured in seconds. The ratio between those two is called the stiffness, and stiffness is what breaks naive implementations.
Step three: Set up your solver. Linear systems from discretized PDEs often come out sparse and banded. Use a sparse direct solver for moderate problems, or an iterative method like GMRES with an appropriate preconditioner for larger ones. I have seen people run conjugate gradient on badly conditioned matrices and waste hours wondering why convergence stalled at residual 10 to the negative 4. The matrix was not the issue. The preconditioner was. A simple incomplete LU factorization fixed it in two iterations. Step four: Validate against an analytical solution or a benchmark case before trusting any new geometry or parameter regime. I cannot overstate how many times I have watched people skip this and spend weeks debugging a result that was wrong from iteration one. The benchmark does not need to match your final problem exactly. It just needs to be a case where you know the answer. Taylor series expansions, similarity solutions, and published test cases from heat transfer and fluid mechanics handbooks all work for this purpose.
Debugging When the System Refuses to Converge
Solver divergence is not always a solver problem. More often it is a physics problem masquerading as a numerical one. The system you are modeling has a feature your discretization cannot resolve, and the residuals climb until the code gives up. I ran into this with a phase change problem where the latent heat release created a sharp moving front. The mesh was fine everywhere except at the front, which kept marching through cells that were too large to capture the gradient. I switched to an adaptive mesh refinement strategy that added elements only where the temperature gradient exceeded a threshold. Convergence happened on the first try after that change. The original setup would have needed roughly forty eight hours of wall clock time per run to even approach a stable solution, and even then it would have been inaccurate.
Common Pitfalls That Nobody Warns You About
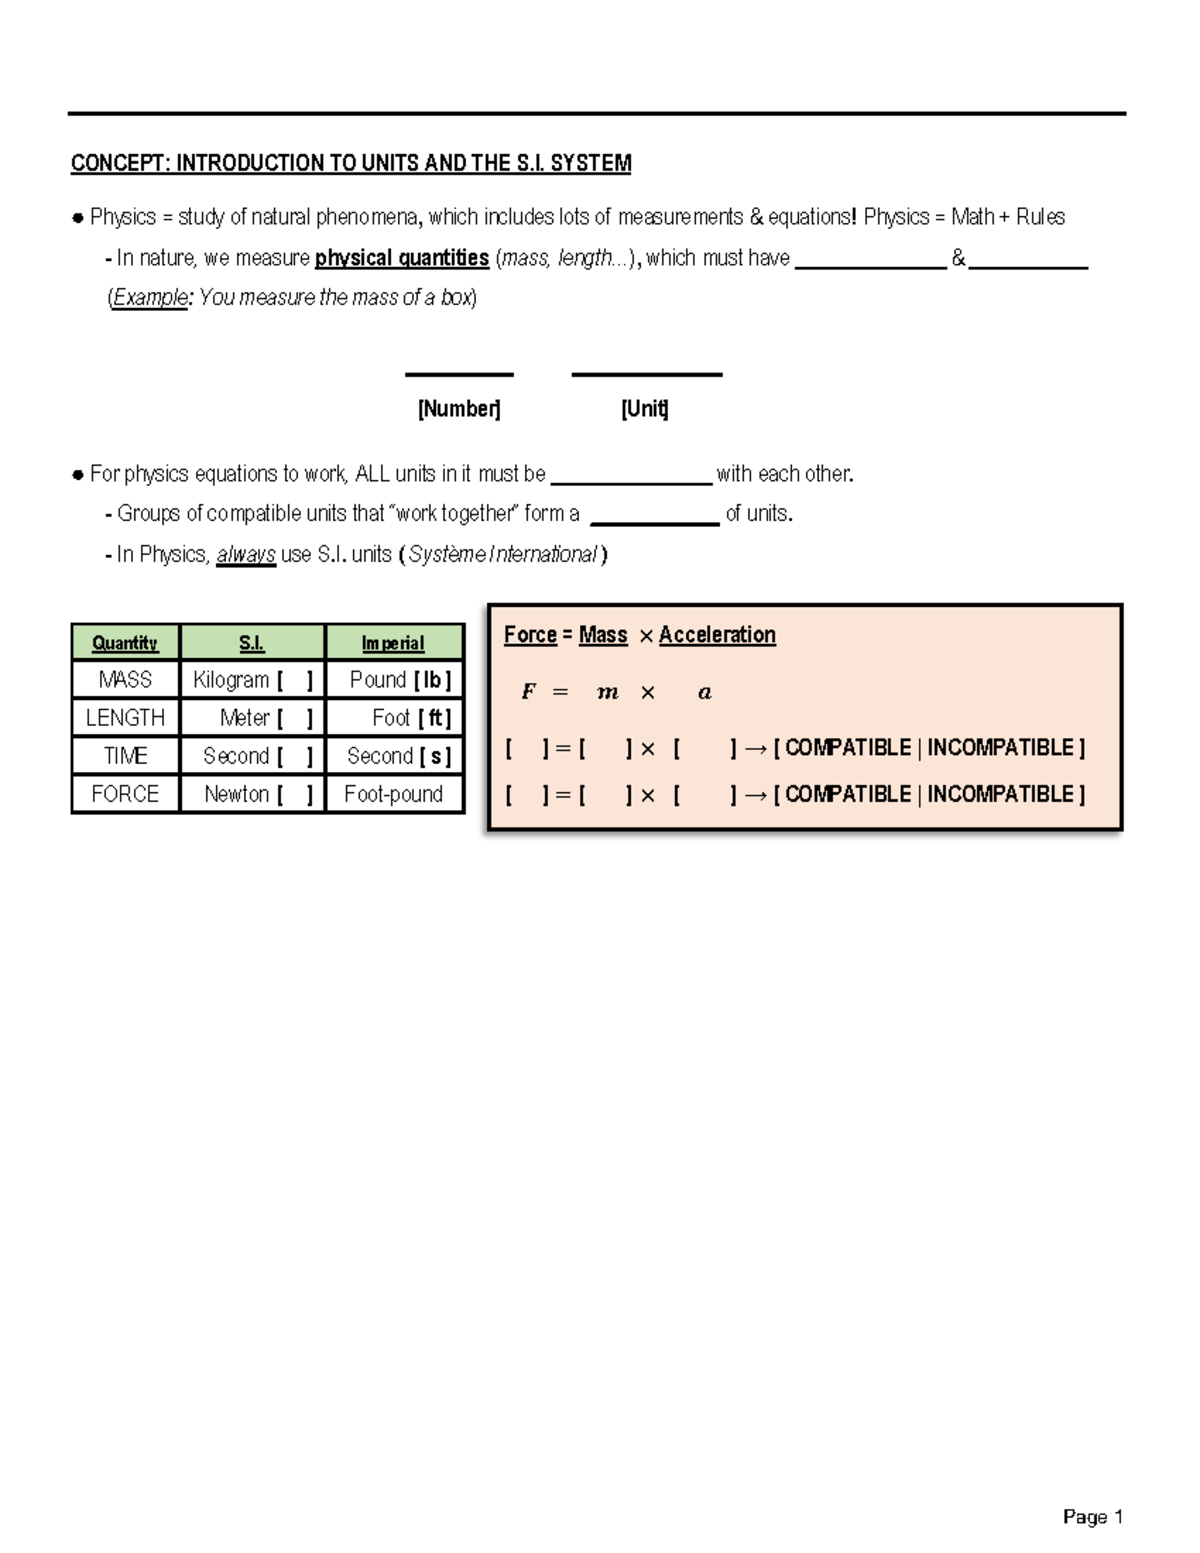
Unit consistency is the obvious one, but the subtle version is worse. You can have every equation right and still produce garbage because your material properties came from a table in imperial units while your geometry was in SI. The numbers look plausible. They are completely wrong. Another trap is assuming that adding more physics always improves accuracy. It does not. It improves fidelity only if your numerical method can actually resolve the additional physics. Add radiation to a convection-dominated problem without a proper radiative transfer solver and you will just get noise dressed up as sophistication. I have seen models with seven different physical mechanisms coupled together that performed worse than a single well-calibrated conservation equation. Simpler is often more accurate because there is less room for parameter uncertainty to accumulate. Parameter sensitivity is also understated. Run a grid independence study and a time step independence study. Then run a parameter sweep on your uncertain inputs. If your result changes by fifty percent when a single coefficient varies by ten percent, your model is not reliable regardless of how elegant the implementation is. I use a straightforward fractional factorial design for this. It catches the worst offenders without requiring a full Monte Carlo campaign, which for a complex 3D system can mean the difference between a afternoon of computation and a week of it.
When a System In Physics Approach Breaks Down
Classical continuum-based system modeling fails when the characteristic length scale approaches the mean free path of the relevant particles. In gas dynamics that is the Knudsen number. Above roughly zero.1 you enter the slip flow regime and your no-slip boundary condition is wrong. Above one you are in the transition regime where continuum assumptions break down almost entirely. Molecular dynamics or Boltzmann solvers become necessary, and those come with their own computational cost that scales poorly with system size. Quantum systems present a different failure mode. Your classical Hamiltonian will not capture tunneling, entanglement, or discrete energy levels. You need a quantum mechanical framework instead. There is no middle ground here. The system either behaves classically or it does not, and guessing which one based on the size of the apparatus is a reliable way to get the wrong answer. For chaotic deterministic systems, predictability degrades exponentially with time regardless of how precisely you set up the model. Lyapunov exponents quantify this. If your system has a positive Lyapunov exponent, long-term predictions are impossible even with a perfect model. The best you can do is characterize the attractor structure and work with ensemble averages rather than individual trajectories. I learned this the hard way on a double pendulum simulation where I spent two weeks trying to improve temporal accuracy before realizing the divergence was intrinsic to the dynamics, not a numerical artifact.
Tools and Resources
For general purpose system modeling in physics, open source options like CalculiX for structural mechanics, OpenFOAM for fluid dynamics, and Elmer FEM for multiphysics problems cover most undergraduate and graduate level work. Commercial packages like COMSOL Multiphysics and ANSYS Mechanical are faster to set up but require licenses that not everyone can access. If you are doing something custom, Python with NumPy and SciPy is sufficient for one-dimensional and modest two-dimensional problems. I wrote a small finite volume solver for transient heat conduction in a rectangular domain using nothing but those libraries, and it ran in under twenty minutes on a laptop. The same problem in COMSOL took about five minutes to set up but required a licensed installation and a larger machine to exploit its parallel solver efficiently. Textbooks that actually focus on the setup rather than just the derivation include Numerical Heat Transfer and Fluid Flow by Patankar for the finite volume perspective, and The Finite Element Method: Linear Static and Dynamic Finite Element Analysis by Reddy for the structural side. Both are dense but they cover the practical decisions that papers and lecture notes usually skip.
Workflow Recommendation
Build the simplest version of your system first. One dimension. Linear material properties. No source terms. Get the numbers to match the analytical solution. Then add complexity one piece at a time, validating at each step. This prevents the situation where you add ten new features, the result goes wrong, and you have no idea which feature caused it. The incremental approach takes longer upfront but saves days of debugging later. In practice I have found that the first version usually takes about an hour to code and validate, and each subsequent complexity addition adds anywhere from thirty minutes to two hours depending on how entangled the new physics is with the existing formulation. Document your boundary conditions, your initial conditions, your mesh parameters, and your solver settings in a single place. I keep a plain text log file alongside every project. When a result looks wrong six months later, that log file is the only thing that tells you whether you changed something you forgot about or whether the problem is genuine. Version control helps too, but a simple log is faster to scan than git blame output when you are tired and need an answer quickly.


