Working Through Systems of Linear Equations
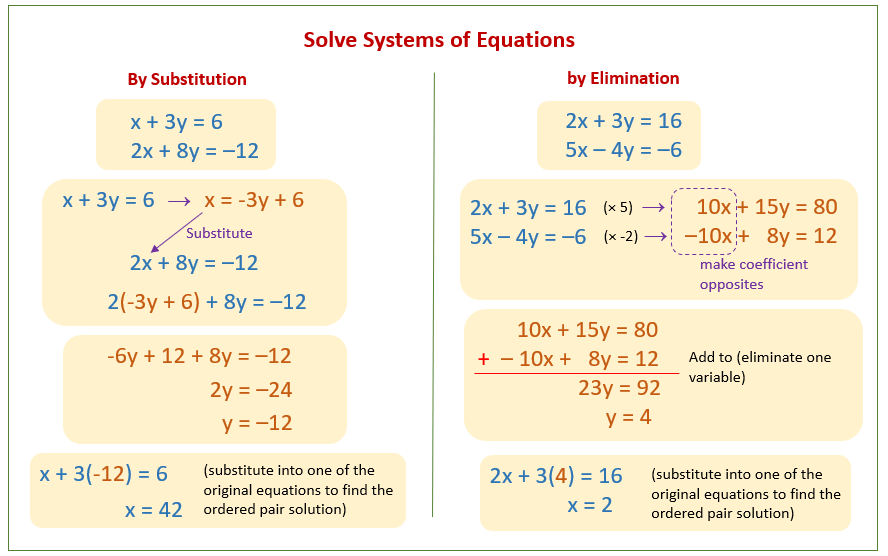
I keep seeing students try to memorize every type of system they might encounter before they've actually solved a dozen. It doesn't work that way. The three main approaches — substitution, elimination, and matrix reduction — cover almost everything you'll see in a standard course. Pick one and get comfortable with it first. Substitution is usually the fastest way to start. Solve one equation for a single variable, then plug that expression into the other equation. You end up with one equation in one unknown. From there it's just algebra until you hit the answer. Let me walk through a concrete example. Consider these two equations: 2x + 3y = 12 and x - y = 1. I'll solve the second equation for x, which gives me x = y + 1. Then I substitute that into the first equation: 2(y + 1) + 3y = 12. Distributing and combining terms gets me 5y + 2 = 12, so y = 2. Going back to x = y + 1, I get x = 3. The solution is the point (3, 2).
To check whether that's actually correct, I plug both values into the original equations. 2(3) + 3(2) = 6 + 6 = 12, which matches the first equation. And 3 - 2 = 1, which matches the second. Checking takes about ten seconds and prevents you from carrying forward an arithmetic mistake that you won't catch until the end of a long problem set.
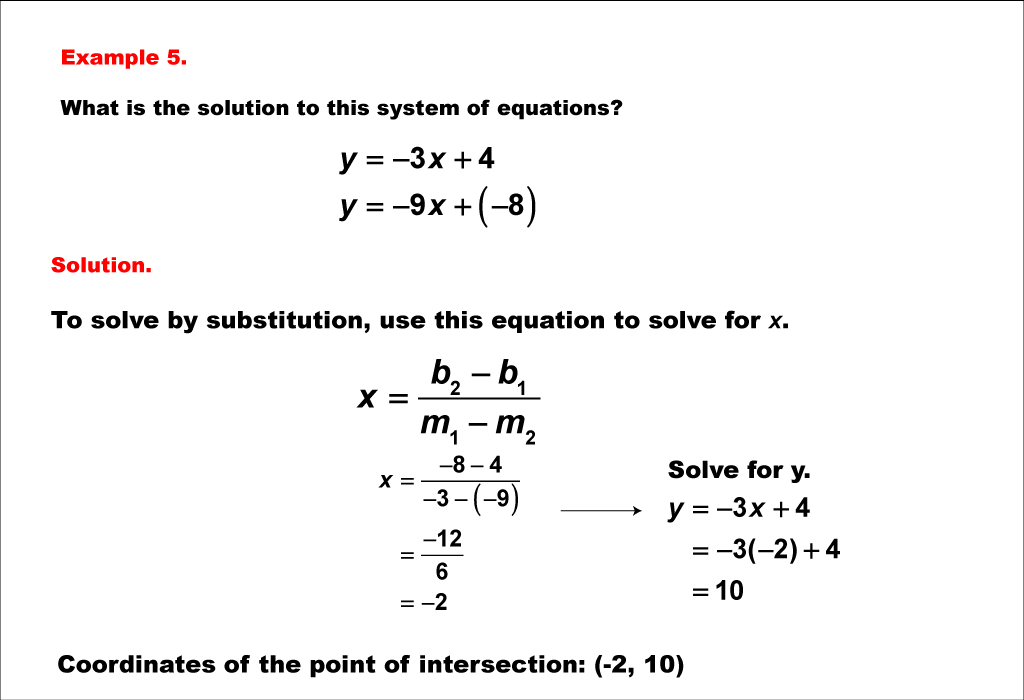
Common System Of Equations Examples You Should Know
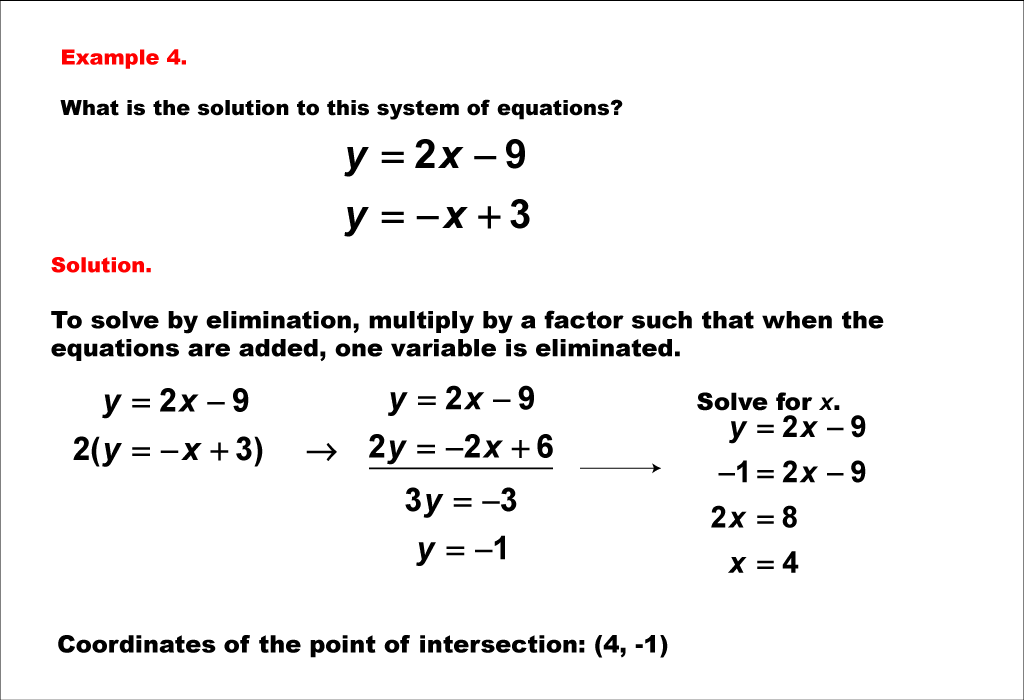
The elimination method works well when the coefficients line up nicely. Take the same pair of equations and multiply the second one by 3 to get 3x - 3y = 3. Now add it to the first equation 2x + 3y = 12. The y terms cancel immediately, leaving 5x = 15, so x = 3. Substituting back gives y = 2 again. You reach the same result through a different path, which is useful because sometimes one path is significantly faster than the other depending on the numbers. Here's another example that comes up frequently. You have 3x + 4y = 24 and 5x - 2y = 10. Eliminating y here means multiplying the second equation by 2, giving you 10x - 4y = 20. Adding that to the first eliminates y directly: 13x = 44, so x = 44/13. Then substituting back into the first equation gives y = 9/13. The fractions are a little messy but the process is identical. When you're dealing with three equations and three variables, the same logic applies but you work through it in stages. Solve one equation for a variable, substitute into the other two to create a 2x2 system, then solve that smaller system using whichever method feels natural.
Get the Full Details
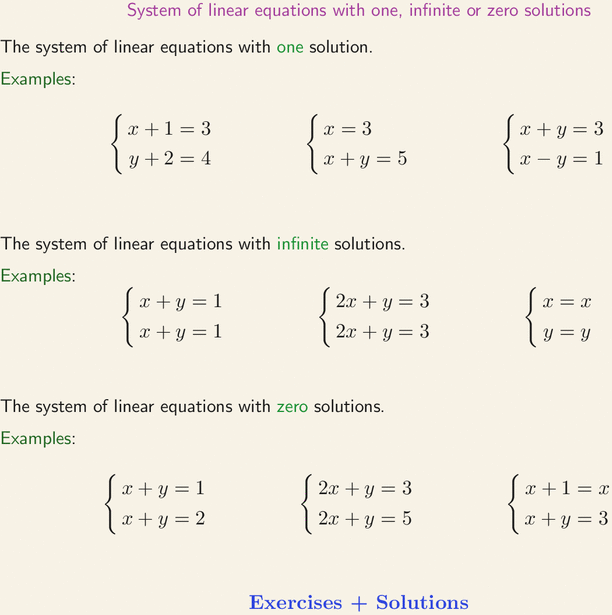
I once spent about forty-five minutes stuck on a homework problem where the system appeared to have no solution because all my elimination steps were reducing to statements like 0 = 5. I kept second-guessing my arithmetic. What I eventually realized was that the third equation was actually a linear combination of the first two with an inconsistent constant term, making the system genuinely inconsistent. The workaround was to write each equation in row-reduced echelon form using an augmented matrix and look for a row of zeros on the left side paired with a nonzero value on the right. That tells you immediately whether the system is inconsistent, has a unique solution, or has infinitely many solutions. Doing it by hand this way takes roughly five to eight minutes for a 3x3 system, whereas guessing your way through elimination can waste twenty minutes or more if you go down the wrong branch.
When Standard Methods Break Down
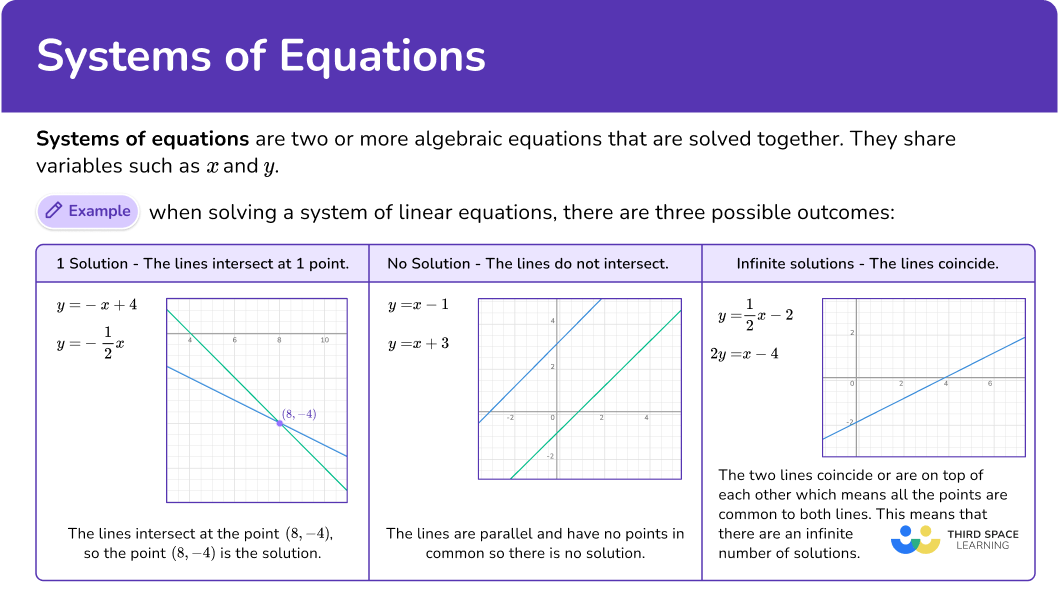
Not every system plays nice. A couple of situations come up often enough that you should recognize them early. Dependent systems produce infinitely many solutions. This happens when one equation is just a multiple of another. If you reduce them properly, you end up with a row like 0 = 0, which gives you no information. The variables are free to take on any value along a line or plane. You express the solution set using a parameter instead of a single point. Nonlinear systems are a different category entirely. A system with one linear and one quadratic equation, for instance, can have zero, one, or two solutions depending on whether the line misses the parabola, touches it, or cuts through it. Substitution still works here, but you end up solving a quadratic equation instead of a linear one. Check your discriminant before doing extra work.
Matrix methods using determinants, specifically Cramer's Rule, are theoretically elegant but practically slow for anything beyond 2x2 or 3x3 systems. Computing determinants by hand for a 4x4 matrix takes several minutes and is prone to sign errors. Gaussian elimination or Gauss-Jordan reduction is generally faster and less error-prone for larger systems. If you have access to computational tools, software like WolframAlpha or a graphing calculator can verify your work in seconds, but relying on that during an exam won't help you develop the underlying skill. Real-world systems sometimes involve floating-point rounding errors that make an exact symbolic solution misleading. In engineering contexts, a system that appears singular might be ill-conditioned instead, meaning small changes in the input data produce large changes in the output. I've seen this in basic circuit analysis problems where resistor values are given to two significant figures and the resulting currents come out to something like 0.333333... when the precision of the input data doesn't actually justify that many decimal places. Truncating to a reasonable number of significant figures early in the calculation prevents false precision from creeping into your final answer. The most useful thing you can do is practice with varied numbers, not just the clean integers that textbooks prefer. When the coefficients are fractions or decimals, the method doesn't change, but the arithmetic gets harder and that's where mistakes happen. Working through at least ten problems in each method — substitution, elimination, and matrix reduction — should give you enough exposure to handle whatever shows up on a test or in practical work.