How To Actually Solve Systems Of Linear Equations Without Losing Your Mind
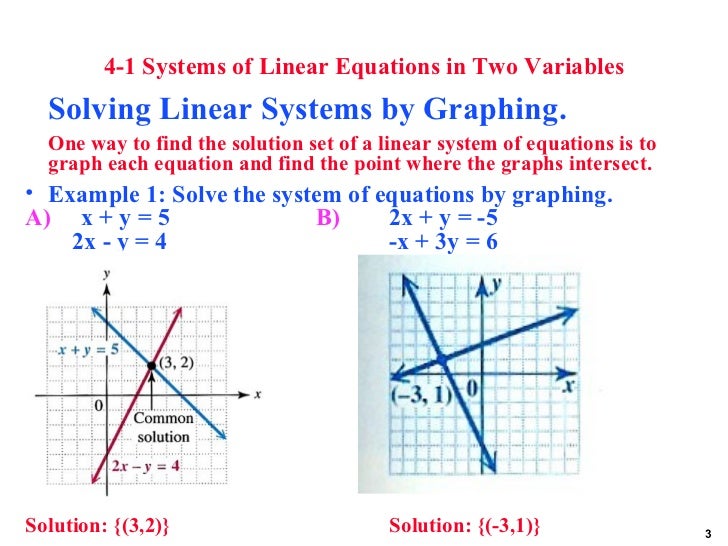
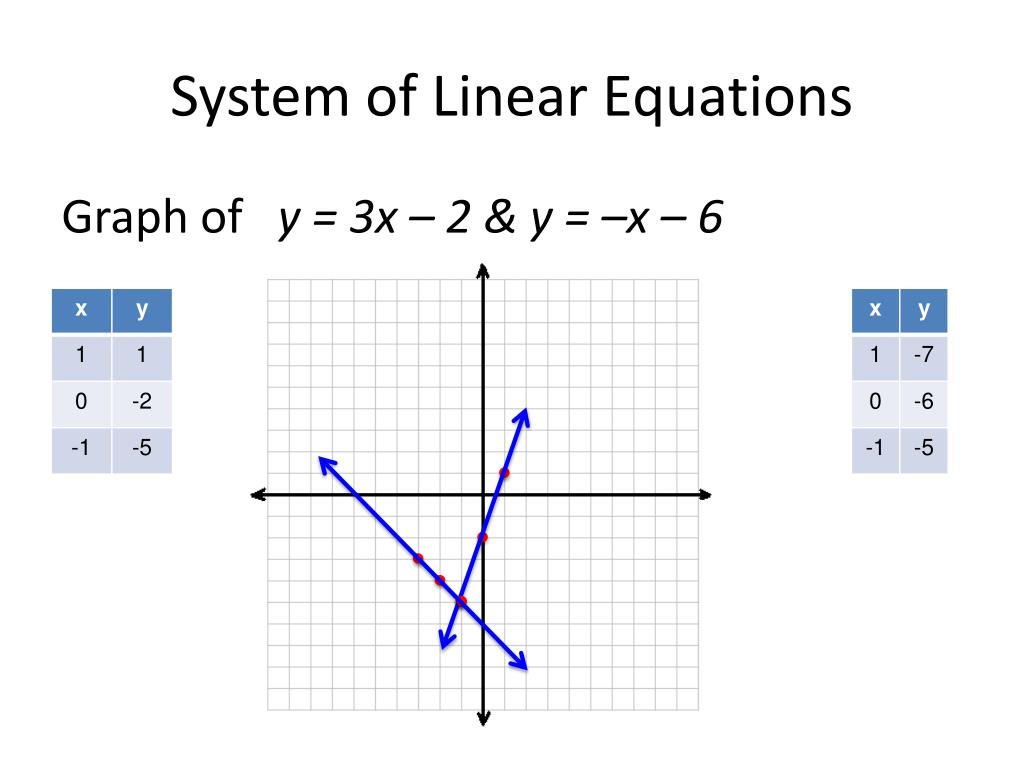
Most people learn three methods for systems of linear equations: substitution, elimination, and graphing. They cover about 80 percent of what you'll encounter in introductory courses, but the other 20 percent is where people waste hours. I want to walk you through what actually works in practice, starting with the method most people get wrong.
Row Reduction Before Anything Else
Gaussian elimination, sometimes called row reduction, is the backbone. You write your system as an augmented matrix, then perform three types of row operations: swap two rows, multiply a row by a nonzero scalar, or add a multiple of one row to another. The goal is to reach row echelon form, where each leading entry is to the right of the one above it, and everything below it is zero. From there, back substitution gives you your answers. Here's the thing about Gaussian elimination that nobody warns you about: roundoff error. When you're doing this by hand with nice integers, it's clean. When you do it on a computer with real-world data, floating point arithmetic can introduce errors that compound across rows. For a 3x3 or 4x4 system, this is rarely noticeable. For anything above 10 variables, partial pivoting becomes essential — swap rows so the largest available entry sits on the diagonal before you eliminate below it. This simple step cuts numerical instability dramatically. I worked on a project a few years ago involving a structural engineering model with roughly 45 simultaneous equations describing load distribution across a bridge truss. The textbook approach would suggest Gaussian elimination, and on paper it works fine. In practice, the matrix had some entries that differed by orders of magnitude, and standard elimination produced wildly inaccurate results — solutions that violated equilibrium conditions. The workaround was switching to LU decomposition with partial pivoting, which factors the matrix into a lower triangular matrix and an upper triangular matrix, then solves each part sequentially. This approach handled the scale differences much more gracefully and gave us results within acceptable tolerance in about 15 minutes instead of failing outright.
Substitution And Elimination — When They Make Sense
Substitution means solving one equation for one variable, then plugging that expression into the remaining equations. It's useful when a system already has a variable isolated or when one equation is simple enough to rearrange quickly. Elimination, the traditional algebra version, means adding or subtracting equations to cancel out a variable. Both are perfectly valid for small systems, but they break down as systems grow. A 10-variable system solved by hand using elimination would take most people several hours and still likely contain arithmetic errors. The key insight most students miss is that substitution and elimination are actually doing the same mathematical work as row reduction — they're just doing it one informal step at a time. Recognizing this connection helps because it means once you understand Gaussian elimination, you already understand why those other methods work. You also understand their limits.
Matrix Methods And Determinants
Cramer's rule uses determinants to solve systems. For a 2x2 system, it's elegant and fast. For a 3x3, it's manageable but tedious. For anything larger, it's computationally expensive and numerically unstable. The determinant of an n x n matrix requires computing n! terms, which means 10 variables already demands 3.6 million calculations. Nobody uses Cramer's rule for systems beyond 3x3 in any professional setting. Inverse matrices offer another approach. If your system is Ax = b, then x = A^(-1)b. The catch is that computing the inverse of a matrix is more work than simply solving the system directly, and it introduces additional numerical error. Professional software rarely solves systems by explicitly computing inverses. They use factorization methods instead — LU, QR, or Cholesky decomposition depending on the matrix properties. If your matrix is symmetric positive definite, Cholesky decomposition is the way to go. It factorizes A into LL^T where L is lower triangular, and it runs about twice as fast as general LU decomposition while using roughly half the memory. This matters when you're solving the same system repeatedly with different right-hand sides, which happens constantly in finite element analysis and optimization problems.
Get the Full Details

When Systems Of Linear Equations Break Down
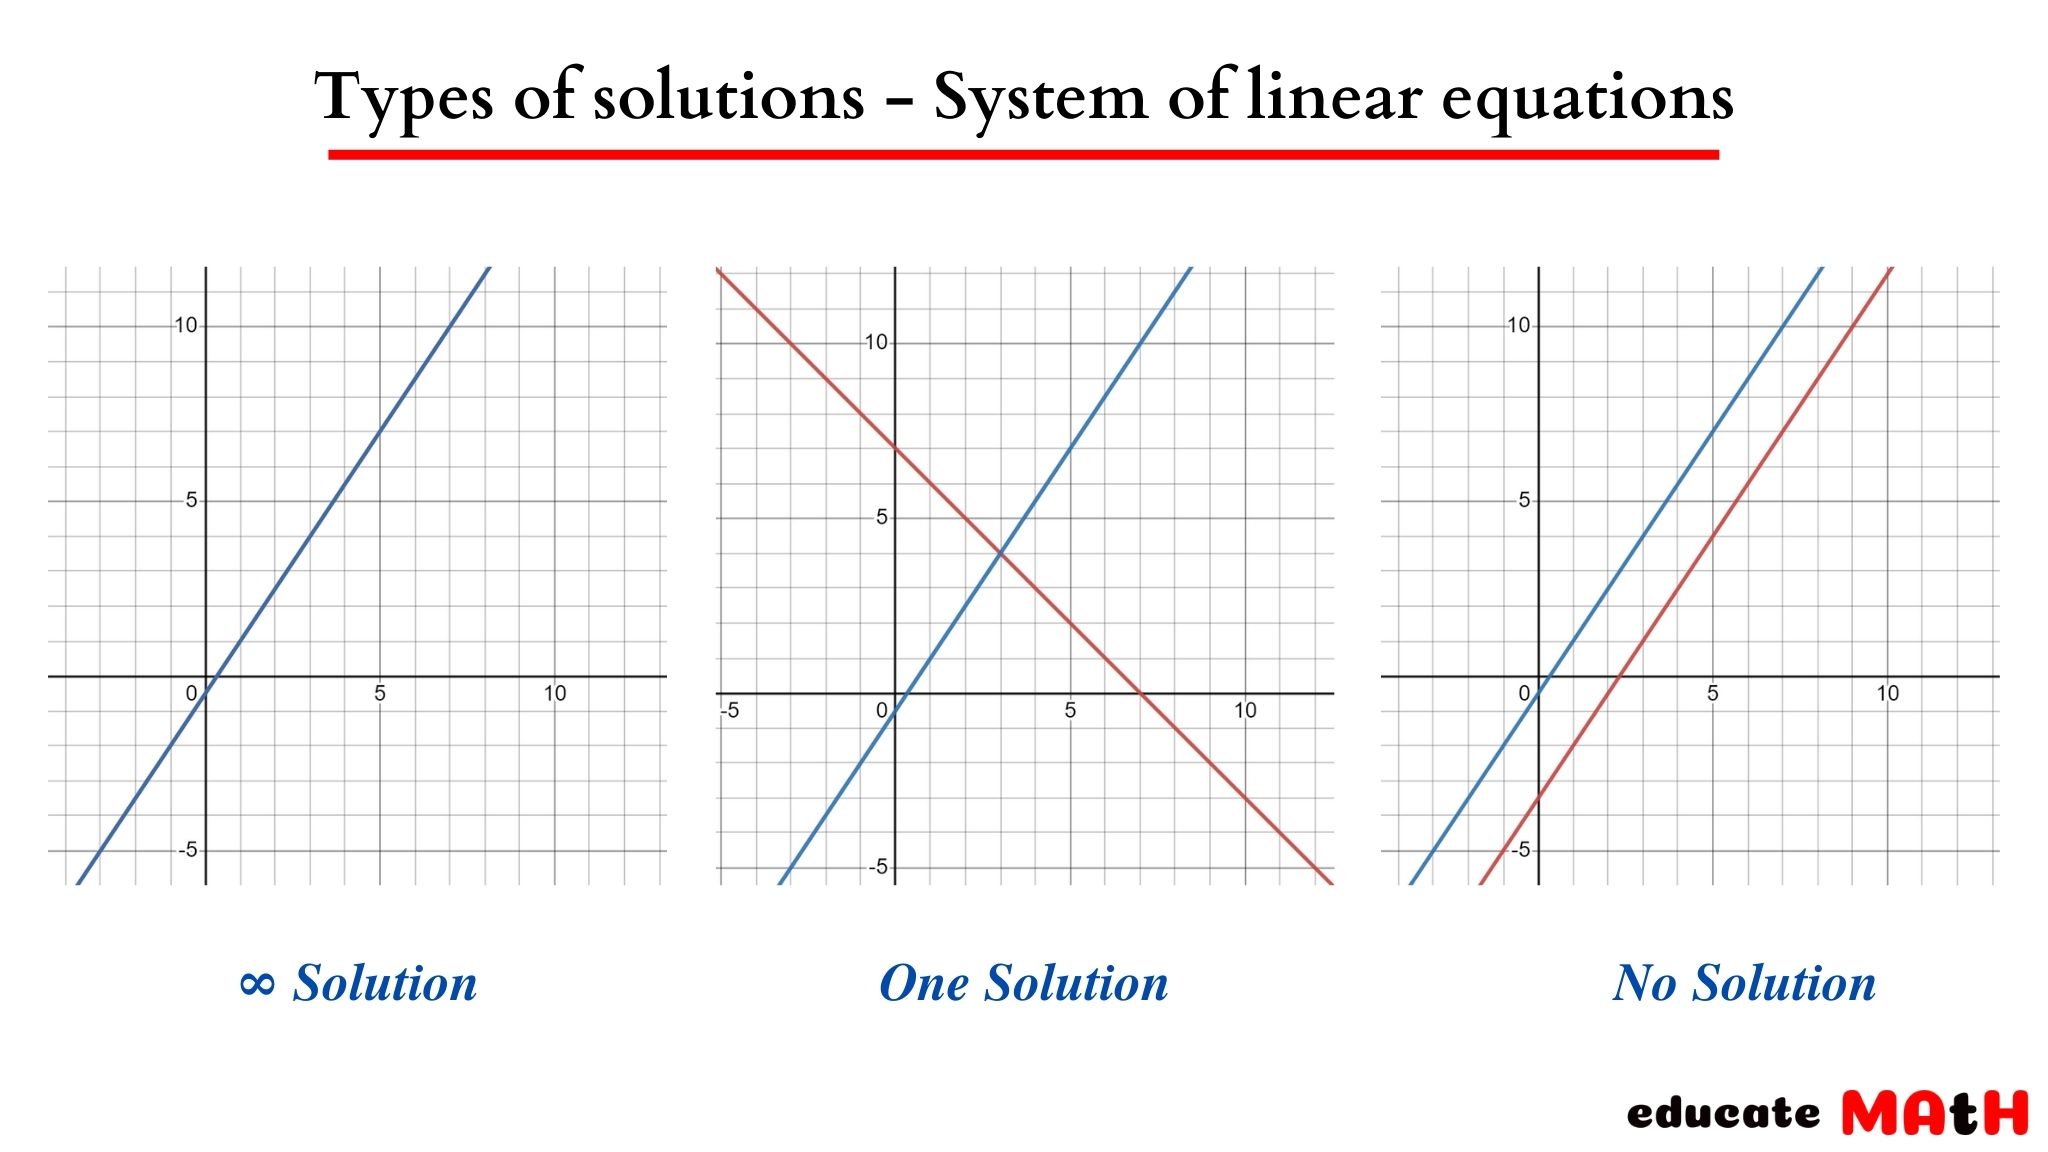
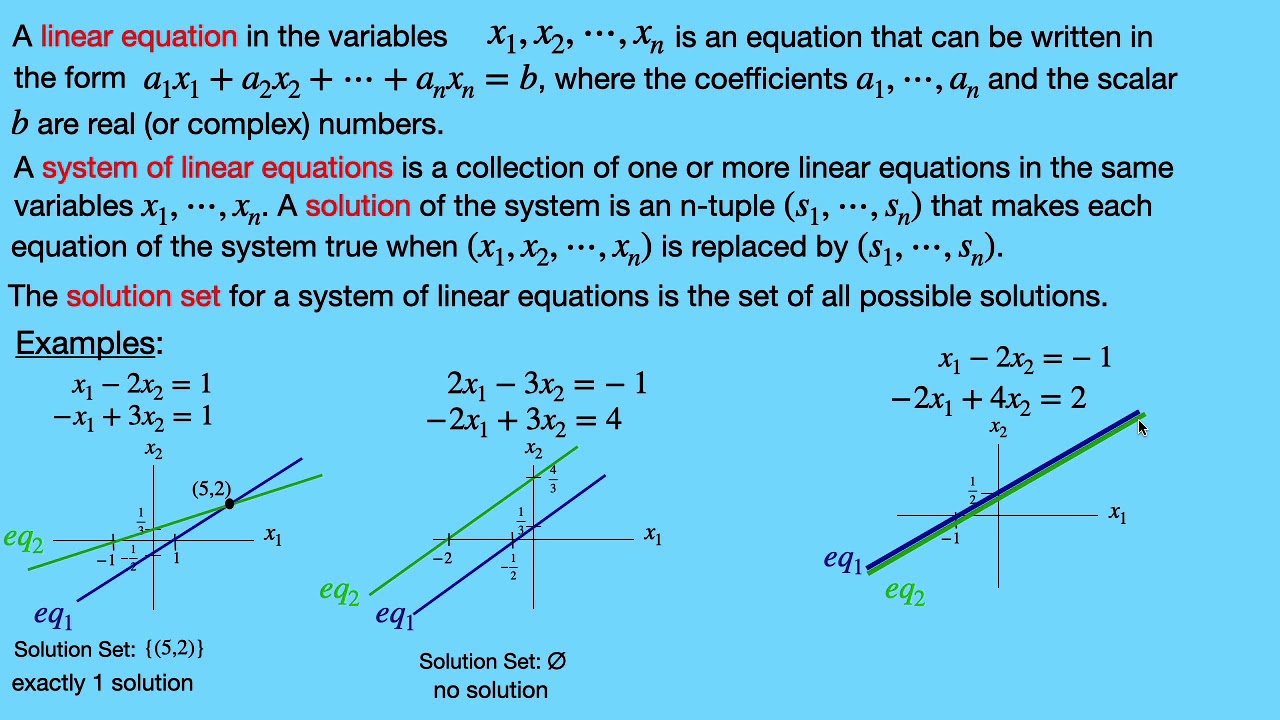
Not every system has a solution, and not every system that appears to have one actually does. There are three possible outcomes: a unique solution, infinitely many solutions, or no solution at all. Row reduction makes this obvious. If you end up with a row of zeros equal to a nonzero value — something like 0 = 5 — the system is inconsistent and has no solution. If you end up with a row of all zeros, the system has free variables and infinitely many solutions. Here's a specific case I ran into that wasn't obvious at first. I was modeling a simple electrical circuit with three loops and found that Gaussian elimination produced a row of zeros with a zero on the right side. At first glance, that looks like infinitely many solutions. But when I traced it back to the original equations, two of the loops were actually dependent — they described the same physical constraint. The system was underdetermined because the circuit diagram had redundant equations, not because the physics allowed multiple valid current distributions. This distinction matters because if you're building a simulation, treating redundant equations as genuinely underdetermined can lead you to impose artificial constraints that distort your results. Sparse matrices are another common gotcha. Most real-world systems — whether from finite element models, network flow problems, or differential equation discretizations — have matrices where the vast majority of entries are zero. Standard Gaussian elimination fills in those zeros, a phenomenon called fill-in. A sparse 10,000 by 10,000 system can become a dense matrix after elimination, exploding from a few hundred kilobytes to several gigabytes of memory. The workaround is to use sparse matrix storage formats and iterative solvers like conjugate gradient or GMRES, which never form the full dense matrix.
Practical Tools And What To Actually Use
If you're doing this by hand for homework, stick with elimination for 2x2 and 3x3 systems. Write out each step clearly. If you're using software, don't write your own Gaussian elimination — it will be slower and less accurate than optimized libraries. NumPy's solve function uses LAPACK, which is battle-tested. For large sparse systems, use SciPy's sparse linear algebra module or an iterative solver. MATLAB's backslash operator automatically selects the best algorithm based on matrix properties, which is why most engineers just write x = A\b and move on. For download links and implementations, the SciPy documentation at docs.scipy.org provides ready-to-use functions that handle the numerical details correctly. NumPy's linalg module covers dense systems. If you need something for educational purposes, sympy handles symbolic solutions and shows exact arithmetic without floating point error, which is useful for understanding the structure of a system before committing to numerical methods. The fundamental principle to keep in mind is that the math is straightforward and the difficulty lies in recognizing which tool matches which problem structure. A well-conditioned small system is solved correctly by almost any method. A large sparse system requires sparsity-aware algorithms. An ill-conditioned system needs regularization or reformulation. Understanding what makes your particular system fall into one of those buckets is worth more than memorizing any single algorithm.