Understanding the T RC Time Constant in Practical Circuits
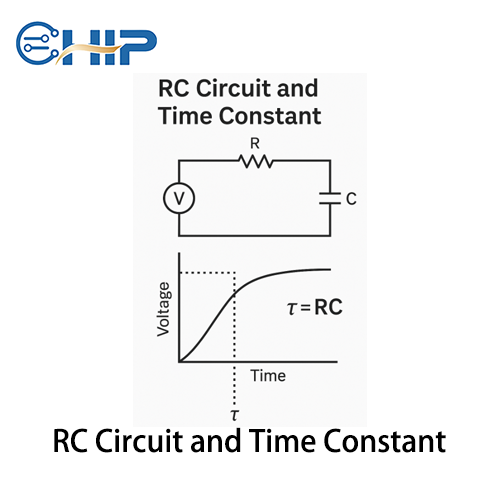
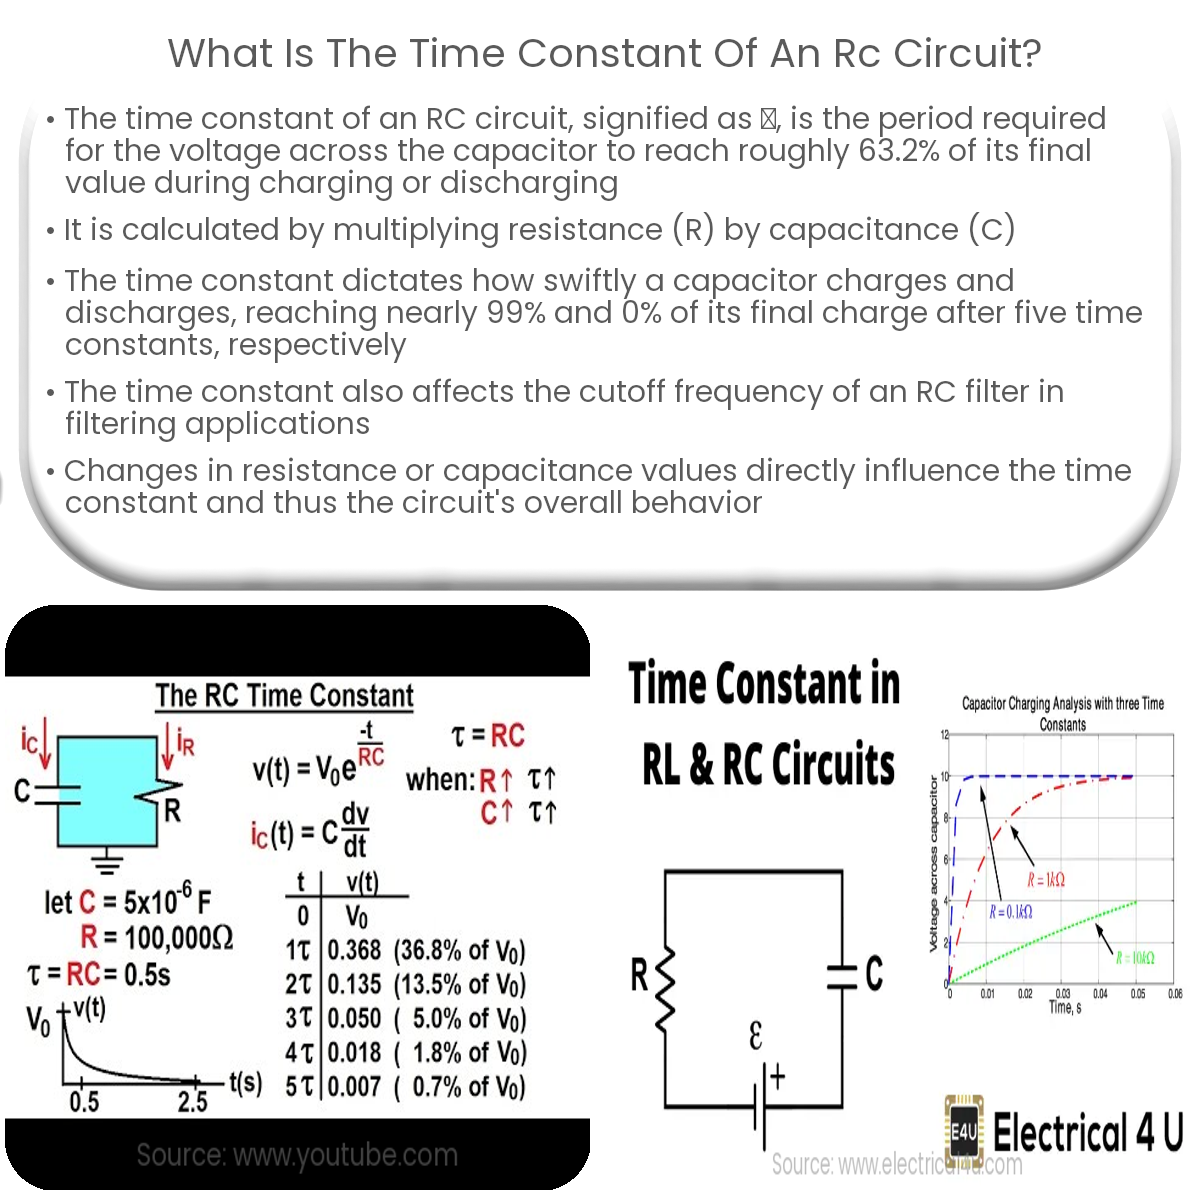
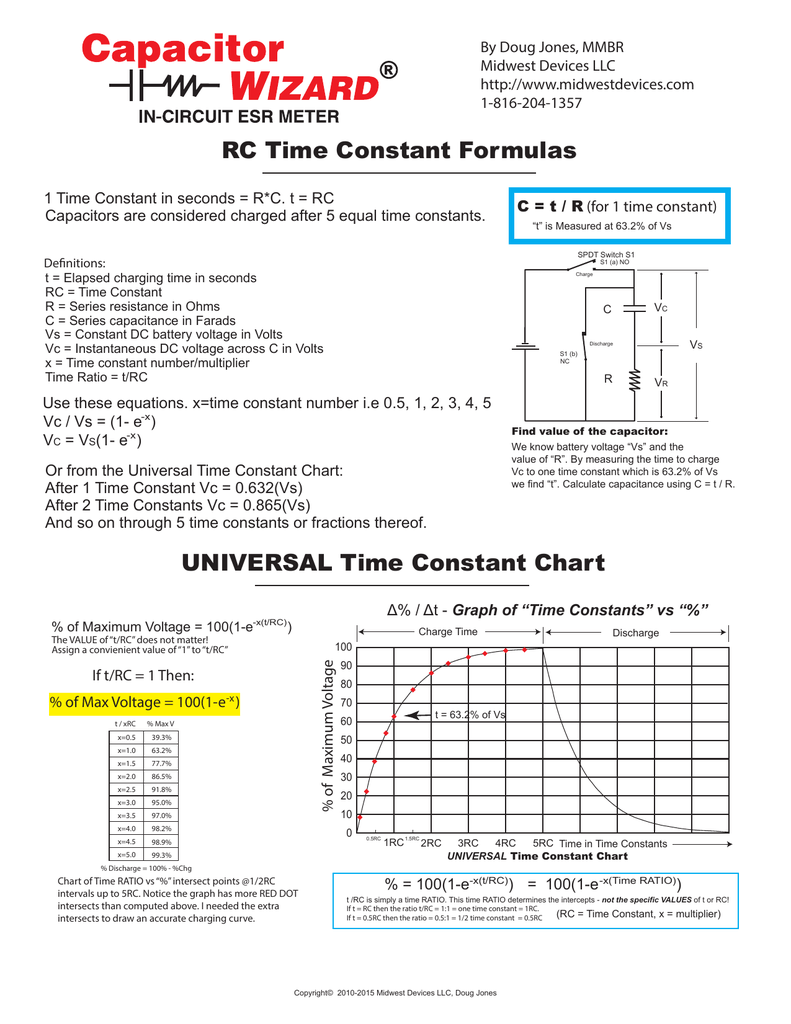
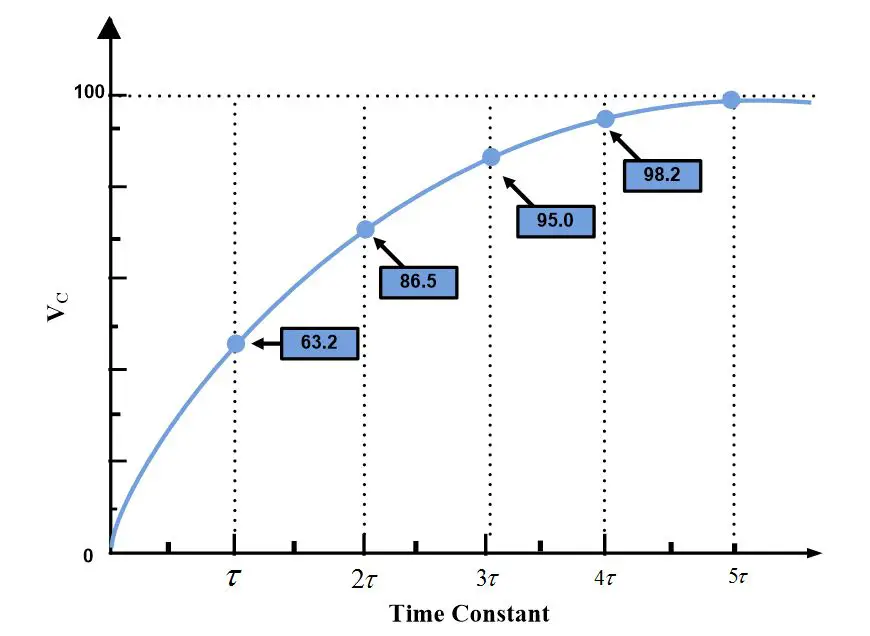
The RC time constant, often written as tau (), is simply the product of resistance and capacitance in a circuit. It tells you how quickly a capacitor charges or discharges through a resistor. One time constant equals approximately 63.2% of the voltage change from the starting point toward the final value. Five time constants gets you to about 99.3%, which most people treat as "fully charged" even though the exponential curve never technically reaches 100%. When I first started designing filter circuits and timing applications, I treated the formula = R × C like gospel. It works for ideal components, but real life has parasitic elements that mess things up. I spent two weeks debugging a timing circuit that was running 18% slow compared to my calculations. The issue? The capacitor's equivalent series resistance (ESR) was adding roughly 47 ohms to the intended 10 kilohm resistor, shifting the effective time constant without my measuring equipment catching it. A bench DMM with ohms mode isn't going to tell you this either, because you're measuring resistance with power off and ESR is a frequency-dependent property. The fix was straightforward once I knew what to look for. I pulled the datasheet for that specific capacitor part number, found the ESR spec at the operating frequency, and added it to my resistance value in the calculation. If you're working with electrolytic capacitors in anything above a few hundred hertz, checking ESR isn't optional. Ceramic capacitors have much lower ESR but introduce their own problem: capacitance changes with applied DC bias voltage. A 10 microfarad ceramic cap can lose 40 to 60% of its rated capacitance at full operating voltage, which completely throws off your time constant calculations if you don't account for it.
Here is the basic math for reference. If you have a 10 kilohm resistor and a 1 microfarad capacitor, the time constant is 10 milliseconds. Charging from 0 volts to a 5 volt supply, the voltage after one time constant will be about 3.16 volts. After two time constants, roughly 4.32 volts. After three, around 4.75 volts. The formula for voltage at any time t during charging is V(t) = V_source × (1 - e^(-t/)), and for discharging it's V(t) = V_initial × e^(-t/). These equations assume an ideal step input, which brings me to another common oversight.
Where People Get This Wrong
The biggest mistake I see in hobbyist and entry-level engineering work is assuming the input to an RC circuit is an instantaneous step. Microcontroller GPIO pins have output impedance, typically between 25 and 50 ohms depending on the processor. When you're timing something precise like a PWM duty cycle measurement or an ADC sampling window, that output impedance adds to your resistor and changes the actual time constant. On a typical Arduino running at 5 volts with a 10 kilohm pull-down and a 100 nanofarad capacitor, the built-in pin resistance shifts by about 0.3%, which sounds negligible until you're building a precision delay line or a sensor interface circuit. Another thing nobody warns you about: temperature coefficient. Capacitor values drift with temperature, and resistor values do too. Aluminum electrolytics can shift by plus or minus 20% across their rated temperature range. X7R ceramic capacitors are relatively stable at plus or minus 15% over temperature. If you need stability, C0G/NP0 ceramics are the way to go, holding within plus or minus 30 parts per million over temperature. But they come in smaller capacitance values at reasonable cost, so you end up balancing multiple constraints. I also want to mention a scenario where the time constant approach breaks down entirely. When you're driving a long cable with an RC network, the cable's capacitance becomes part of your circuit. A 50-foot shielded cable can add 2000 to 3000 picofarads of capacitance. If your design assumes a 100 picofarad load and you add that cable, your time constant just increased by 10 to 30 times. The workaround is to use a low-impedance driver or terminate the cable properly rather than trying to recalculate the entire passive network.
Get the Full Details

Measuring It Yourself
If you want to verify your time constant experimentally, you don't need expensive equipment. A standard oscilloscope with a 10 megohm probe is sufficient. Apply a square wave from a function generator or even a microcontroller pin at a frequency low enough that the capacitor has time to fully charge and discharge within each half-cycle. A good rule of thumb is to set the period to at least 10 times your expected time constant. Measure the voltage at the capacitor node and find the point where it crosses 63.2% of the full swing during charging. The time elapsed from the rising edge to that point is your measured tau. For resistance values below 1 kilohm, the 10 megohm input impedance of most oscilloscope probes creates a parallel path that skews your measurement. In that case, you can use the two-point method instead. Record the voltage at two different times during charging, then solve for tau using the equation = (t2 - t1) / ln[(V_final - V1)/(V_final - V2)]. This method cancels out the probe impedance issue because you're working with ratios rather than absolute values.
When to Use Different Approaches
For simple debounce circuits on mechanical switches, a rough calculation based on nominal component values is usually adequate. A 10 kilohm resistor and 0.1 microfarad capacitor gives you 1 millisecond of filtering, which handles most switch bounce. Component tolerance won't matter much because the bounce period is in the single-digit millisecond range anyway. For precision timing applications like sensor interfacing or ADC hold circuits, you need to be much more careful. The TI TMS320F28379D microcontroller datasheet recommends an external RC filter on the ADC input with a time constant between 10 and 100 microseconds, and it explicitly notes that the source impedance must be considered. If you're sampling at 200 kilosamples per second, each conversion window is 5 microseconds. Your RC network needs to settle well within that window, which means using a time constant roughly one-fifth or less of the sampling period. That's 2 microseconds or under for this particular chip. Power supply filtering is a different domain altogether. The RC time constant here governs how quickly the output can respond to load transients. A long time constant means good ripple rejection but poor transient response. A short time constant means the opposite. This is why switched-mode power supplies rarely rely on a single RC filter stage, and why you'll see multi-stage LC filters or active feed-forward compensation in designs that need both good ripple attenuation and fast transient recovery.
One last practical note: if you're building a circuit that sits in a temperature-fluctuating environment, measure your actual time constant at the extremes of your operating range, not just at room temperature. I had a project where the calculated tau at 25 degrees Celsius was 50 milliseconds, but at 70 degrees it shifted to 58 milliseconds due to capacitor drift. The system was designed with a 45-millisecond timeout, so it started failing sporadically in hot conditions. The fix was swapping to a temperature-compensated capacitor and redesigning the timeout to 65 milliseconds, which gave us margin across the full range.